Cooperative ankle-exoskeleton control can reduce effort to recover balance after unexpected disturbances during
Cristina Bayón1, Arvid Q L Keemink2, Michelle van Mierlo2
1Department of Biomechanical Engineering, University of Twente, Enschede, The Netherlands. c.bayoncalderon@utwente.nl.

Background:
In the last two decades, lower-limb exoskeletons have been developed to assist human standing and locomotion. One of the ongoing challenges is the cooperation between the exoskeleton balance support and the wearer control. Here we present a cooperative ankle-exoskeleton control strategy to assist in balance recovery after unexpected disturbances during walking, which is inspired on human balance responses.
Methods:
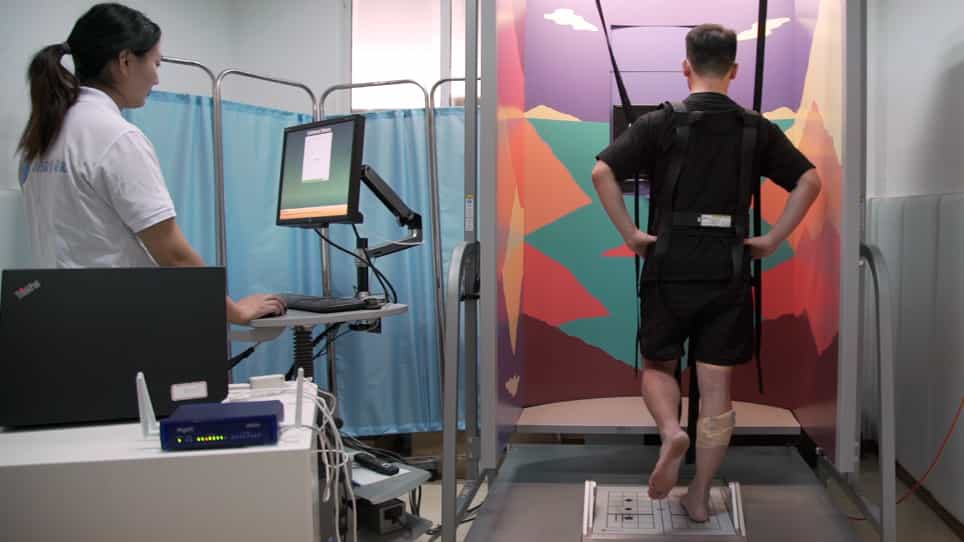
We evaluated the novel controller in ten able-bodied participants wearing the ankle modules of the Symbitron exoskeleton. During walking, participants received unexpected forward pushes with different timing and magnitude at the pelvis level, while being supported (Exo-Assistance) or not (Exo-NoAssistance) by the robotic assistance provided by the controller. The effectiveness of the assistive strategy was assessed in terms of (1) controller performance (Detection Delay, Joint Angles, and Exerted Ankle Torques), (2) analysis of effort (integral of normalized Muscle Activity after perturbation onset); and (3) Analysis of center of mass COM kinematics (relative maximum COM Motion, Recovery Time and Margin of Stability) and spatio-temporal parameters (Step Length and Swing Time).
Results:
In general, the results show that when the controller was active, it was able to reduce participants' effort while keeping similar ability to counteract and withstand the balance disturbances. Significant reductions were found for soleus and gastrocnemius medialis activity of the stance leg when comparing Exo-Assistance and Exo-NoAssistance walking conditions.
Conclusions:
The proposed controller was able to cooperate with the able-bodied participants in counteracting perturbations, contributing to the state-of-the-art of bio-inspired cooperative ankle exoskeleton controllers for supporting dynamic balance. In the future, this control strategy may be used in exoskeletons to support and improve balance control in users with motor disabilities.