Related Experiment Video
Updated: Oct 3, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Neuro-adaptive containment control of unmanned surface vehicles with disturbance observer and collision-free
Qun Deng1, Yan Peng1, Dong Qu1
1The School of Mechatronics Engineering and Automation, Shanghai University, Shanghai, 200444, China.

Abstract:
The adaptive containment control problem with collision avoidance is investigated for unmanned surface vehicles (USVs). At first, the finite time disturbance observer is developed to present the estimation and compensation of external disturbance. Then, incorporating the artificial potential and radial basis function into the new containment strategy, all followers can enter the convex hull spanned by leaders while the collision is avoided. Furthermore, it is demonstrated that the error signals in the closed-loop system are boundedness by employing Lyapunov stability. Simulation studies finally manifest the effectiveness of proposed method.

Related Concept Videos
 01:10
Control Systems
At the heart...
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:15
Elastic Collisions: Case Study
 01:14
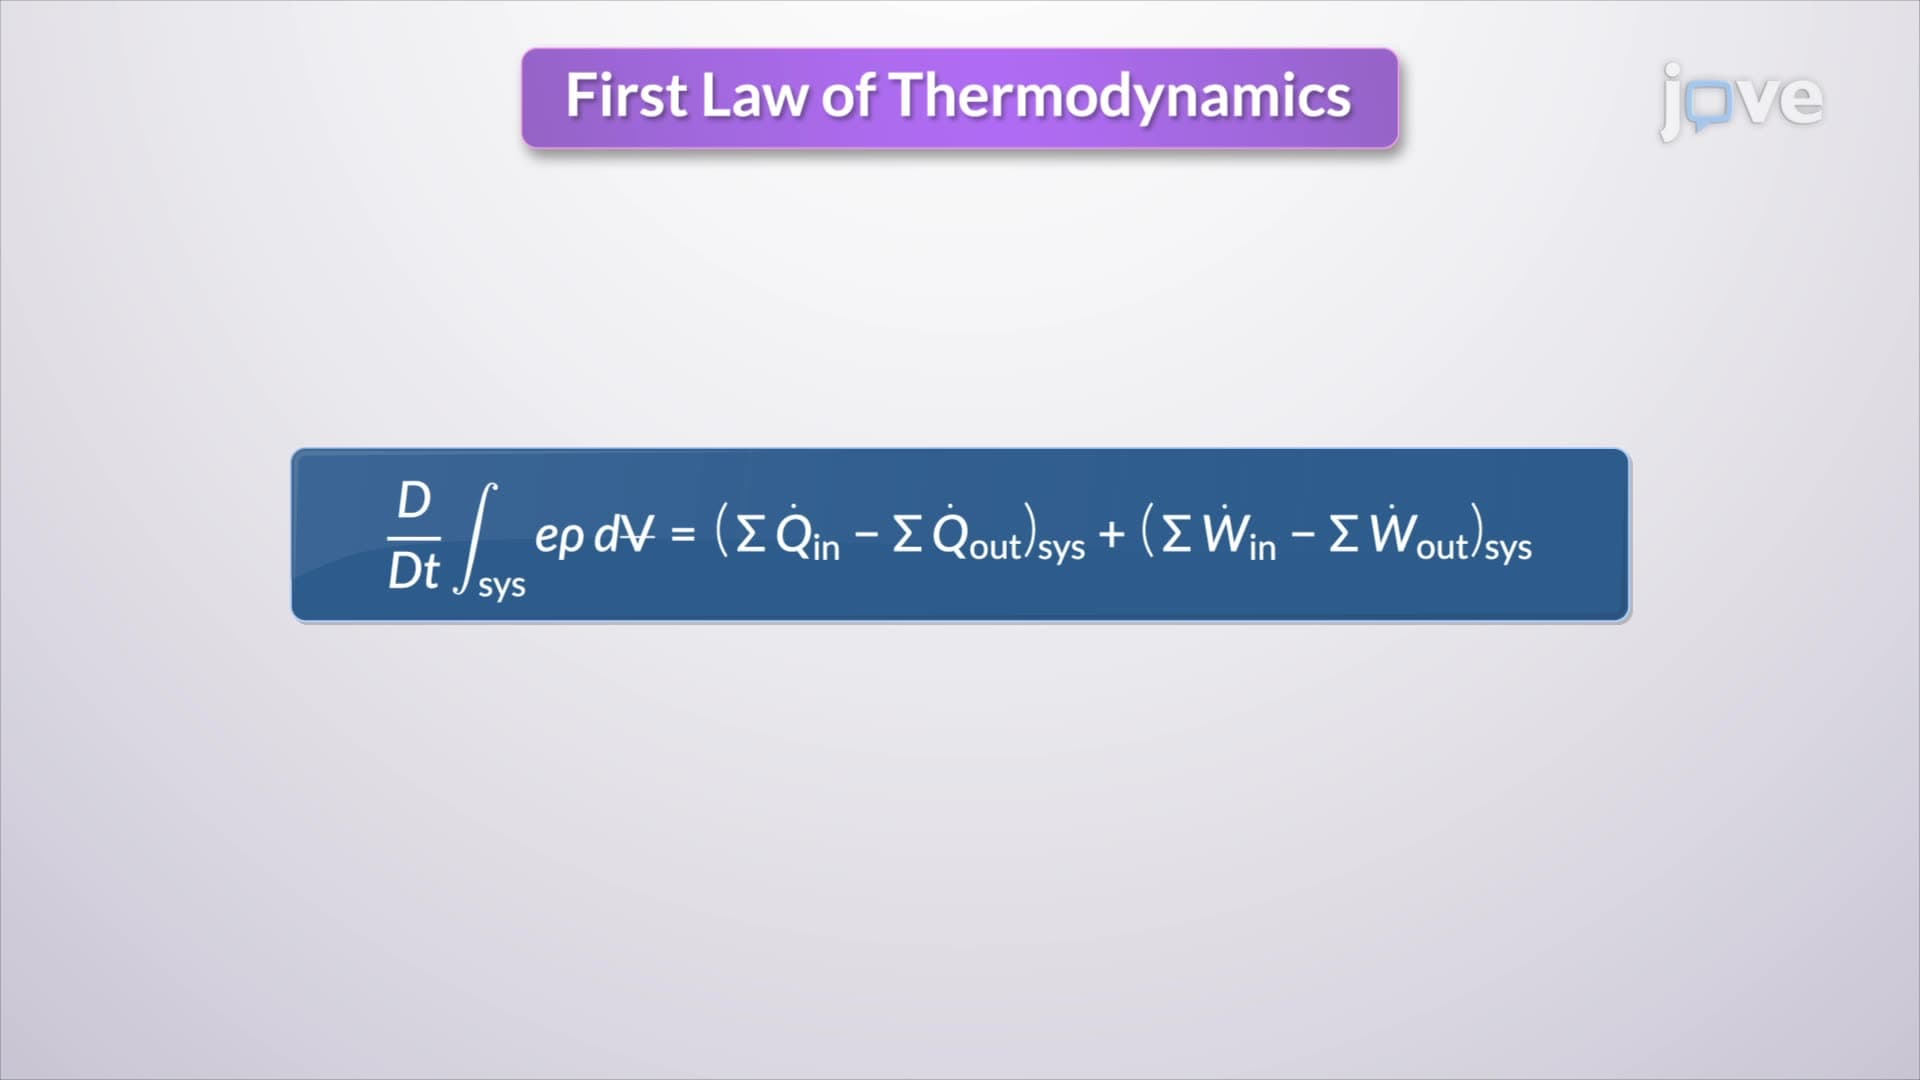
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:00
Elastic Collisions: Introduction