Related Experiment Video
Updated: Oct 2, 2025


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Embodied neuromorphic intelligence
Chiara Bartolozzi1, Giacomo Indiveri2, Elisa Donati2
1Event-Driven Perception for Robotics, Istituto Italiano di Tecnologia, via San Quirico 19D, 16163, Genova, Italy. chiara.bartolozzi@iit.it.

Abstract:
The design of robots that interact autonomously with the environment and exhibit complex behaviours is an open challenge that can benefit from understanding what makes living beings fit to act in the world. Neuromorphic engineering studies neural computational principles to develop technologies that can provide a computing substrate for building compact and low-power processing systems. We discuss why endowing robots with neuromorphic technologies - from perception to motor control - represents a promising approach for the creation of robots which can seamlessly integrate in society. We present initial attempts in this direction, highlight open challenges, and propose actions required to overcome current limitations.
Related Concept Videos
 01:01
Neuroplasticity
 01:25
Neural Circuits
Neuronal pools are collections of nerve cells with similar functions and interact through chemical and electrical signals. These pools include both interneurons (the central neural circuit nodes that...
 01:10
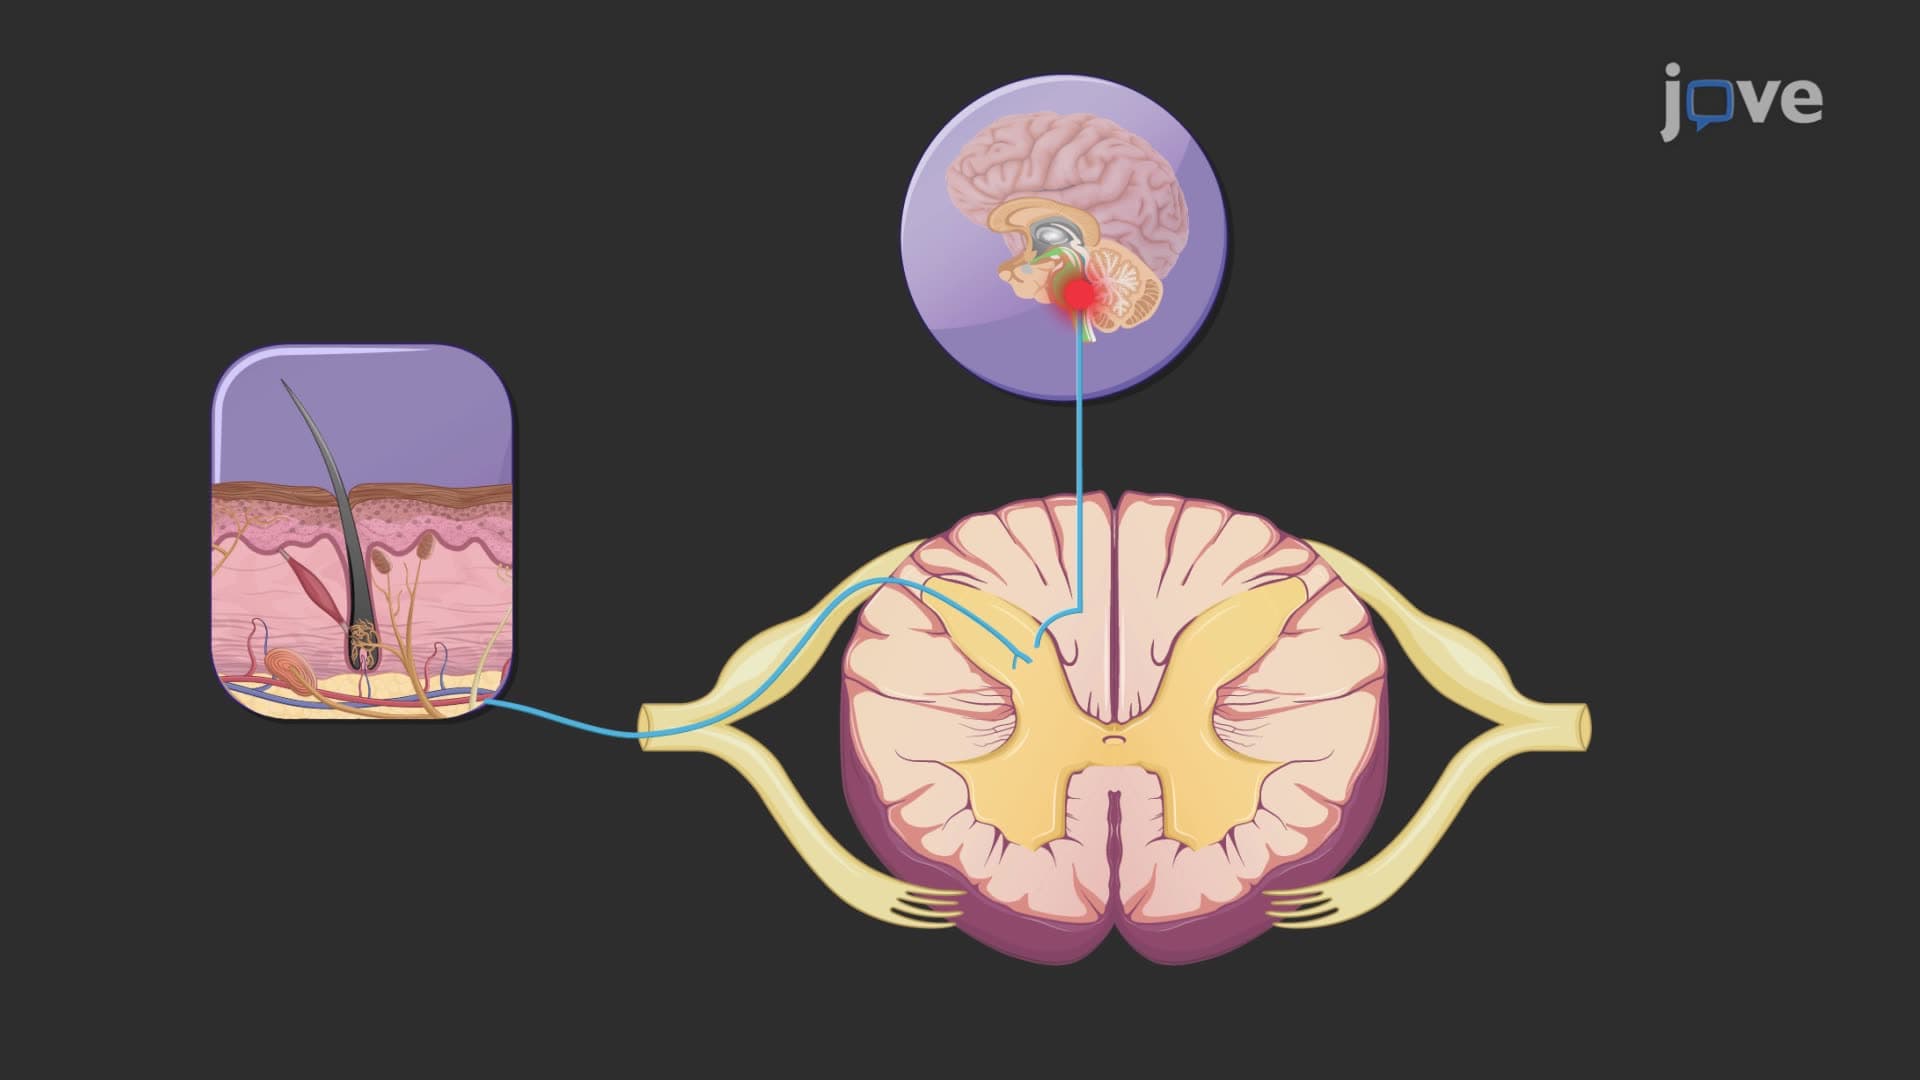
Spinal Cord: Information Processing
Sensory Information Processing
Sensory information processing begins at the sensory receptors located in the skin and other tissues, which detect somatic sensory stimuli such as touch, temperature, or pain. These receptors function as catalysts, initiating...
 01:27
Intelligence
 01:13
Nonconscious Mimicry
 01:24
Triarchic Theory of Intelligence