Geometric Parameter Identification of Medical Robot Based on Improved Beetle Antennae Search Algorithm
Related Experiment Video
Updated: Oct 2, 2025
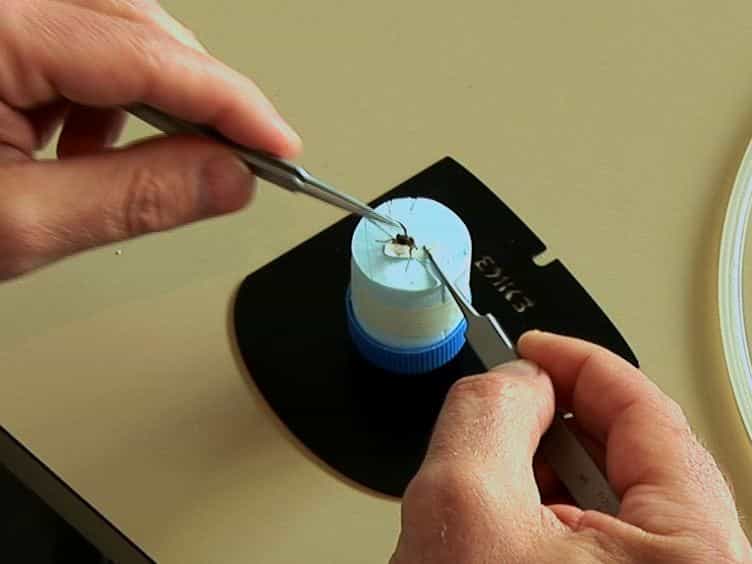
Using Insect Electroantennogram Sensors on Autonomous Robots for Olfactory Searches
Published on: August 4, 2014
Bin Kou1,2, Dongcheng Ren1,2, Shijie Guo1,2
1Academy for Engineering and Technology, Fudan University, Shanghai 200433, China.

Abstract:
To improve the accuracy of common intelligent algorithms when identifying the parameters of geometric error in medical robots, this paper proposes an improved beetle antennae search algorithm (RWSAVSBAS). We first establish a model for the kinematic error in medical robots, and then add the random wandering behavior of the wolf colony algorithm to the search process of the beetle antennae search algorithm to strengthen its capability for local search. Following this, we improve the global convergence ability of the beetle antennae search algorithm by using the simulated annealing algorithm. We compare the accuracy of end positioning of the proposed algorithm with the frog-jumping algorithm and the beetle antennae search algorithm with variable step length through simulations. The results show that the proposed algorithm has a higher accuracy of convergence, and can significantly improve the accuracy of end positioning of the medical robot.
More Related Videos
 08:13
SwarmSight: Real-time Tracking of Insect Antenna Movements and Proboscis Extension Reflex Using a Common Preparation and Conventional Hardware
Published on: December 25, 2017
 10:17
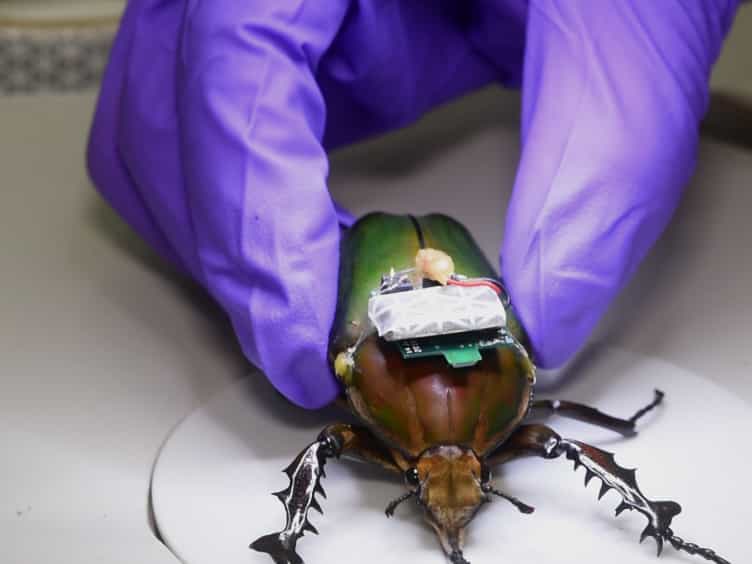
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016