New Flexible Tactile Sensor Based on Electrical Impedance Tomography
Related Experiment Video
Updated: Oct 2, 2025
Monitoring Lung Function with Electrical Impedance Tomography in the Intensive Care Unit
Published on: September 6, 2024
Haibin Wu1, Bingying Zheng1, Haomiao Wang1
1School of Mechanical Engineering and Automation, Fuzhou University, Fuzhou 350116, China.

Abstract:
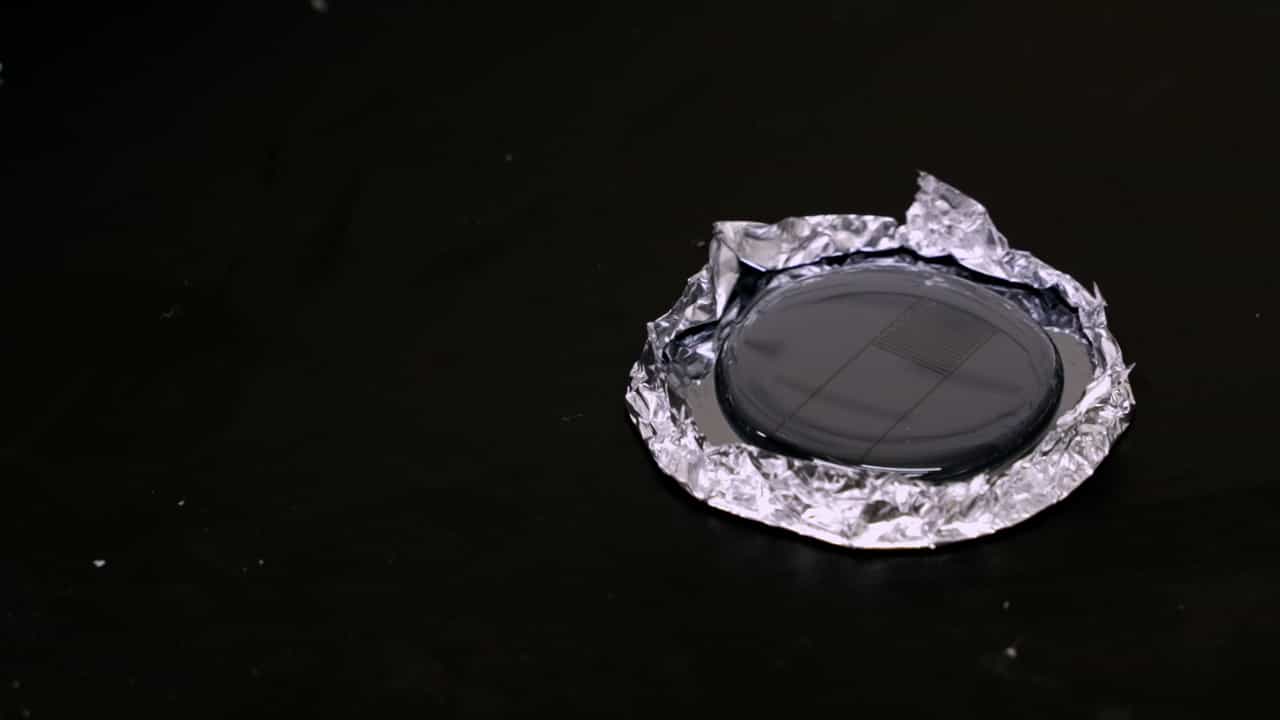
In order to obtain external information and ensure the security of human-computer interaction, a double sensitive layer structured tactile sensor was proposed in this paper. Based on the EIT (Electrical Impedance Tomography) method, the sensor converts the information from external collisions or contact into local conductivity changes, and realizes the detection of one or more contact points. These changes can be processed into an image containing positional and force information. The experiments were conducted on the actual sensor sample. The OpenCV toolkit was used to process the positional information of contact points. The distributional regularities of errors in positional detection were analyzed, and the accuracy of the positional detection was evaluated. The effectiveness, sensitivity, and contact area of the force detection were analyzed based on the result of the EIT calculations. Furthermore, multi-object tests of pressure were conducted. The results of the experiment indicated that the proposed sensor performed well in detecting the position and force of contact. It is suitable for human-robot interaction.