Related Experiment Video
Updated: Oct 2, 2025


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Spherical Robots for Special Purposes: A Review on Current Possibilities
Marek Bujňák1, Rastislav Pirník1, Karol Rástočný1
1Faculty of Electrical Engineering and Information Technology, University of Zilina, 010 26 Zilina, Slovakia.

Abstract:
The review discusses the possibilities of different driving mechanisms and sensors of spherical robots, and a special kind of mobile robots is introduced and discussed. The sensors discussed can expand robots' sensing capabilities which are typically very limited. Most spherical robots have holonomic characteristics and protect the inner environment using a shell. Today, there are a diversity of driving mechanisms. Therefore, this article provides a review of all of them and identifies their basic properties. Accordingly, many spherical robots have only inner sensors for moving, balancing, driving, etc. However, a few of them are also equipped with sensors that can measure environmental properties. Therefore, in this paper, we propose the possibility of using such sensors as cameras, LiDARs, thermocouples, and gas sensors, which can be used for special purposes underground, for example, in mines, underground tunnels, or road tunnels. After combining all components are combined, it is possible to design a special type of spherical robot designed for underground exploration, such as accidents in mines or road tunnels.


Related Concept Videos
 01:23
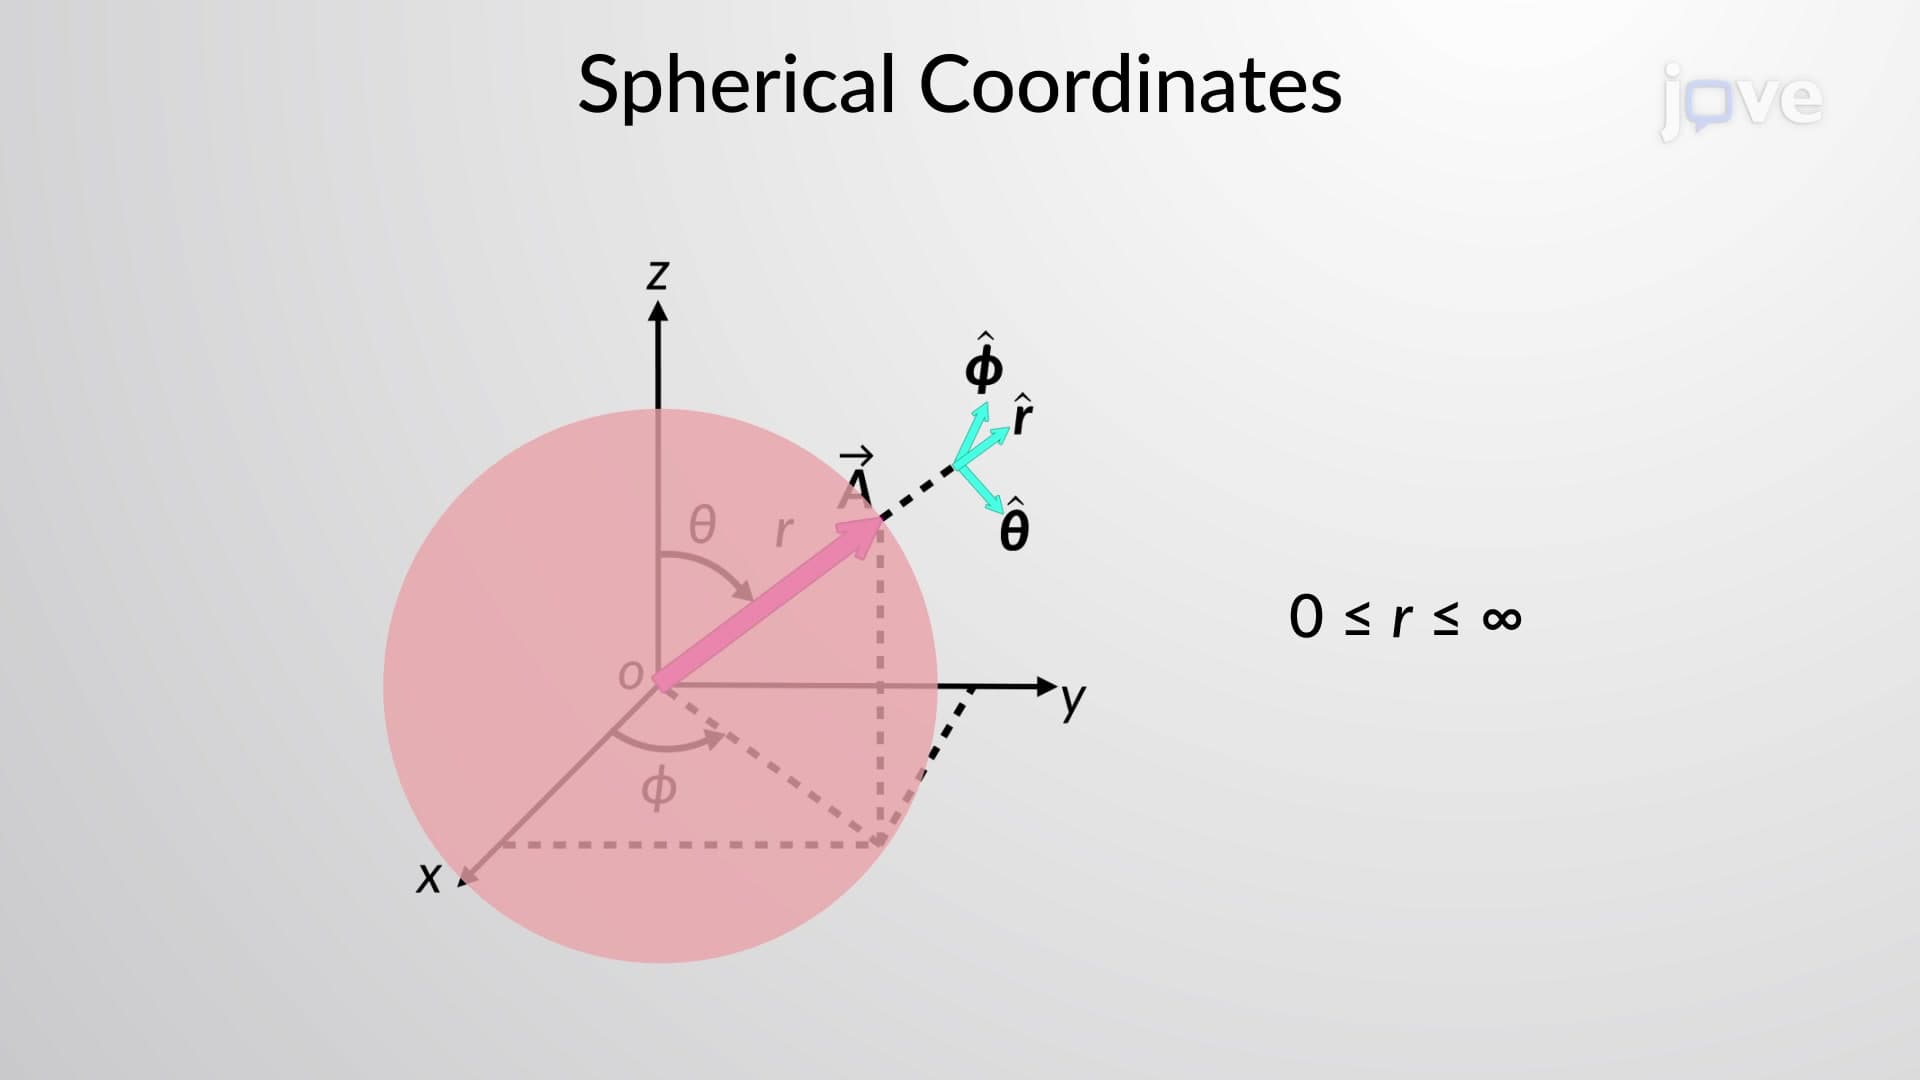
Spherical Coordinates
 01:26
Gauss's Law: Spherical Symmetry