Related Experiment Video
Updated: Oct 1, 2025
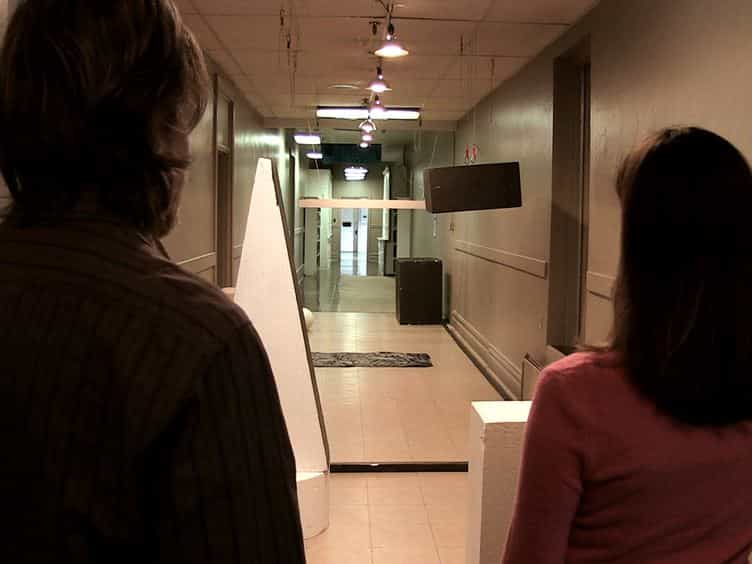

A Standardized Obstacle Course for Assessment of Visual Function in Ultra Low Vision and Artificial Vision
Published on: February 11, 2014
Effects of vision on energy expenditure and kinematics during level walking
Ola Eiken1, Igor B Mekjavic2, Jan Babič2
1Division of Environmental Physiology, School of Chemistry, Biotechnology and Health, KTH Royal Institute of Technology, Berzelius v. 13, 171 65, Stockholm, Sweden. eiken@kth.se.

Purpose:
We have previously observed substantially higher oxygen uptake in soldiers walking on terrain at night than when performing the same walk in bright daylight. The aims of the present study were to investigate the influence of vision on mechanical efficiency during slow, horizontal, constant-speed walking, and to determine whether any vision influence is modified by load carriage.
Methods:
Each subject (n = 15) walked (3.3 km/h) for 10 min on a treadmill in four different conditions: (1) full vision, no carried load, (2) no vision, no carried load, (3) full vision with a 25.5-kg rucksack, (4) no vision with a 25.5-kg rucksack.
Results:
Oxygen uptake was 0.94 ± 0.12 l/min in condition (1), 1.15 ± 0.20 l/min in (2), 1.15 ± 0.12 l/min in (3) and 1.35 ± 0.19 l/min in (4). Thus, lack of vision increased oxygen uptake by about 19%. Analyses of movement pattern, by use of optical markers attached to the limbs and torso, revealed considerably shorter step length (12 and 10%) in the no vision (2 and 4) than full vision conditions (1 and 3). No vision conditions (2 and 4) increased step width by 6 and 6%, and increased vertical foot clearance by 20 and 16% compared to full vision conditions (1 and 3).
Conclusion:
The results suggest that vision has a marked influence on mechanical efficiency even during entrained, repetitive movements performed on an obstacle-free horizontal surface under highly predictable conditions.
Related Concept Videos
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The...