Use of compliant actuators for throwing rigid projectiles
Related Experiment Video
Updated: Sep 30, 2025
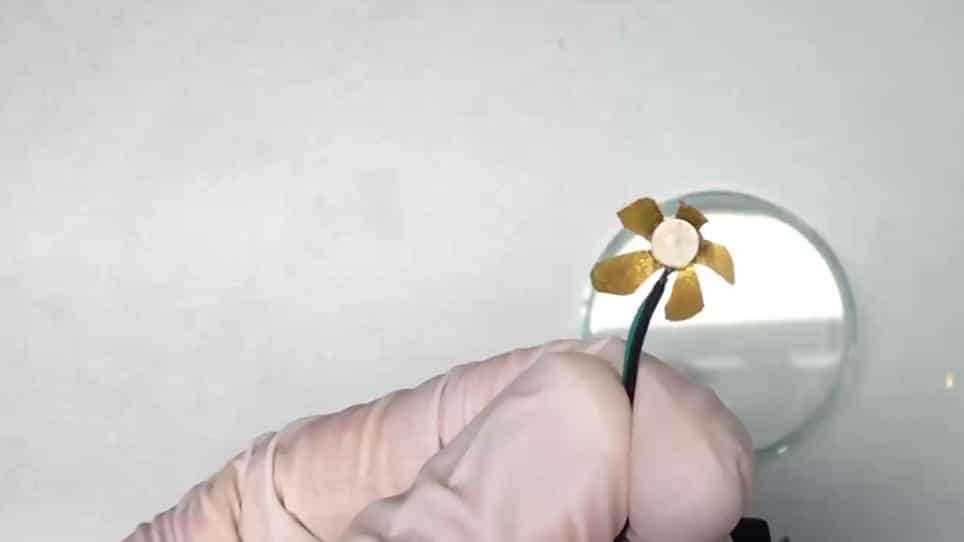
Rapid Manufacturing of Thin Soft Pneumatic Actuators and Robots
Published on: November 8, 2019
Guillaume Giombini1, Joachim Mathiesen2, Christophe D'Angelo1
1Université Côte d'Azur, CNRS, Institut de Physique de Nice (INPHYNI), 06100 Nice, France.

Abstract:
Muscles and tendons, actuators in robotics, and various sports implements are examples that exploit elasticity to accelerate objects. Tuning the mechanical properties of elastic elements connecting objects can greatly enhance the transfer of mechanical energy between the objects. Here, we study experimentally the throw of rigid projectiles by an actuator, which has a soft elastic element added to the distal end. We vary the thickness of the elastic layer and suggest a simple mass-spring chain model to find the properties of the elastic layer, which will maximize the energy transfer from the actuator to the projectile. The insertion of a soft layer, impedance matched to the ejection frequency of the projectile mass, can increase the throwing efficiency by over 400%. Finally, we identify that very thick and very soft compliant layers could potentially lead to high efficiency and flexibility simultaneously.
Related Concept Videos
 01:18
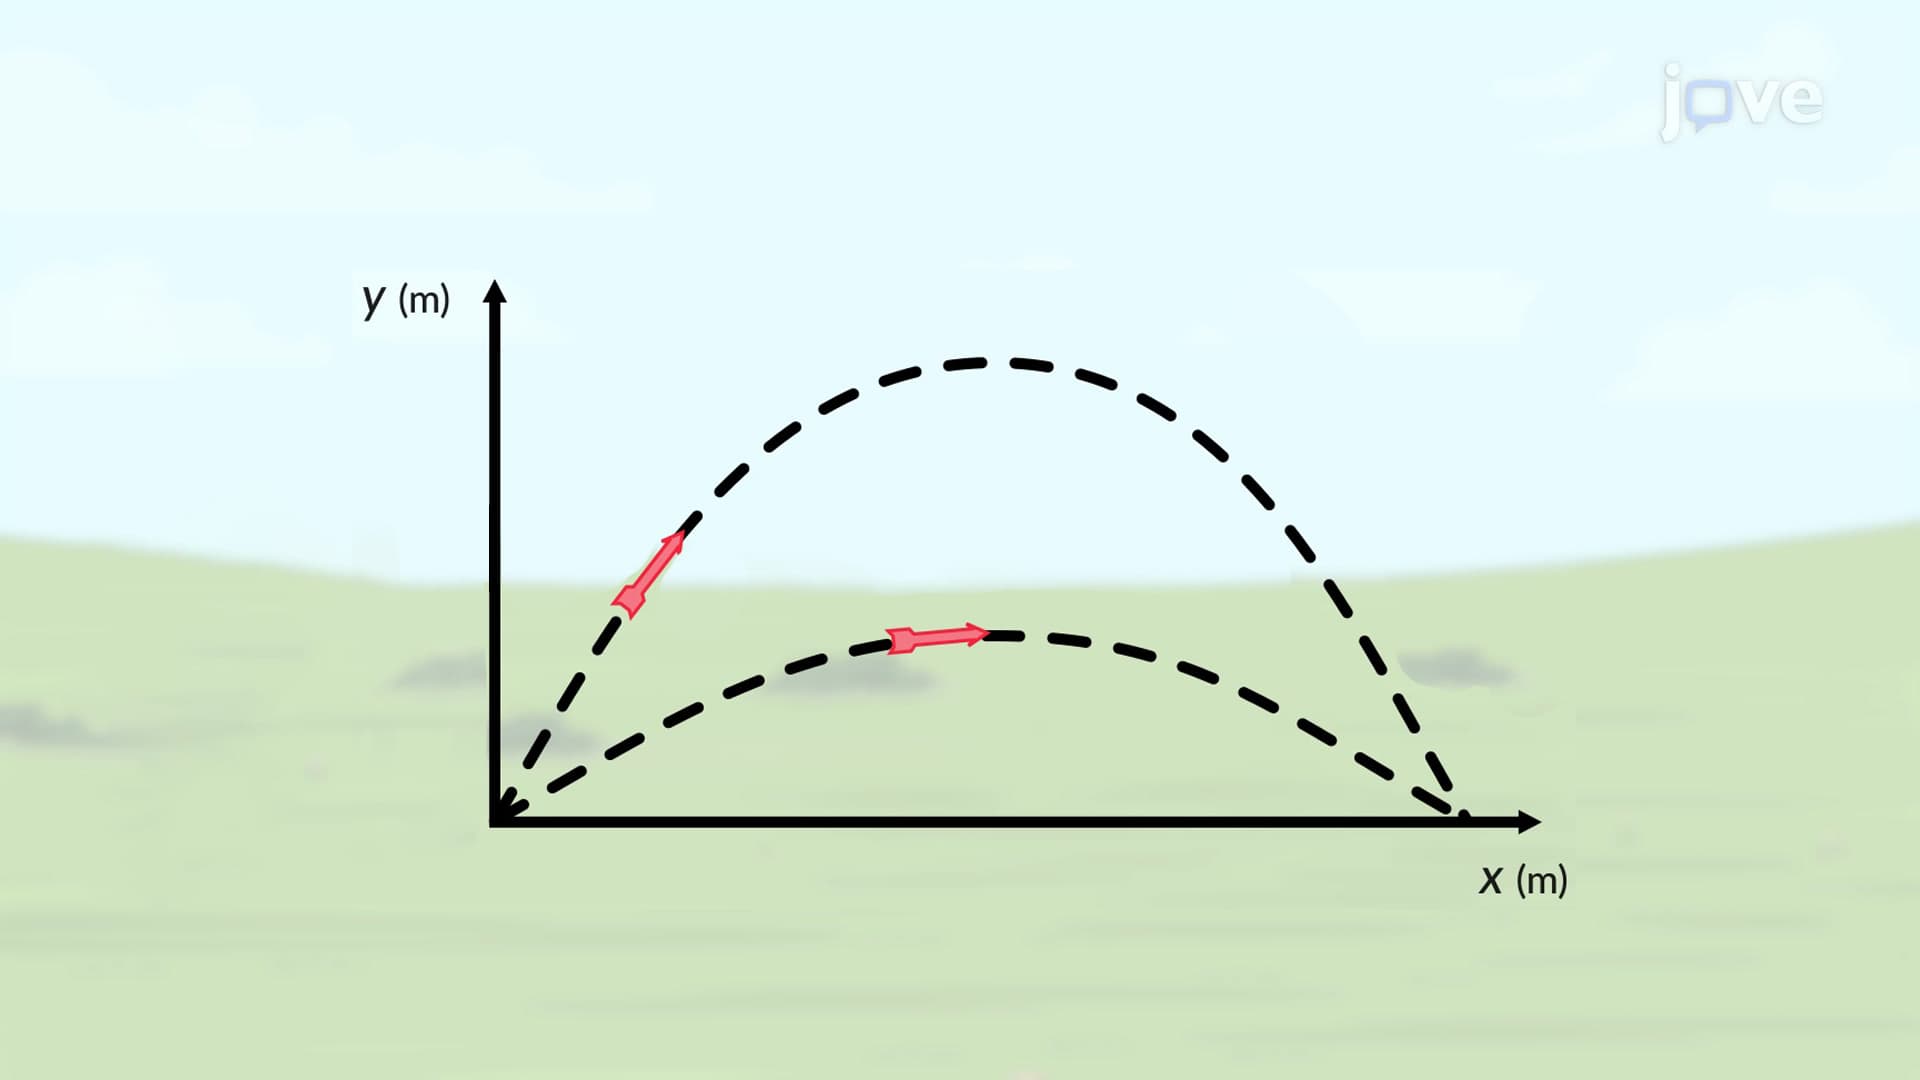
Projectile Motion: Example
When we speak of the range (R) of a projectile on...
 01:20
Projectile Motion
When an object falls under gravity and has no...
 01:23
Motion of a Projectile
Horizontal motion, governed by the initial kick, maintains a constant velocity throughout the flight of the soccer ball.
 01:26
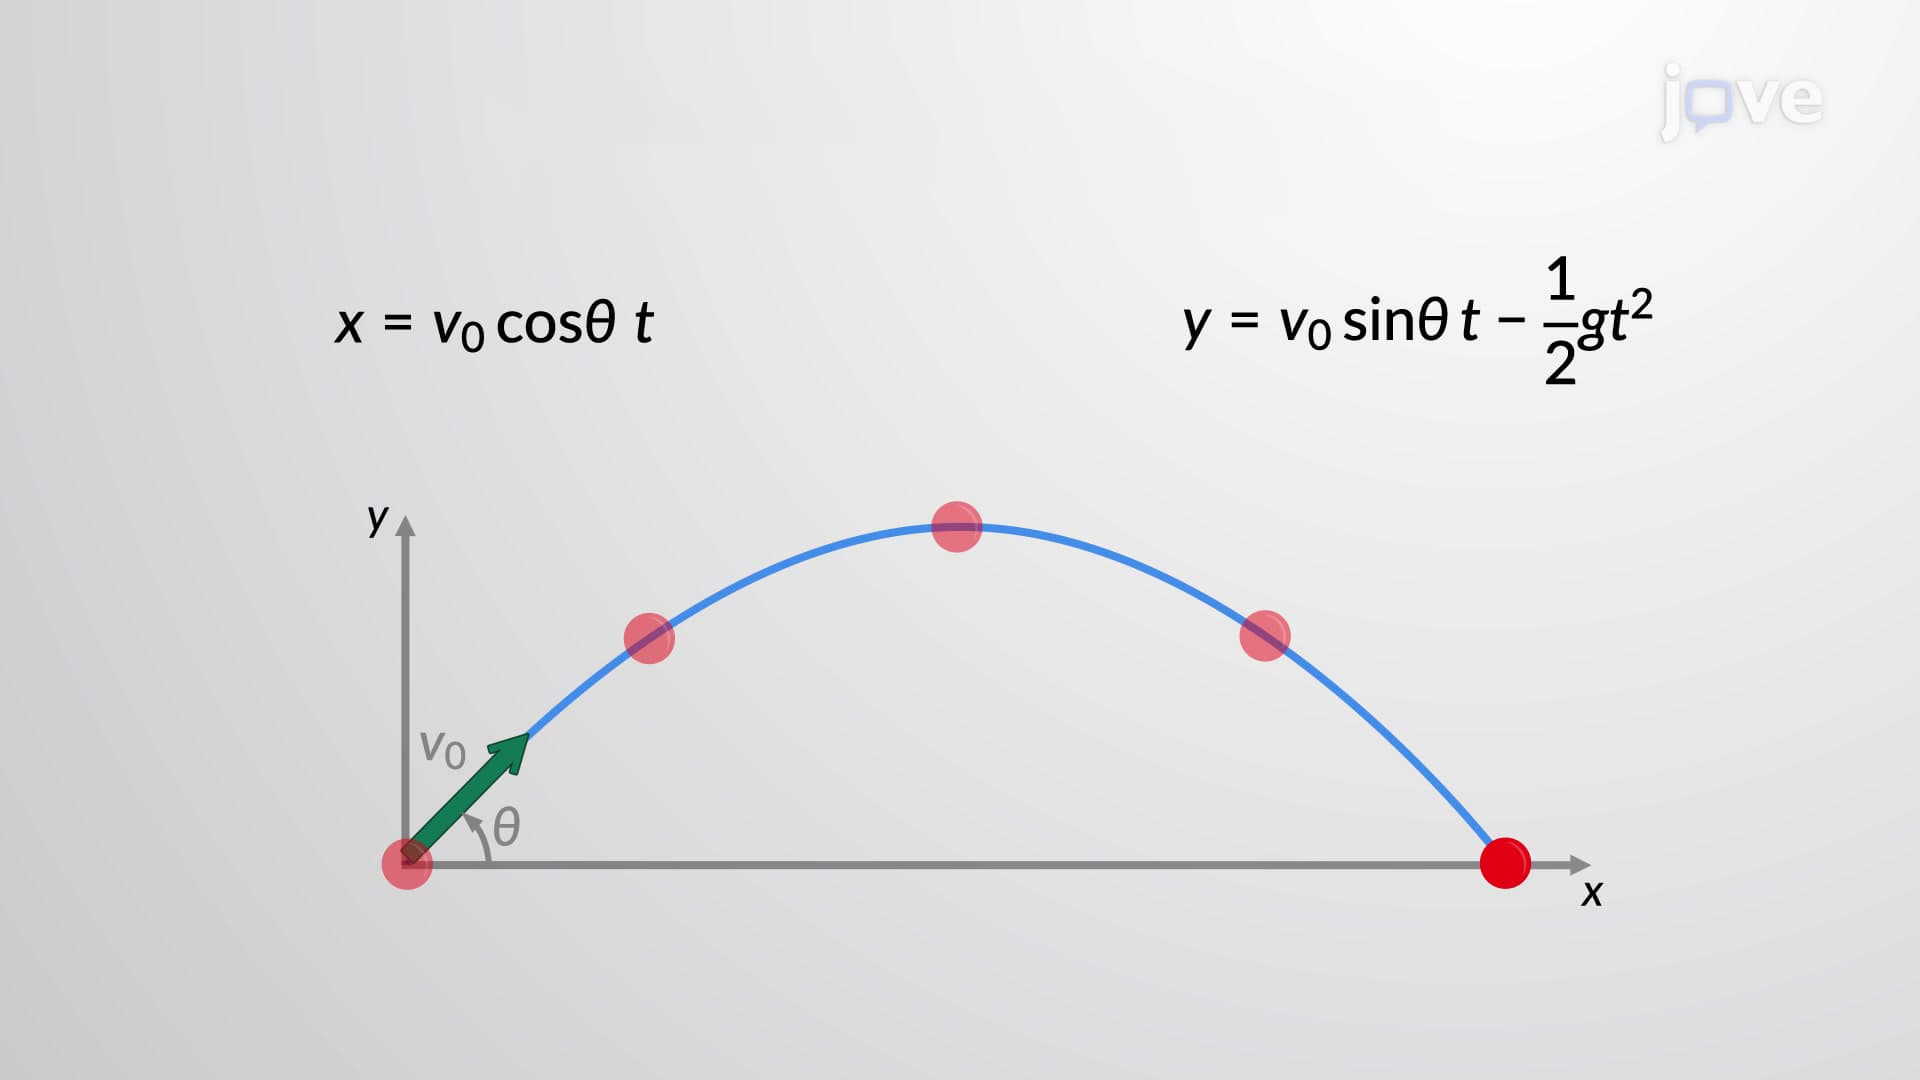
Projectile Motion: Equations
Any projectile motion problem can be solved by using the following strategy:
 01:26
Impact: Problem Solving
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
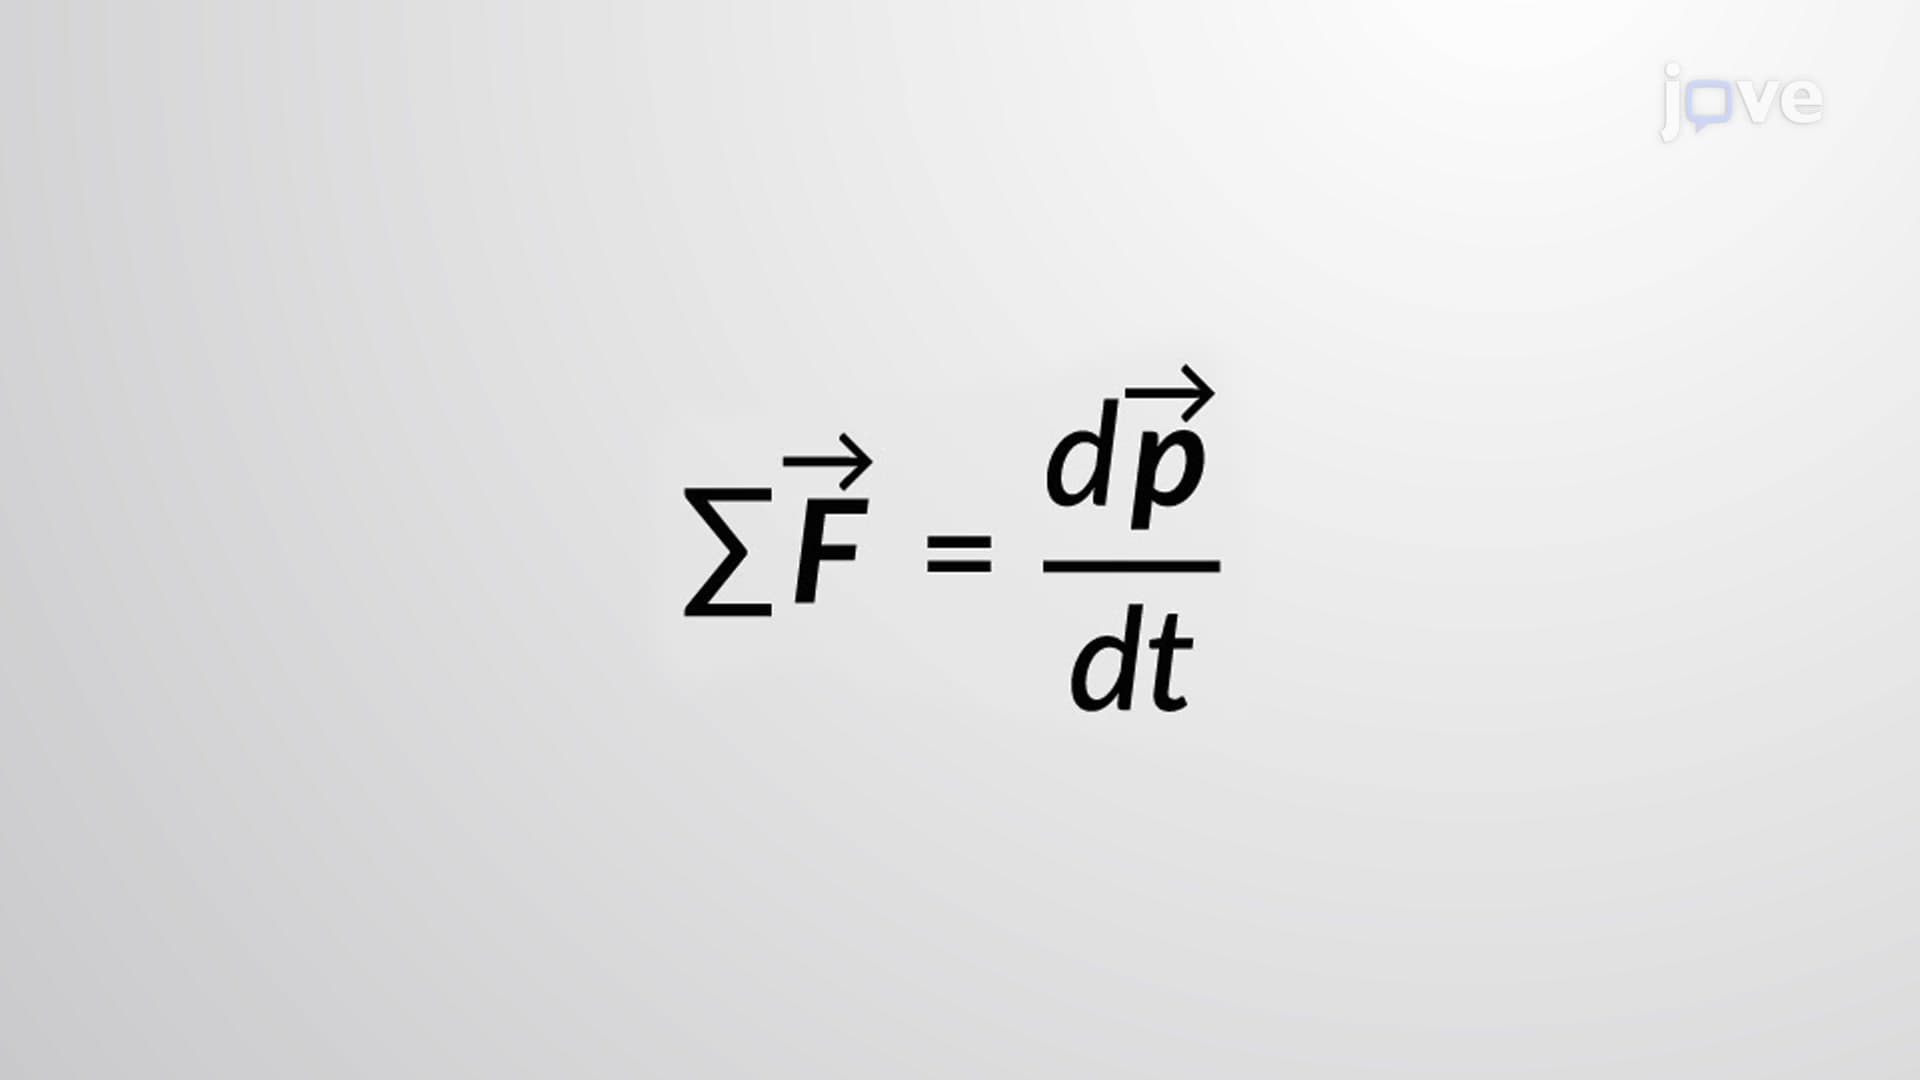 01:17
Force and Momentum