Related Experiment Video
Updated: Sep 29, 2025


Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
Big Data Analysis and Prediction System Based on Improved Convolutional Neural Network
Xuegong Du1, Xiaojun Cao1, Rui Zhang1
1College of Information Engineering, Lanzhou University of Finance and Economics, Lanzhou 730020, China.

Abstract:
This paper presents a big data analysis and prediction system based on convolutional neural networks. Continuous template matching technology is used to analyze the distributed data structure of big data, and the information fusion processing of cloud service combination big data is combined with matching related detection methods, frequent item detection, and association rule feature extraction of high-dimensional fusion data. A clustering method is adopted to realize the classification and mining of cloud service portfolio big data. The hardware equipment of the car to detect the surrounding environment is complicated, and the combination of the convolutional neural network and the camera to detect the surrounding environment has become a research hotspot. However, simply using the convolutional neural network to process the camera data to control the turning angle of the car has the problems of long training time and low accuracy. An improved convolutional neural network is proposed. The experimental results show that the accuracy of data mining by this method is 12.43% and 21.76% higher than that of traditional methods, and the number of iteration steps is shorter, indicating that the timeliness of mining is higher. This network structure can effectively improve the training speed of the network and improve the accuracy of the network. It is proven that the convolutional neural network has faster training speed and higher accuracy.
Related Concept Videos
 01:07
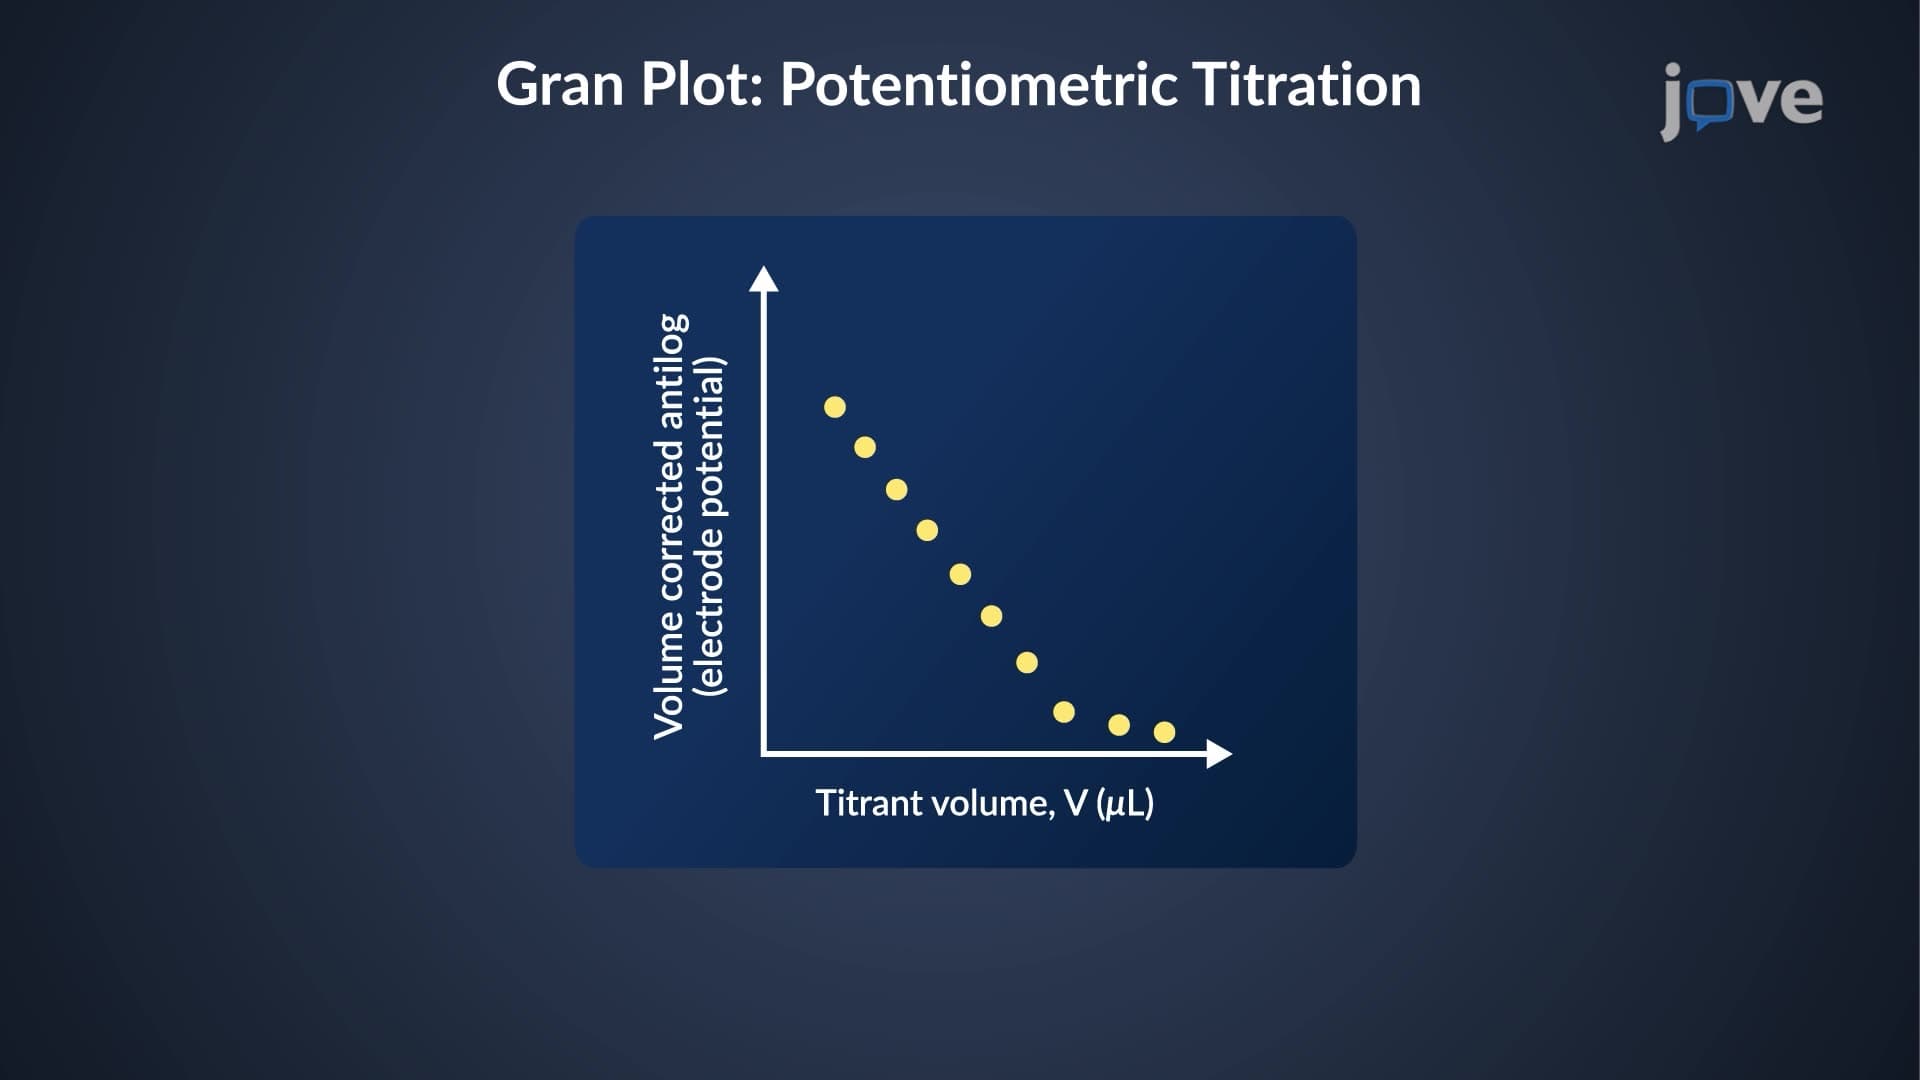
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:31
Classification of Systems-II
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.