Related Experiment Video
Updated: Sep 29, 2025

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
H∞ Control for a Class of Two-Time-Scale Cyber-Physical Systems: An Asynchronous Dynamic Event-Triggered Protocol

Abstract:
In this article, the H∞ control problem is investigated for a class of two-time-scale cyber-physical systems (TTSCPSs). In order to reduce the network bandwidth occupation and lighten the computation burden, an asynchronous dynamic event-triggered protocol (ADETP) is designed to arrange the signal transmissions from sensors to the composite controllers, in which the triggering sequences of fast and slow system components are determined separately. A novel composite controller based on the proposed ADETP is designed dependent on the singular perturbation parameter (SPP) such that the closed-loop TTSCPS is asymptotically stable with meeting a required H∞ performance index when the SPP is no more than a given upper bound. Gain matrices of the desired composite controller are parameterized in terms of the solutions to certain matrix inequalities that are readily solvable. Finally, simulation results of a nuclear reactor are presented to verify the effectiveness of the proposed approach.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:31
Classification of Systems-II
 01:21
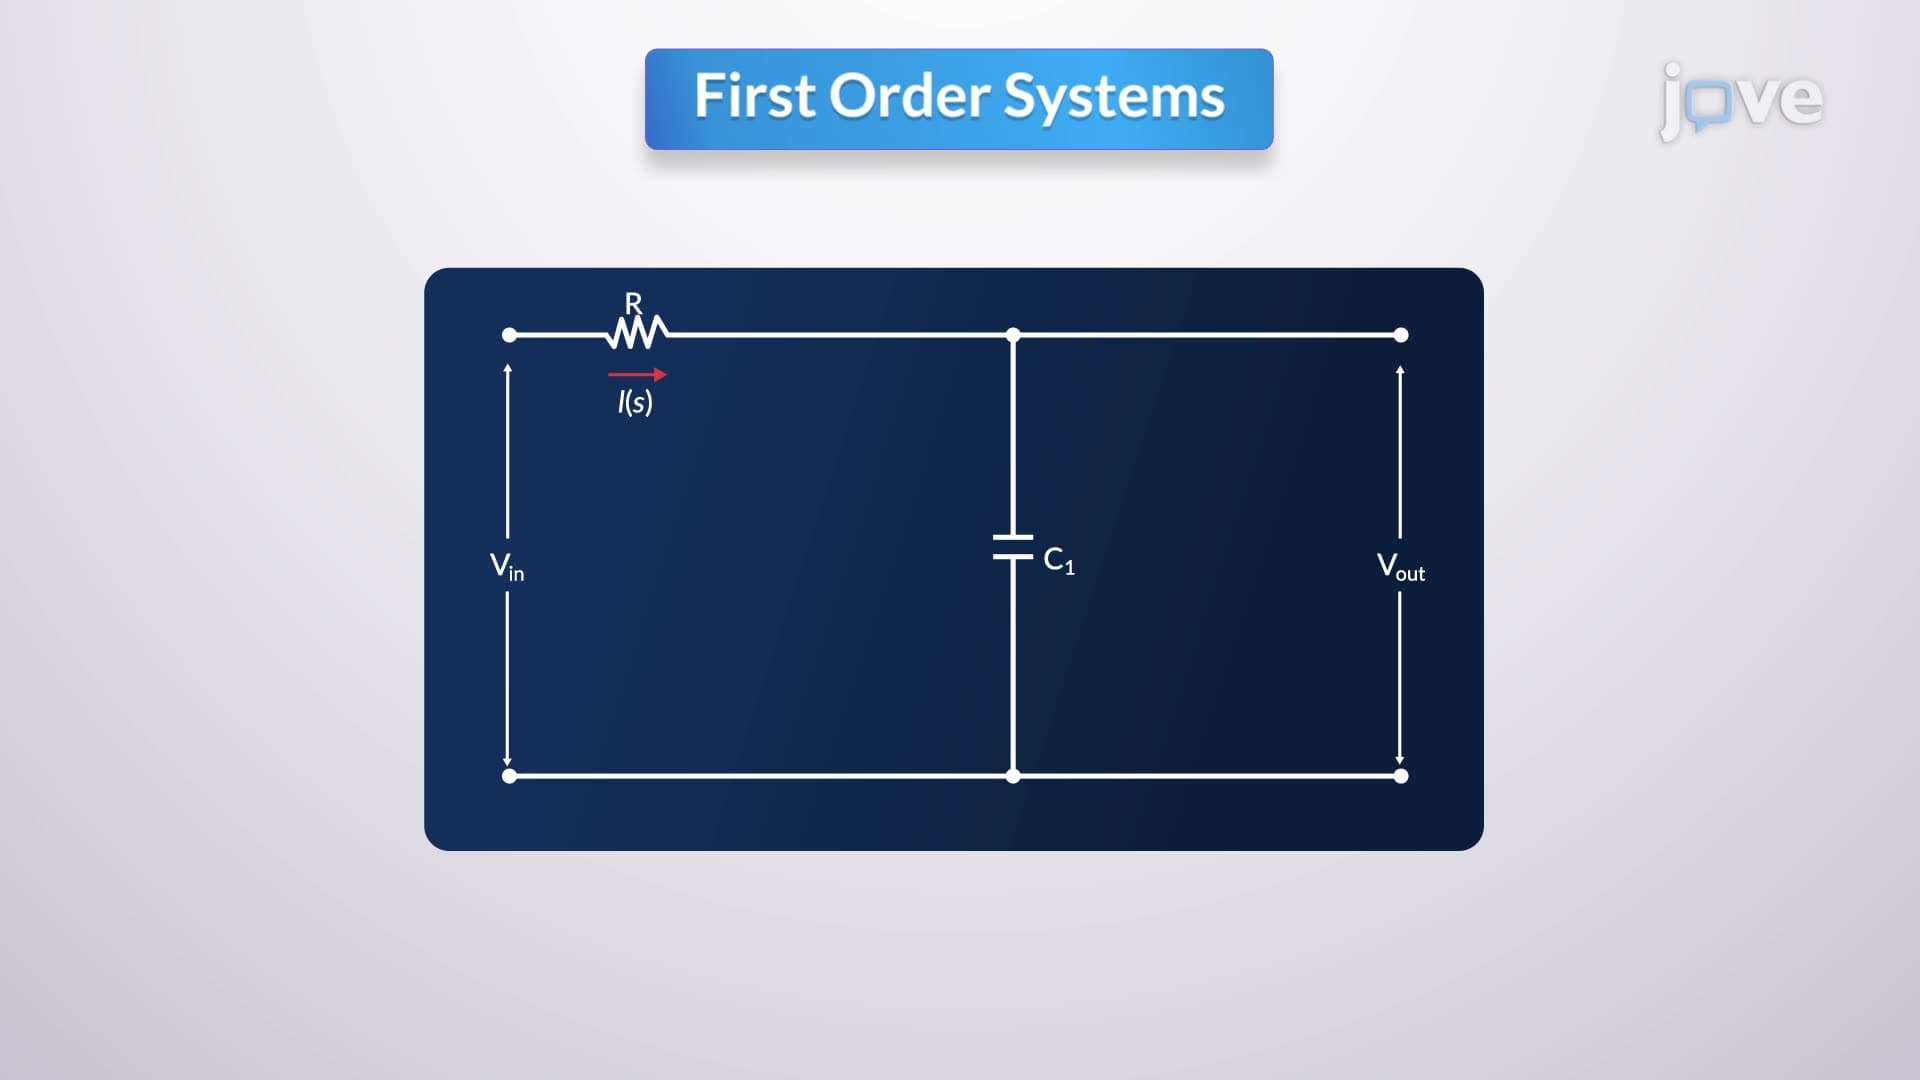
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:21
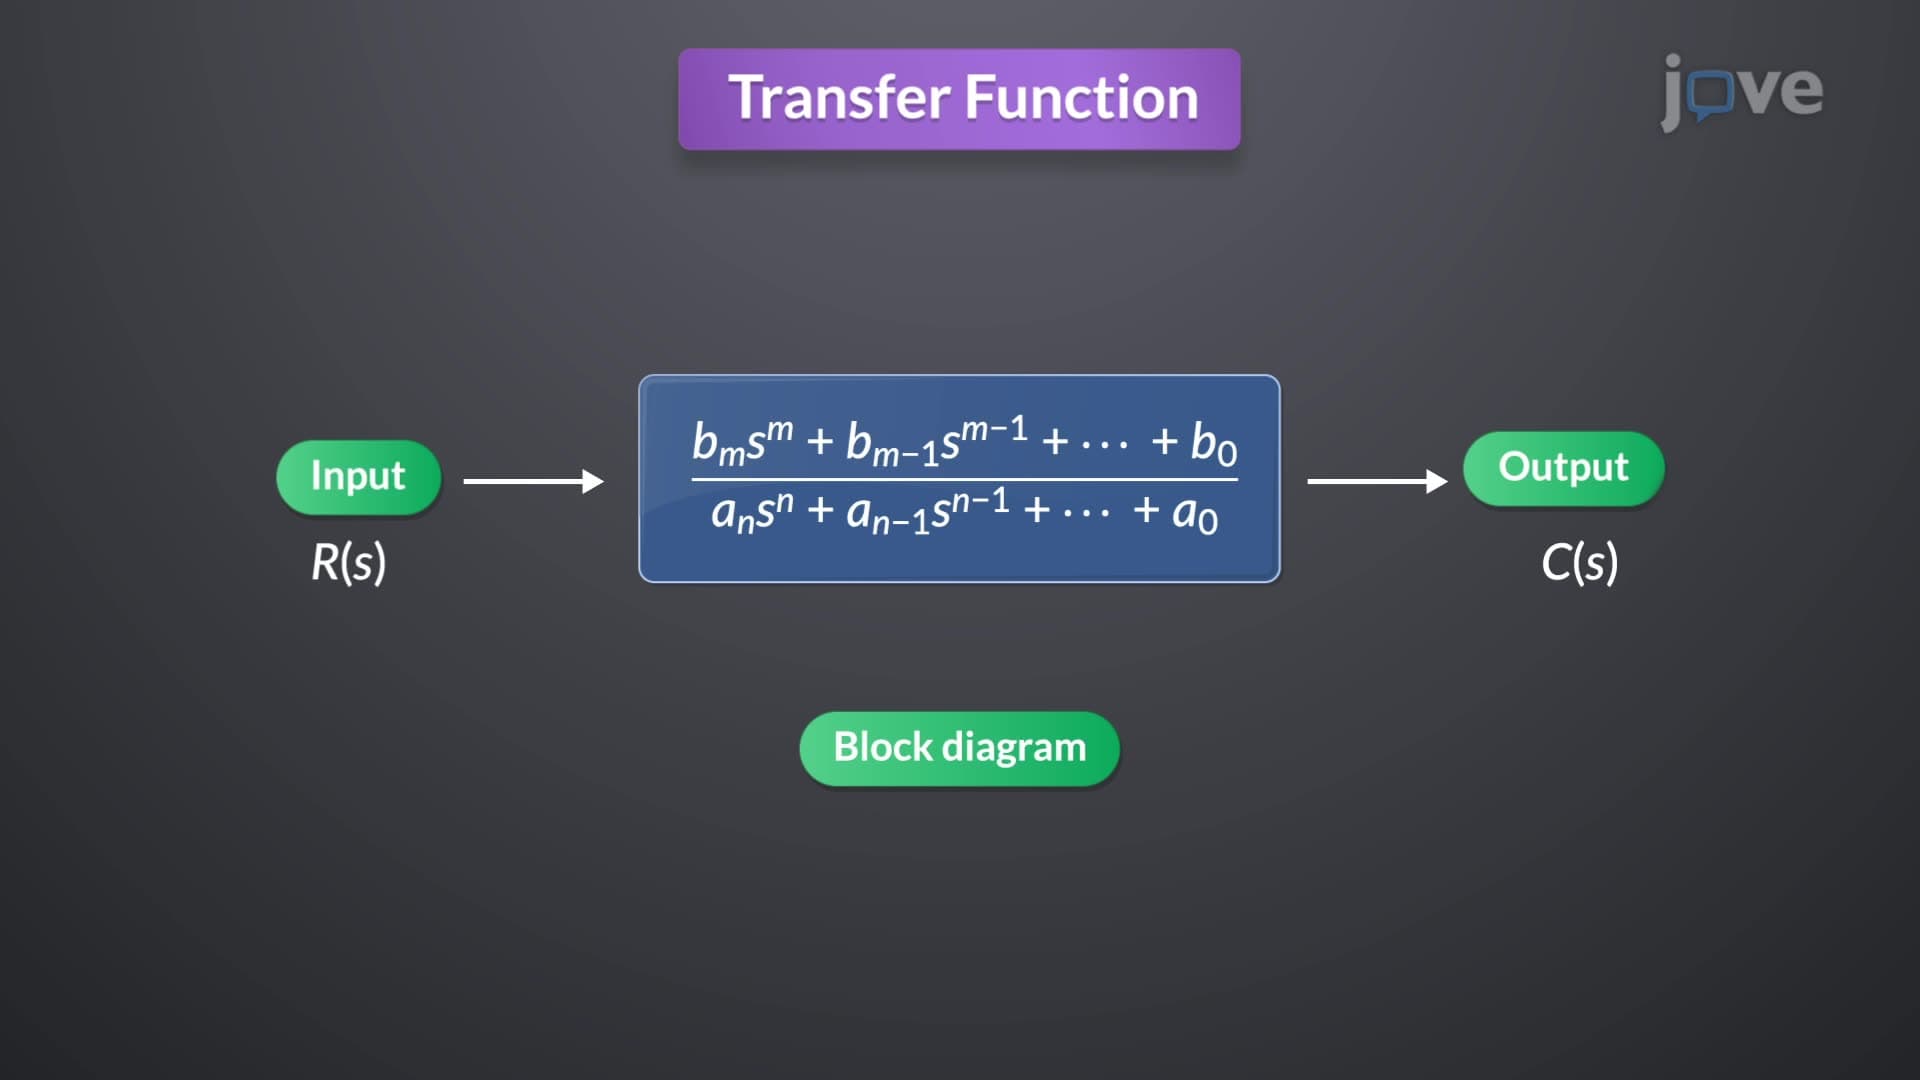
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....