Related Experiment Video
Updated: Sep 29, 2025
Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Model Analysis of Robotic Soft Arms including External Force Effects
Zhi Chen1, Zhong Liu1, Xingguo Han1
1School of Mechanical Engineering, Guilin University of Aerospace Technology, Guilin 541004, China.

Abstract:
Because robotic soft arms have a high power-to-weight ratio, low cost, and ease of manufacturability, increasing numbers of researchers have begun to focus on their characteristics in recent years. However, many urgent problems remain to be resolved. For example, soft arms are made of hyperelastic material, making it difficult to obtain accurate model predictions of the soft arm shape. This paper proposes a new modeling method for soft arms, combining the constant curvature model with Euler-Bernoulli beam theory. By combining these two modeling methods, we can quickly solve for the soft arm deformation under the action of an external force. This paper also presents an experimental platform based on a cable-driven soft arm to verify the validity of the proposed model. We carried out model verification experiments to test for different external effects. Experimental results show that the maximum error of our proposed soft arm deformation model is between 2.86% and 8.75%, demonstrating its effectiveness.

Related Concept Videos
 01:23
Simplification of a Force and Couple System: II
 01:30
Machines: Problem Solving II
 01:30
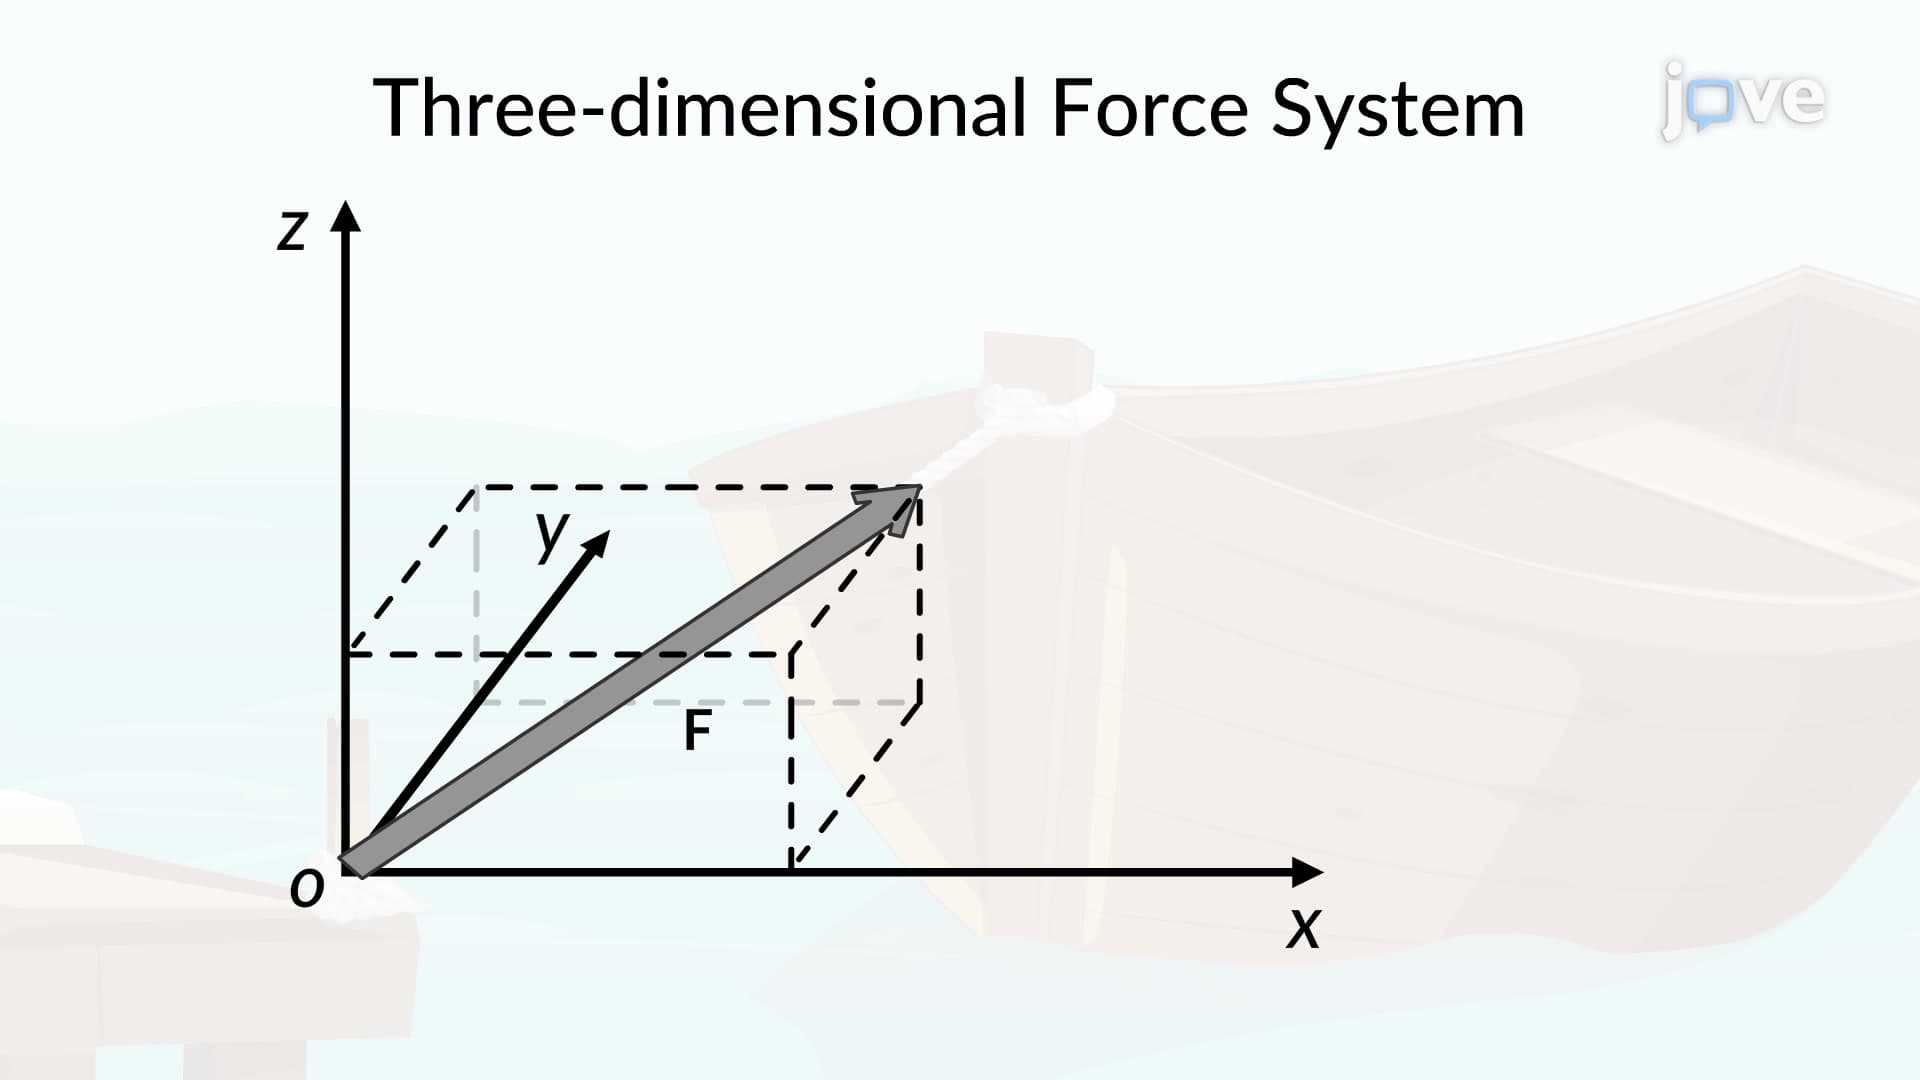
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:30
Three-Dimensional Force System
 01:14
Stability of structures