Oscillation result for half-linear delay difference equations of second-order

Chinnasamy Jayakumar1, Shyam Sundar Santra2, Dumitru Baleanu3,4,5

  • 1Department of Mathematics, Mahendra Arts & Science College (Autonomous), Kalipatti, Namakkal Dt., Tamil Nadu, India.

Related Concept Videos

Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
192
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
133
RLC Circuit as a Damped Oscillator01:30

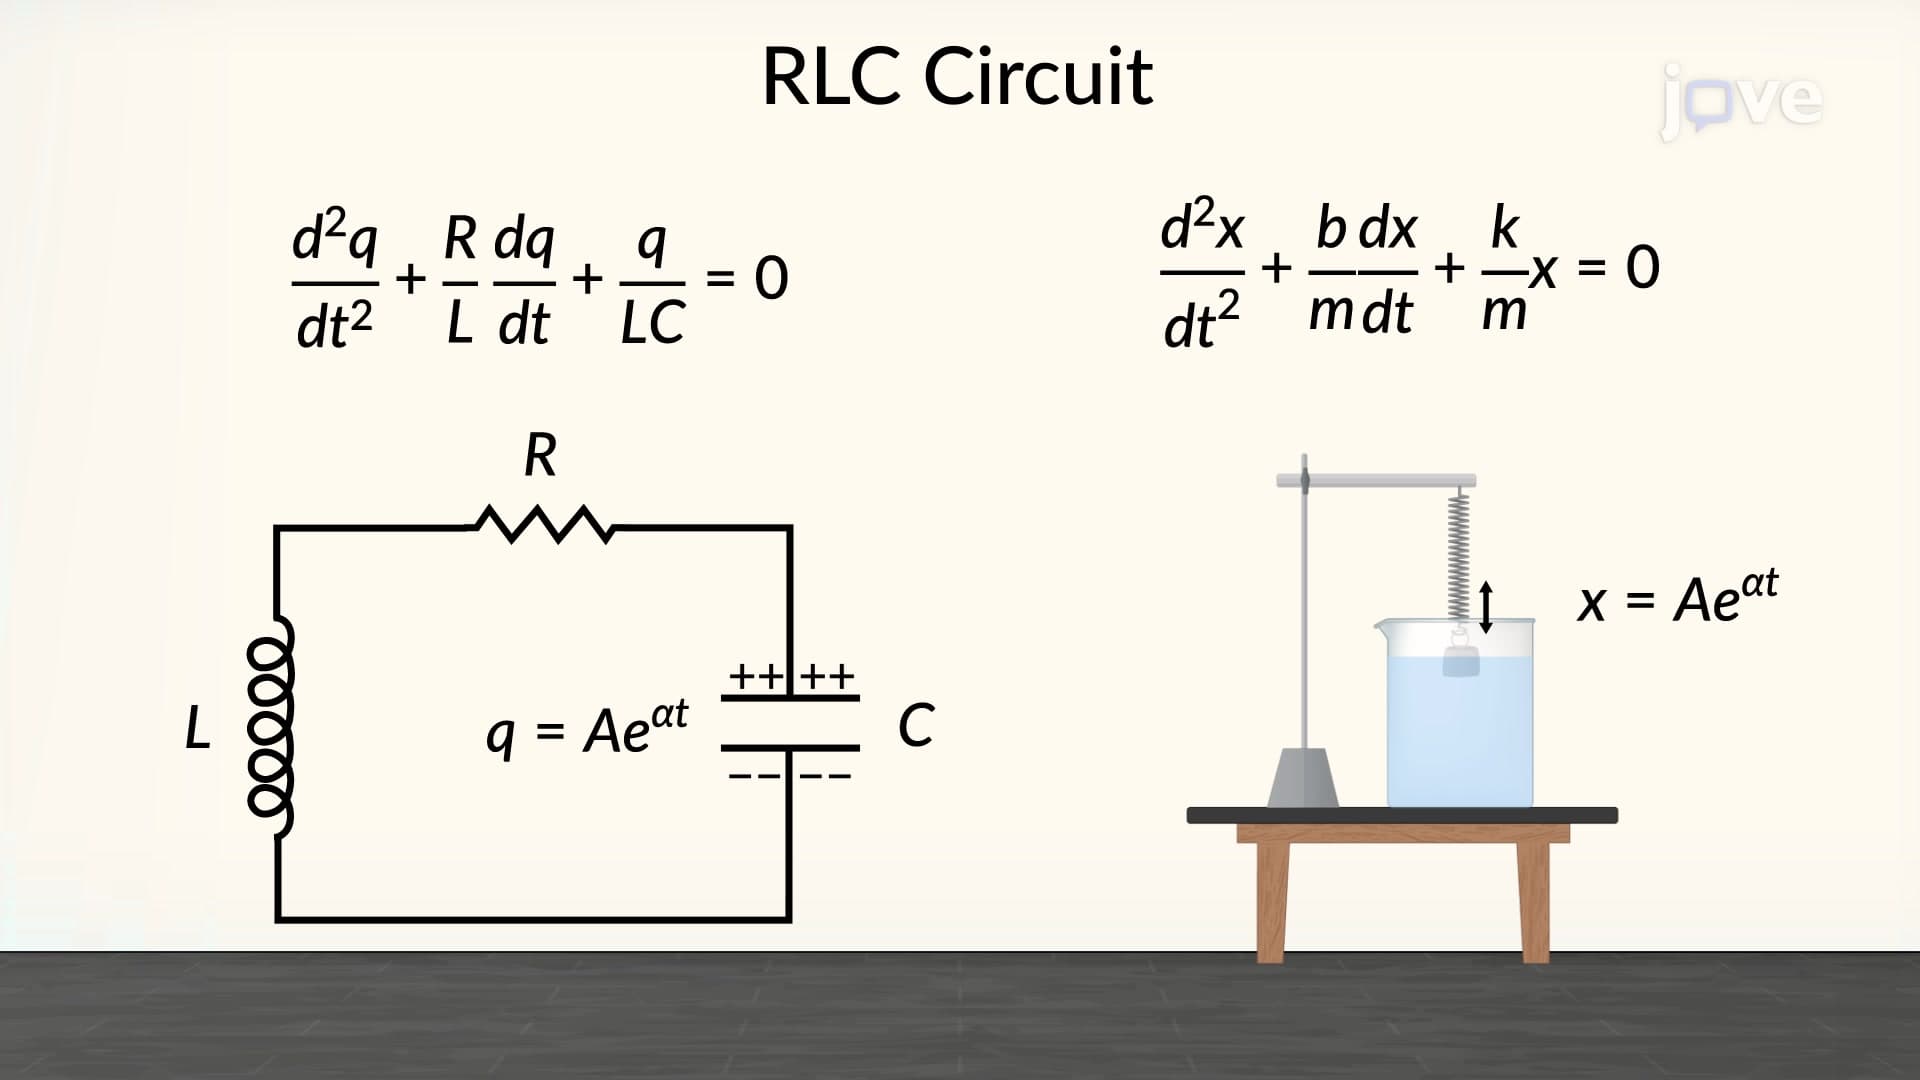
RLC Circuit as a Damped Oscillator

An RLC circuit combines a resistor, inductor, and capacitor, connected in a series or parallel combination.
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
1.4K
Second Order systems I01:20

Second Order systems I

A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
270
Types of Responses of Series RLC Circuits01:11

Types of Responses of Series RLC Circuits

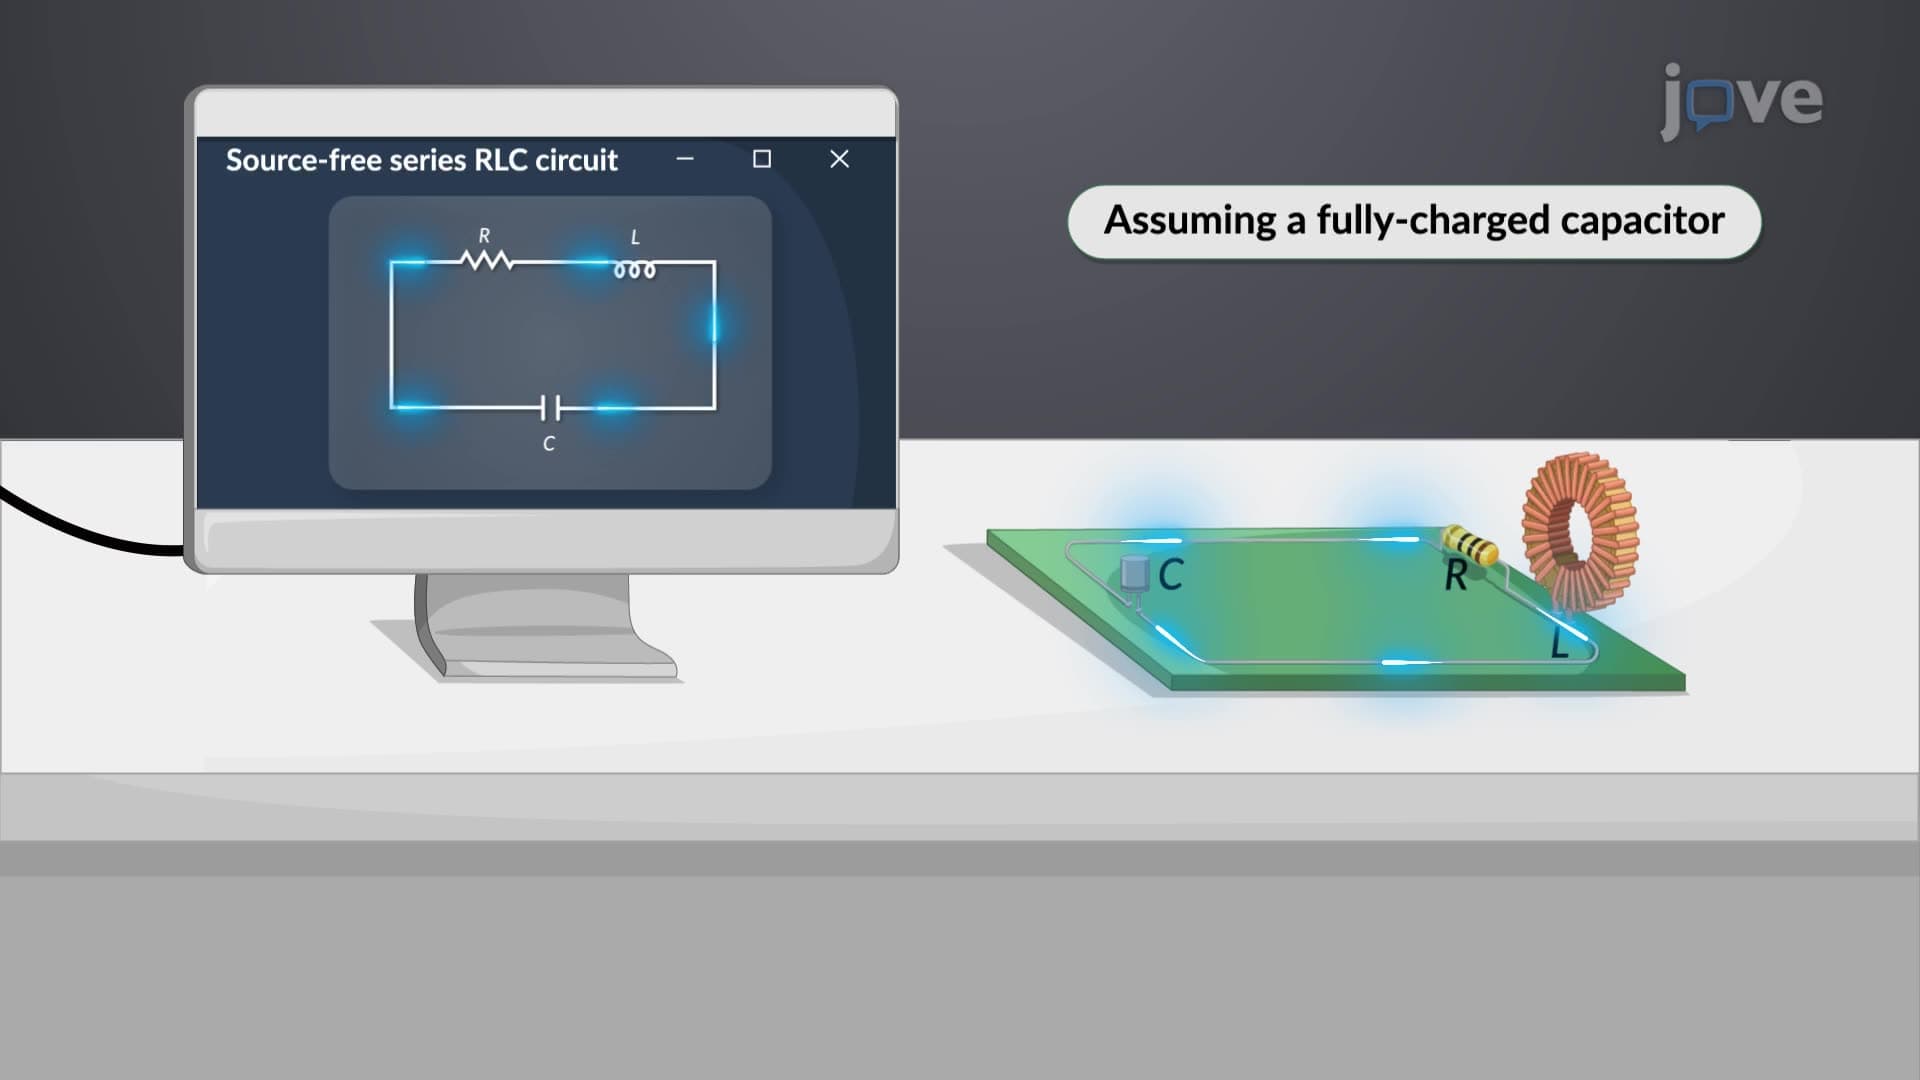
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
1.0K
Damped Oscillations01:07

Damped Oscillations

In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
6.1K