Related Experiment Video
Updated: Sep 27, 2025
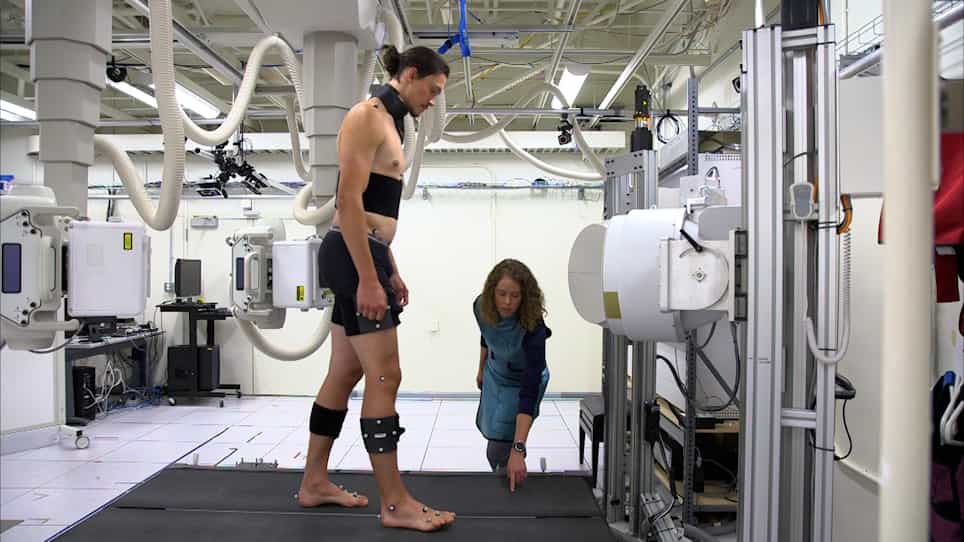

In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
In Vivo three-dimensional kinematics of normal knees during sitting sideways on the floor
Kenichi Kono1,2, Takaharu Yamazaki3, Shoji Konda4
1Department of Orthopaedic Surgery, Faculty of Medicine, The University of Tokyo, 7-3-1 Hongo, Bunkyo-ku, Tokyo, 113-0033, Japan.

Background:
The normal knee kinematics during asymmetrical kneeling such as the sitting sideways remains unknown. This study aimed to clarify in vivo kinematics during sitting sideways of normal knees.
Methods:
Twelve knees from six volunteers were examined. Under fluoroscopy, each volunteer performed a sitting sideways. A two-dimensional/three-dimensional registration technique was used. The rotation angle, varus-valgus angle, anteroposterior translation of the medial and lateral sides of the femur relative to the tibia, and kinematic pathway in each flexion angle was evaluated.
Results:
Bilateral knees during sitting sideways showed a femoral external rotation relative to the tibia with flexion (ipsilateral: 13.7 ± 3.5°, contralateral: 5.8 ± 6.8°). Whereas the ipsilateral knees showed valgus movement of 4.6 ± 2.5° from 130° to 150° of flexion, and the contralateral knees showed varus movement of -3.1 ± 4.4° from 110° to 150° of flexion. The medial side of the contralateral knees was more posteriorly located than that of the ipsilateral knees beyond 110° of flexion. The lateral side of the contralateral knees was more anteriorly located than that of the ipsilateral knees from 120° to 150° of flexion. In the ipsilateral knees, a medial pivot pattern followed by a bicondylar rollback was observed. In the contralateral knees, no significant movement followed by a bicondylar rollback was observed.
Conclusion:
Even though the asymmetrical kneeling such as sitting sideways, the knees did not display asymmetrical movement.
Related Concept Videos
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:11
Anatomical Positions
The body is upright, facing forward, and standing erect.
The feet are parallel and flat on the floor.
The arms are hanging by the...
 01:16
Bones of the Lower Limb: Femur and Patella
 01:18
Kinematic Equations - III
Using the kinematic equations,...