A 3D-printed neuromorphic humanoid hand for grasping unknown objects
Related Experiment Video
Updated: Sep 27, 2025
Design and Use of an Apparatus for Presenting Graspable Objects in 3D Workspace
Published on: August 8, 2019
Chao Bao1, Tae-Ho Kim1, Amirhossein Hassanpoor Kalhori1
1Additive Manufacturing Laboratory, School of Mechatronic Systems Engineering, Simon Fraser University, Surrey V3T 0A3, Canada.

Abstract:
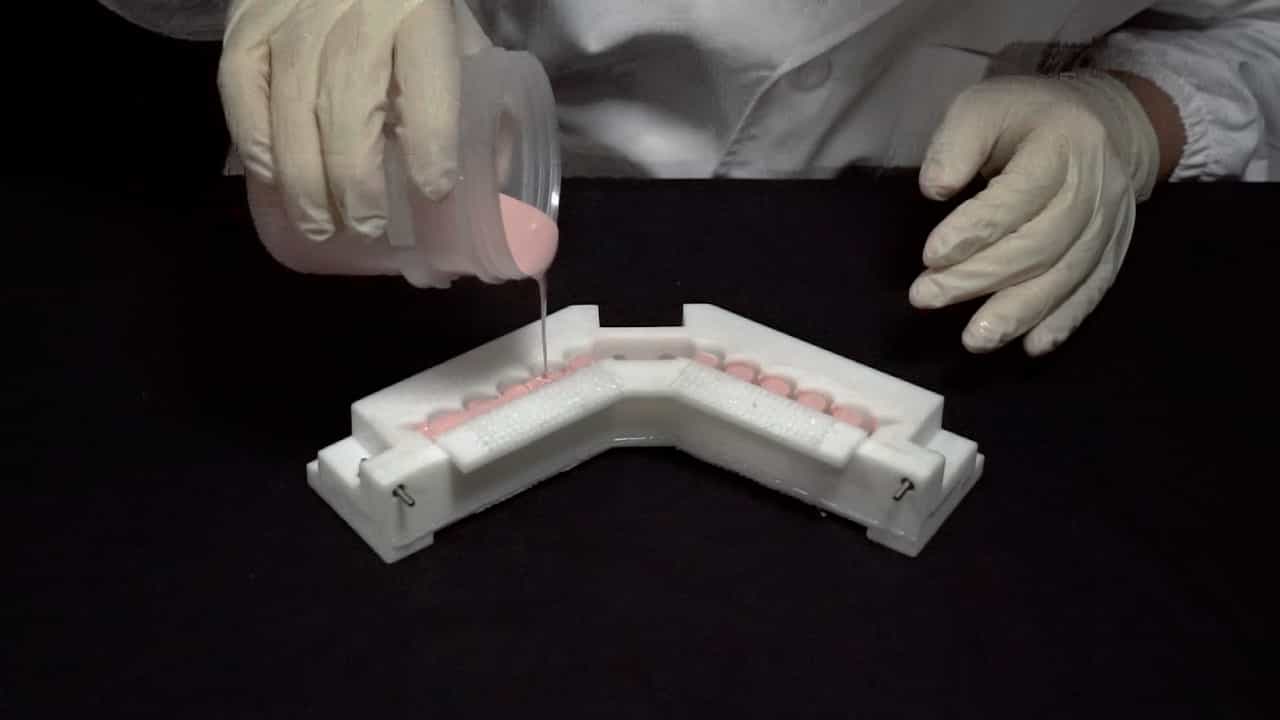
Compared with conventional von Neumann's architecture-based processors, neuromorphic systems provide energy-saving in-memory computing. We present here a 3D neuromorphic humanoid hand designed for providing an artificial unconscious response based on training. The neuromorphic humanoid hand system mimics the reflex arc for a quick response by managing complex spatiotemporal information. A 3D structural humanoid hand is first integrated with 3D-printed pressure sensors and a portable neuromorphic device that was fabricated by the multi-axis robot 3D printing technology. The 3D neuromorphic robot hand provides bioinspired signal perception, including detection, signal transmission, and signal processing, together with the biomimetic reflex arc function, allowing it to hold an unknown object with an automatically increased gripping force without a conventional controlling processor. The proposed system offers a new approach for realizing an unconscious response with an artificially intelligent robot.