
An SDP-based approach for computing the stability number of a graph
Elisabeth Gaar1, Melanie Siebenhofer2, Angelika Wiegele2
1Institute of Production and Logistics Management, Johannes Kepler University Linz, Altenberger Straß 69, 4040 Linz, Austria.

Abstract:
Finding the stability number of a graph, i.e., the maximum number of vertices of which no two are adjacent, is a well known NP-hard combinatorial optimization problem. Since this problem has several applications in real life, there is need to find efficient algorithms to solve this problem. Recently, Gaar and Rendl enhanced semidefinite programming approaches to tighten the upper bound given by the Lovász theta function. This is done by carefully selecting some so-called exact subgraph constraints (ESC) and adding them to the semidefinite program of computing the Lovász theta function. First, we provide two new relaxations that allow to compute the bounds faster without substantial loss of the quality of the bounds. One of these two relaxations is based on including violated facets of the polytope representing the ESCs, the other one adds separating hyperplanes for that polytope. Furthermore, we implement a branch and bound (B&B) algorithm using these tightened relaxations in our bounding routine. We compare the efficiency of our B&B algorithm using the different upper bounds. It turns out that already the bounds of Gaar and Rendl drastically reduce the number of nodes to be explored in the B&B tree as compared to the Lovász theta bound. However, this comes with a high computational cost. Our new relaxations improve the run time of the overall B&B algorithm, while keeping the number of nodes in the B&B tree small.
Related Concept Videos
 01:14
Stability of structures
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:15
Routh-Hurwitz Criterion I
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:19
Routh-Hurwitz Criterion II
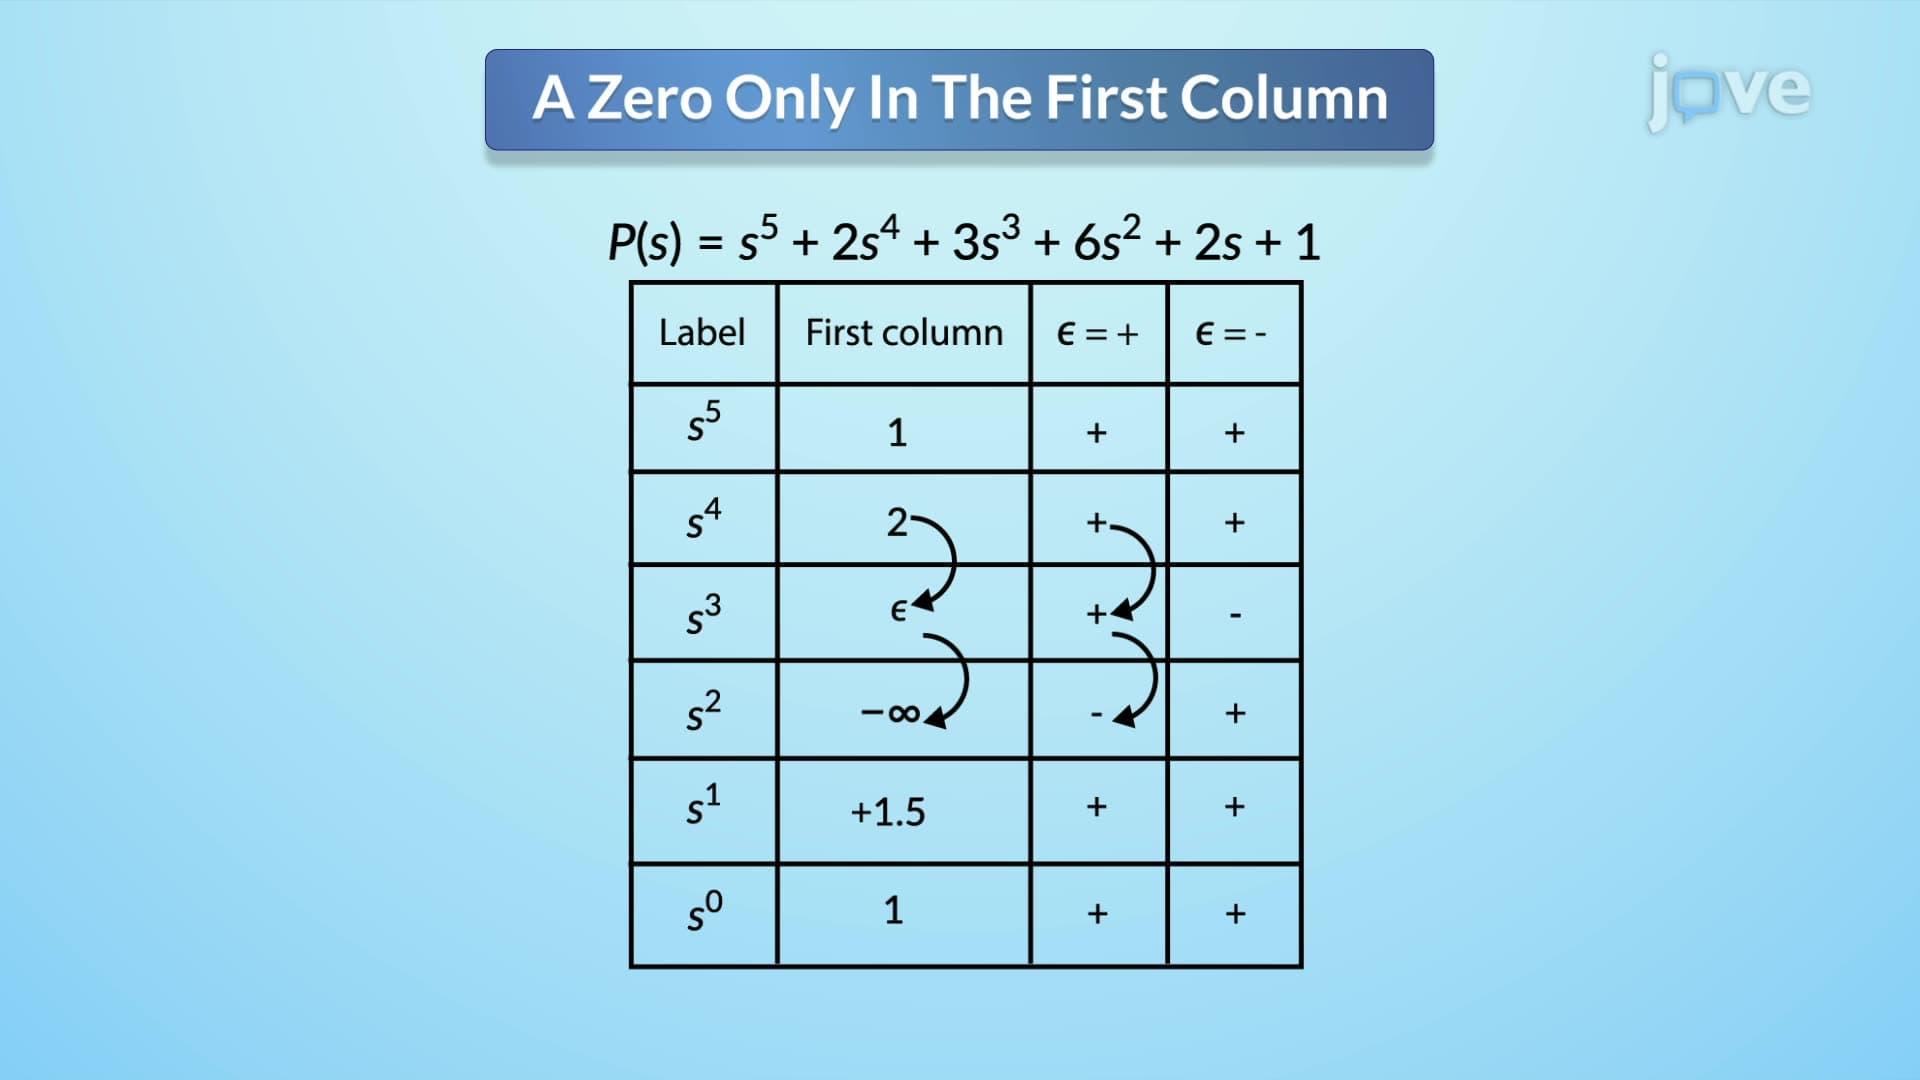
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...