Related Experiment Video
Updated: Sep 27, 2025

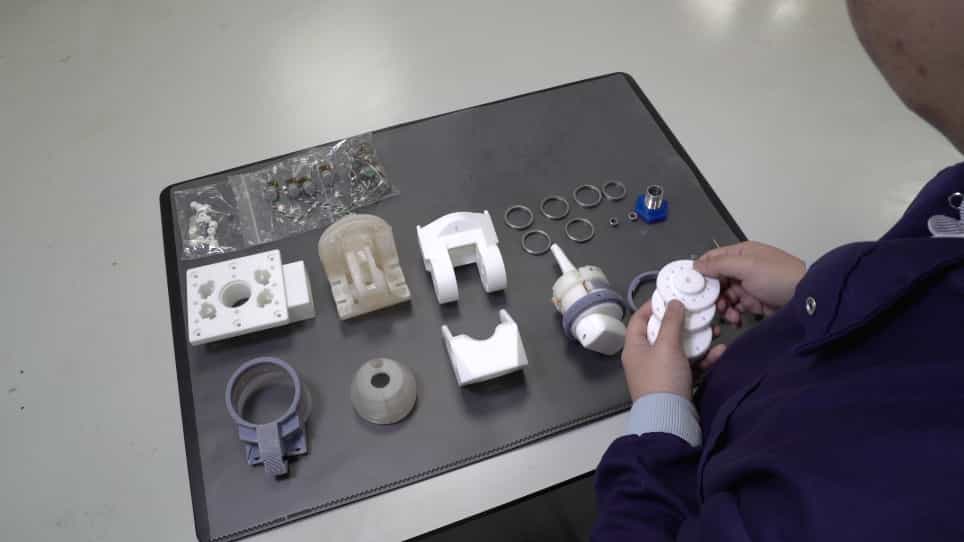
Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
A Sampling-Based Unfixed Orientation Search Method for Dual Manipulator Cooperative Manufacturing
1School of Mechanical Science & Engineering, Huazhong University of Science & Technology, Wuhan 430074, China.

Abstract:
The case of dual manipulators with shared workspace, asynchronous manufacturing tasks, and independent objects is named a dual manipulator cooperative manufacturing system, which requires collision-free path planning as a vital issue in terms of safety and efficiency. This paper combines the mathematical modeling method with the time sampling method in the classification of robot path-planning algorithms. Through this attempt we can achieve an optimal local search path during each sampling period interval. Our strategy is to build the corresponding non-linear optimization functions set based on the motion characteristics of the dual manipulator system. In this way, the path-planning problem can be turned into a purely mathematical problem of solving the non-linear optimization programming equations set. The spatial geometric analysis is used to linearize the predicted dual-manipulator minimum distance equation, thus linearizing the non-linear optimization equations set. Finally, this system of linear optimization equations will be mapped directly into a virtual Euclidean space and then solved intuitively using the spatial geometry theory. By simulation and comparing with the previous strategies, we find that the planning results of the newly proposed planning strategy are smoother and have shorter deviations as well as a higher algorithmic efficiency in terms of spatial geometric properties.

Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:30
Method of Joints: Problem Solving II
 01:15
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...