Related Experiment Video
Updated: Sep 25, 2025


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
DGInet: Dynamic graph and interaction-aware convolutional network for vehicle trajectory prediction
Jiyao An1, Wei Liu1, Qingqin Liu1
1College of Computer Science and Electronic Engineering, Hunan University, Changsha 410082, China.

Abstract:
This paper investigates vehicle trajectory prediction problems in real traffic scenarios by fully harnessing the spatio-temporal dependencies between multiple vehicles. The existing GCN-based trajectory predictions are often considered in a single traffic scene without time attributes, complete interaction information, dynamic graph-based model, etc. Time and interaction aware models are more challenging than the existing ones. Despite very well does the graph-based model describe the relationship between driving vehicles, the critical problem in the traffic scene is how to deeply explore the spatio-temporal characteristics of dynamic graphs. Therefore, a novel dynamic graph and interaction-aware neural network model called as DGInet is proposed by combining a semi-global graph mechanism and an M-product based graph convolutional network, which are built into novel dual-network architecture in the entire model. The DGInet is built by exploiting the dynamic interaction in depth between driving vehicles in urban traffic scenarios, and then realized by utilizing semi-global graph convolution operations on the input data cell to capture the basic spatial interaction features of the driving scene. Meanwhile, the dynamic graph is further extracted by a novel M-product approach, in which the embedding of the model is then established along with the embedding of the semi-global network to perform the final embedding. Extensive experiments have been conducted on the two public datasets, named NGSIM and Apollo respectively, to show that our approach outperforms the existing ones with better performance and less computing time. Besides the real-world Shenzhen traffic dataset, China, is also developed to verify the effectiveness of our approach.
Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:07
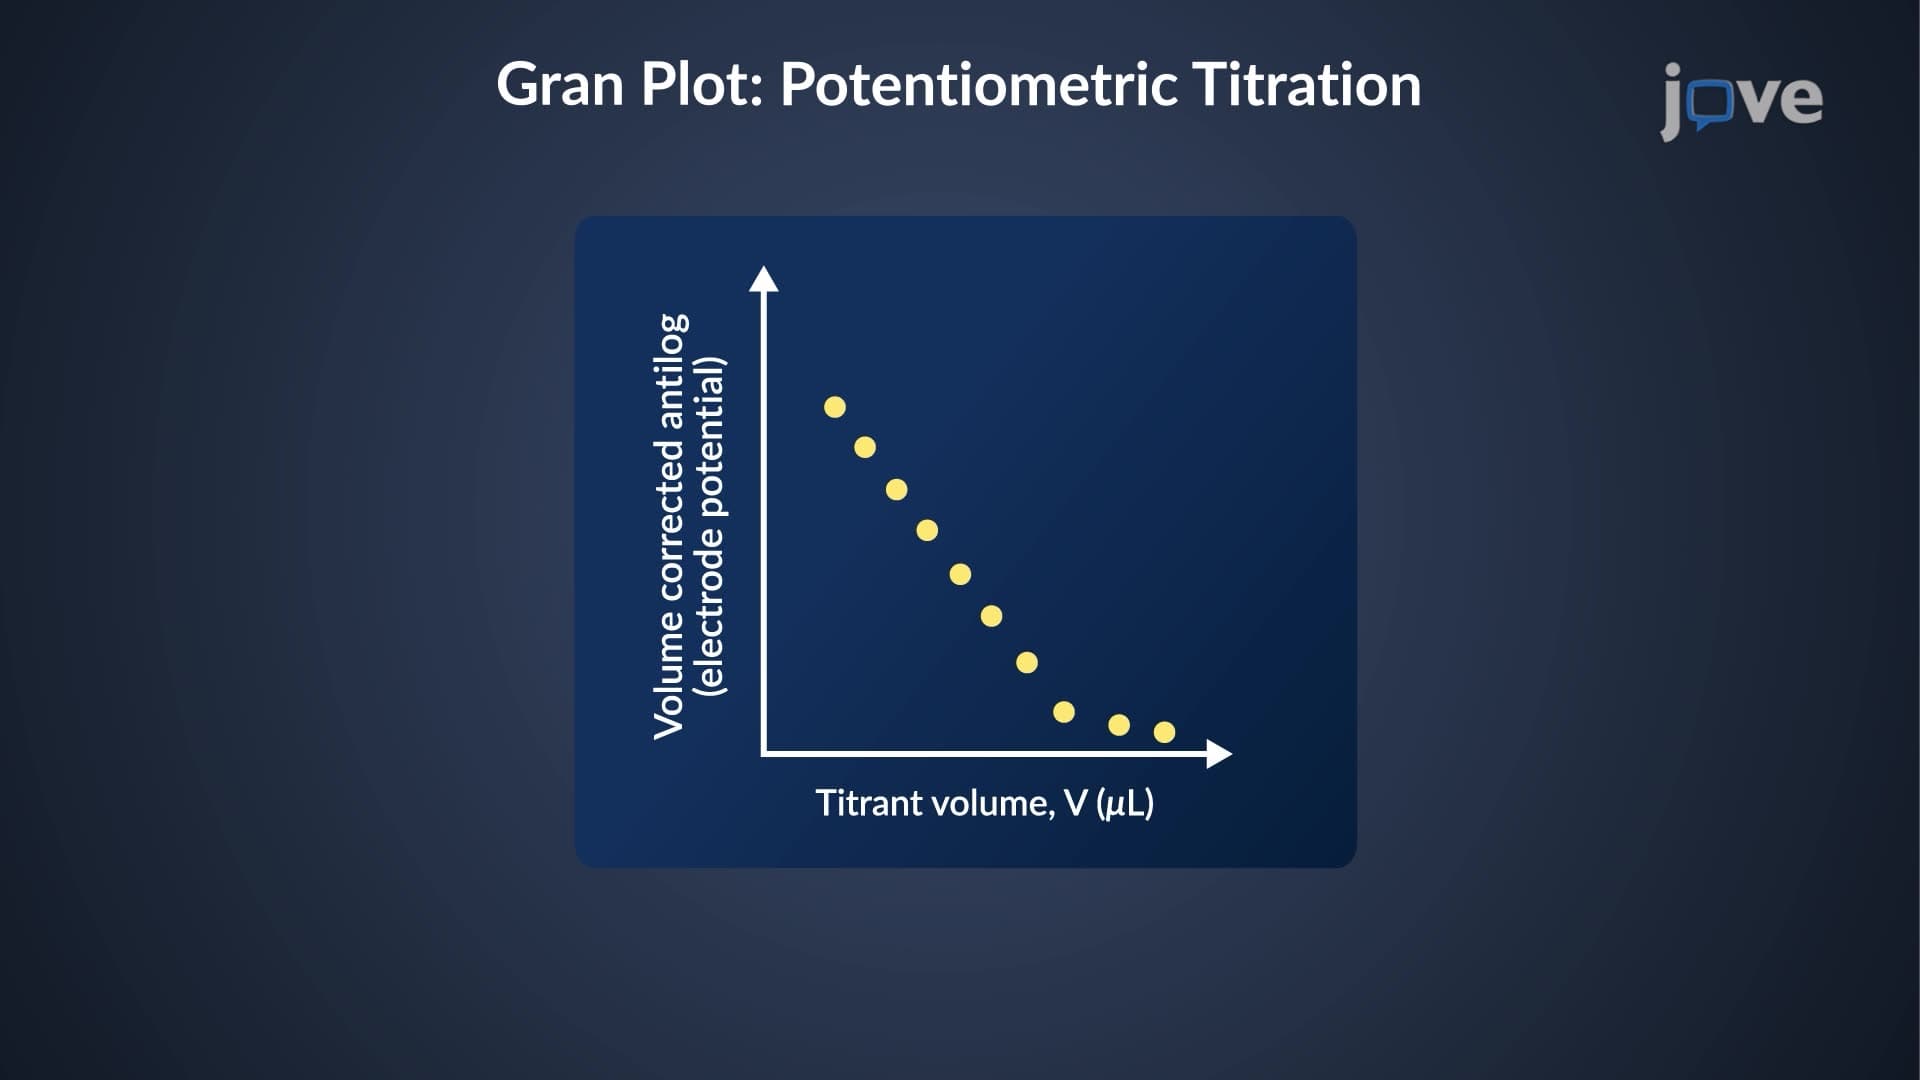
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:34
Velocity and Position by Graphical Method
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:27
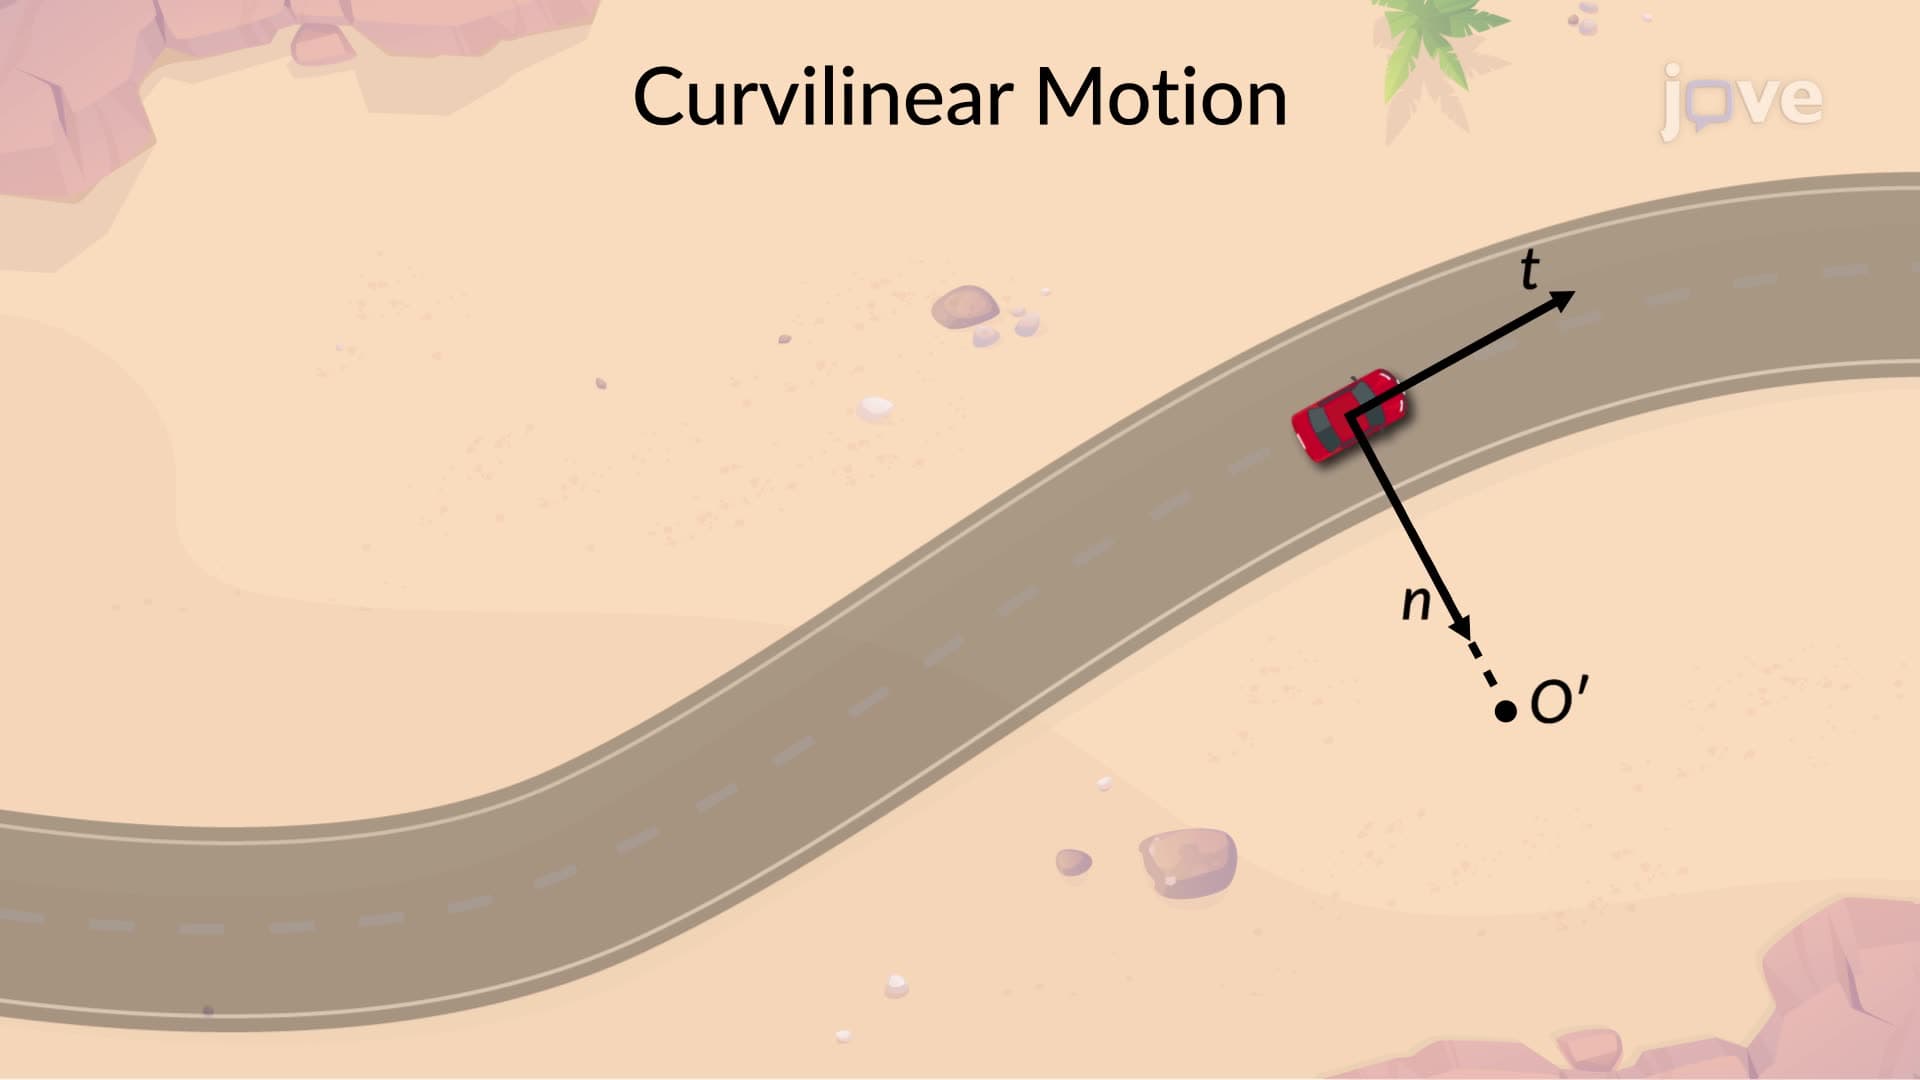
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...