Related Experiment Video
Updated: Sep 25, 2025
FIM Imaging and FIMtrack: Two New Tools Allowing High-throughput and Cost Effective Locomotion Analysis
Published on: December 24, 2014
ACO-Kinematic: a hybrid first off the starting block
Kaylash Chaudhary1, Avinesh Prasad1, Vishal Chand1
1The University of the South Pacific, Suva, Fiji.

Abstract:
The use of robots in carrying out various tasks is popular in many industries. In order to carry out a task, a robot has to move from one location to another using shorter, safer and smoother route. For movement, a robot has to know its destination, its previous location, a plan on the path it should take, a method for moving to the new location and a good understanding of its environment. Ultimately, the movement of the robot depends on motion planning and control algorithm. This paper considers a novel solution to the robot navigation problem by proposing a new hybrid algorithm. The hybrid algorithm is designed by combining the ant colony optimization algorithm and kinematic equations of the robot. The planning phase in the algorithm will find a route to the next step which is collision free and the control phase will move the robot to this new step. Ant colony optimization is used to plan a step for a robot and kinematic equations to control and move the robot to a location. By planning and controlling different steps, the hybrid algorithm will enable a robot to reach its destination. The proposed algorithm will be applied to multiple point-mass robot navigation in a multiple obstacle and line segment cluttered environment. In this paper, we are considering a priori known environments with static obstacles. The proposed motion planning and control algorithm is applied to the tractor-trailer robotic system. The results show a collision and obstacle free navigation to the target. This paper also measures the performance of the proposed algorithm using path length and convergence time, comparing it to a classical motion planning and control algorithm, Lyapunov based control scheme (LbCS). The results show that the proposed algorithm performs significantly better than LbCS including the avoidance of local minima.

Related Concept Videos
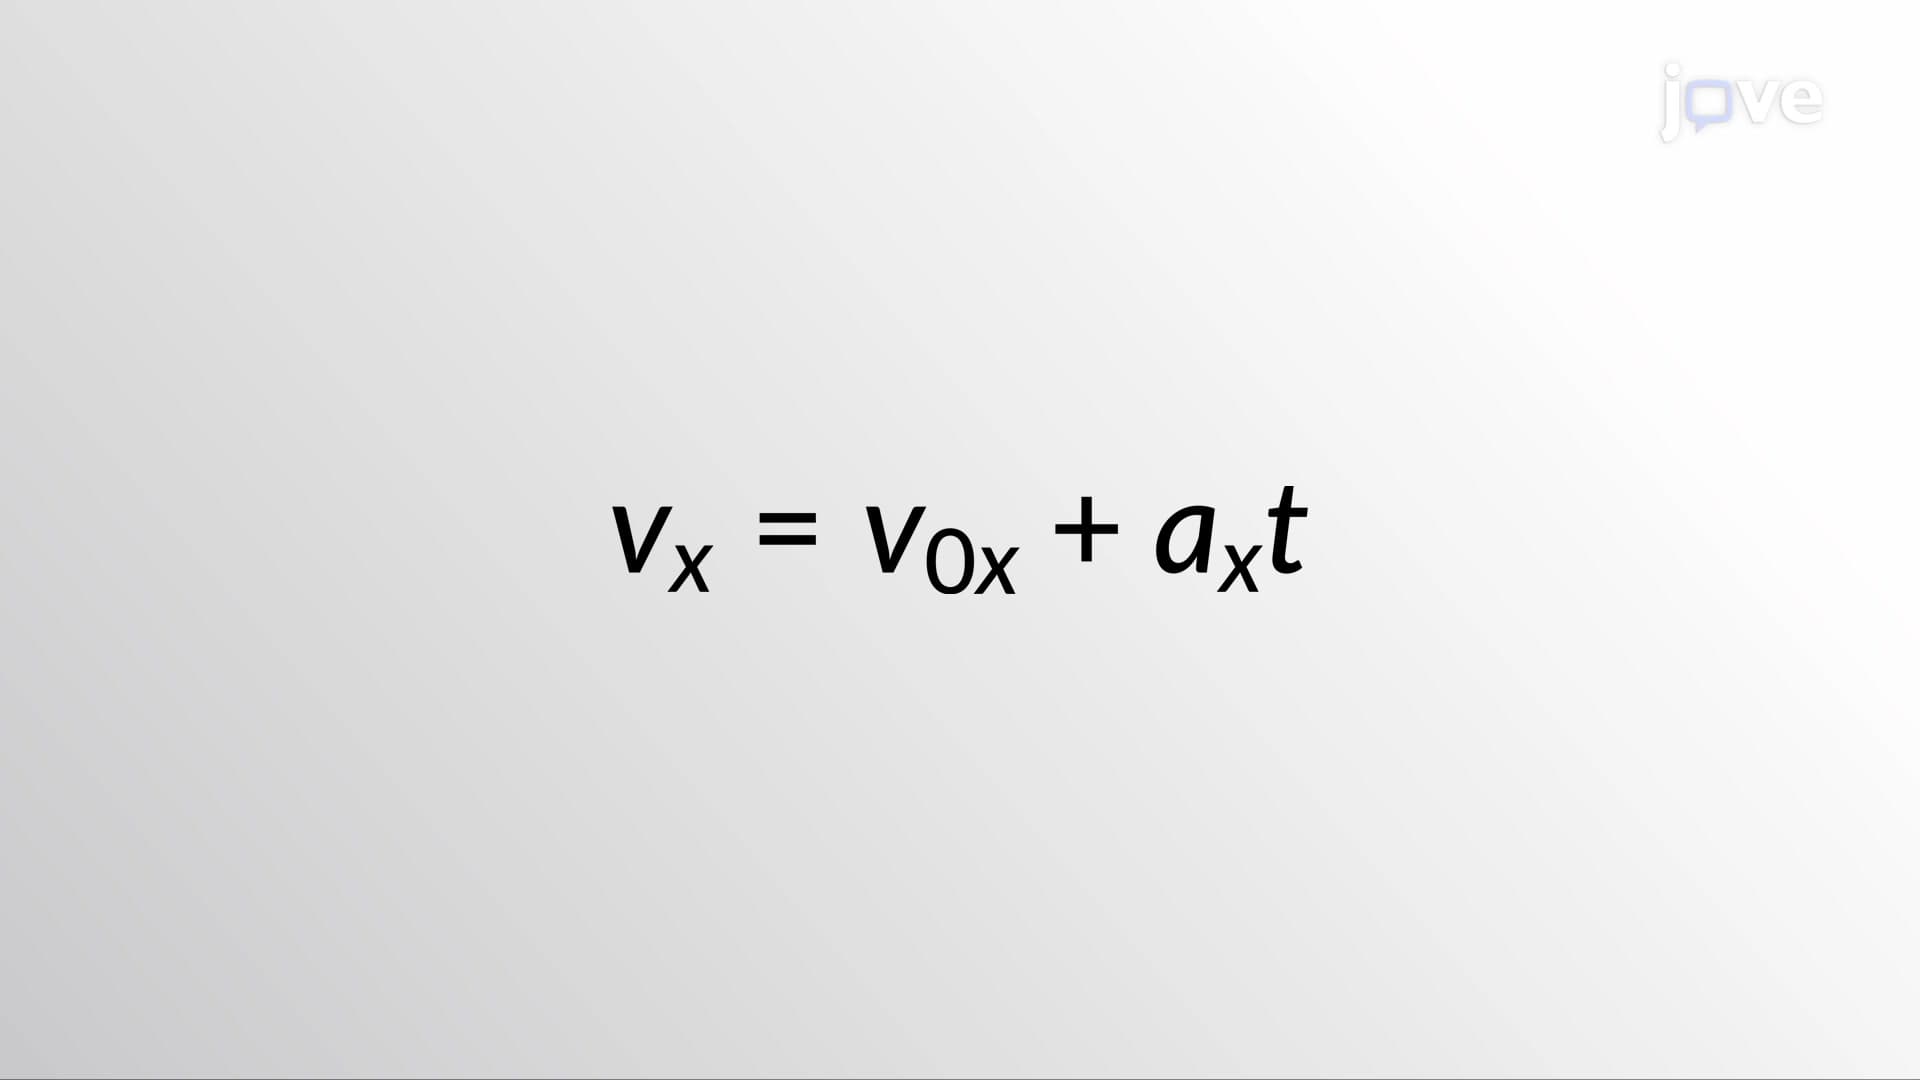 01:26
Kinematic Equations - I
 01:26
Kinetic Friction
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
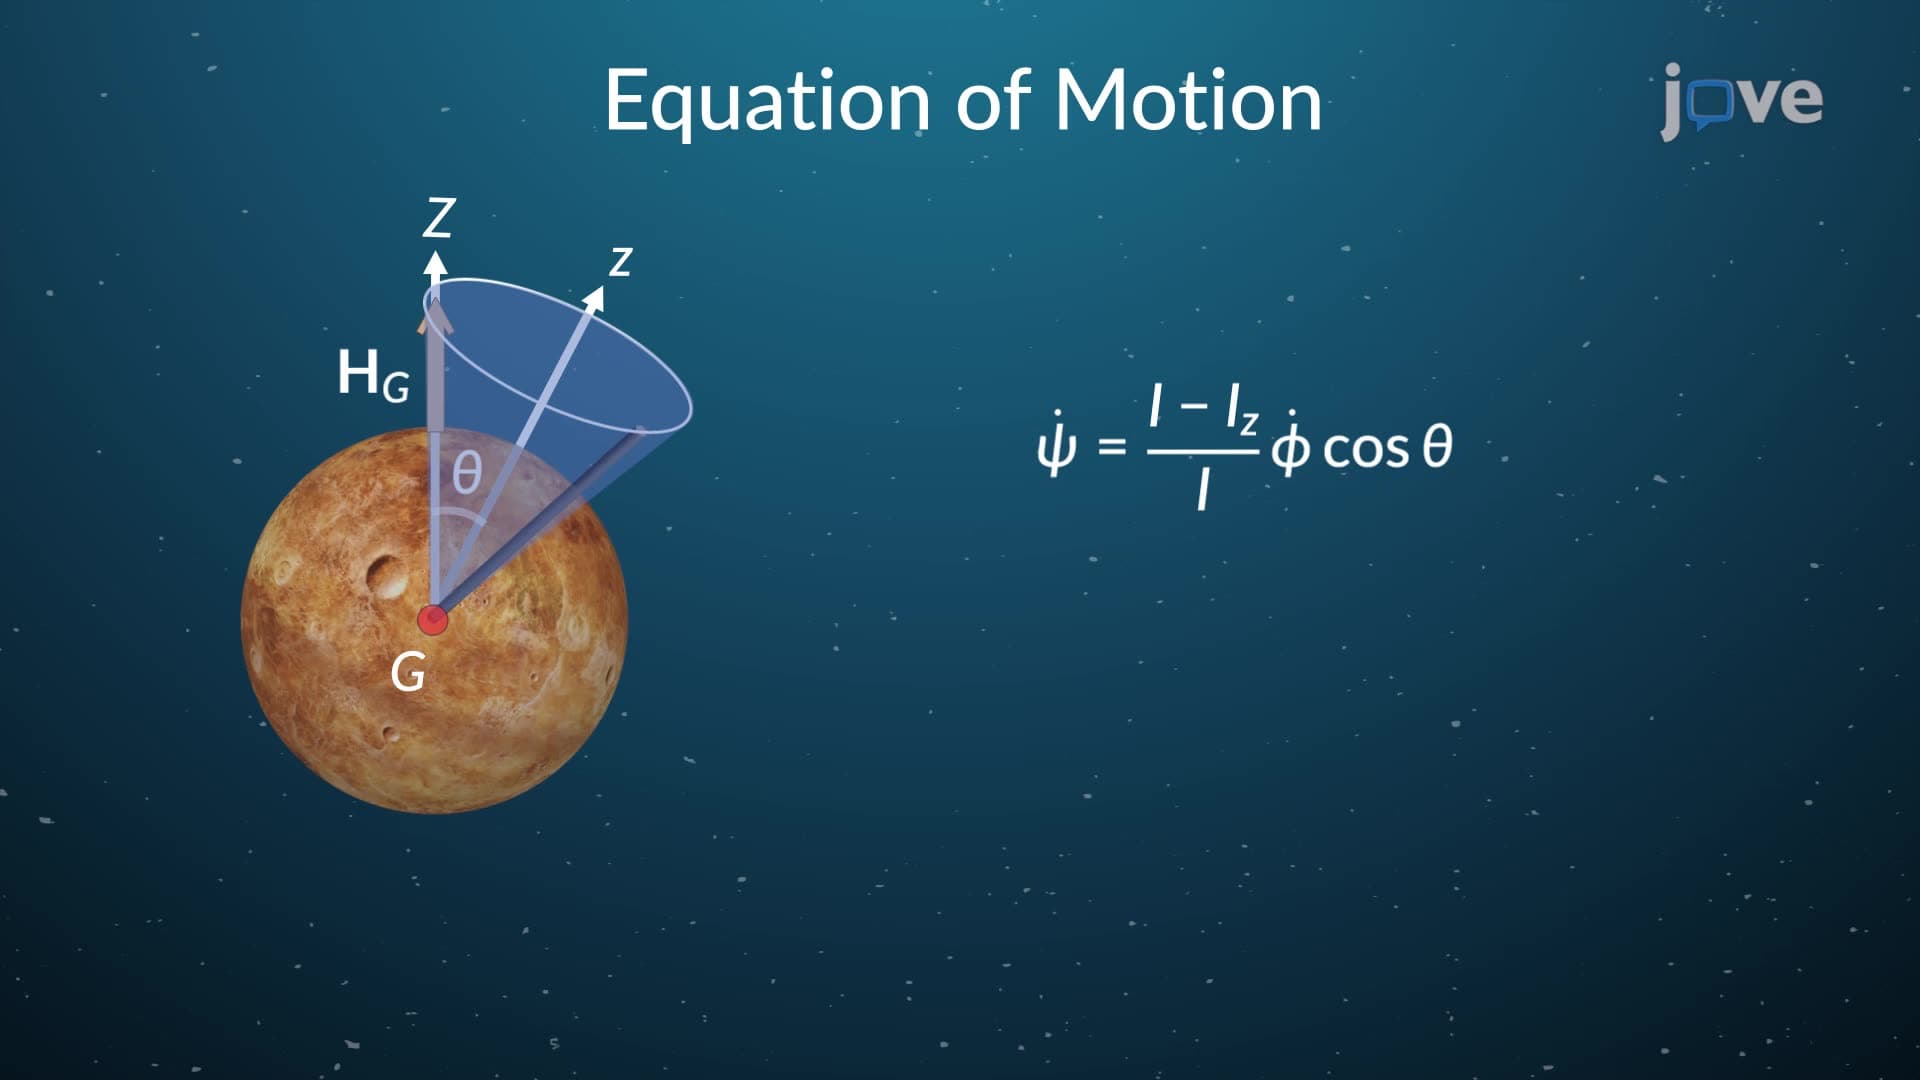
Torque Free Motion