Accelerated Optimization on Riemannian Manifolds via Discrete Constrained Variational Integrators
Related Experiment Video
Updated: Sep 24, 2025
A Coupled Experiment-finite Element Modeling Methodology for Assessing High Strain Rate Mechanical Response of Soft Biomaterials
Published on: May 18, 2015
Valentin Duruisseaux1, Melvin Leok1
1Department of Mathematics, University of California, San Diego, La Jolla, CA 92093-0112 USA.

Abstract:
A variational formulation for accelerated optimization on normed vector spaces was recently introduced in Wibisono et al. (PNAS 113:E7351-E7358, 2016), and later generalized to the Riemannian manifold setting in Duruisseaux and Leok (SJMDS, 2022a). This variational framework was exploited on normed vector spaces in Duruisseaux et al. (SJSC 43:A2949-A2980, 2021) using time-adaptive geometric integrators to design efficient explicit algorithms for symplectic accelerated optimization, and it was observed that geometric discretizations which respect the time-rescaling invariance and symplecticity of the Lagrangian and Hamiltonian flows were substantially less prone to stability issues, and were therefore more robust, reliable, and computationally efficient. As such, it is natural to develop time-adaptive Hamiltonian variational integrators for accelerated optimization on Riemannian manifolds. In this paper, we consider the case of Riemannian manifolds embedded in a Euclidean space that can be characterized as the level set of a submersion. We will explore how holonomic constraints can be incorporated in discrete variational integrators to constrain the numerical discretization of the Riemannian Hamiltonian system to the Riemannian manifold, and we will test the performance of the resulting algorithms by solving eigenvalue and Procrustes problems formulated as optimization problems on the unit sphere and Stiefel manifold.
Related Concept Videos
 01:06
Divergence and Stokes' Theorems
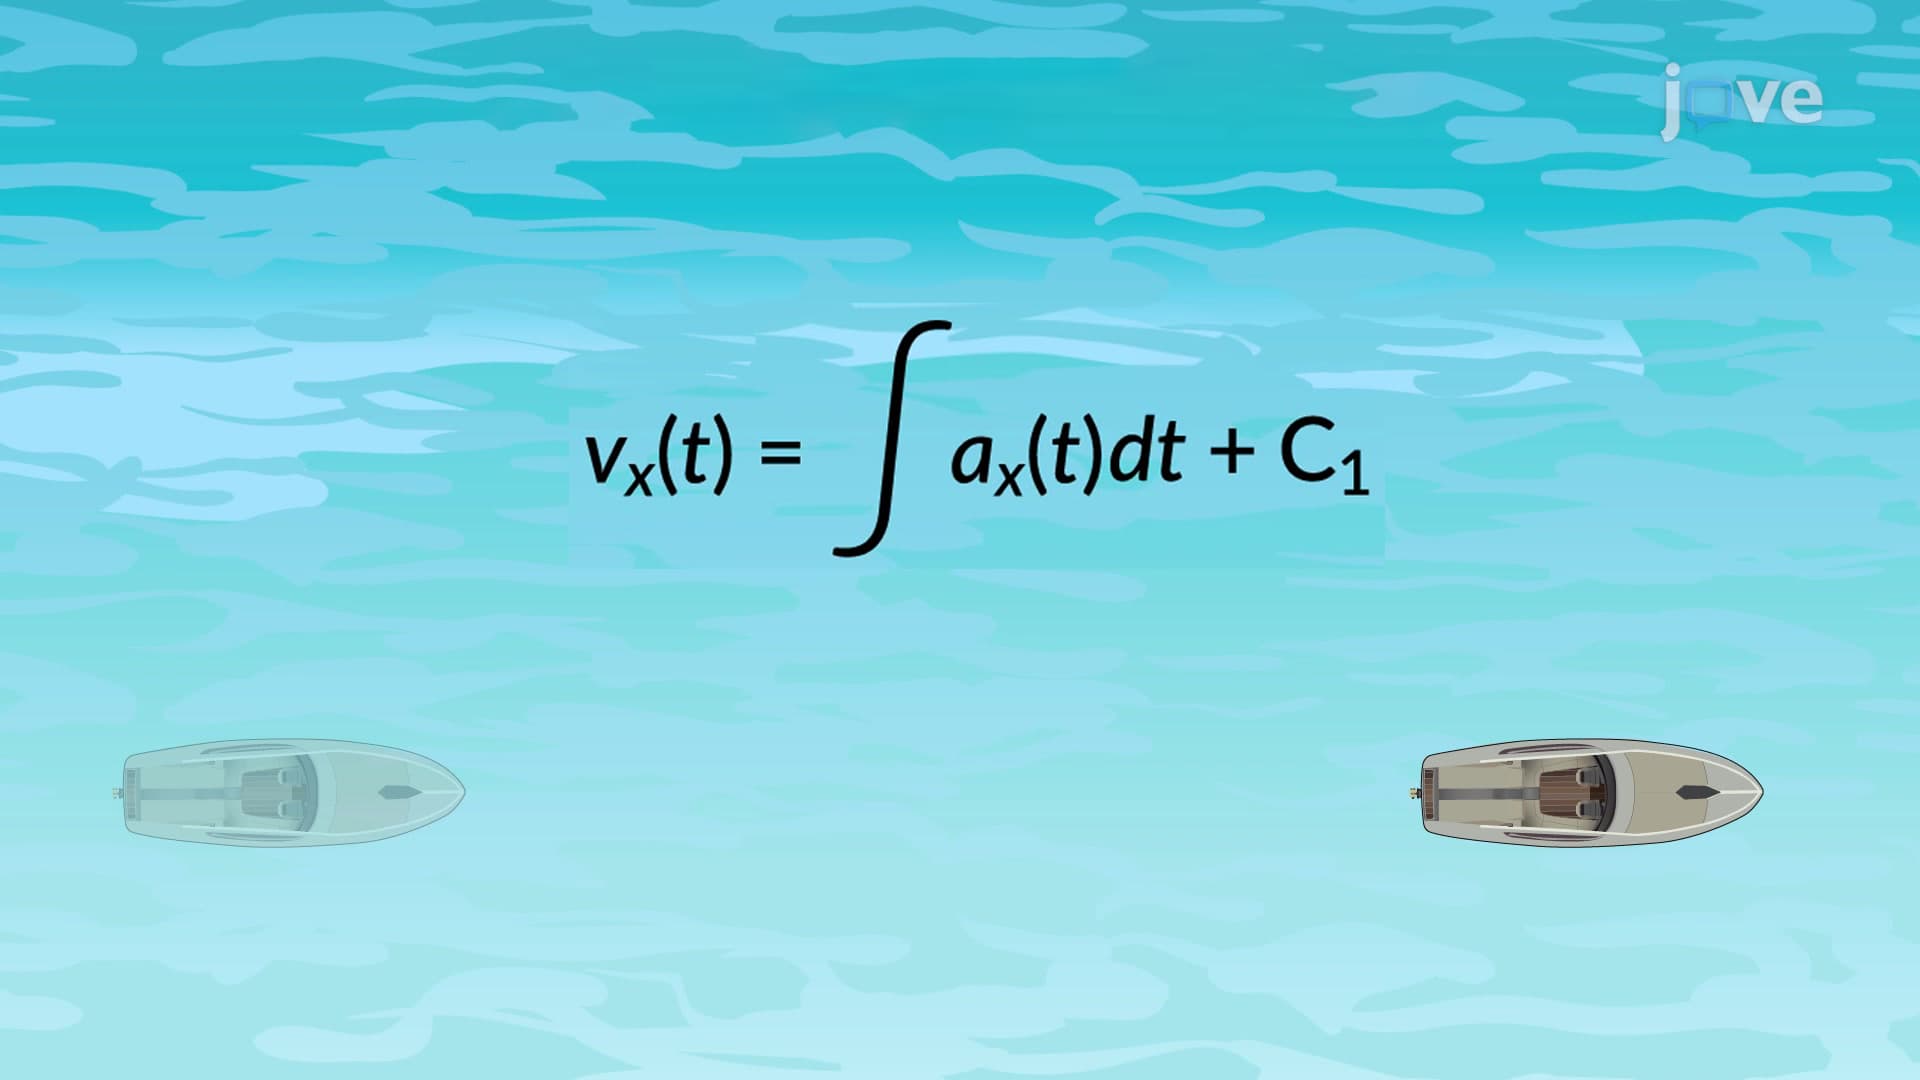 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:15
Routh-Hurwitz Criterion I
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:19
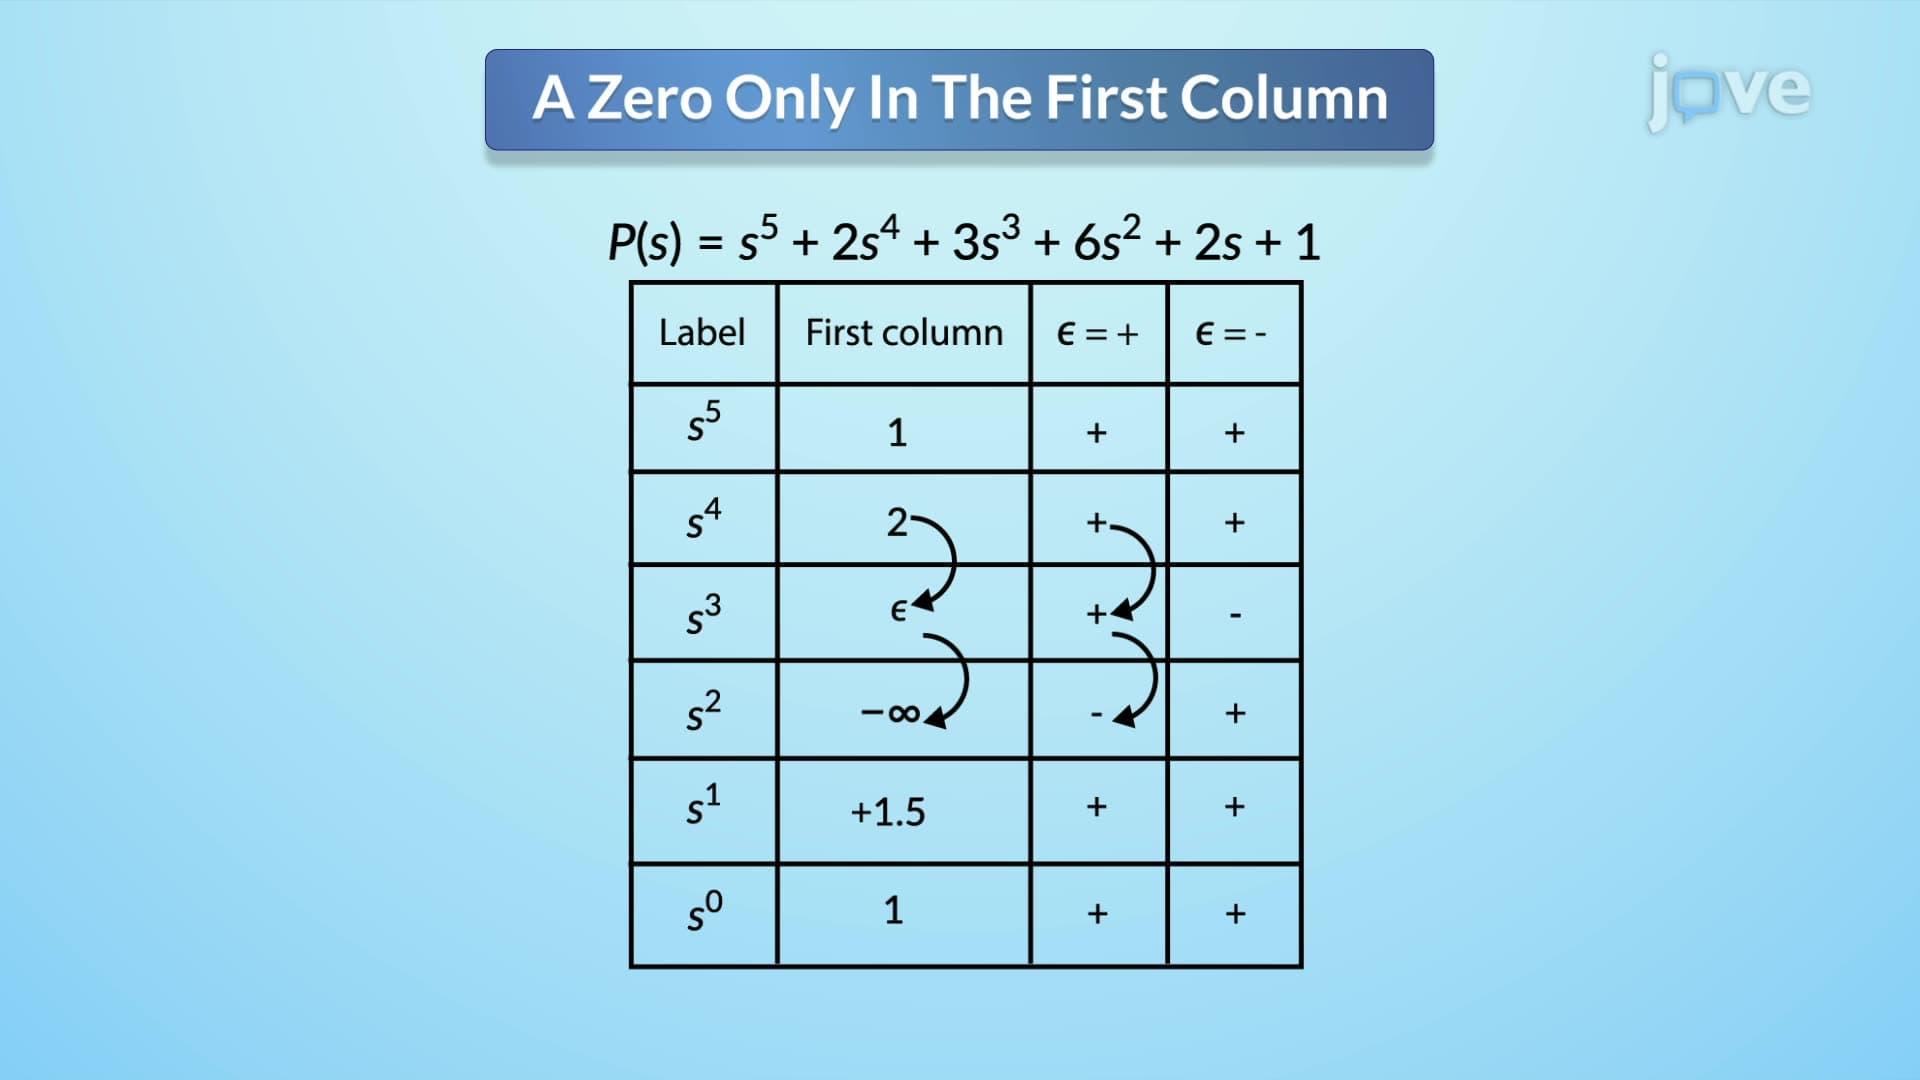
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...