Related Experiment Video
Updated: Sep 24, 2025

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Generalized n-Dimensional Rigid Registration: Theory and Applications

Abstract:
The generalized rigid registration problem in high-dimensional Euclidean spaces is studied. The loss function is minimized with an equivalent error formulation by the Cayley formula. The closed-form linear least-square solution to such a problem is derived which generates the registration covariances, i.e., uncertainty information of rotation and translation, providing quite accurate probabilistic descriptions. Simulation results indicate the correctness of the proposed method and also present its efficiency on computation-time consumption, compared with previous algorithms using singular value decomposition (SVD) and linear matrix inequality (LMI). The proposed scheme is then applied to an interpolation problem on the special Euclidean group SE(n) with covariance-preserving functionality. Finally, experiments on covariance-aided Lidar mapping show practical superiority in robotic navigation.
More Related Videos
 02:09
Multi-modal Pulmonary Imaging: Using Complementary Information from CT and Hyperpolarized 129Xe MRI to Evaluate Lung Structure-Function
Published on: April 12, 2024
 07:13
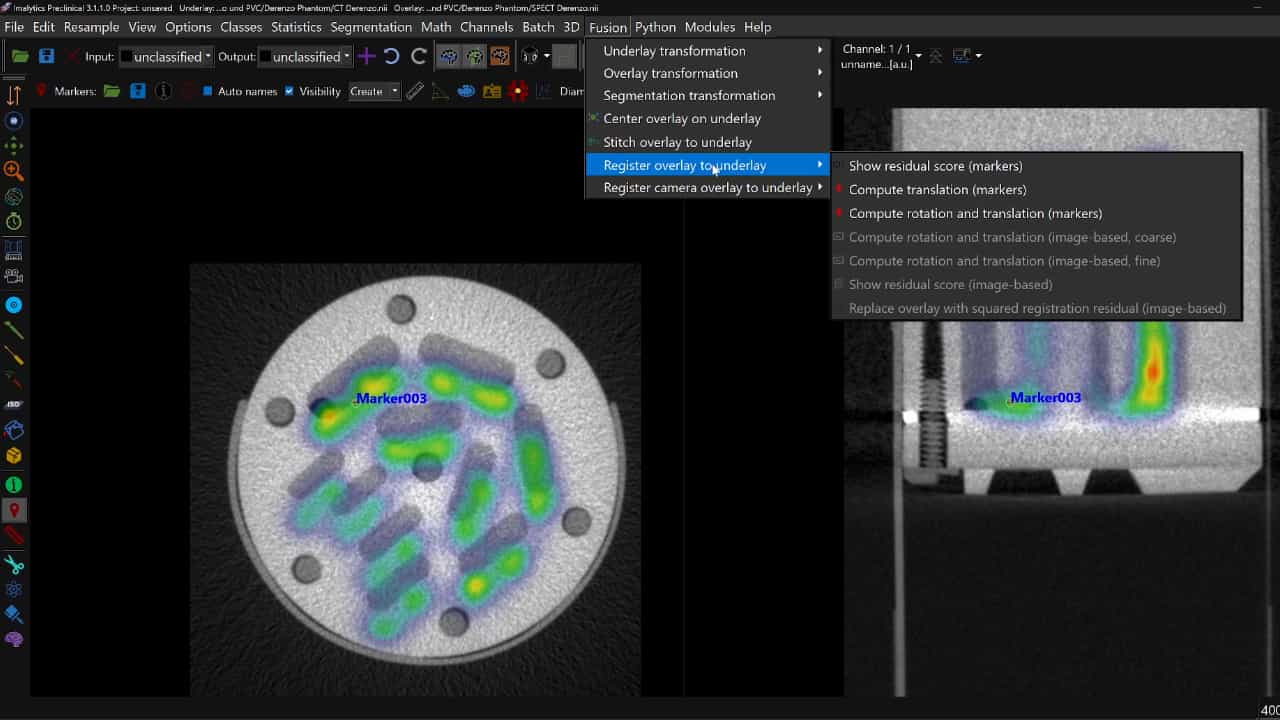
Author Spotlight: An Efficient and Robust Software for Automated Fusion of Multiple Preclinical Imaging Modalities
Published on: October 27, 2023
Related Concept Videos
 01:29
Three-Dimensional Analysis of Strain
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:22
Generalized Hooke's Law
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...