Related Experiment Video
Updated: Sep 24, 2025

Generation and Coherent Control of Pulsed Quantum Frequency Combs
Published on: June 8, 2018
Controlled precision QUBO-based algorithm to compute eigenvectors of symmetric matrices
Benjamin Krakoff1, Susan M Mniszewski2, Christian F A Negre3
1Department of Mathematics, University of Michigan, Ann Arbor, Michigan, United States of America.

Abstract:
We describe an algorithm to compute the extremal eigenvalues and corresponding eigenvectors of a symmetric matrix which is based on solving a sequence of Quadratic Binary Optimization problems. This algorithm is robust across many different classes of symmetric matrices; It can compute the eigenvector/eigenvalue pair to essentially any arbitrary precision, and with minor modifications, can also solve the generalized eigenvalue problem. Performance is analyzed on small random matrices and selected larger matrices from practical applications.
More Related Videos
 16:01
An Experimental Protocol for Assessing the Performance of New Ultrasound Probes Based on CMUT Technology in Application to Brain Imaging
Published on: September 24, 2017
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:28
Cartesian Vector Notation
 01:26
Cartesian Form for Vector Formulation
 01:19
Routh-Hurwitz Criterion II
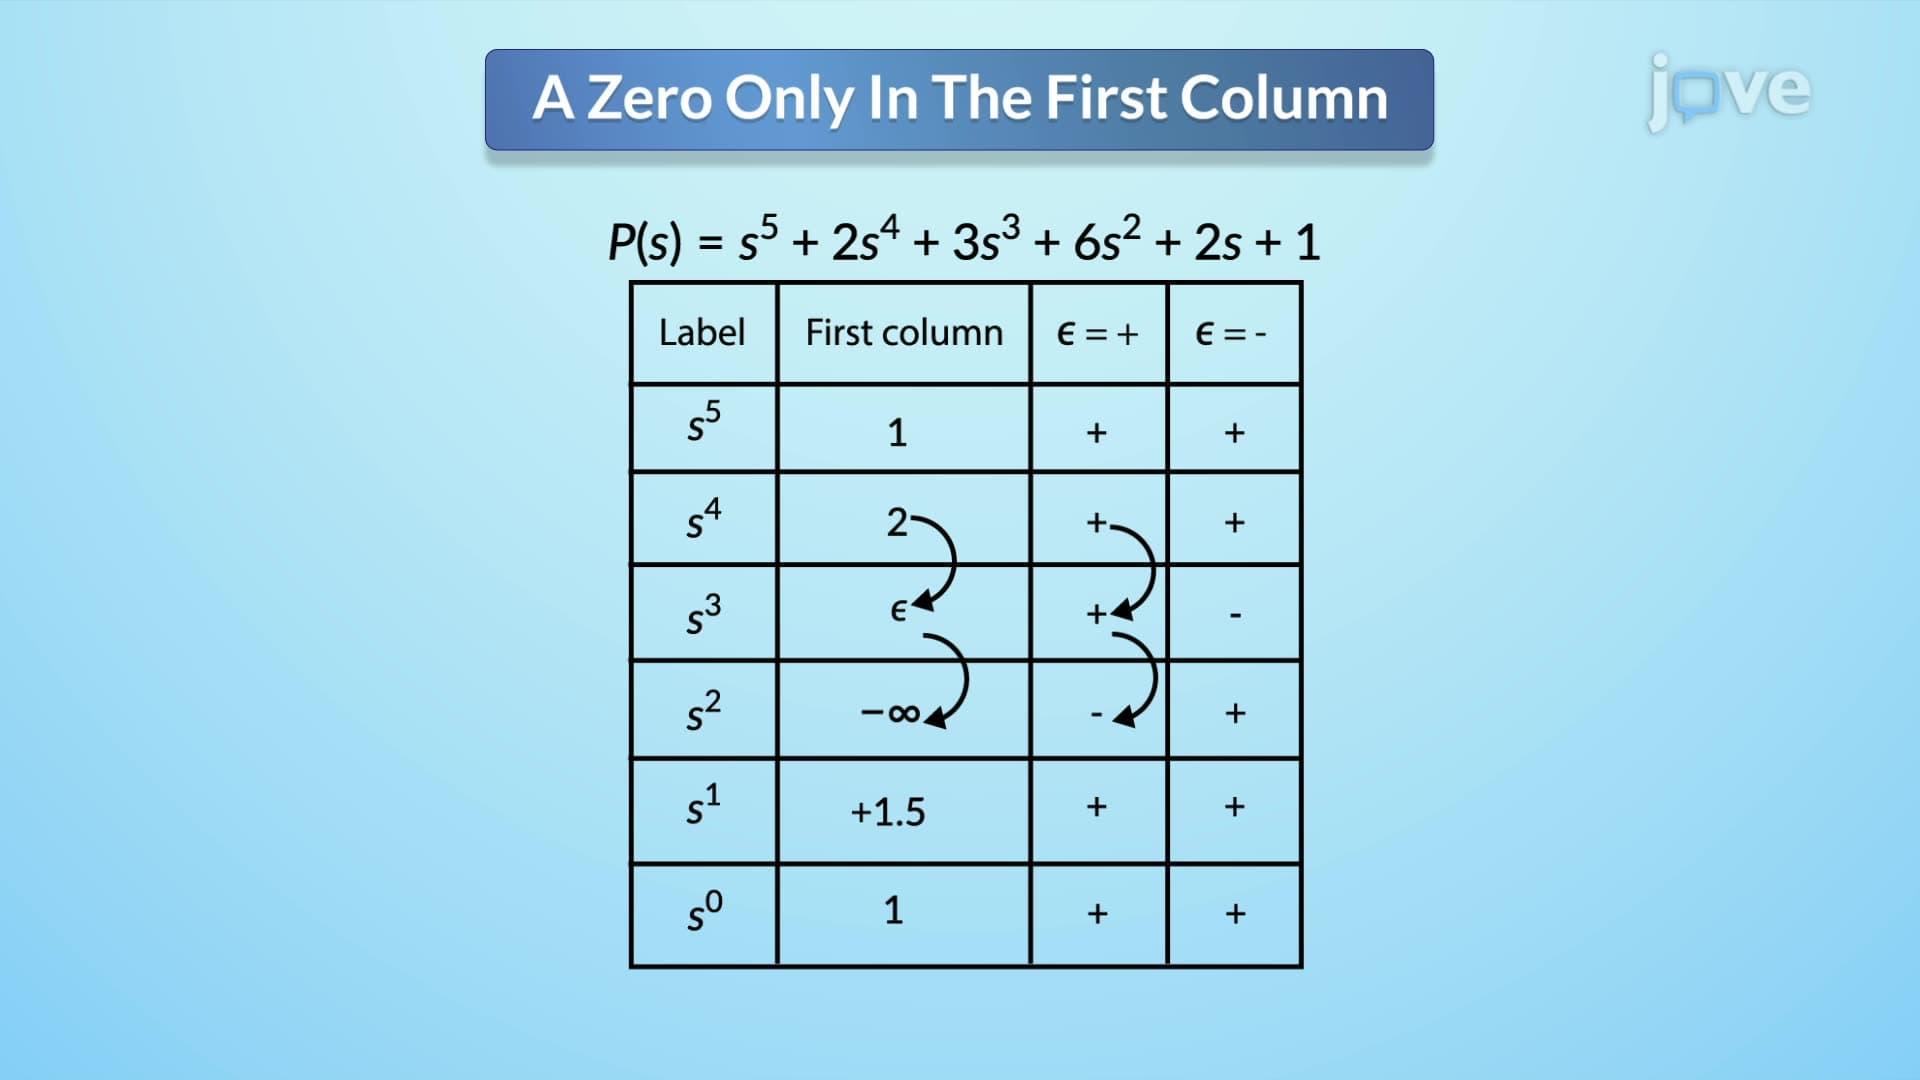
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
 01:29
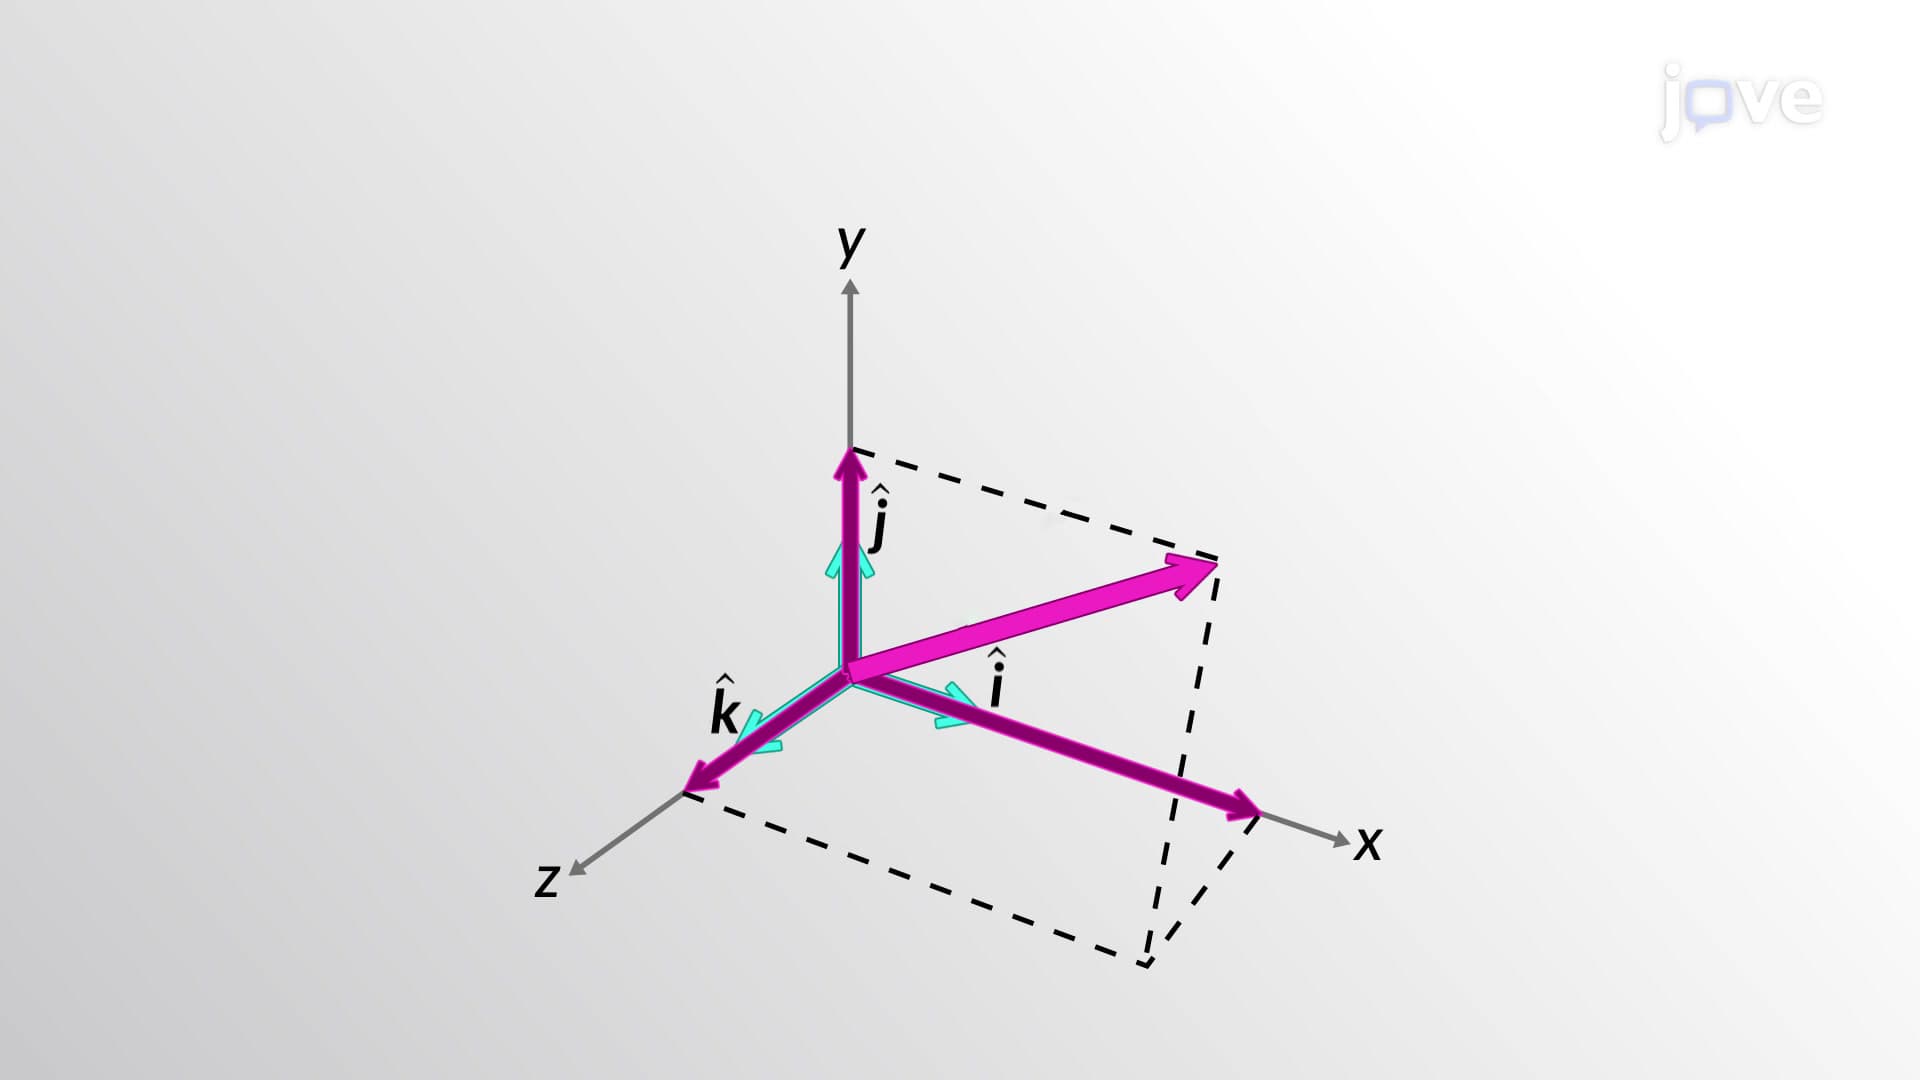
Vector Components in the Cartesian Coordinate System