Related Experiment Video
Updated: Sep 23, 2025
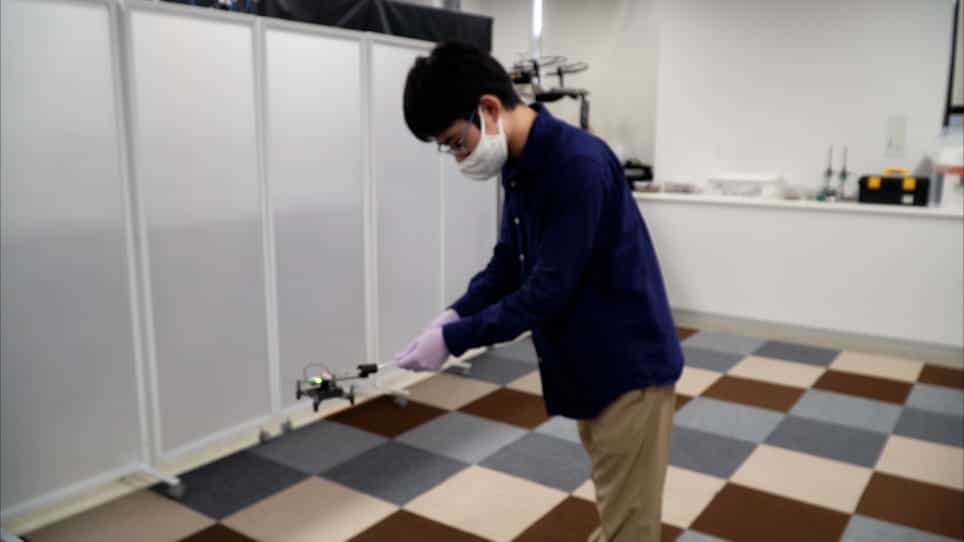

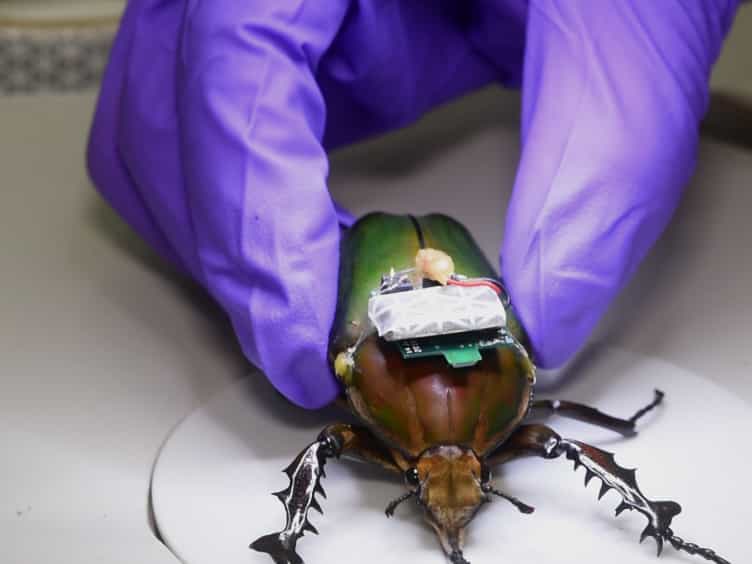
Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
A bioinspired revolving-wing drone with passive attitude stability and efficient hovering flight
Songnan Bai1, Qingning He2, Pakpong Chirarattananon1
1Department of Biomedical Engineering, City University of Hong Kong, Tat Chee Avenue, Hong Kong SAR, China.

Abstract:
Among small rotorcraft, the use of multiple compact rotors in a mechanically simple design leads to impressive agility and maneuverability but inevitably results in high energetic demand and acutely restricted endurance. Small spinning propellers used in these vehicles contrast with large lifting surfaces of winged seeds, which spontaneously gyrate into stable autorotation upon falling. The pronounced aerodynamic surfaces and delayed stalls are believed key to efficient unpowered flight. Here, the bioinspired principles are adopted to notably reduce the power consumption of small aerial vehicles by means of a samara-inspired robot. We report a dual-wing 35.1-gram aircraft capable of hovering flight via powered gyration. Equipped with two rotors, the underactuated robot with oversized revolving wings, designed to leverage unsteady aerodynamics, was optimized for boosted flight efficiency. Through the analysis of flight dynamics and stability, the vehicle was designed for passive attitude stability, eliminating the need for fast feedback to stay upright. To this end, the drone demonstrates flight with a twofold decrease in power consumption when compared with benchmark multirotor robots. Exhibiting the power loading of 8.0 grams per watt, the vehicle recorded a flight time of 14.9 minutes and up to 24.5 minutes when equipped with a larger battery. Taking advantage of the fast revolving motion to overcome the severe underactuation, we also realized position-controlled flight and illustrated examples of mapping and surveillance applications with a 21.5-gram payload.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:02
Gyroscope
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:24
Gyroscope: Precession
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
Lift