Related Experiment Video
Updated: Sep 23, 2025
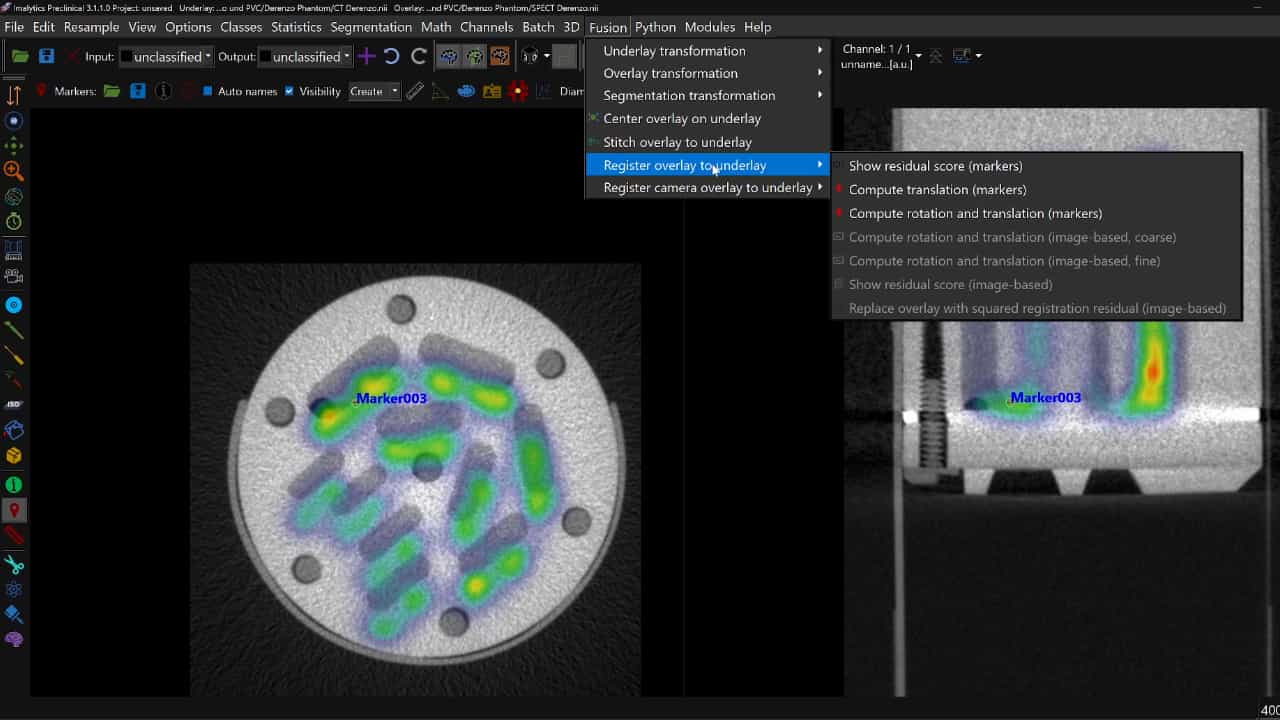

Author Spotlight: An Efficient and Robust Software for Automated Fusion of Multiple Preclinical Imaging Modalities
Published on: October 27, 2023
3D-DFM: Anchor-Free Multimodal 3-D Object Detection With Dynamic Fusion Module for Autonomous Driving

Abstract:
Recent advances in cross-modal 3D object detection rely heavily on anchor-based methods, and however, intractable anchor parameter tuning and computationally expensive postprocessing severely impede an embedded system application, such as autonomous driving. In this work, we develop an anchor-free architecture for efficient camera-light detection and ranging (LiDAR) 3D object detection. To highlight the effect of foreground information from different modalities, we propose a dynamic fusion module (DFM) to adaptively interact images with point features via learnable filters. In addition, the 3D distance intersection-over-union (3D-DIoU) loss is explicitly formulated as a supervision signal for 3D-oriented box regression and optimization. We integrate these components into an end-to-end multimodal 3D detector termed 3D-DFM. Comprehensive experimental results on the widely used KITTI dataset demonstrate the superiority and universality of 3D-DFM architecture, with competitive detection accuracy and real-time inference speed. To the best of our knowledge, this is the first work that incorporates an anchor-free pipeline with multimodal 3D object detection.

Related Concept Videos
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...