Adaptive iterative learning control for high-order nonlinear systems with random initial state shifts

Guojun Li1, Tiantian Lu1, Yishi Han1
1Basic Courses Department, Zhejiang Police College, Hangzhou, 310053, China.

Abstract:
Aiming at the tracking problem for a class of high-order nonlinear systems with arbitrary initial state, this paper proposes different initial state shifts rectifying schemes for systems with different orders from the perspective of solving differential equations to ensure that the systems achieve complete tracking over the specified interval. This method relaxes the requirement of initial positioning in iterative learning control, and solves the problem of iterative learning control for high-order nonlinear systems with arbitrary initial state error. The theoretical analysis shows that the proposed schemes can make all signals in the system bounded, and ensure that the tracking error in the preset interval tends to zero as the number of iterations increases. When designing the controller, the arctangent function is used to avoid flutter of the control signal and related variables. The final simulations verify the effectiveness of the proposed algorithms.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
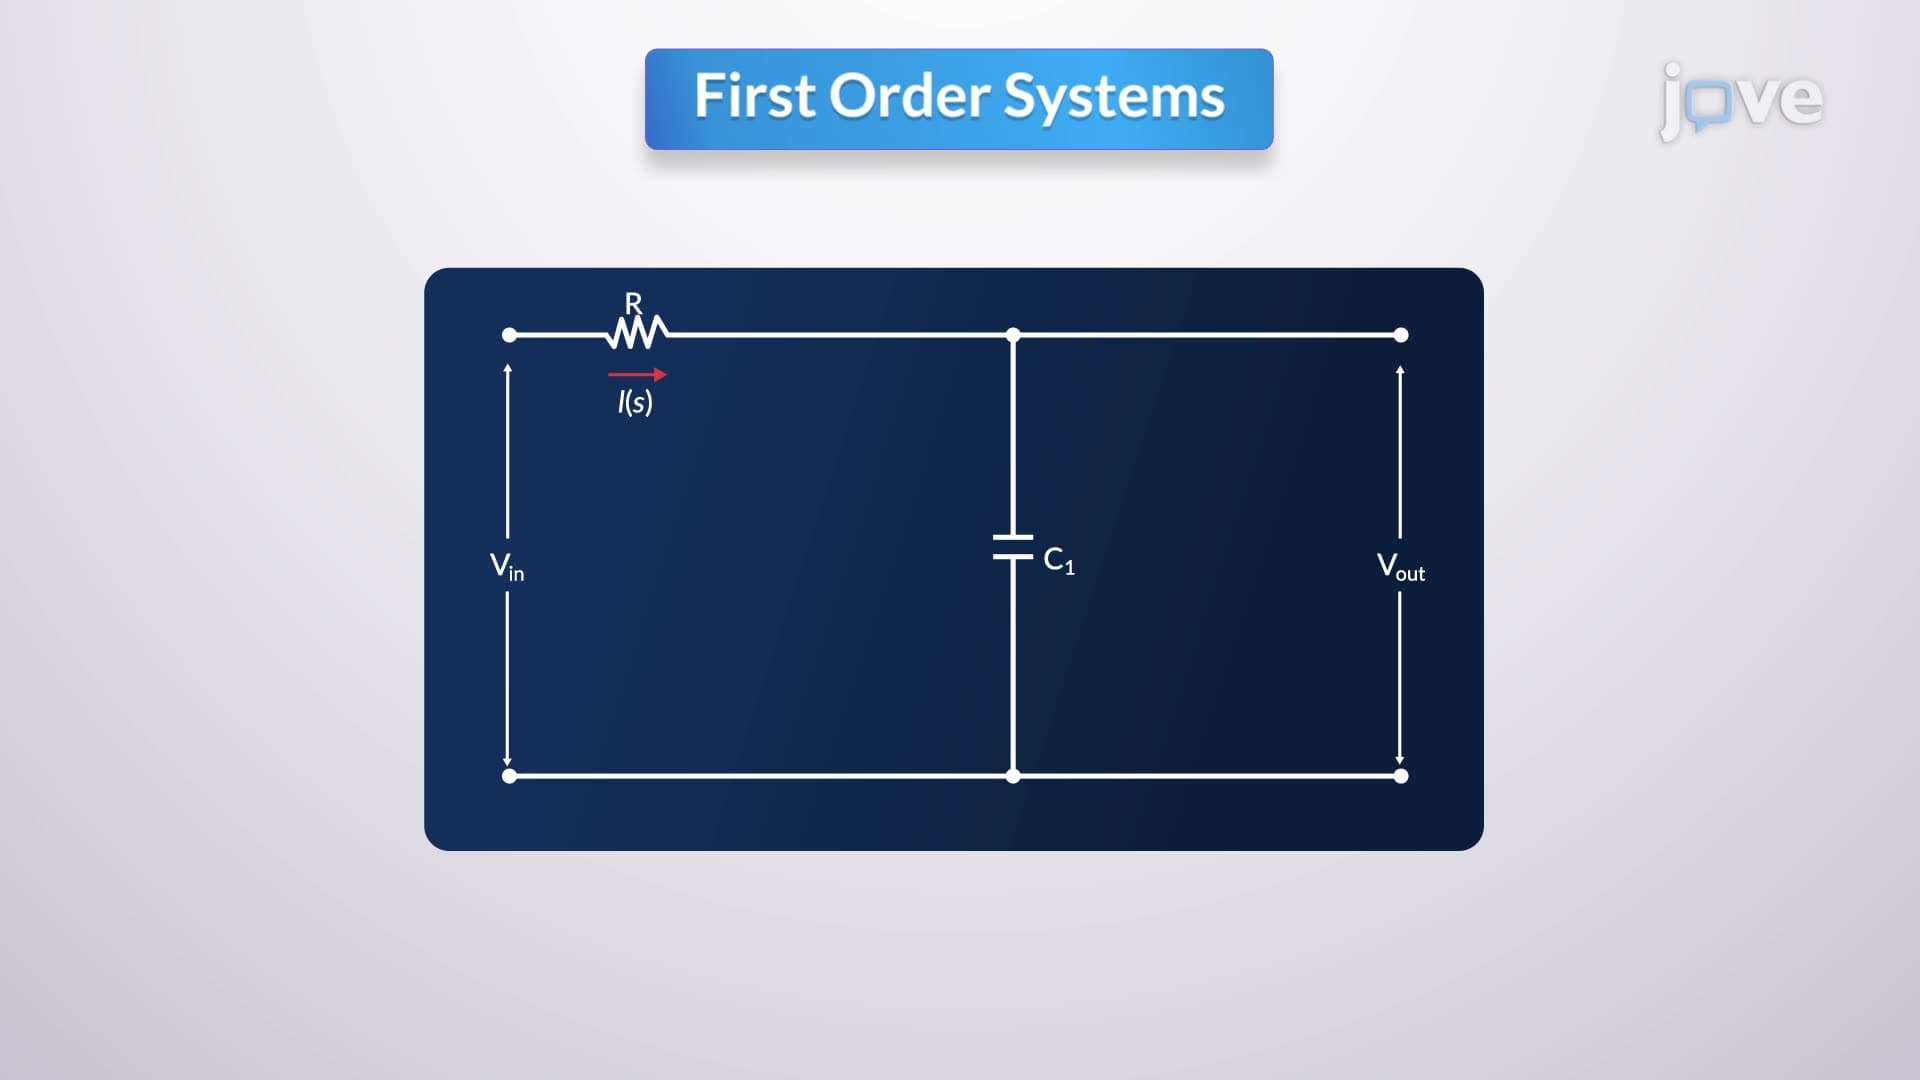
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:18
Second Order systems II