Related Experiment Video
Updated: Sep 23, 2025

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Estimating curvilinear self-motion from optic flow with a biologically inspired neural system
Oliver W Layton1,2, Nathaniel Powell2, Scott T Steinmetz2
1Department of Computer Science, Colby College, Waterville, ME, United States of America.

Abstract:
Optic flow provides rich information about world-relative self-motion and is used by many animals to guide movement. For example, self-motion along linear, straight paths without eye movements, generates optic flow that radiates from a singularity that specifies the direction of travel (heading). Many neural models of optic flow processing contain heading detectors that are tuned to the position of the singularity, the design of which is informed by brain area MSTd of primate visual cortex that has been linked to heading perception. Such biologically inspired models could be useful for efficient self-motion estimation in robots, but existing systems are tailored to the limited scenario of linear self-motion and neglect sensitivity to self-motion along more natural curvilinear paths. The observer in this case experiences more complex motion patterns, the appearance of which depends on the radius of the curved path (path curvature) and the direction of gaze. Indeed, MSTd neurons have been shown to exhibit tuning to optic flow patterns other than radial expansion, a property that is rarely captured in neural models. We investigated in a computational model whether a population of MSTd-like sensors tuned to radial, spiral, ground, and other optic flow patterns could support the accurate estimation of parameters describing both linear and curvilinear self-motion. We used deep learning to decode self-motion parameters from the signals produced by the diverse population of MSTd-like units. We demonstrate that this system is capable of accurately estimating curvilinear path curvature, clockwise/counterclockwise sign, and gaze direction relative to the path tangent in both synthetic and naturalistic videos of simulated self-motion. Estimates remained stable over time while rapidly adapting to dynamic changes in the observer's curvilinear self-motion. Our results show that coupled biologically inspired and artificial neural network systems hold promise as a solution for robust vision-based self-motion estimation in robots.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
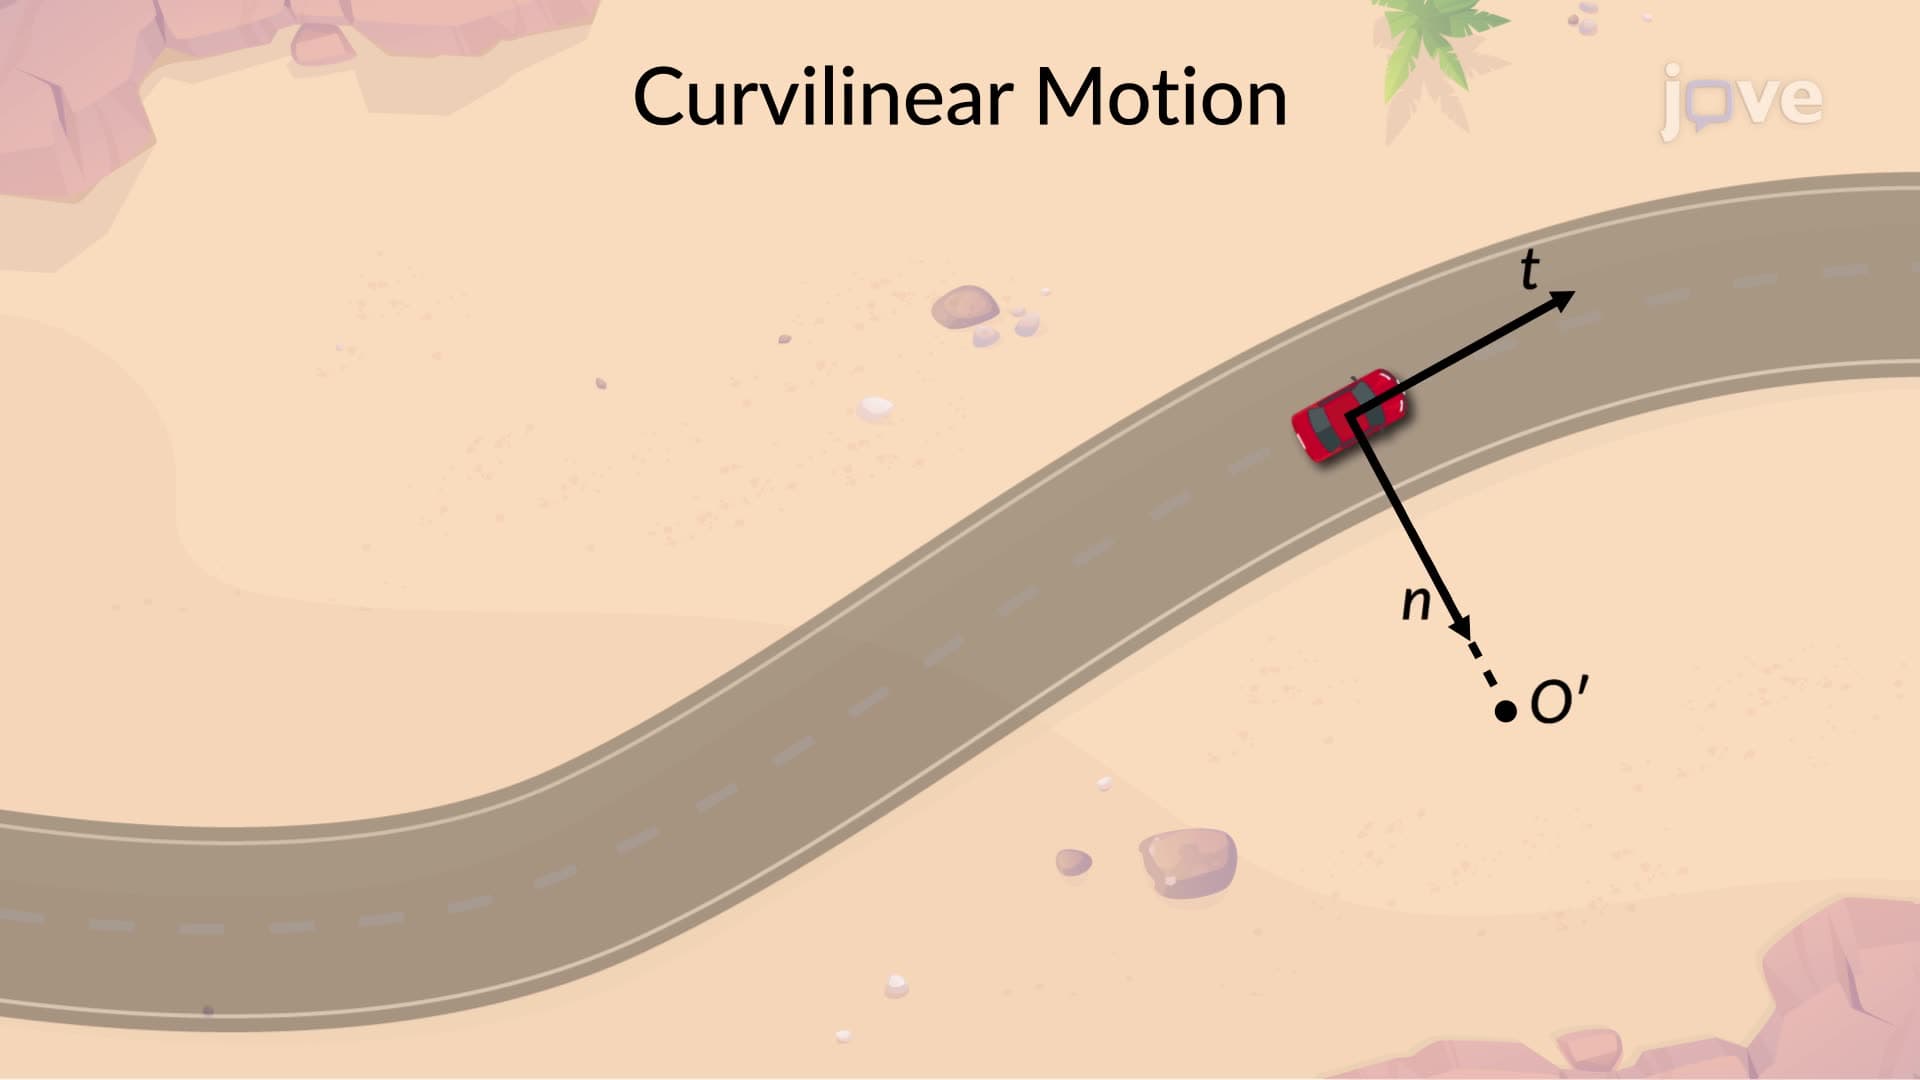
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:27
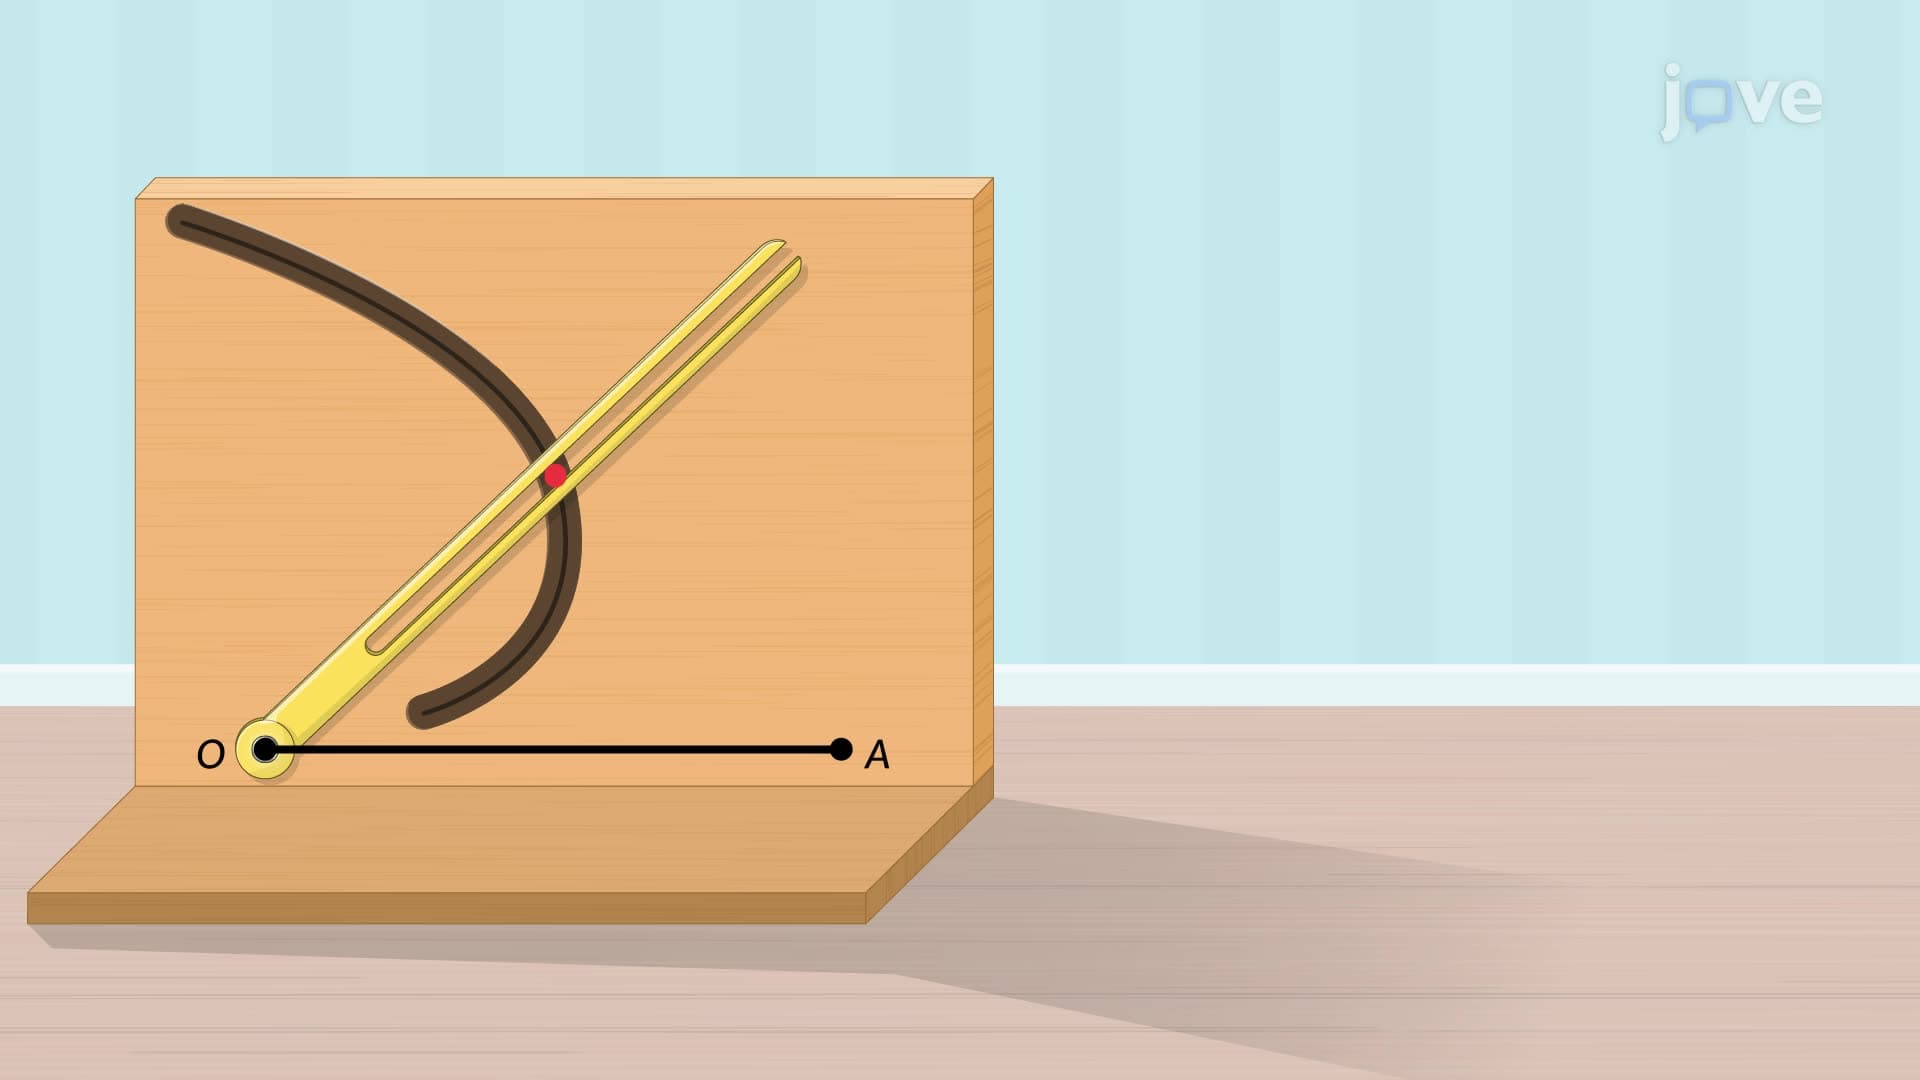
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...