The stability investigation of variable viscosity control in the human-robot interaction
Related Experiment Video
Updated: Sep 22, 2025

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Lin Dong1, Nicolas Perrin1, Florian Richer1
1Institut des Systèmes Intelligents et de Robotique, Sorbonne Universités UPMC Univ. Paris 06, Paris, France.

Background:
For many co-manipulative applications, variable damping is a valuable feature provided by robots. One approach is implementing a high viscosity at low velocities and a low viscosity at high velocities. This, however, is proven to have the possibility to alter human natural motion performance.
Methods:
We show that the distortion is caused by the viscosity drop resulting in robot's resistance to motion. To address this, a method for stably achieving the desired behaviour is presented. It involves leveraging a first-order linear filter to slow the viscosity variation down.
Results:
The proposition is supported by a theoretical analysis using a robotic model. Meanwhile, the user performance in human-robot experiments gets significantly improved, showing the practical efficiency in real applications.
Conclusions:
This paper discusses the variable viscosity control in the context of co-manipulation. An instability problem and its solution were theoretically shown and experimentally evidenced through human-robot experiments.
More Related Videos
Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
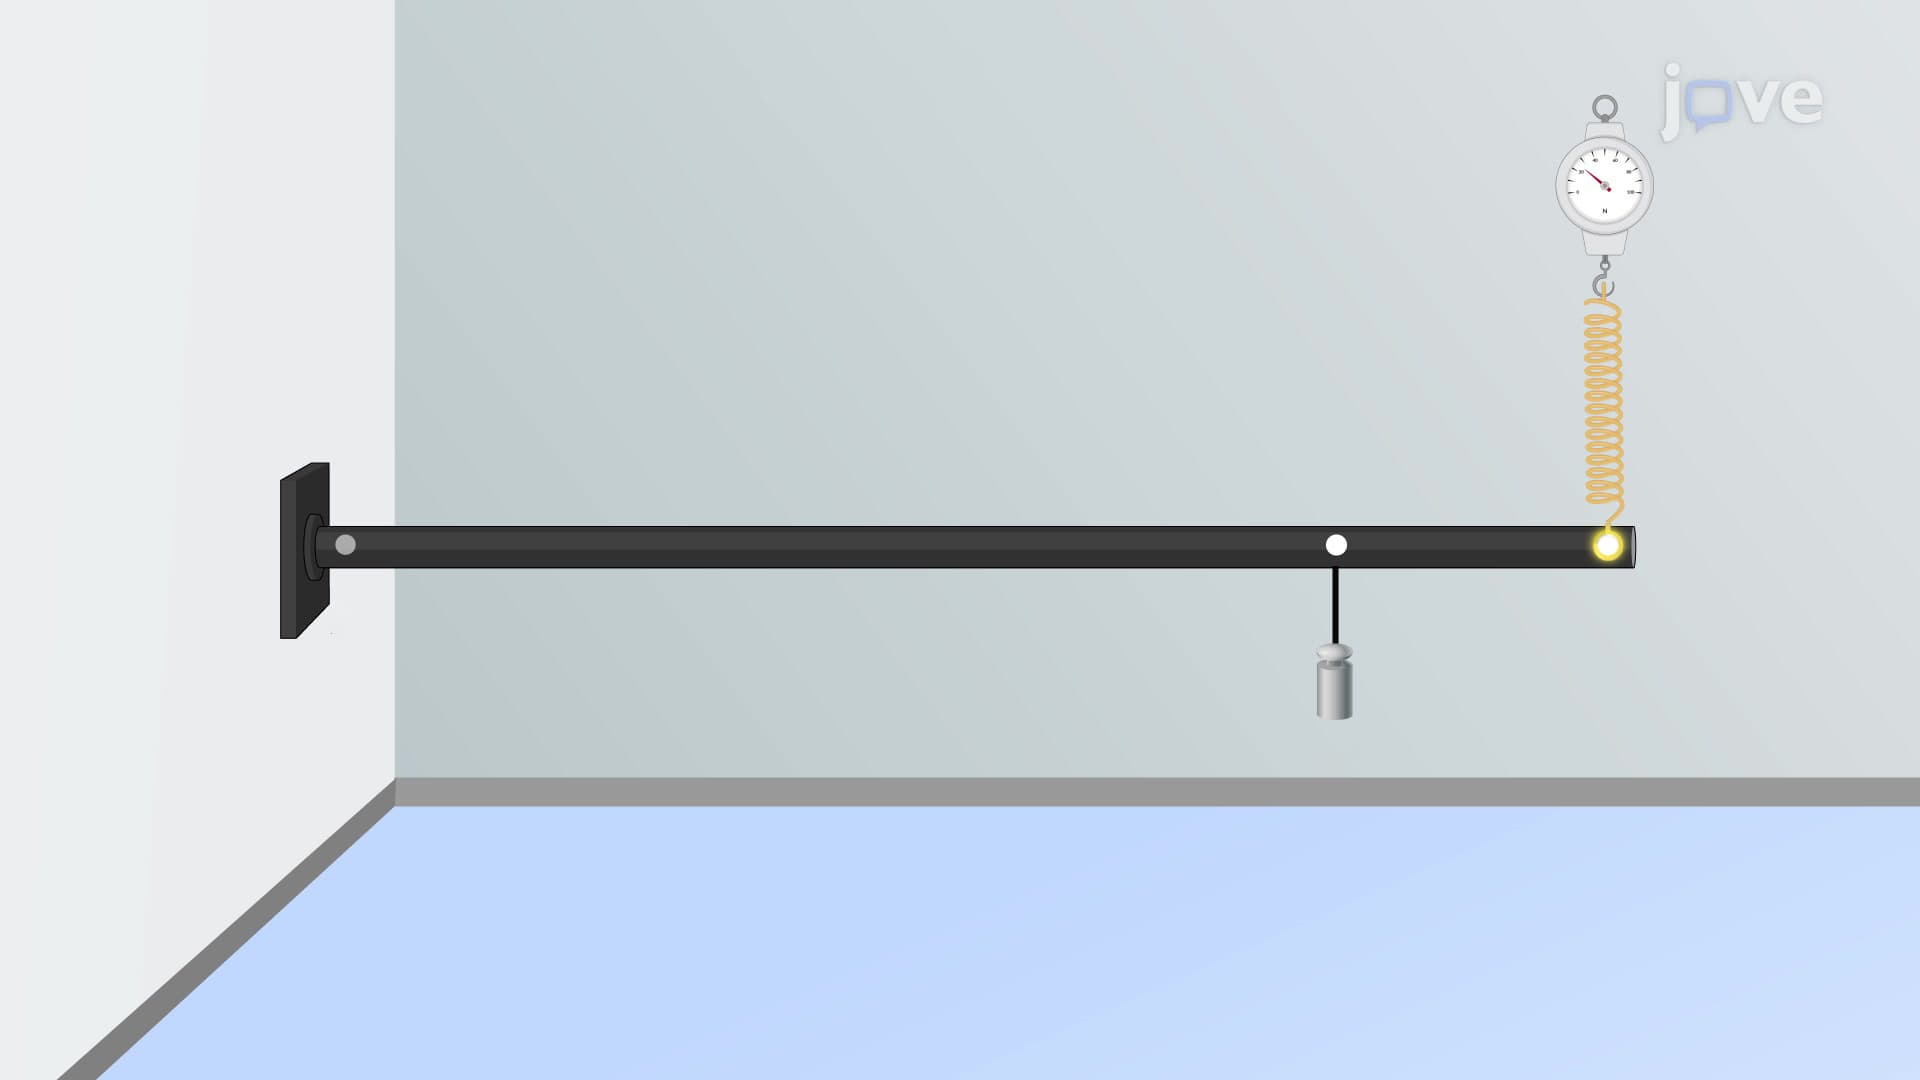
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:15
Kinematic Equations: Problem Solving
 01:13
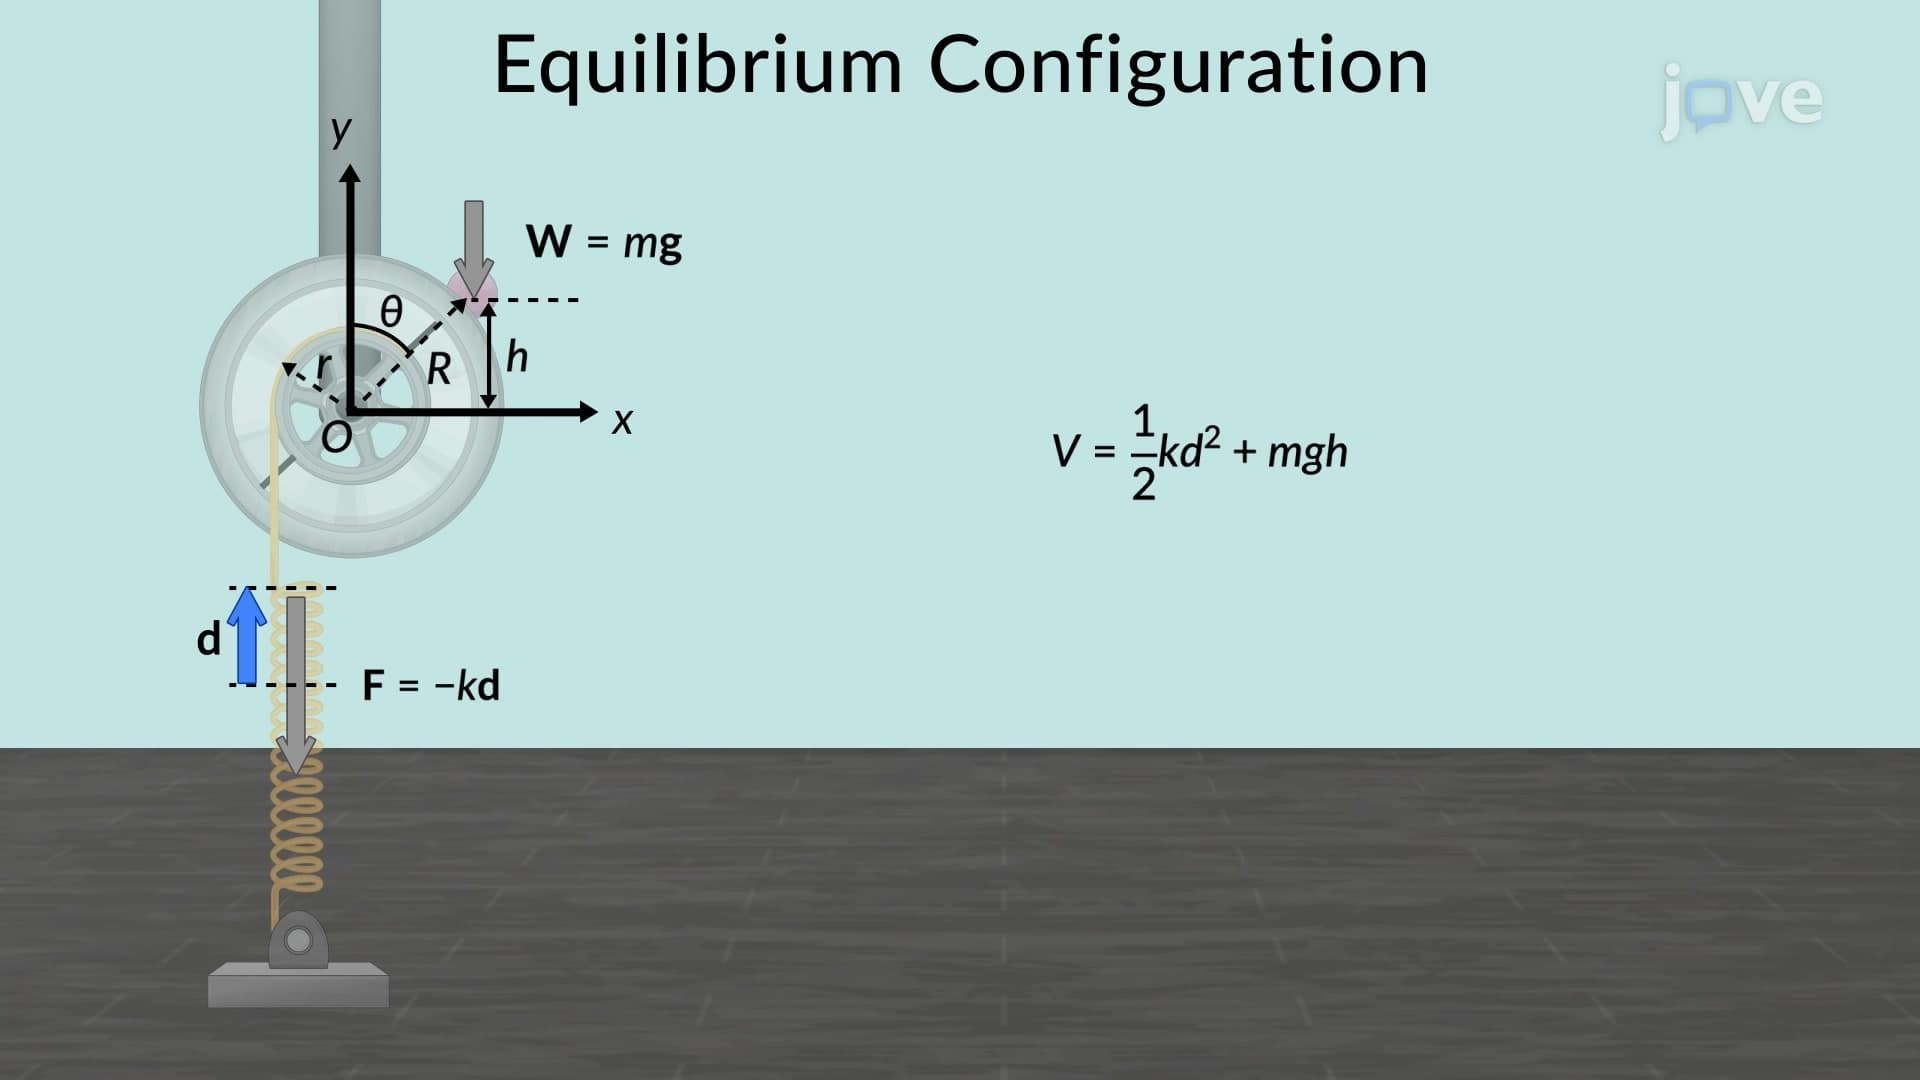
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...