Related Experiment Video
Updated: Sep 22, 2025

Bringing the Visible Universe into Focus with Robo-AO
Published on: February 12, 2013
Influence of Integration Schemes and Maneuvers on the Initial Alignment and Calibration of AUVs: Observability and
Adriano Frutuoso1, Felipe O Silva2, Ettore A de Barros1
1Unmanned Vehicles Laboratory, Department of Mechatronics Engineering, University of Sao Paulo, Avenida Professor Mello Moraes, 2231, Sao Paulo 05508-030, Brazil.

Abstract:
The use of autonomous underwater vehicles (AUV) has increased in a wide range of sectors, including the oil and gas industry, military, and marine research. The AUV capabilities to operate without a direct human operator and untethered to a support vessel are features that have aroused interest in the marine environment. The localization of AUV is significantly affected by the initial alignment and the calibration of the navigation sensors. In this sense, this paper proposes a thorough observability analysis applied to the latter problem. The observability analysis is carried out considering three types of sensor fusion integration and a set of maneuvers, and the results are validated through numerical simulations. As main contribution of this paper, it is shown how the addition of position errors in the observation vector can decouple some gyro and accelerometer biases from the latitude and altitude errors, particularly in the stationary observability analysis. The influence of oscillations in the diving plane and typical AUV maneuvers are analyzed, showing their relative impacts on the degree of observability of the inertial measurement unit (IMU)/Doppler velocity log (DVL) misalignment and DVL scale factor error. Finally, the state's estimation accuracy is also analyzed, showing the limitation of the degree of observability as an assessment tool for the estimability of the states.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:19
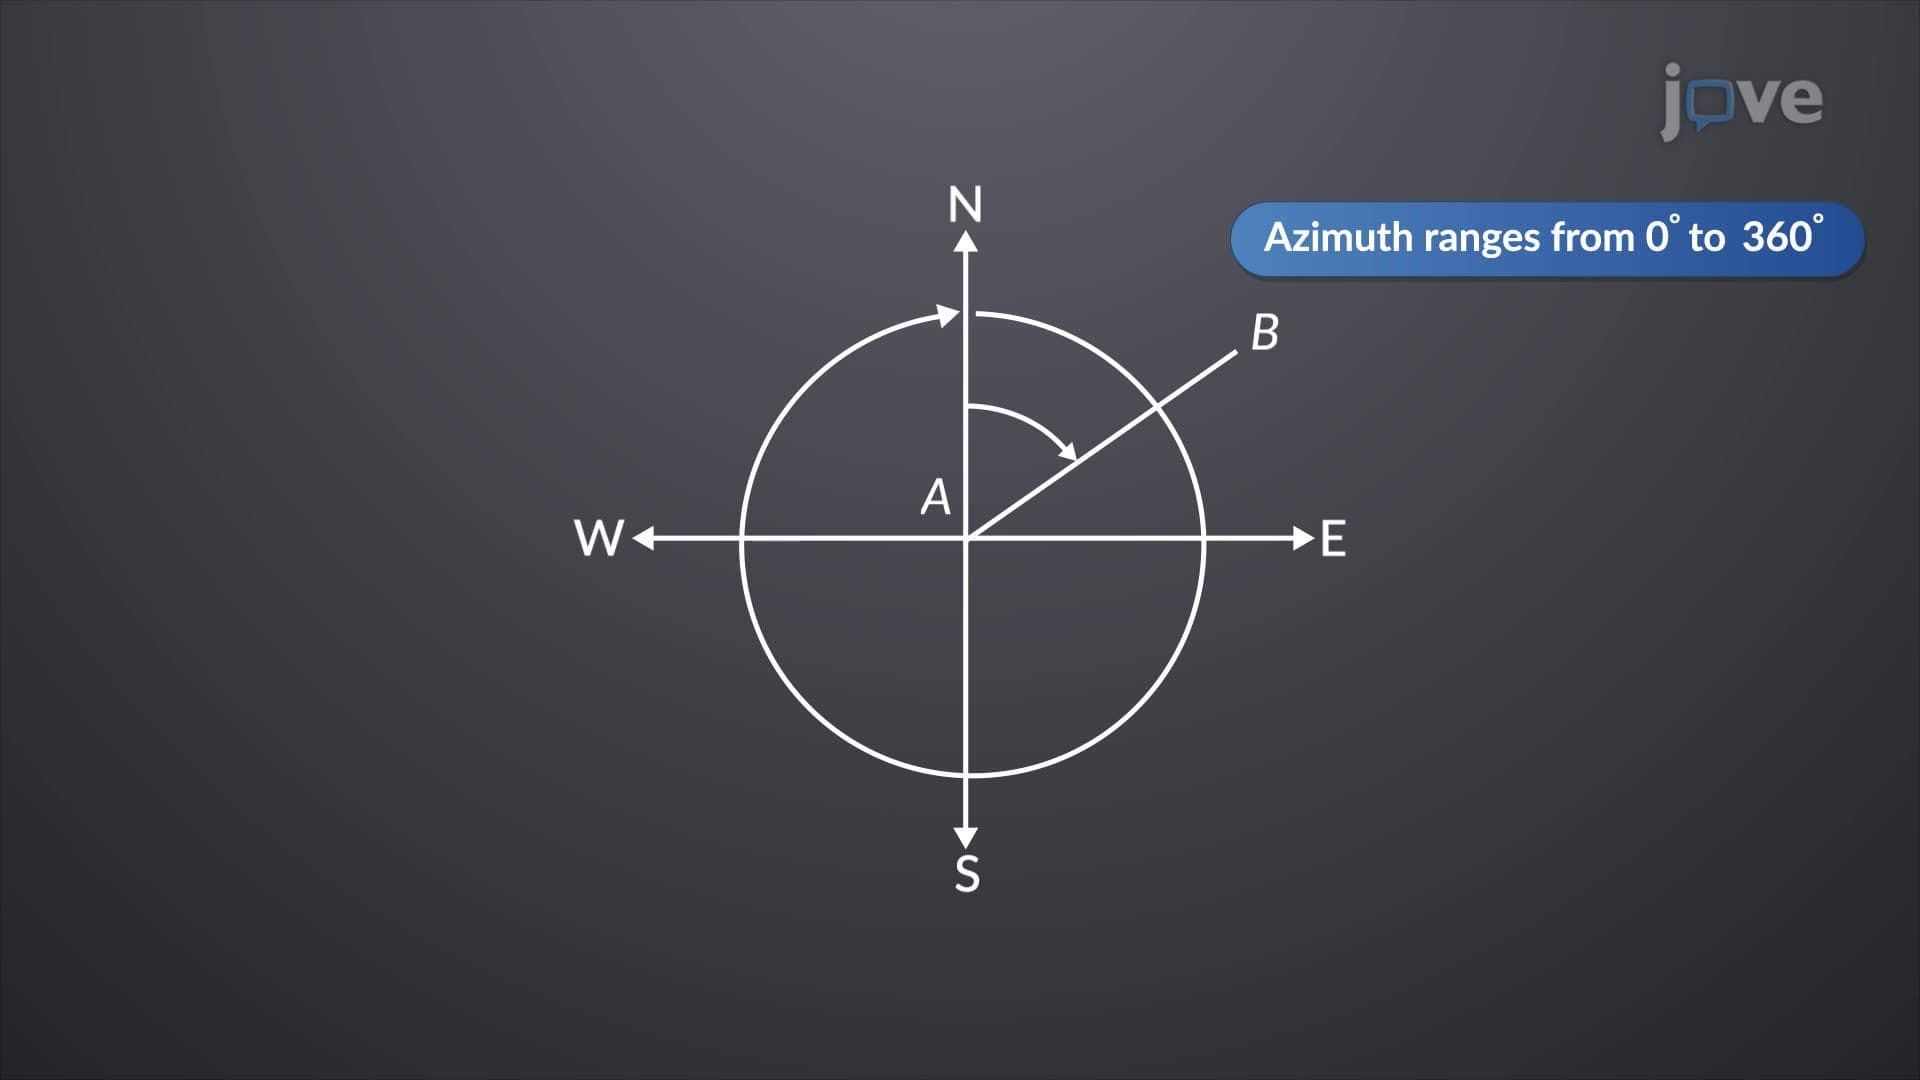
Azimuths and Bearings
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...