Related Experiment Video
Updated: Sep 22, 2025


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Autonomous Vehicle State Estimation and Mapping Using Takagi-Sugeno Modeling Approach
1Institut de Robòtica i Informàtica Industrial (CSIC-UPC), Llorens i Artigas, 4-6, 08028 Barcelona, Spain.

Abstract:
This paper proposes an optimal approach for state estimation based on the Takagi-Sugeno (TS) Kalman filter using measurement sensors and rough pose obtained from LIDAR scan end-points matching. To obtain stable and optimal TS Kalman gain for estimator design, a linear matrix inequality (LMI) is optimized which is constructed from Lyapunov stability criteria and dual linear quadratic regulator (LQR). The technique utilizes a Takagi-Sugeno (TS) representation of the system, which allows modeling the complex nonlinear dynamics in such a way that linearization is not required for the estimator or controller design. In addition, the TS fuzzy representation is exploited to obtain a real-time Kalman gain, avoiding the expensive optimization of LMIs at every step. The estimation schema is integrated with a nonlinear model-predictive control (NMPC) that is in charge of controlling the vehicle. For the demonstration, the approach is tested in the simulation, and for practical validity, a small-scale autonomous car is used.
More Related Videos

Related Concept Videos
 01:21
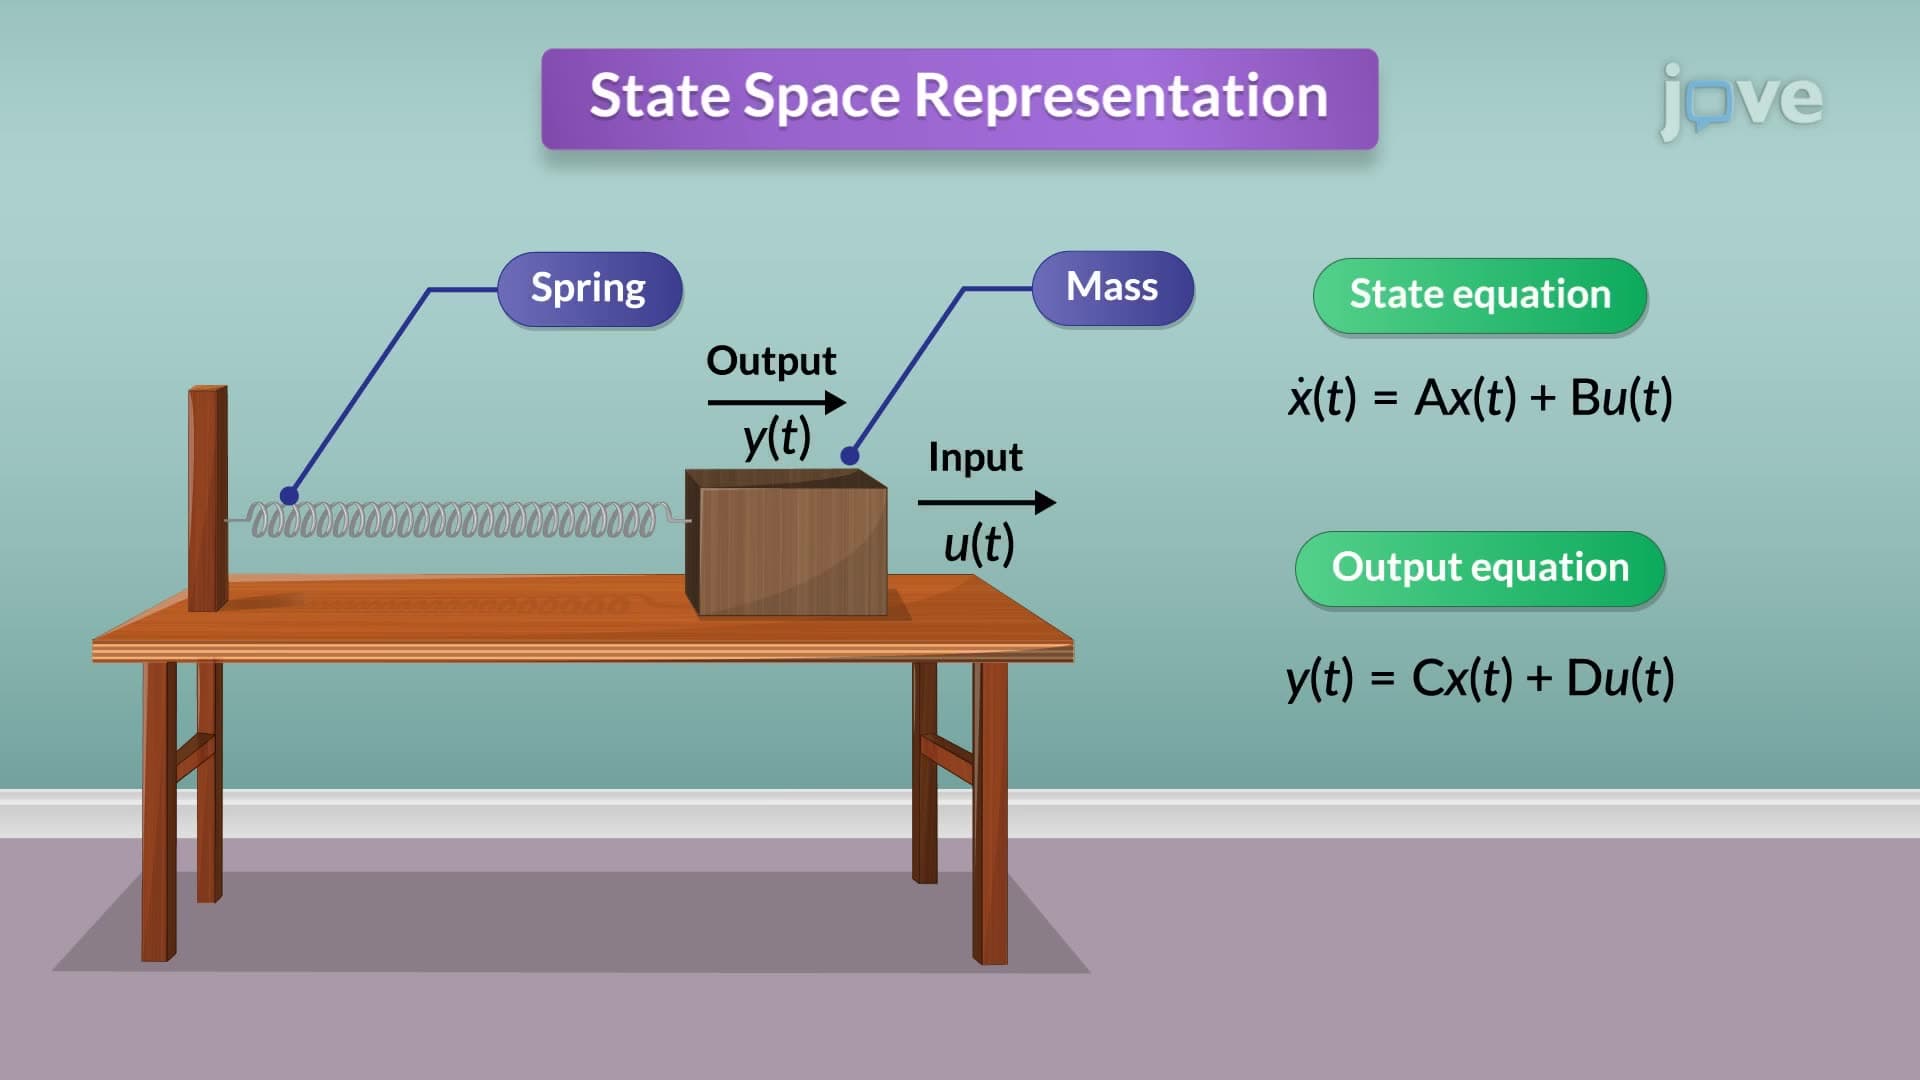
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:27
State Space Representation
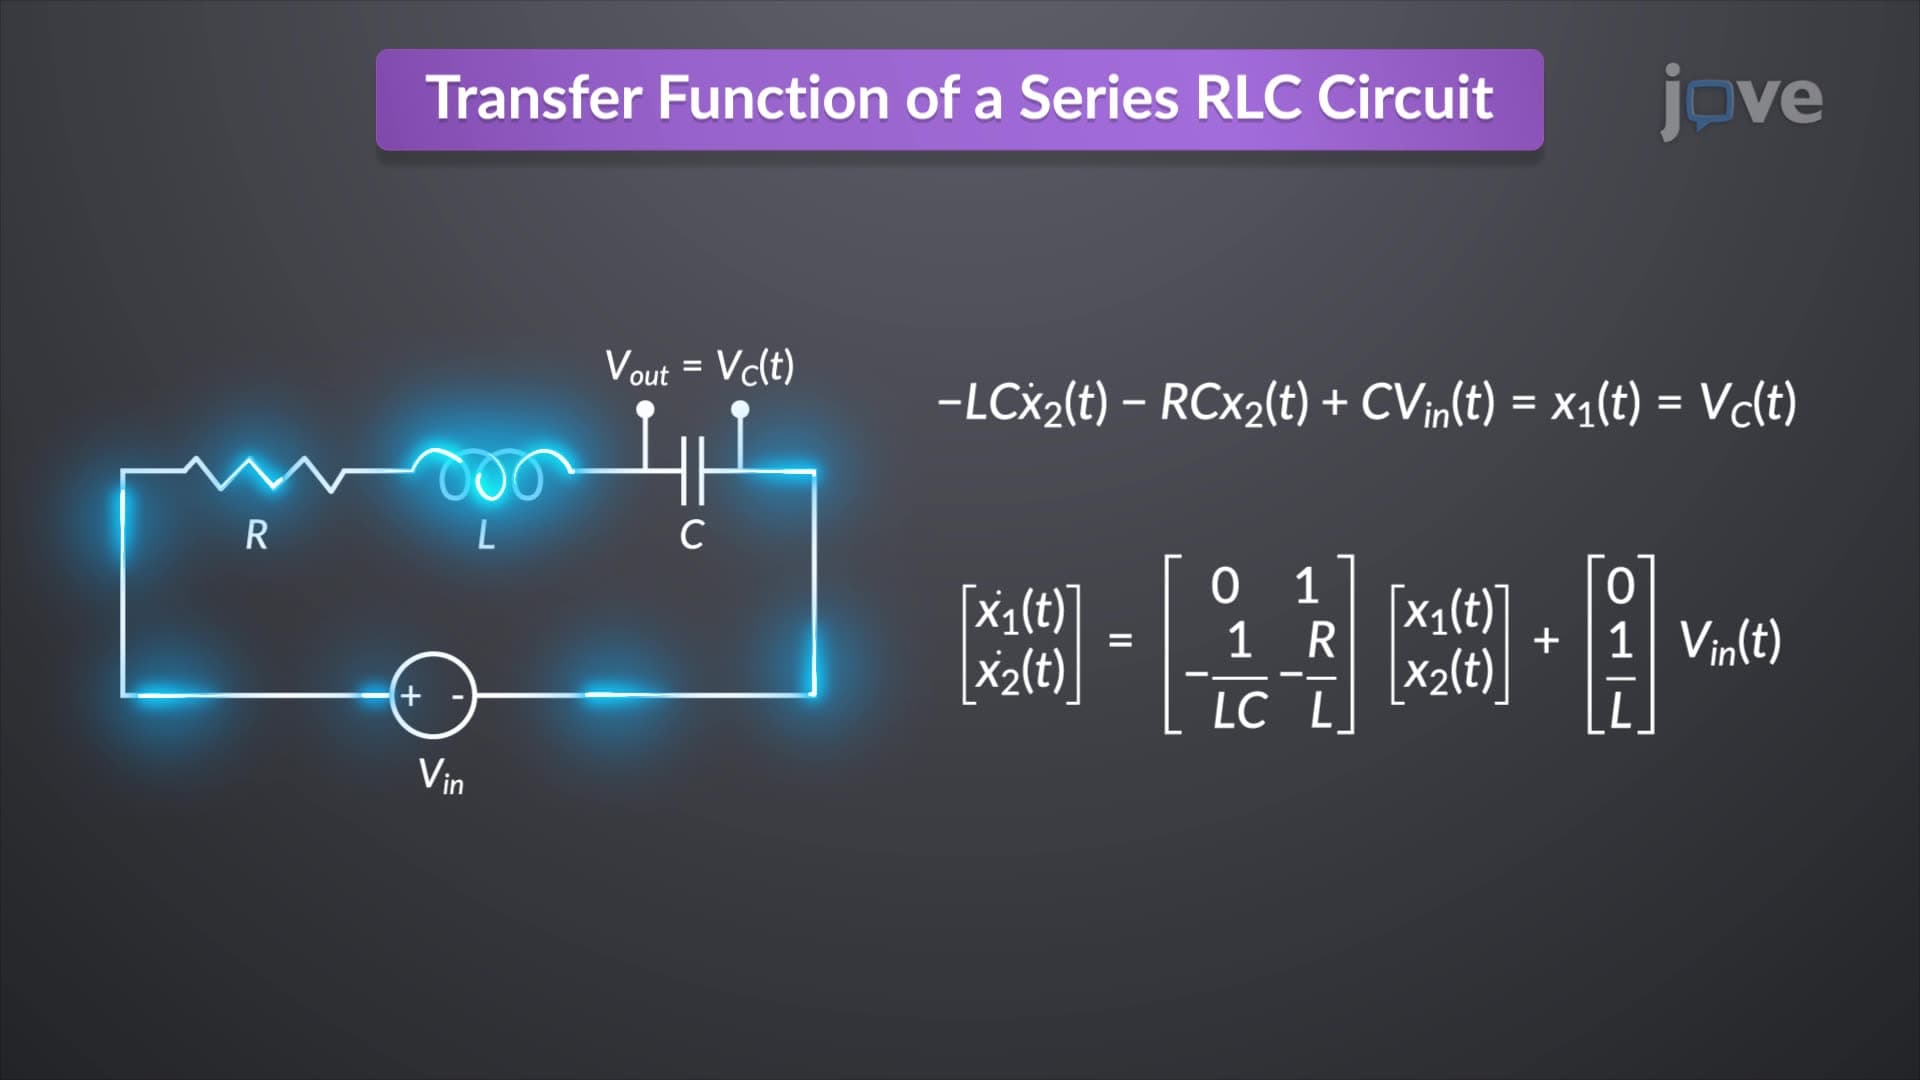
Consider an RLC circuit, a...
 01:23
Transfer Function to State Space
In an...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:30
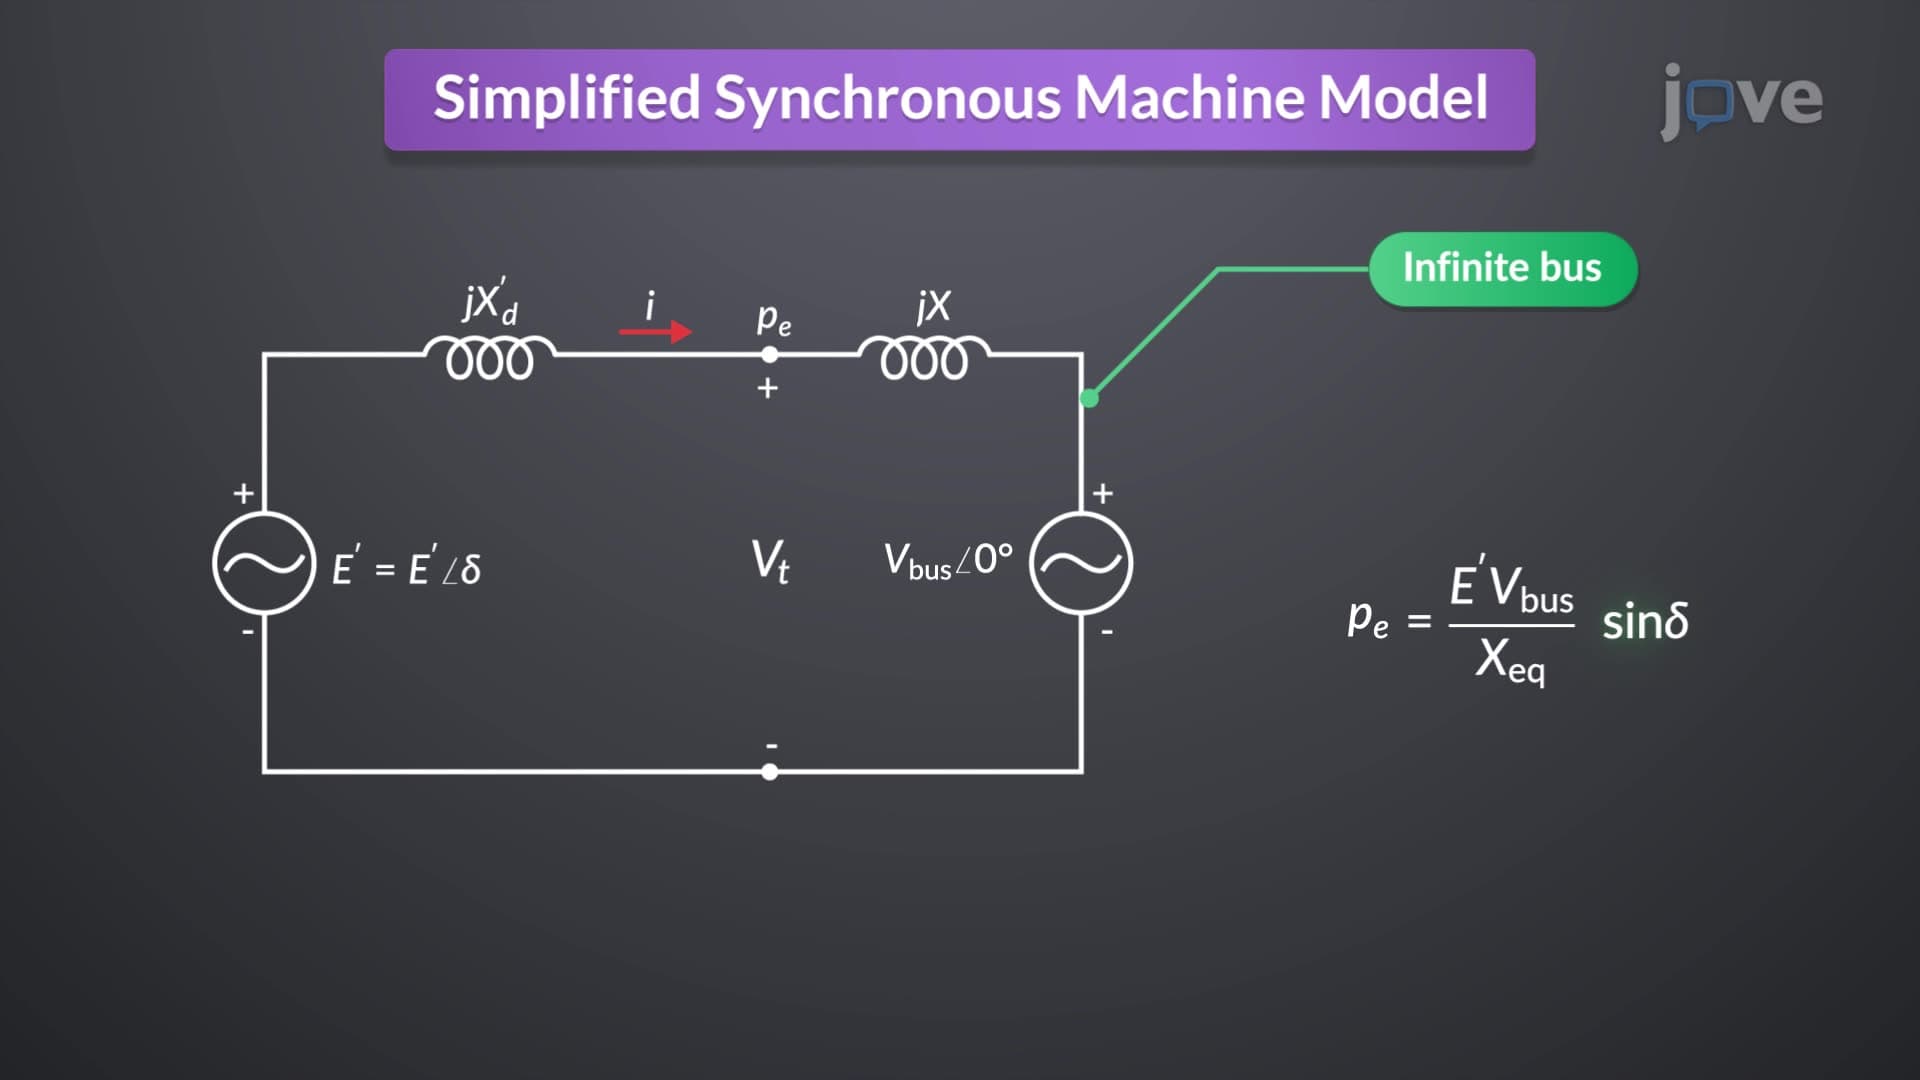
Simplified Synchronous Machine Model
In this model, each generator is connected to a...