Related Experiment Video
Updated: Sep 21, 2025


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Zonotopic Linear Parameter Varying SLAM Applied to Autonomous Vehicles
Marc Facerias1, Vicenç Puig2, Eugenio Alcala2
1Autonomous Systems, Department of Electrical and Electronic Engineering, University of Manchester, Sackville Street Building, Manchester M1 3BB, UK.

Abstract:
This article presents an approach to address the problem of localisation within the autonomous driving framework. In particular, this work takes advantage of the properties of polytopic Linear Parameter Varying (LPV) systems and set-based methodologies applied to Kalman filters to precisely locate both a set of landmarks and the vehicle itself. Using these techniques, we present an alternative approach to localisation algorithms that relies on the use of zonotopes to provide a guaranteed estimation of the states of the vehicle and its surroundings, which does not depend on any assumption of the noise nature other than its limits. LPV theory is used to model the dynamics of the vehicle and implement both an LPV-model predictive controller and a Zonotopic Kalman filter that allow localisation and navigation of the robot. The control and estimation scheme is validated in simulation using the Robotic Operating System (ROS) framework, where its effectiveness is demonstrated.
More Related Videos

Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:19
Root-Locus Method
This system can be represented by a block...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:27
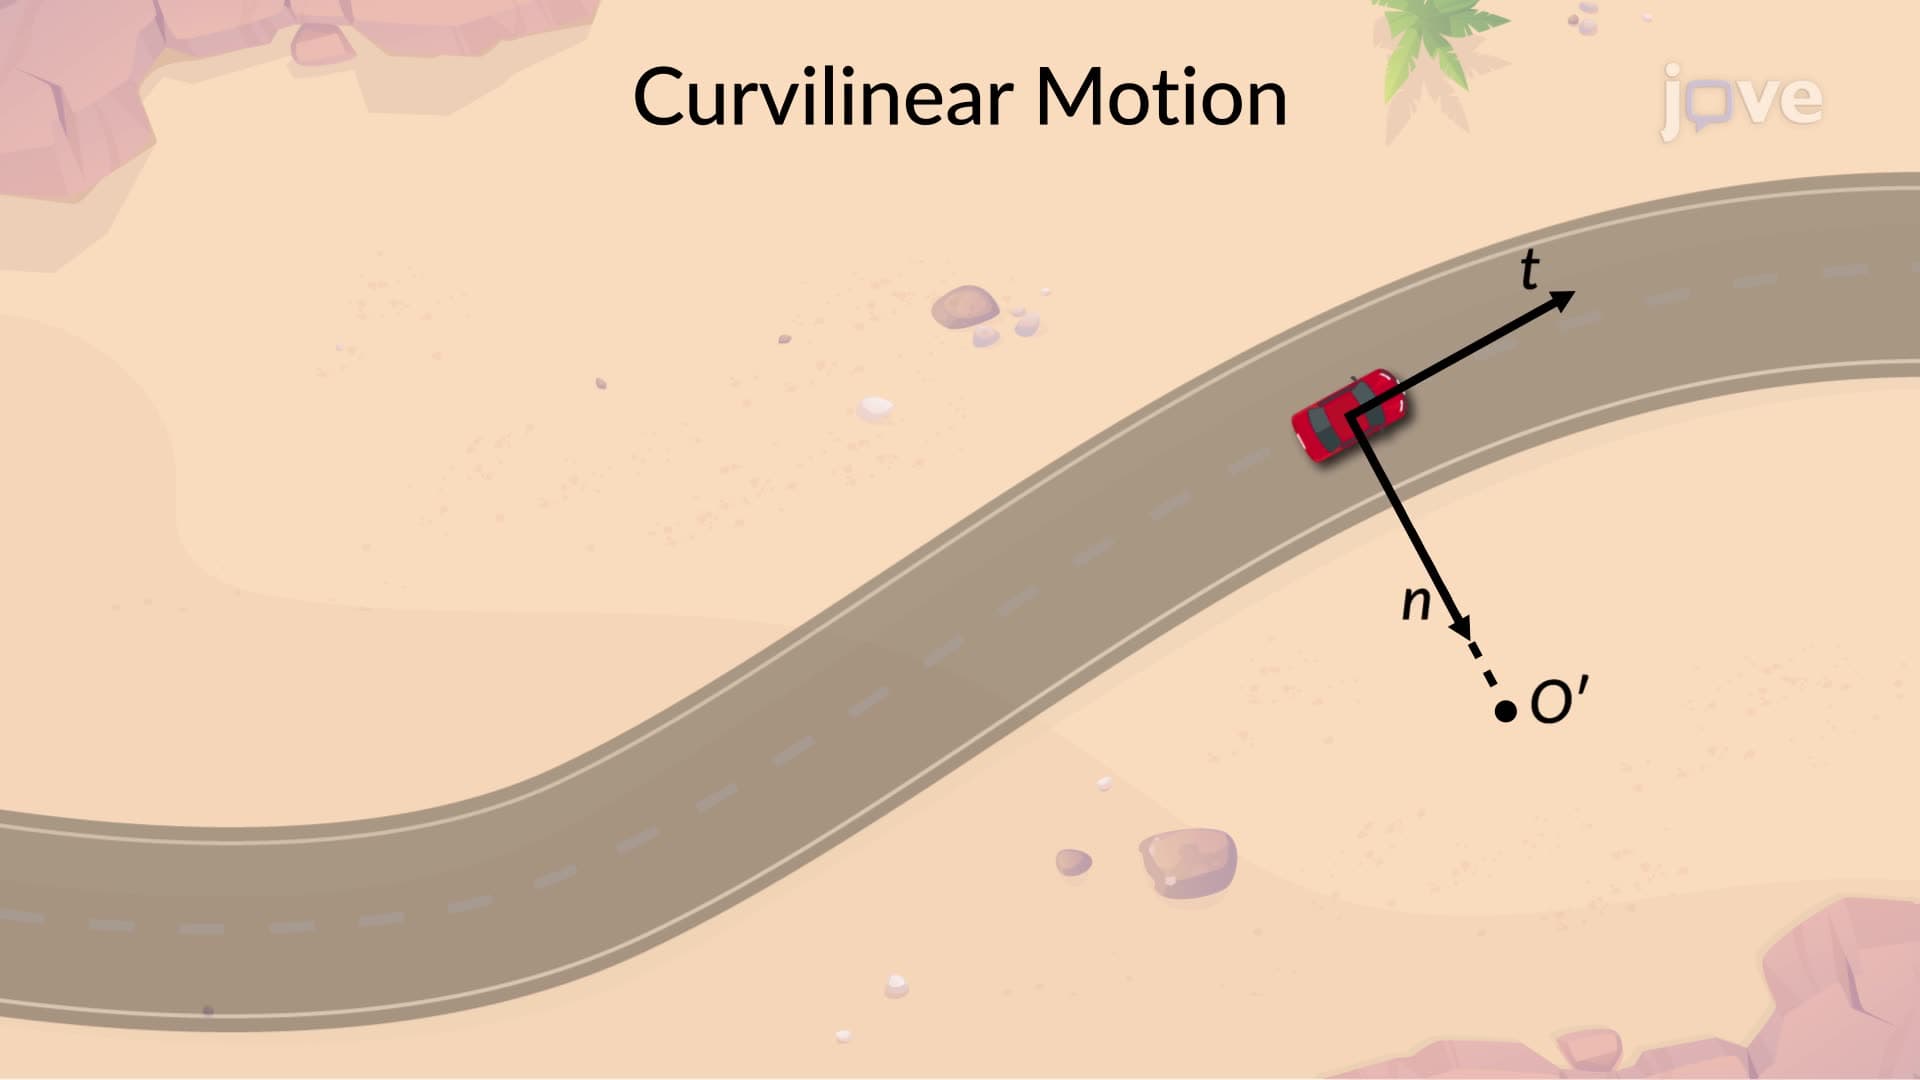
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:13
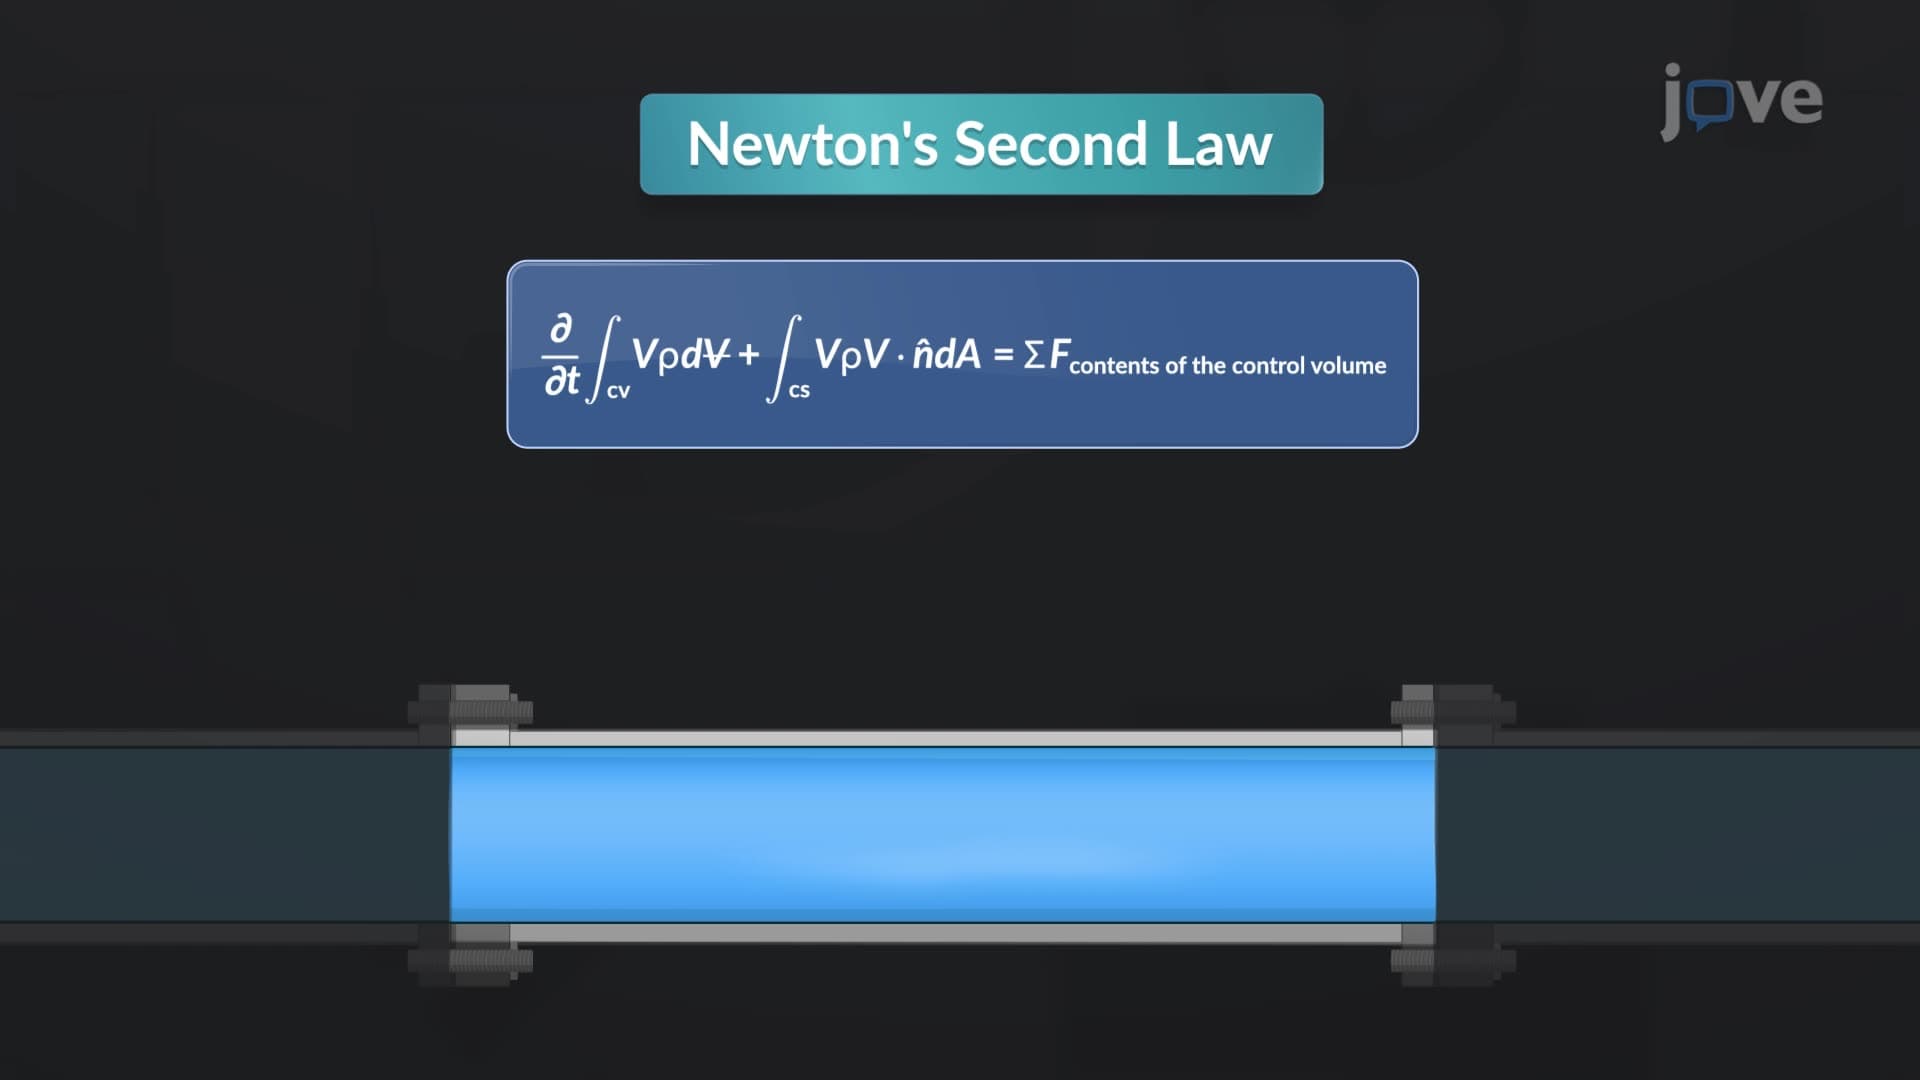
Linear Momentum in Control Volume