Related Experiment Video
Updated: Sep 21, 2025
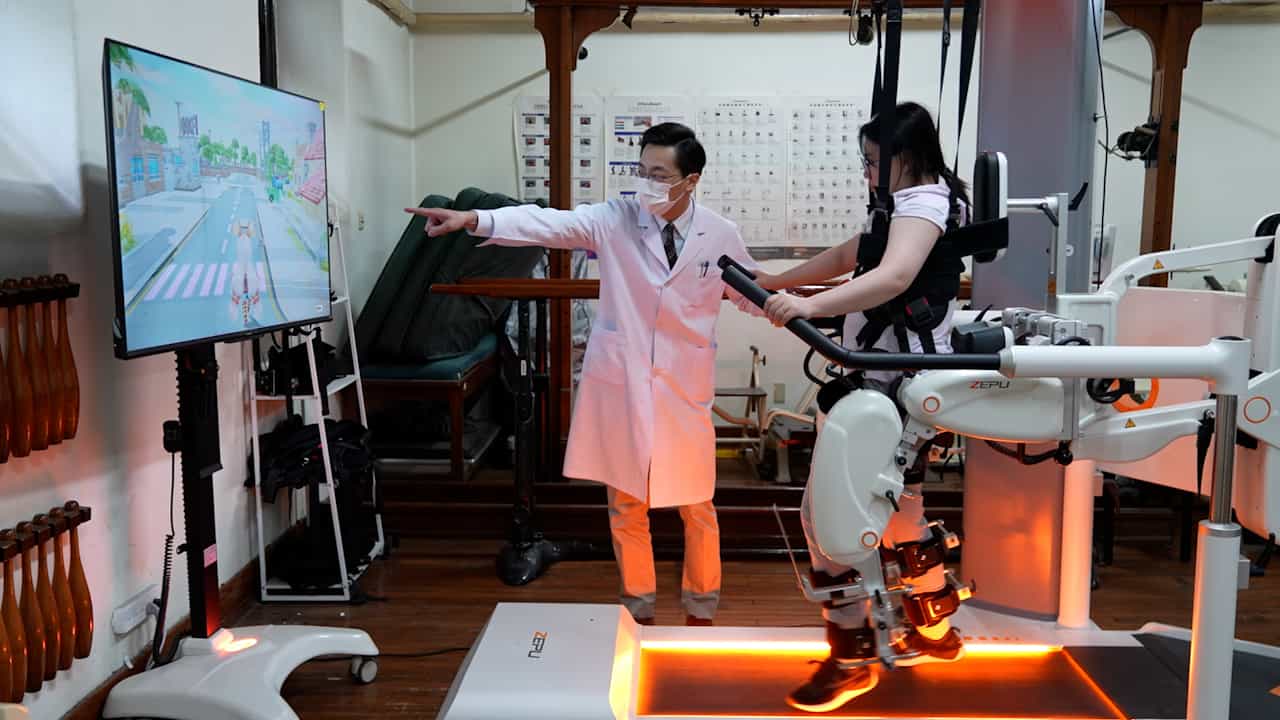
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
Feasibility of Overground Gait Training Using a Joint-Torque-Assisting Wearable Exoskeletal Robot in Children with
Juntaek Hong1, Jongweon Lee2, Taeyoung Choi1
1Department and Research Institute of Rehabilitation Medicine, Yonsei University College of Medicine, Seoul 03722, Korea.

Abstract:
Pediatric gait disorders are often chronic and accompanied by various complications, which challenge rehabilitation efforts. Here, we retrospectively analyzed the feasibility of overground robot-assisted gait training (RAGT) using a joint-torque-assisting wearable exoskeletal robot. In this study, 17 children with spastic cerebral palsy, cerebellar ataxia, and chronic traumatic brain injury received RAGT sessions. The Gross Motor Function Measure (GMFM), 6-min walk test (6 MWT), and 10-m walk test (10 MWT) were performed before and after intervention. The oxygen rate difference between resting and training was performed to evaluate the intensity of training in randomly selected sessions, while the Quebec User Evaluation of Satisfaction with assistive Technology 2.0 assessment was performed to evaluate its acceptability. A total of four of five items in the GMFM, gait speed on the 10 MWT, and total distance on the 6 MWT showed statistically significant improvement (p < 0.05). The oxygen rate was significantly higher during the training versus resting state. Altogether, six out of eight domains showed satisfaction scores more than four out of five points. In conclusion, overground training using a joint-torque-assisting wearable exoskeletal robot showed improvement in gross motor and gait functions after the intervention, induced intensive gait training, and achieved high satisfaction scores in children with static brain injury.