Locating an Underwater Target Using Angle-Only Measurements of Heterogeneous Sonobuoys Sensors with Low Accuracy
Related Experiment Video
Updated: Sep 21, 2025
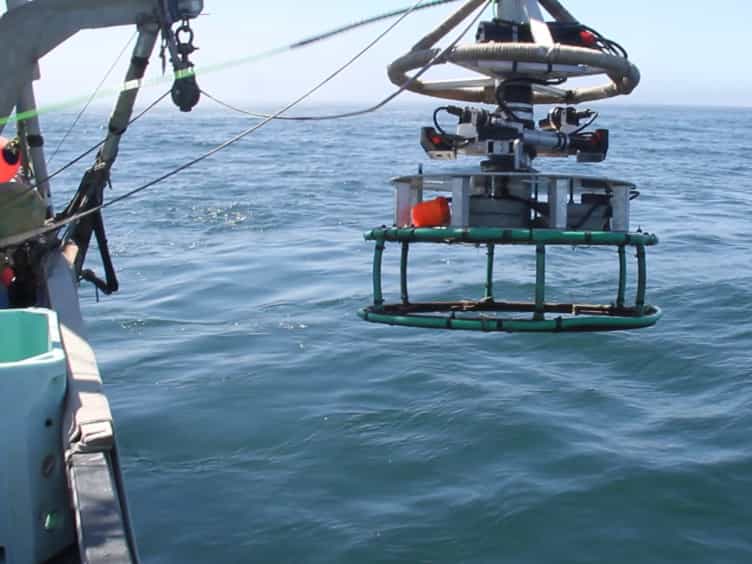
Development of New Methods for Quantifying Fish Density Using Underwater Stereo-video Tools
Published on: November 20, 2017
1Electronic and Electrical Department, Sungkyunkwan University, Suwon 16419, Korea.

Abstract:
This paper considers locating an underwater target, where many sonobuoys are positioned to measure the bearing of the target's sound. A sonobuoy has very low bearing accuracy, such as 10 degrees. In practice, we can use multiple heterogeneous sonobuoys, such that the variance of a sensor noise may be different from that of another sensor. In addition, the maximum sensing range of a sensor may be different from that of another sensor. The true target must exist within the sensing range of a sensor if the sensor detects the bearing of the target. In order to estimate the target position based on bearings-only measurements with low accuracy, this paper introduces a novel target localization approach based on multiple Virtual Measurement Sets (VMS). Here, each VMS is derived considering the bearing measurement noise of each sonar sensor. As far as we know, this paper is novel in locating a target's 2D position based on heterogeneous sonobuoy sensors with low accuracy, considering the maximum sensing range of a sensor. The superiority (considering both time efficiency and location accuracy) of the proposed localization is verified by comparing it with other state-of-the-art localization methods using computer simulations.
Related Concept Videos
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:17
Common Leveling Mistakes and Errors
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:28
Field Application of Global Positioning System
 01:26
Errors in Global Positioning System