Related Experiment Video
Updated: Sep 21, 2025
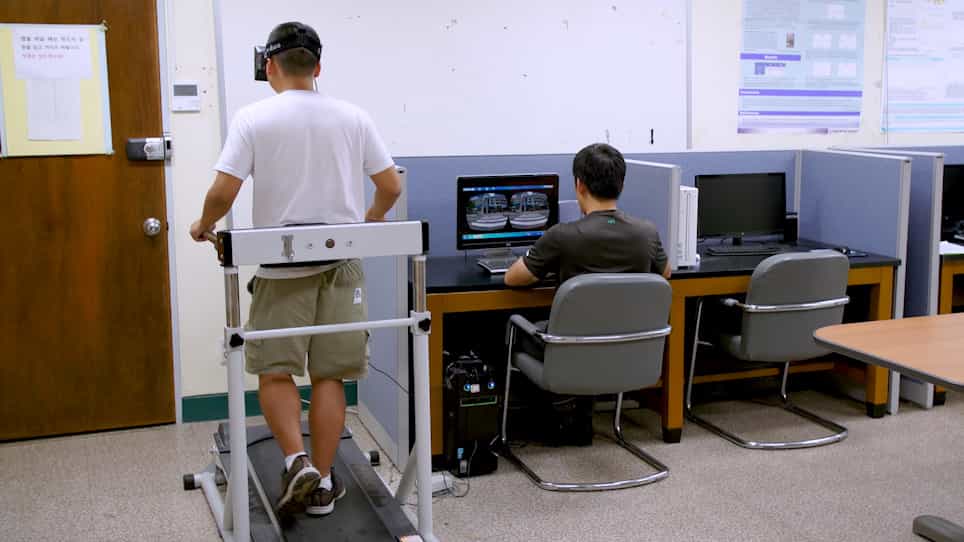

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
A longitudinal inter-vehicle distance controller application for autonomous vehicle platoons
Alex Gunagwera1, Aydin Tarik Zengin1
1Department of Computer Engineering, Istanbul Sabahattin Zaim University, Kucukcekmece, Istanbul, Turkey.

Abstract:
Autonomous vehicle platoons are a promising solution to road safety, efficient road utilization, emission reduction, among other problems facing today's transportation industry. However, consistently maintaining the desired inter-vehicle distance is one of the major problems facing autonomous vehicle platoons. In this study, we propose a proportional-integral-derivative (PID)-based cost-efficient algorithm to control the longitudinal inter-vehicle distance between successive members of an autonomous vehicle platoon. In our approach, calculations of the control algorithm are decentralized, and the data used in the control algorithm is obtained using one sensor per platoon member making the algorithm cost-efficient both computationally and financially. The proposed algorithm was implemented using the Robot Operating System (ROS) and applied to 3D vehicle models in simulations designed to mimic the natural environment in order to demonstrate and evaluate the suitability of the proposed algorithm for demanding and applicable scenarios. We performed meticulous simulations using the ROS framework in conjunction with the gazebo platform. In the proposed approach, the desired inter-vehicle distance between platoon members was successfully kept with a maximum absolute error of 5 m under any given scenario at any given time while maintaining platoon formation and ensuring that no collisions occur among platoon members.


Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:19
PID Controller
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:21
Distributed Loads: Problem Solving