Related Experiment Video
Updated: Sep 21, 2025
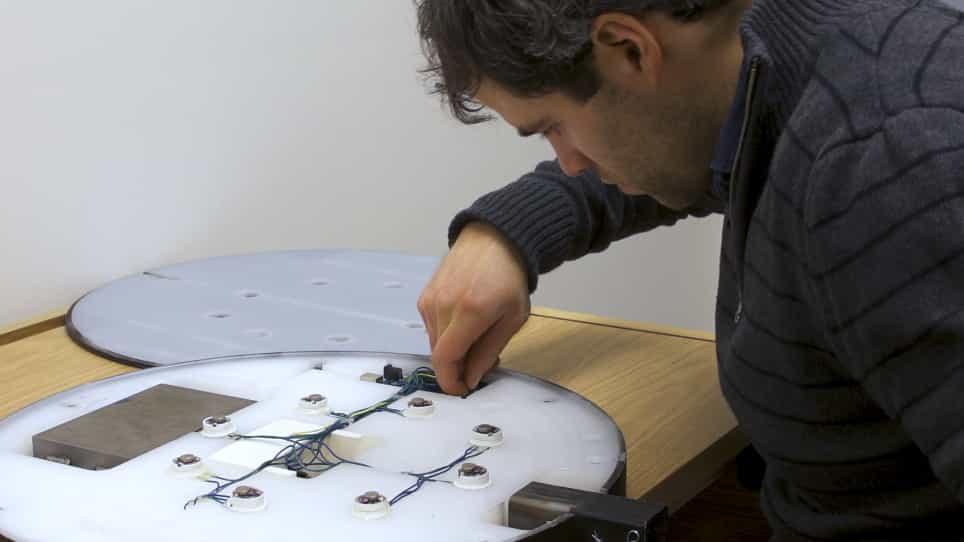

A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
Predictor feedback models for stick balancing with delay mismatch and sensory dead zones
Dalma J Nagy1, Tamás Insperger1
1Department of Applied Mechanics, Faculty of Mechanical Engineering, Budapest University of Technology and Economics, Műegyetem rkp. 3., H-1111 Budapest, Hungary.

Abstract:
Human stick balancing is investigated in terms of reaction time delay and sensory dead zones for position and velocity perception using a special combination of delayed state feedback and mismatched predictor feedback as a control model. The corresponding mathematical model is a delay-differential equation with event-driven switching in the control action. Due to the sensory dead zones, initial conditions of the actual state cannot always be provided for an internal-model-based prediction, which indicates that (1) perfect prediction is not possible and (2) the delay in the switching condition cannot be compensated. The imperfection of the predictor is described by the delay mismatch, which is treated as a lumped parameter that creates a transition between perfect predictor feedback (zero delay mismatch) and delayed state feedback (mismatch equal to switching delay). The maximum admissible switching delay (critical delay) is determined numerically based on a practical stabilizability concept. This critical delay is compared to a realistic reference value of 230 ms in order to assess the possible regions of the threshold values for position and velocity perception. The ratio of the angular position and angular velocity for 44 successful balancing trials by 8 human subjects was used to validate the numerical results. Comparison of actual human stick balancing data and numerical simulations based on the mismatched predictor feedback model provided a plausible range of parameters: position detection threshold 1°, velocity detection threshold between 4.24 and 9.35°/s, and delay mismatch around 100-150 ms.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:18
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...