
Model-Free Optimal Tracking Control of Nonlinear Input-Affine Discrete-Time Systems via an Iterative Deterministic

Abstract:
In this article, a novel model-free dynamic inversion-based Q-learning (DIQL) algorithm is proposed to solve the optimal tracking control (OTC) problem of unknown nonlinear input-affine discrete-time (DT) systems. Compared with the existing DIQL algorithm and the discount factor-based Q-learning (DFQL) algorithm, the proposed algorithm can eliminate the tracking error while ensuring that it is model-free and off-policy. First, a new deterministic Q-learning iterative scheme is presented, and based on this scheme, a model-based off-policy DIQL algorithm is designed. The advantage of this new scheme is that it can avoid the training of unusual data and improve data utilization, thereby saving computing resources. Simultaneously, the convergence and stability of the designed algorithm are analyzed, and the proof that adding probing noise into the behavior policy does not affect the convergence is presented. Then, by introducing neural networks (NNs), the model-free version of the designed algorithm is further proposed so that the OTC problem can be solved without any knowledge about the system dynamics. Finally, three simulation examples are given to demonstrate the effectiveness of the proposed algorithm.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
First Order Systems
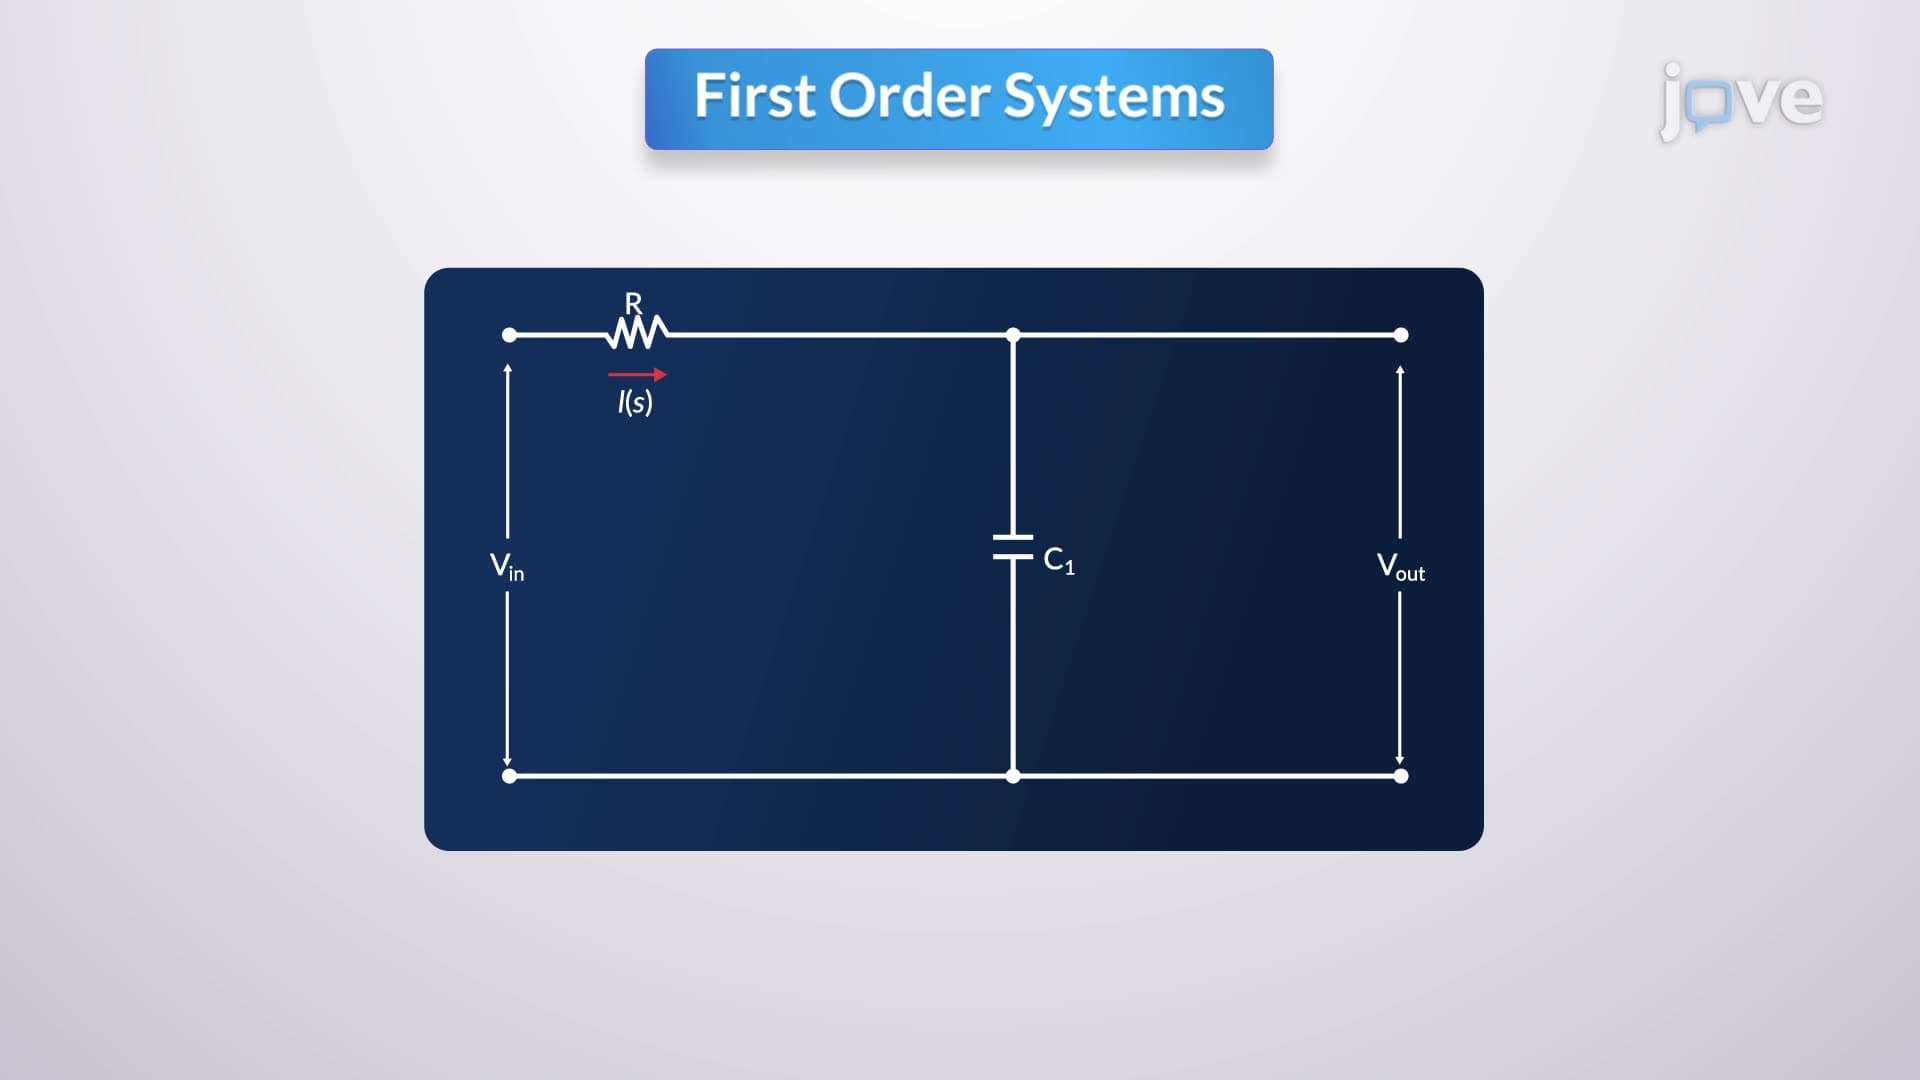
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:10
Control Systems
At the heart...