Related Experiment Video
Updated: Sep 20, 2025


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
The spring-mass model and other reductionist models of bipedal locomotion on inclines
Alessandro Maria Selvitella1,2, Kathleen Lois Foster3
1Department of Mathematical Sciences, Purdue University Fort Wayne, 2101 E. Coliseum Blvd, Fort Wayne, 46805, IN, USA.

Abstract:
The spring-mass model is a model of locomotion aimed at giving the essential mathematical laws of the trajectory of the center of mass of an animal during bouncing gaits, such as hopping (one-dimensional) and running (two-dimensional). This reductionist mechanical system has been extensively investigated for locomotion over horizontal surfaces, whereas it has been largely neglected on other ecologically relevant surfaces, including inclines. For example, how the degree of inclination impacts the dynamics of the center of mass of the spring-mass model has not been investigated thoroughly. In this work, we derive a mathematical model which extends the spring-mass model to inclined surfaces. Among our results, we derive an approximate solution of the system, assuming a small angular sweep of the limb and a small spring compression during stance, and show that this approximation is very accurate, especially for small inclinations of the ground. Furthermore, we derive theoretical bounds on the difference between the Lagrangian and Lagrange equations of the true and approximate system, and discuss locomotor stability questions of the approximate solutions. We test our models through a sensitivity analysis using parameters relevant to the locomotion of bipedal animals (quail, pheasant, guinea fowl, turkey, ostrich, and humans) and compare our approximate solution to the numerically derived solution of the exact system. We compare the two-dimensional spring-mass model on inclines with the one-dimensional spring-mass model to which it reduces under the limit of no horizontal velocity; we compare the two-dimensional spring-mass model on inclines with the inverted-pendulum model on inclines towards which it converges in the case of high stiffness-to-mass ratio. We include comparisons with historically prevalent no-gravity approximations of these models, as well. The insights we have gleaned through all these comparisons and the ability of our approximation to replicate some of the kinematic changes observed in animals moving on different inclines (e.g. reduction in vertical oscillation of the center of mass and decreased stride length) underlines the valuable and reasonable contributions that very simple, reductionist models, like the spring-mass model, can provide.


Related Concept Videos
 01:17
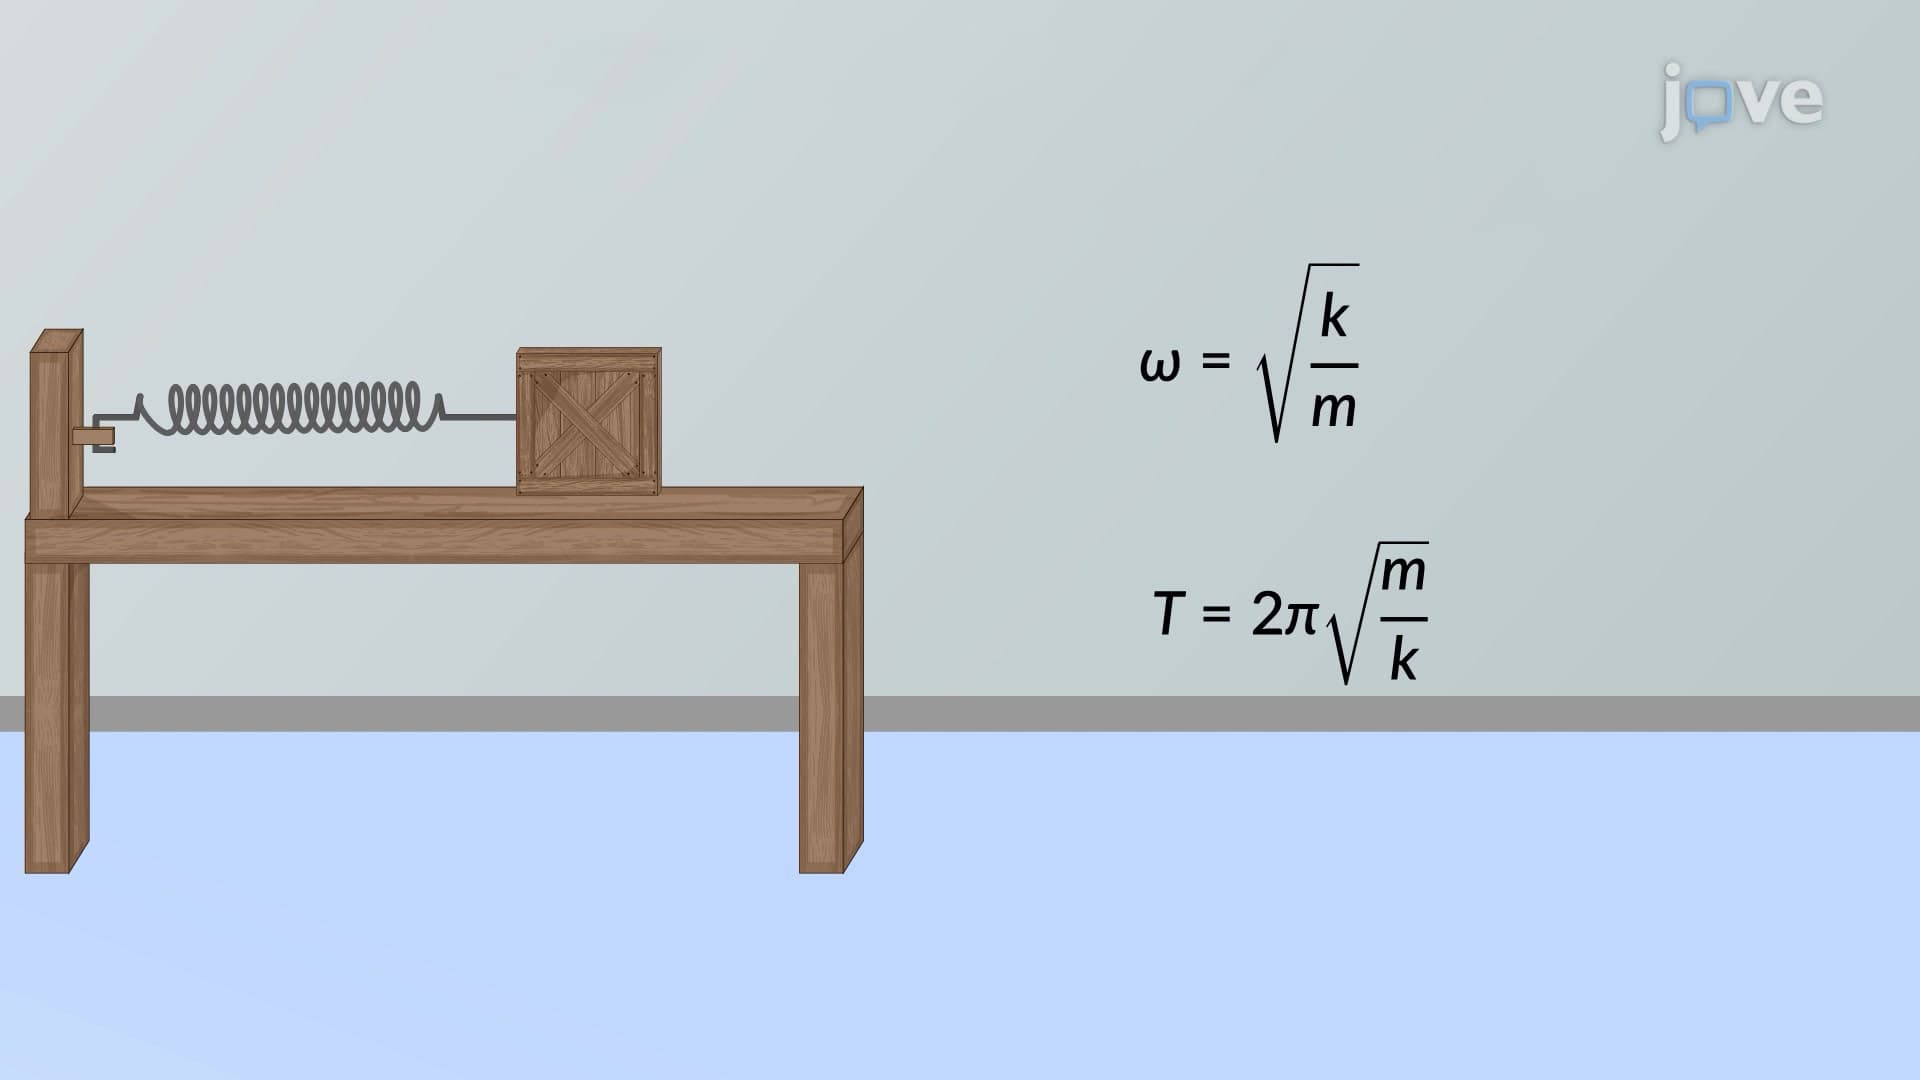
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:09
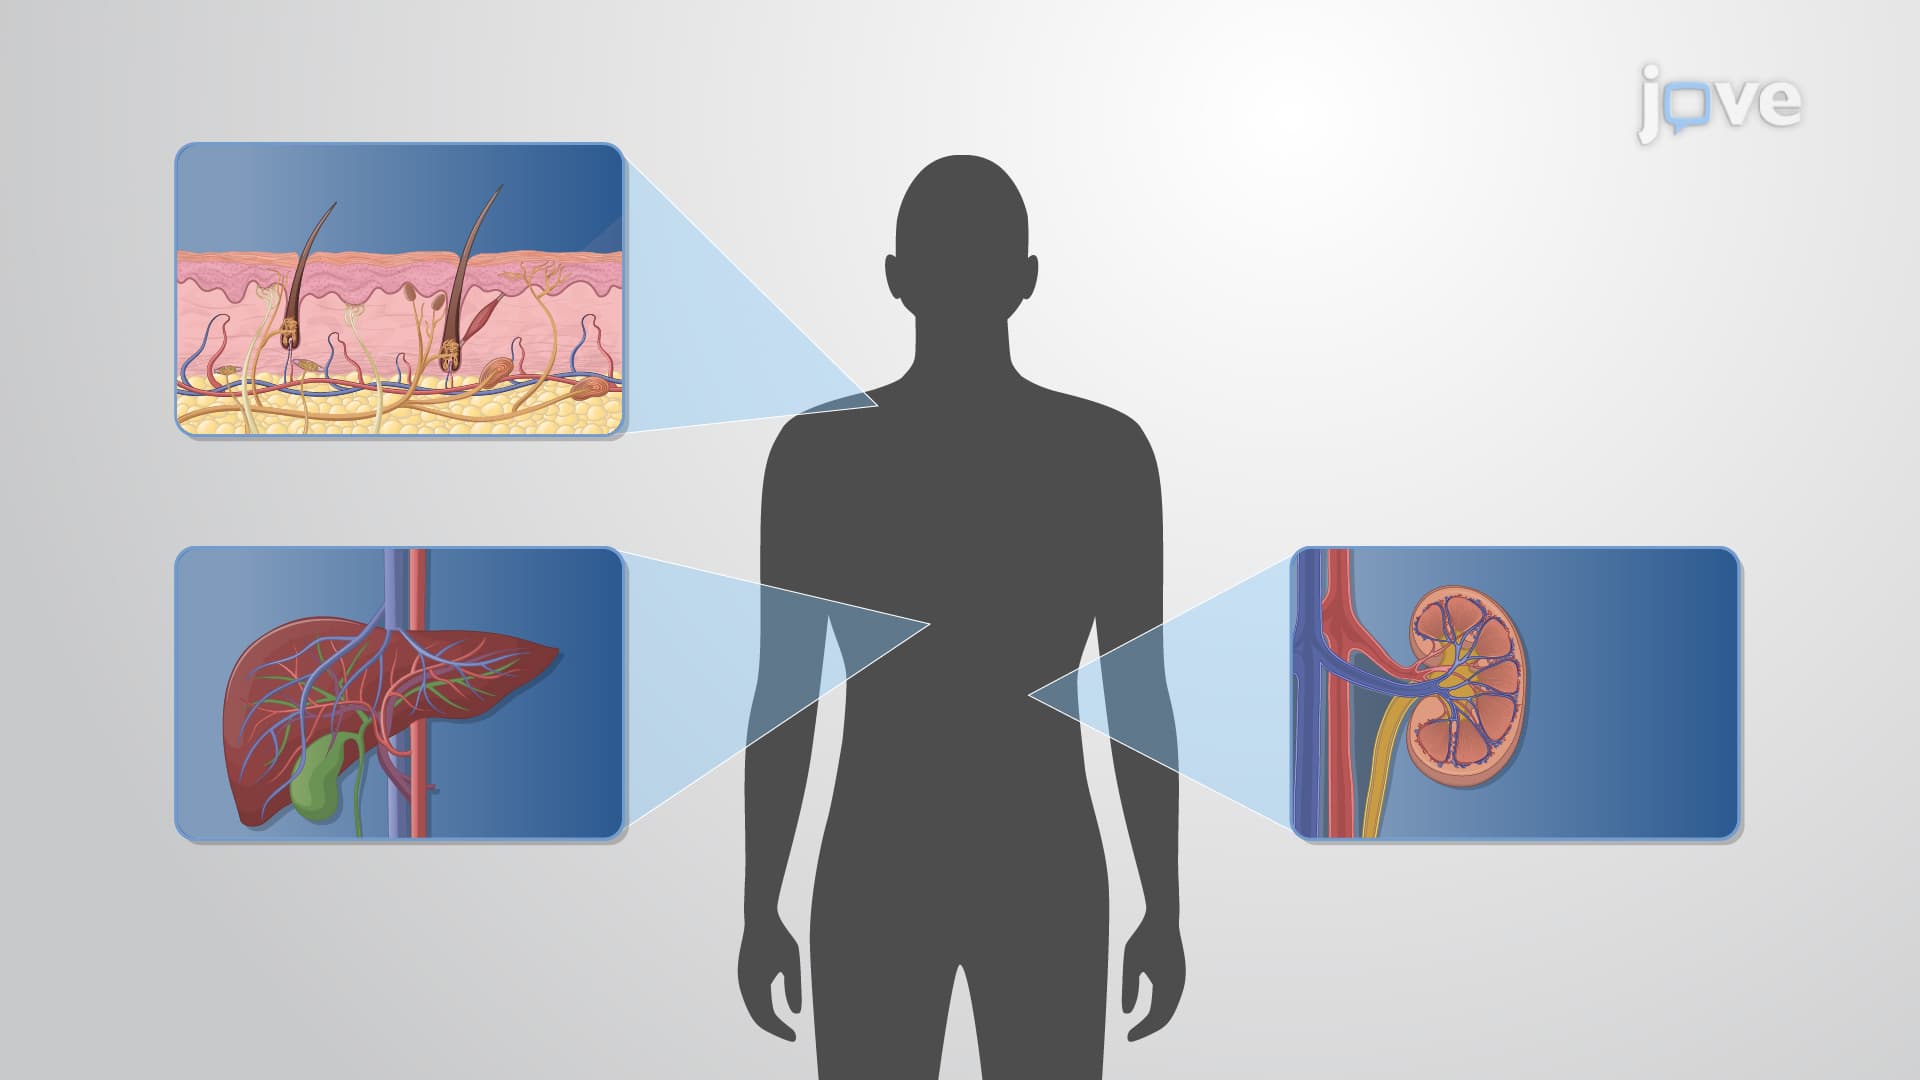
Clearance Models: Physiological Models
The organ's clearance rate depends on the blood flow to the organ and the extraction ratio (E). The extraction ratio describes the organ's...
 01:18
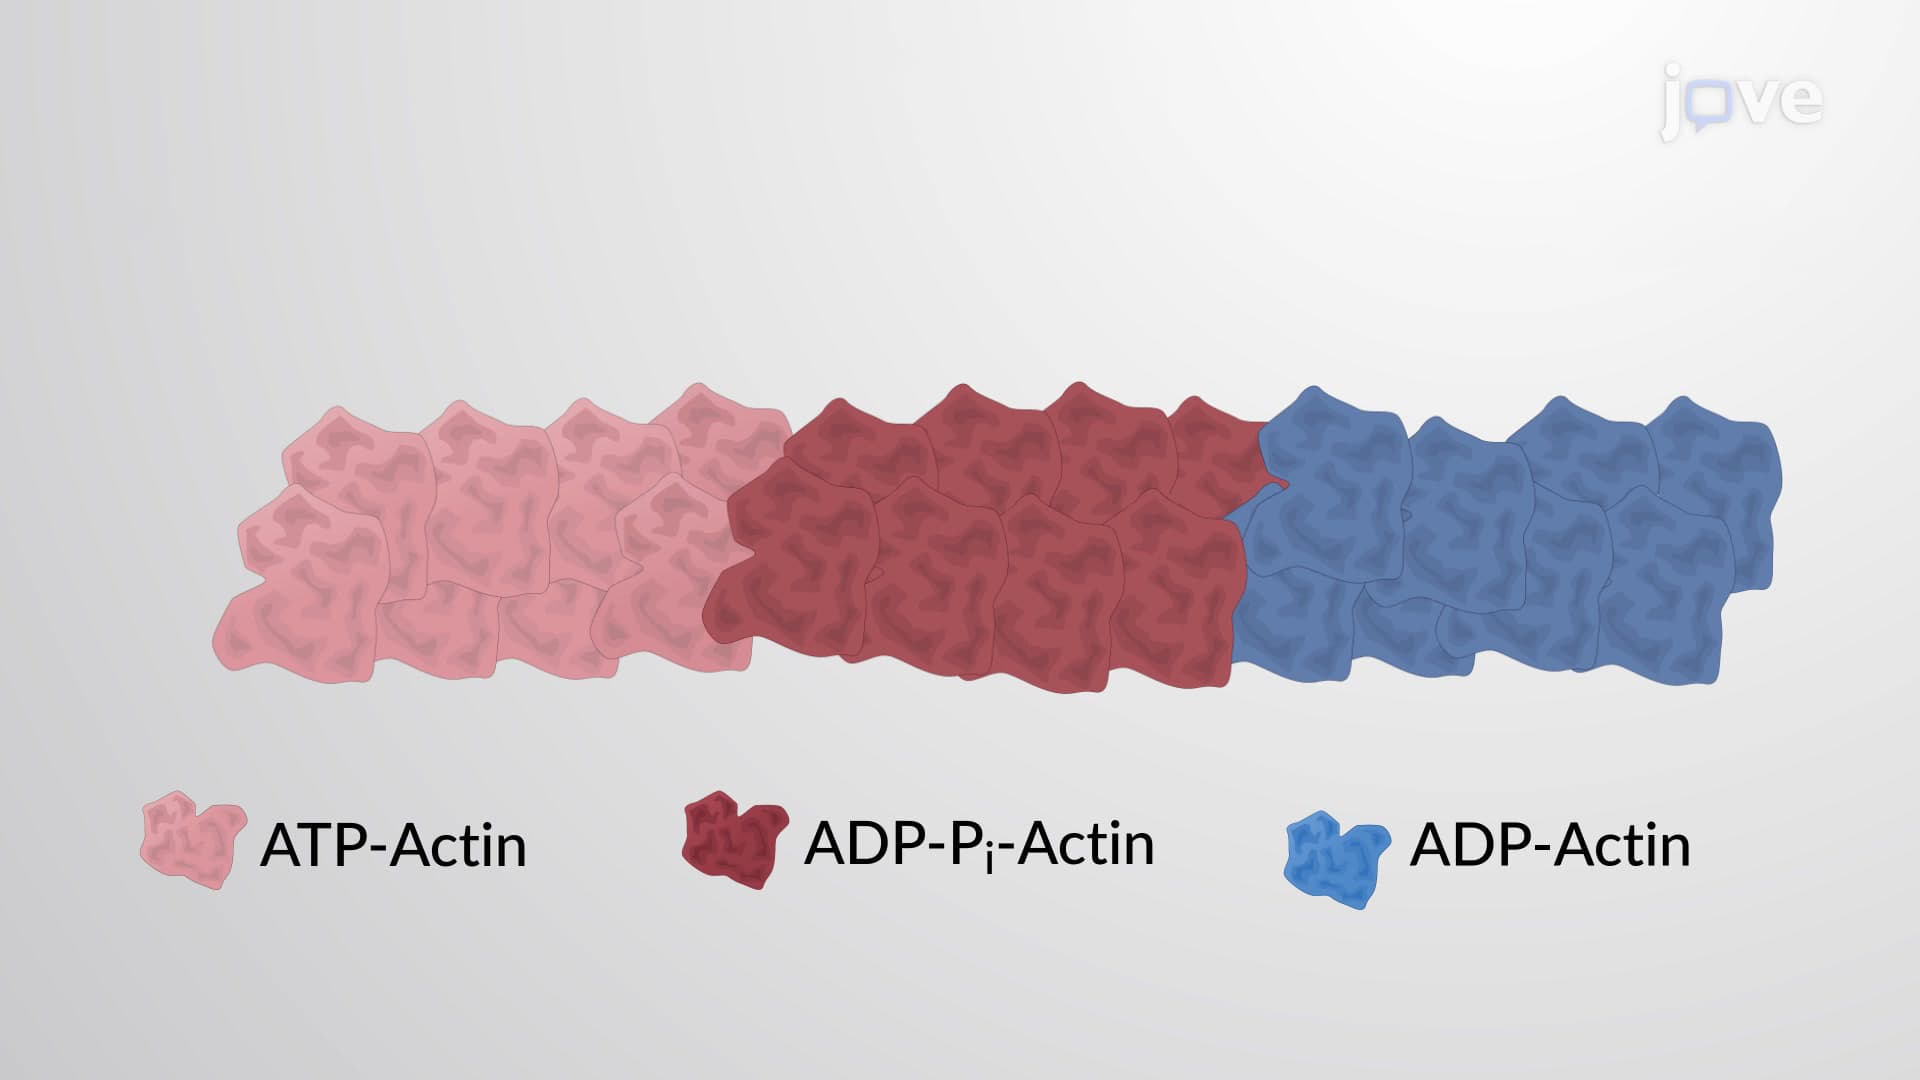
Actin Treadmilling
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:17
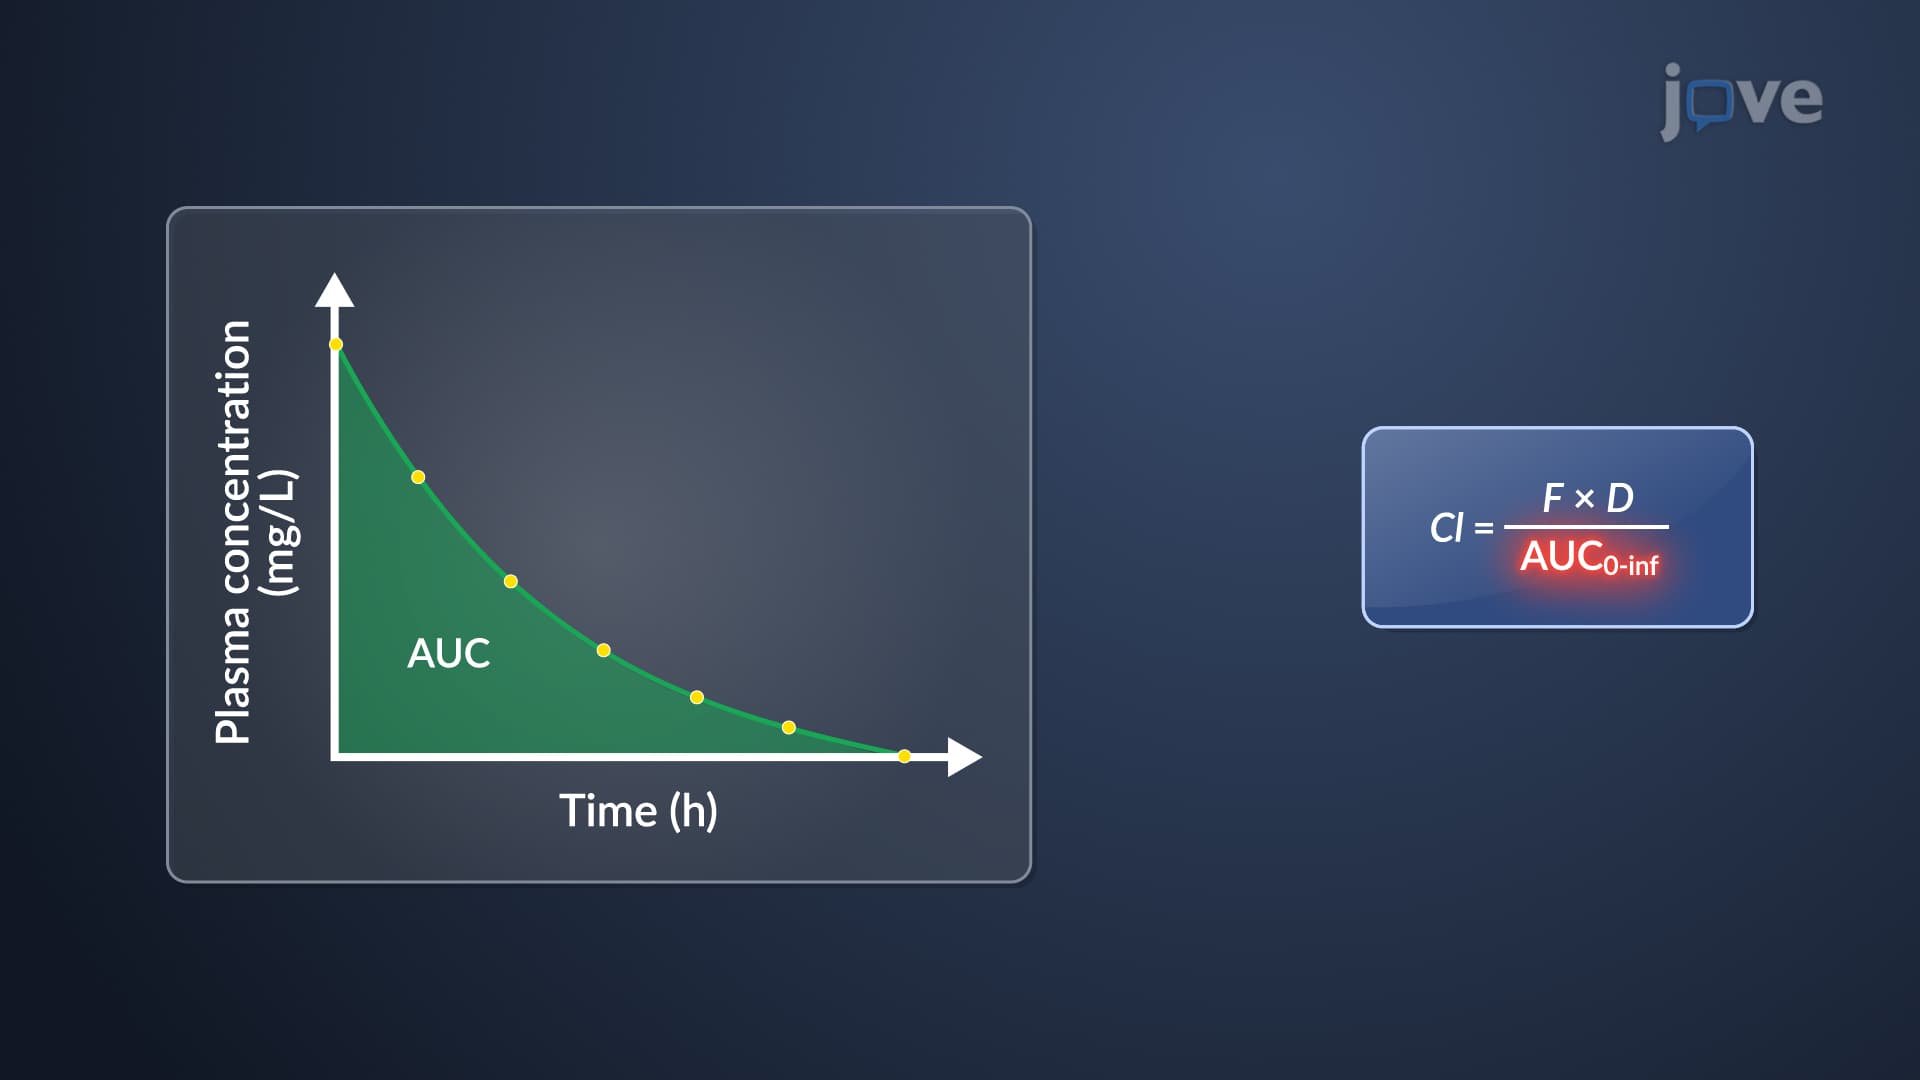
Clearance Models: Noncompartmental Models
The noncompartmental approach capitalizes on extensive sampling data, correlating the volume of distribution to systemic exposure and the administered dosage. This method enables...
 01:23
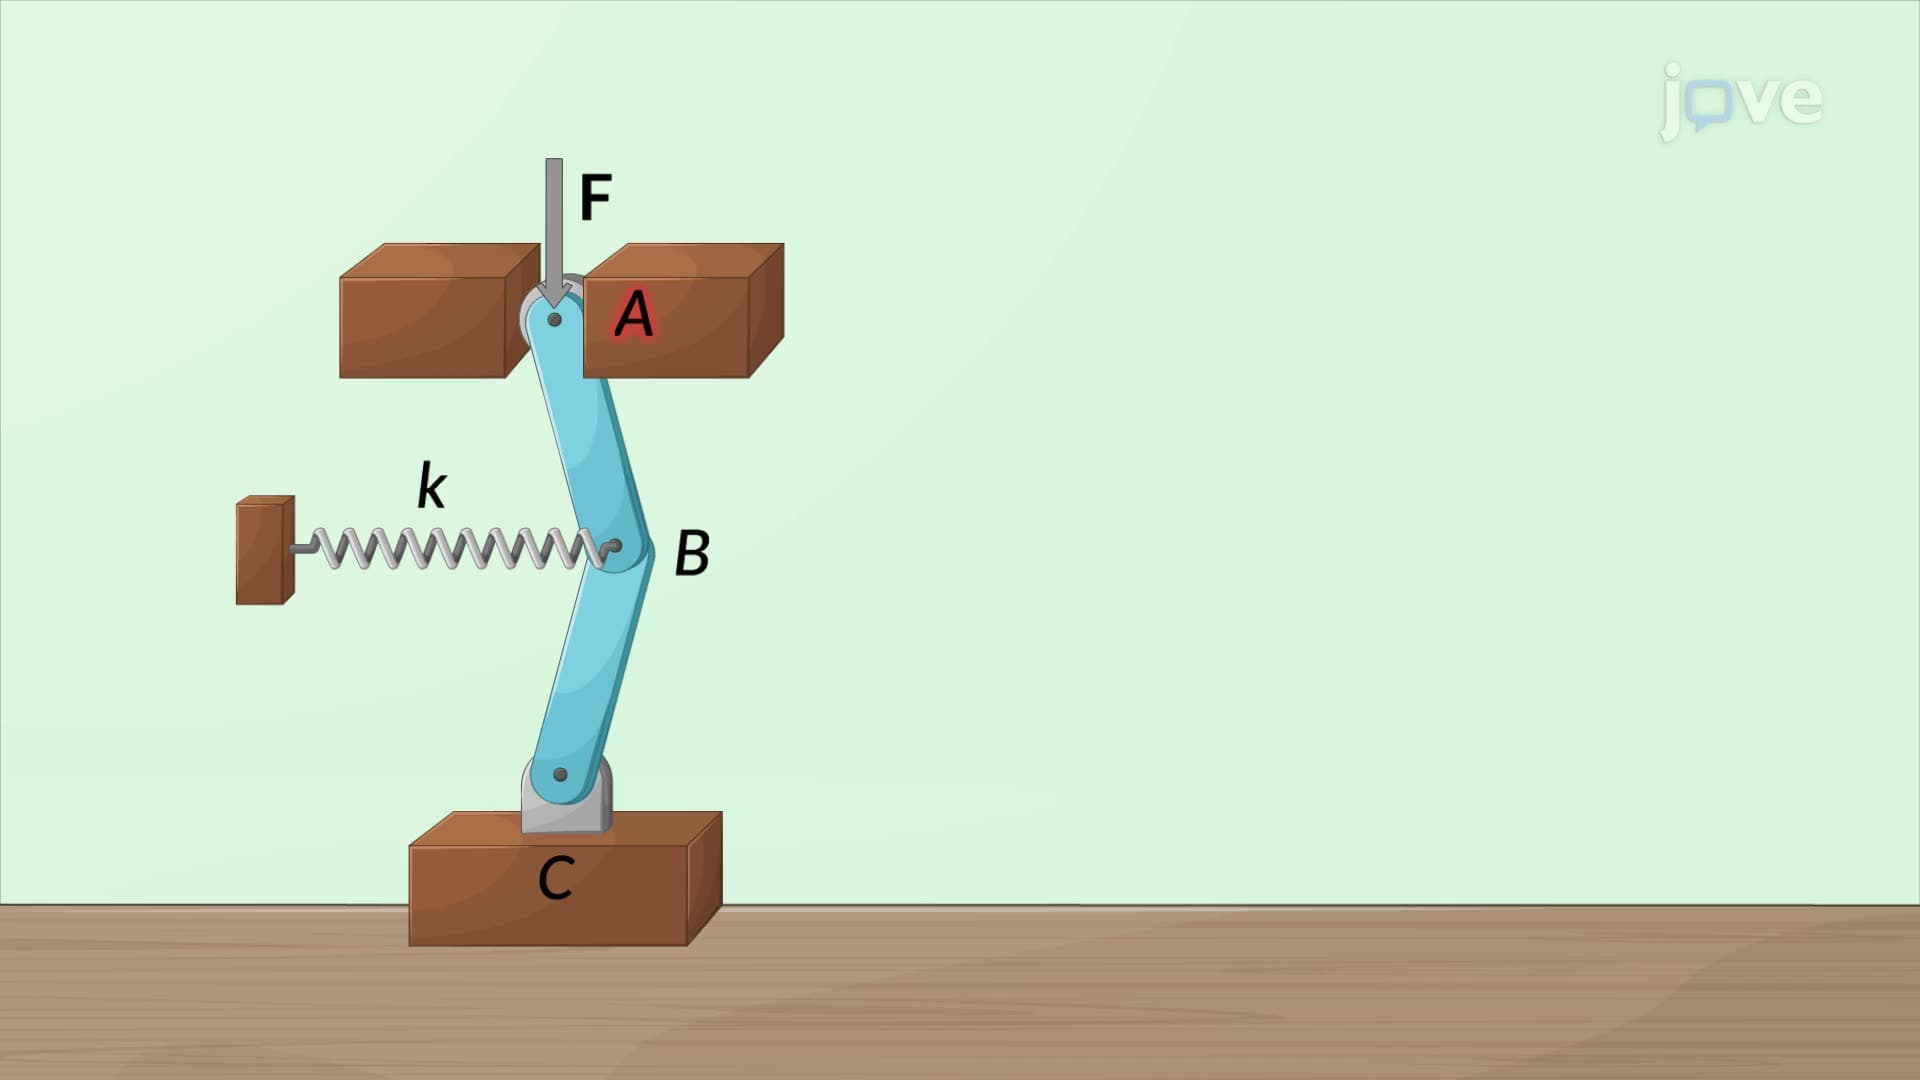
Euler's Formula to Columns: Problem Solving
The system comprises two vertical rigid bars, AB and BC,...