Related Experiment Video
Updated: Sep 7, 2025

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Can a Spine Robot Be More Efficient and Less Expensive While Maintaining Accuracy?
Mohamed A R Soliman1,2,3, John Pollina1,2, Kornelis Poelstra4
1Department of Neurosurgery, Jacobs School of Medicine and Biomedical Sciences at University at Buffalo, Buffalo, NY, USA.

Background:
Spinal surgical robots are in the early phases of development and adoption. These systems need to be easier to use, less costly, and more workflow-efficient.
Methods:
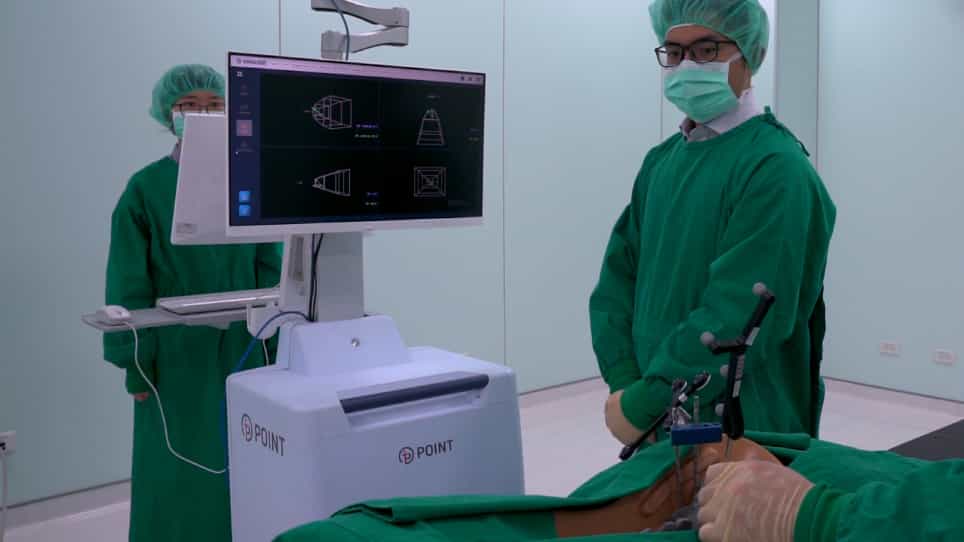
A portable, operating room table-mounted spine robot and camera system are described. Accuracy and workflow efficiency were assessed in comparison to another commonly utilized spinal robotic system.
Results:
For the surgical task of inserting 4 pedicle screws into 2 adjacent lumbar vertebrae, equivalent accuracy was seen with both systems. The new robotic system was more efficient in terms of total procedure time, system setup time, and screw planning to in-position time (p<0.05).
Conclusions:
Spinal robotic systems can be more efficient and less expensive while maintaining accuracy.
Clinical Relevance:
Spinal robots are being increasingly utilized in clinical practice. Lowering the cost of these systems and increasing their workflow efficiency should help patients and spine surgeons alike.