Related Experiment Video
Updated: Jun 27, 2026
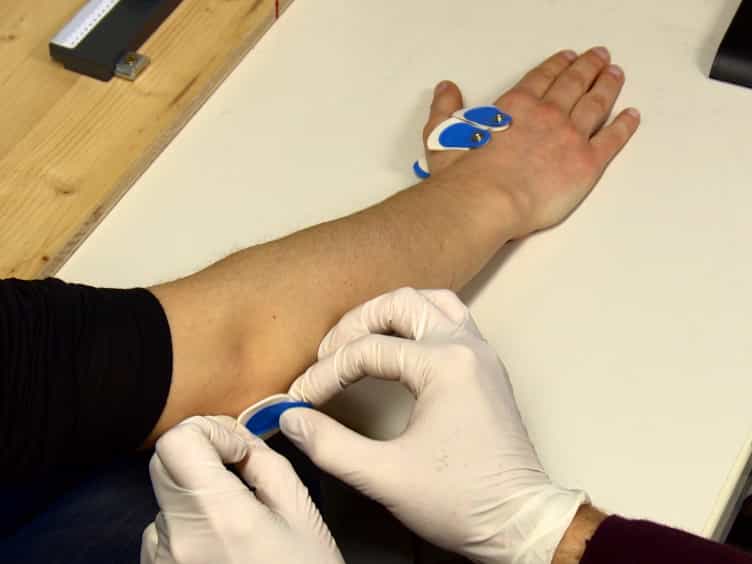

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
A cable driven robotic palpation system with contact force sensing based on cable tension observation
Chikweto Francis1, Taiga Sato1, Takeshi Okuyama2
1Department of Biomedical Engineering, Graduate School of Biomedical Engineering, Tohoku University, Sendai, Japan.

Background:
Prostate Cancer screening based on manual palpation is subjective. Robotic palpation systems can objectively acquire stiffness conditions of the prostate.
Methods:
A 2DoF cable driven robotic system for prostate palpation is proposed. An indirect method to estimate the contact force based on cable tension observation is presented. Kinematic models and a joint angle estimation method to determine the tip position of the probe are derived. Positioning accuracy was verified using an optical marker tracking system and by displacement measurement, respectively. The contact force estimation method was validated on silicone phantom samples.
Results:
A good consistence between the estimated and measured contact force was observed. The contact force was correlated with the elastic modulus of each silicone phantom. There was also a good agreement between the theoretical and the measured tip position.
Conclusion:
In the proposed palpation system, the indirect contact force estimation method is viable and holds potential for the stiffness assessment of the prostate. The tip position vital for palpation can be determined through estimated joint angles.
More Related Videos


Related Concept Videos
 01:30
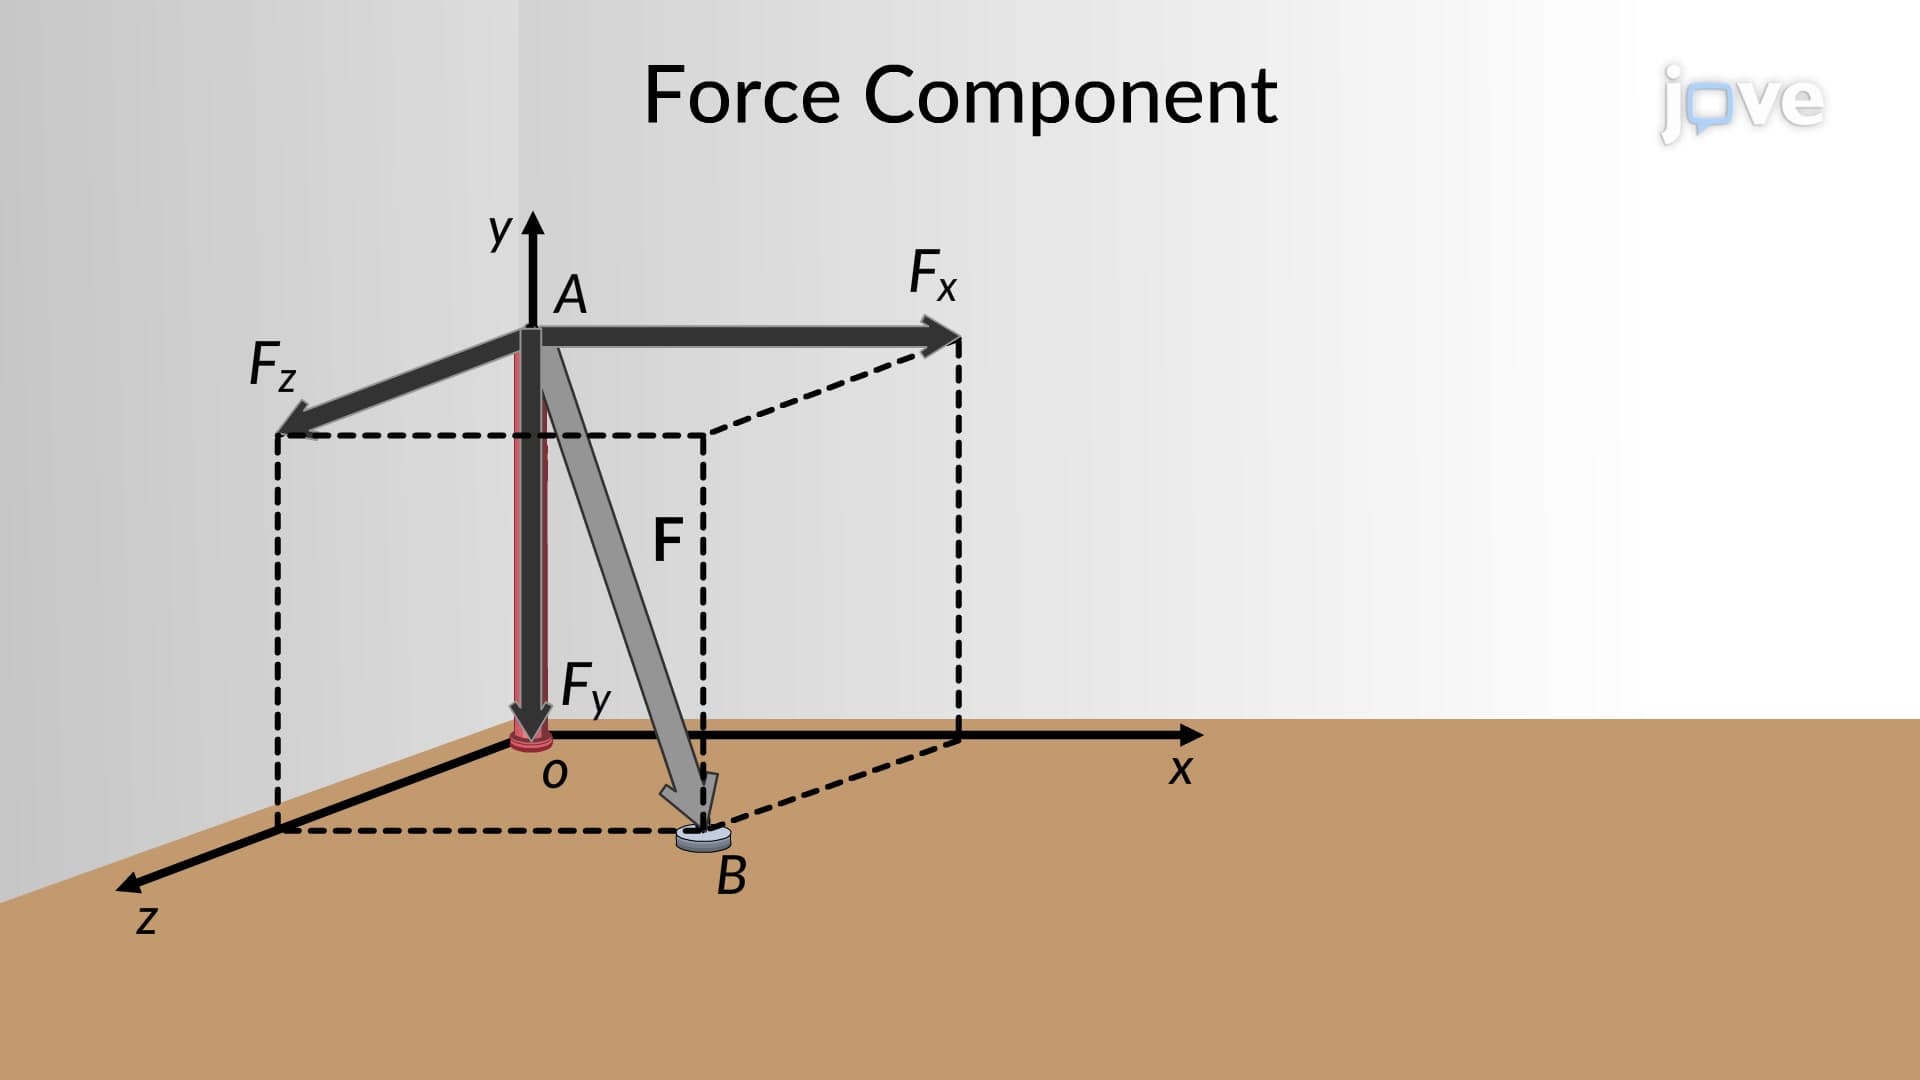
Principle of Moments: Problem Solving
One such scenario involves a pole placed in a three-dimensional system with a cable attached. When a tension is applied to the cable, the moment about the z-axis passing through...
 01:28
Cable Subjected to Concentrated Loads
 01:24
Cable Subjected to a Distributed Load
 01:13
Cable Subjected to Its Own Weight
A generalized loading function is employed to analyze a cable subjected to its own weight. This function considers the force acting along the cable's arc length rather than its projected length, providing a more accurate...
 01:29
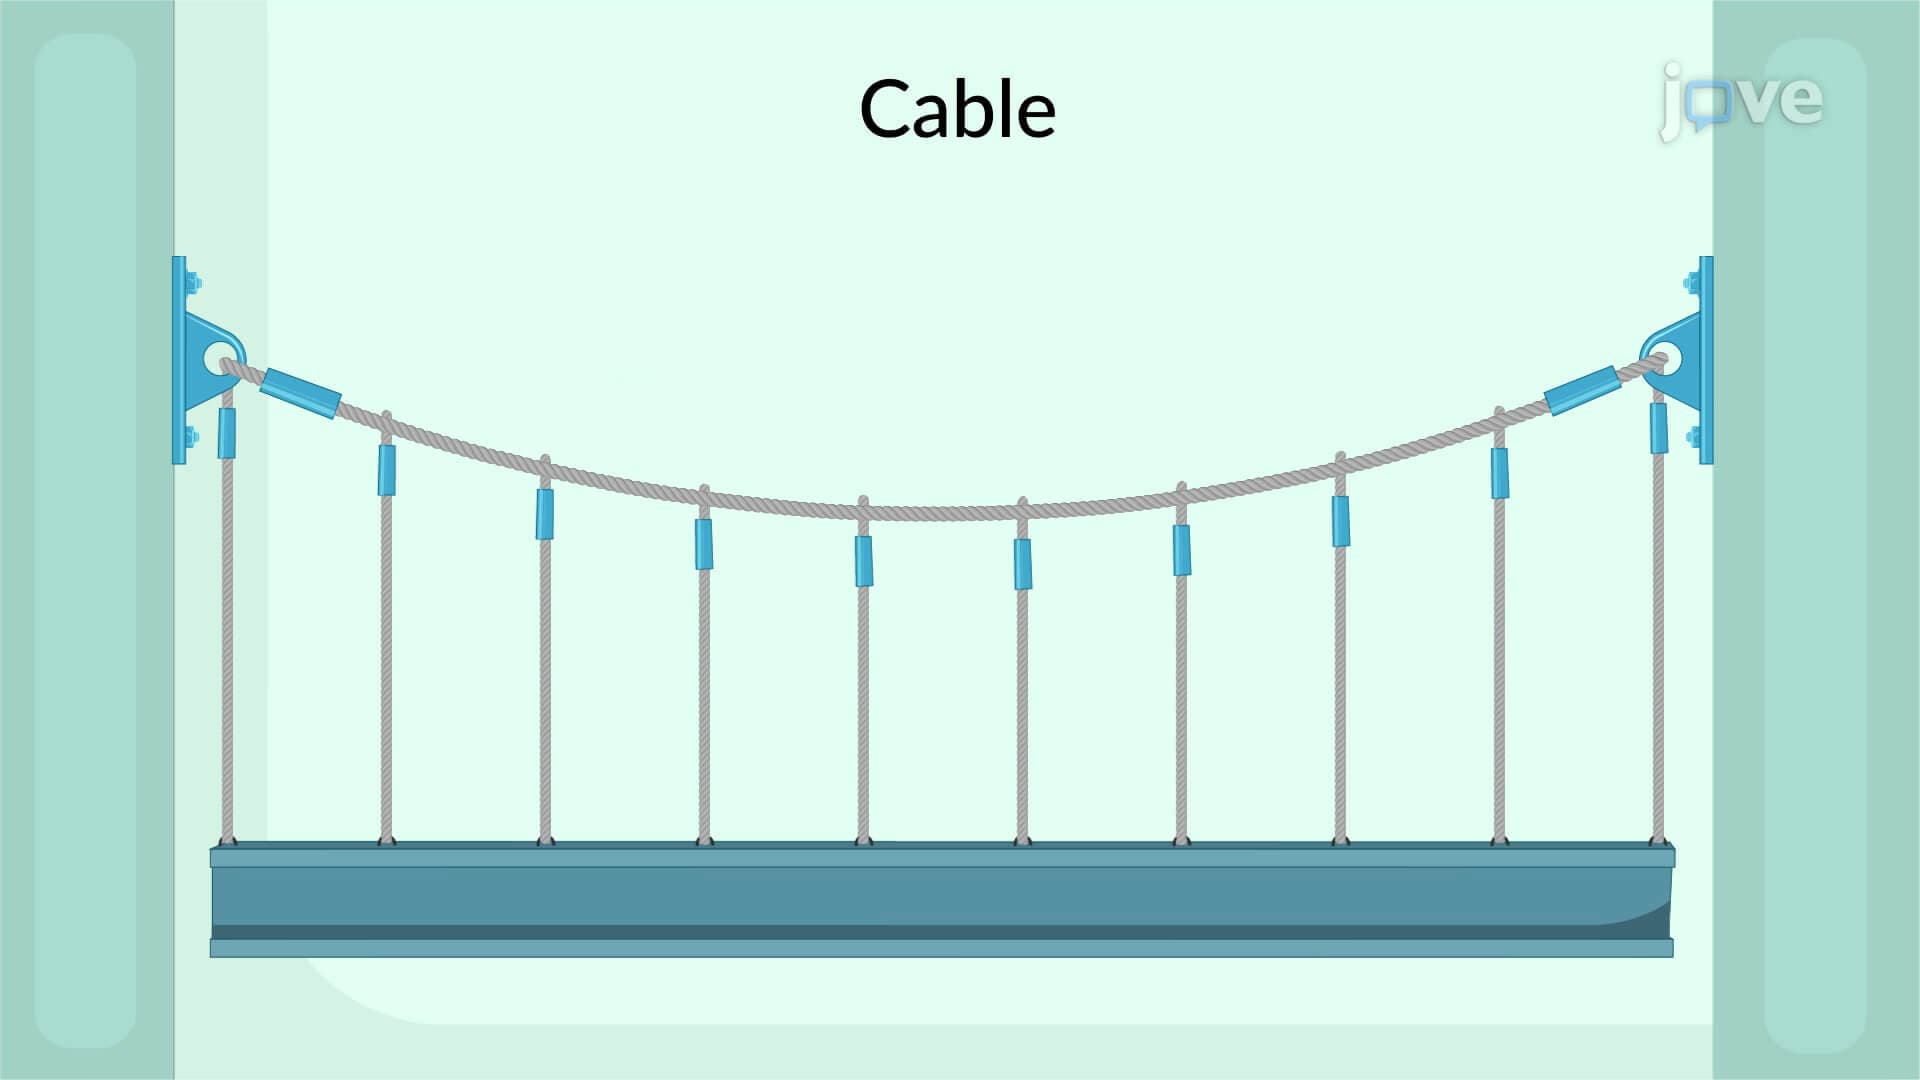
Cable: Problem Solving
 01:10
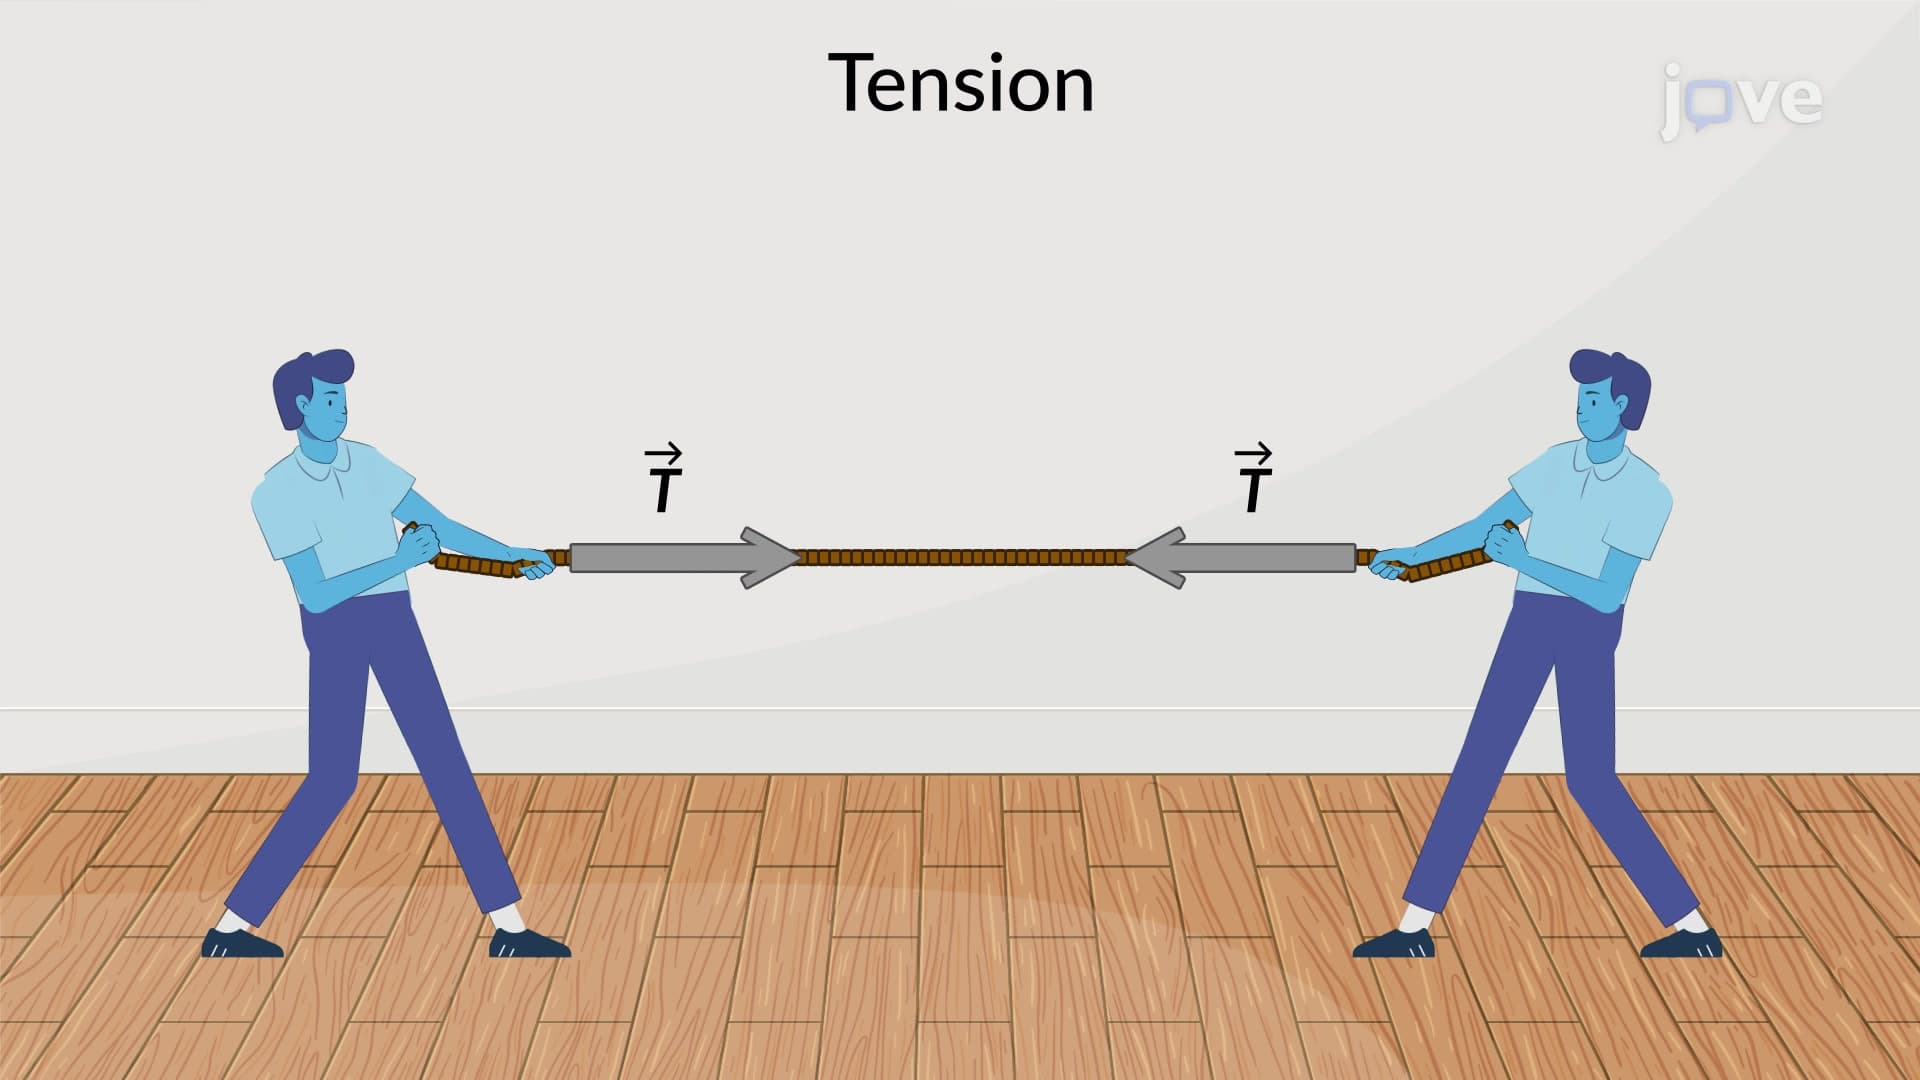
Tension