Related Experiment Video
Updated: Sep 6, 2025

Time-dependent Increase in the Network Response to the Stimulation of Neuronal Cell Cultures on Micro-electrode Arrays
Published on: May 29, 2017
Exponential Stability of Impulsive Timescale-Type Nonautonomous Neural Networks With Discrete Time-Varying and

Abstract:
Global exponential stability (GES) for impulsive timescale-type nonautonomous neural networks (ITNNNs) with mixed delays is investigated in this article. Discrete time-varying and infinite distributed delays (DTVIDDs) are taken into consideration. First, an improved timescale-type Halanay inequality is proven by timescale theory. Second, several algebraic inequality criteria are demonstrated by constructing impulse-dependent functions and utilizing timescale analytical techniques. Different from the published works, the theoretical results can be applied to GES for ITNNNs and impulsive stabilization design of timescale-type nonautonomous neural networks (TNNNs) with mixed delays. The improved timescale-type Halanay inequality considers time-varying coefficients and DTVIDDs, which improves and extends some existing ones. GES criteria for ITNNNs cover the stability conditions of discrete-time nonautonomous neural networks (NNs) and continuous-time ones, and these theoretical results hold for NNs with discrete-continuous dynamics. The effectiveness of our new theoretical results is verified by two numerical examples in the end.

Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:31
Classification of Systems-II
 01:21
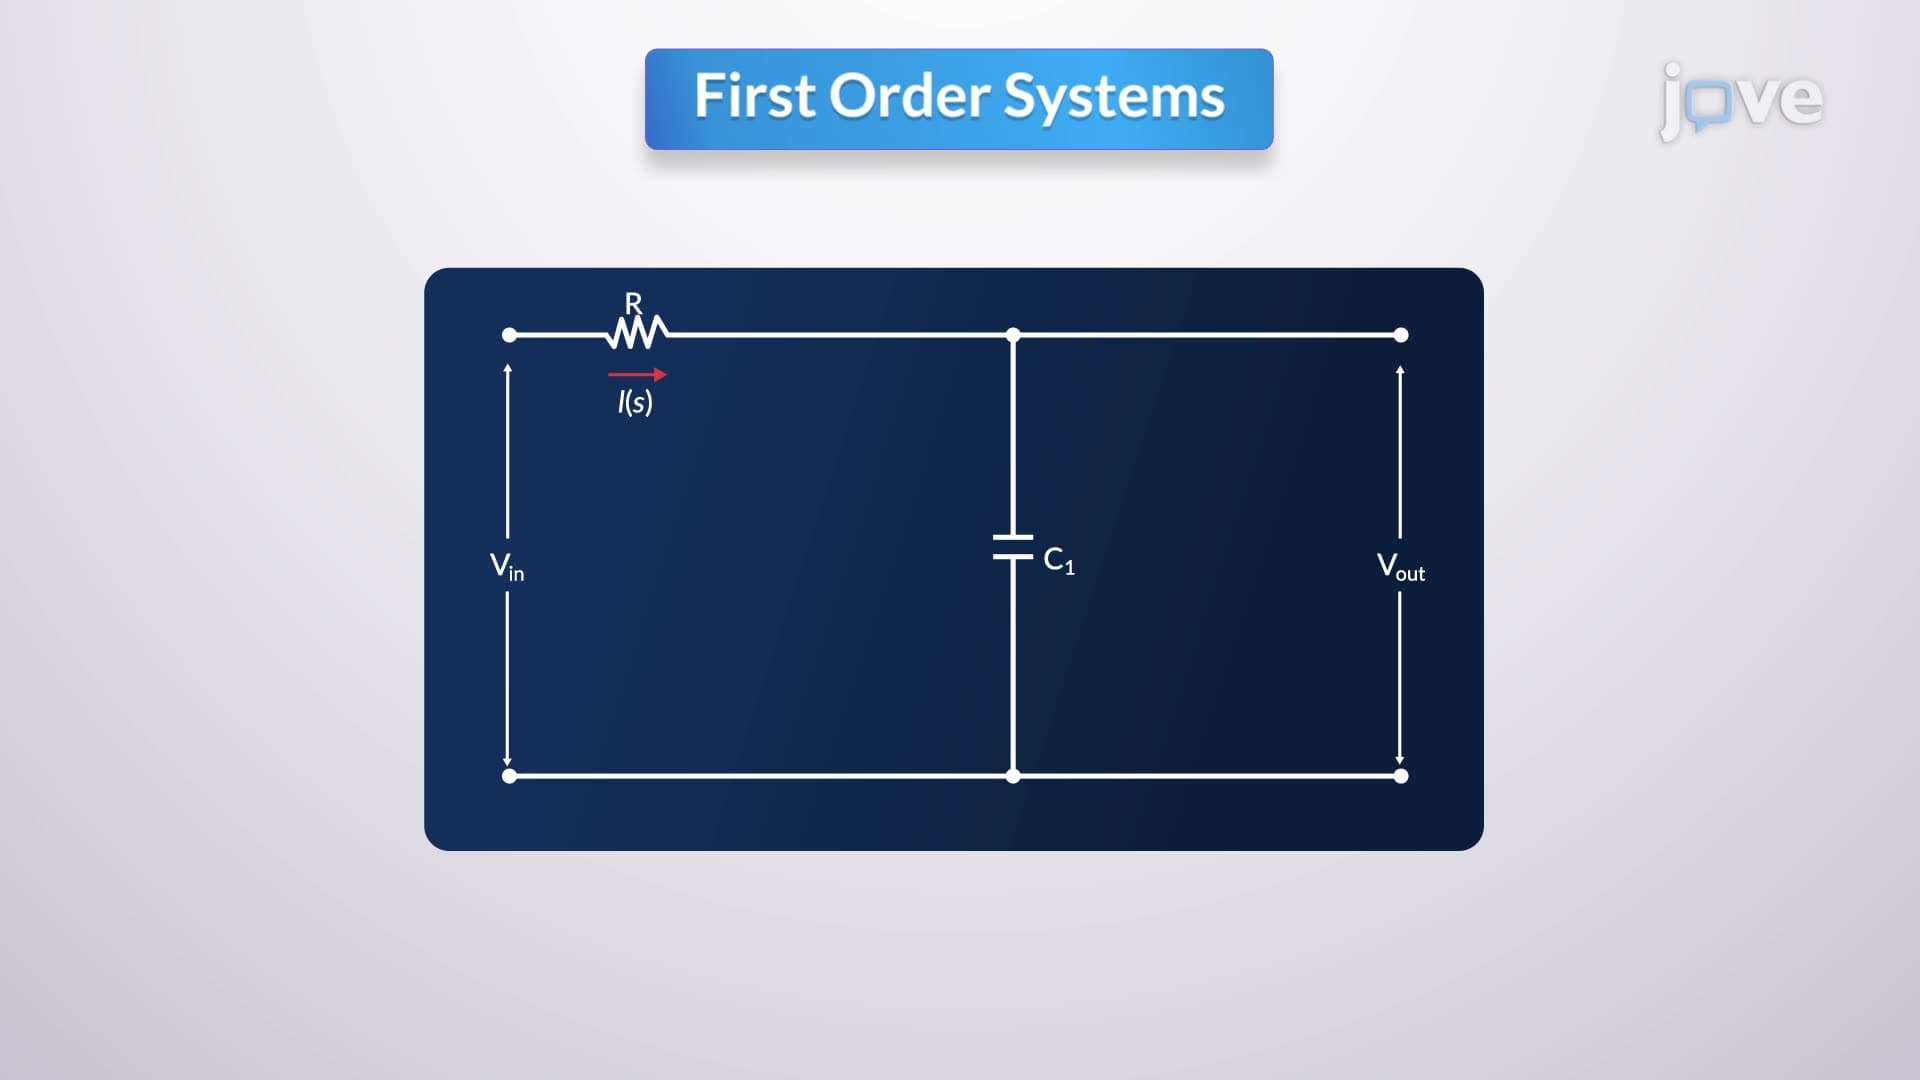
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:28
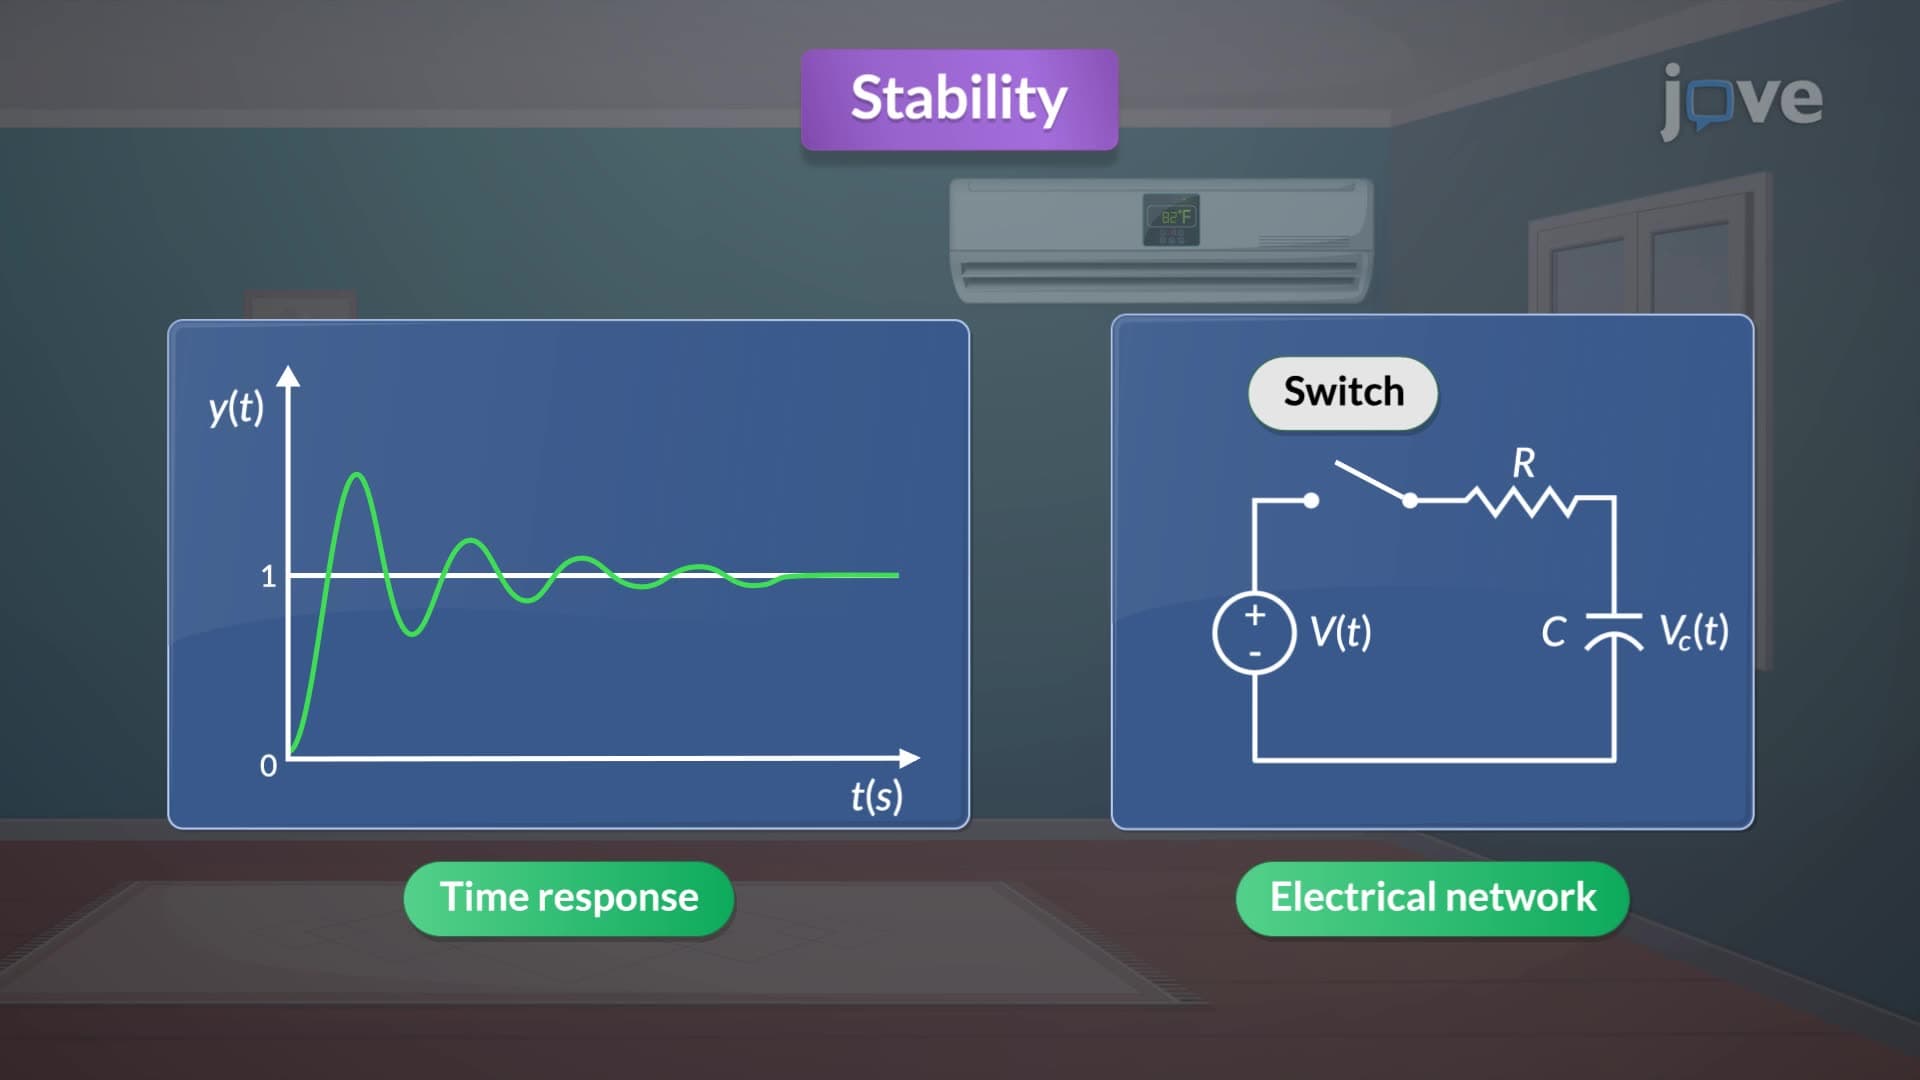
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:16
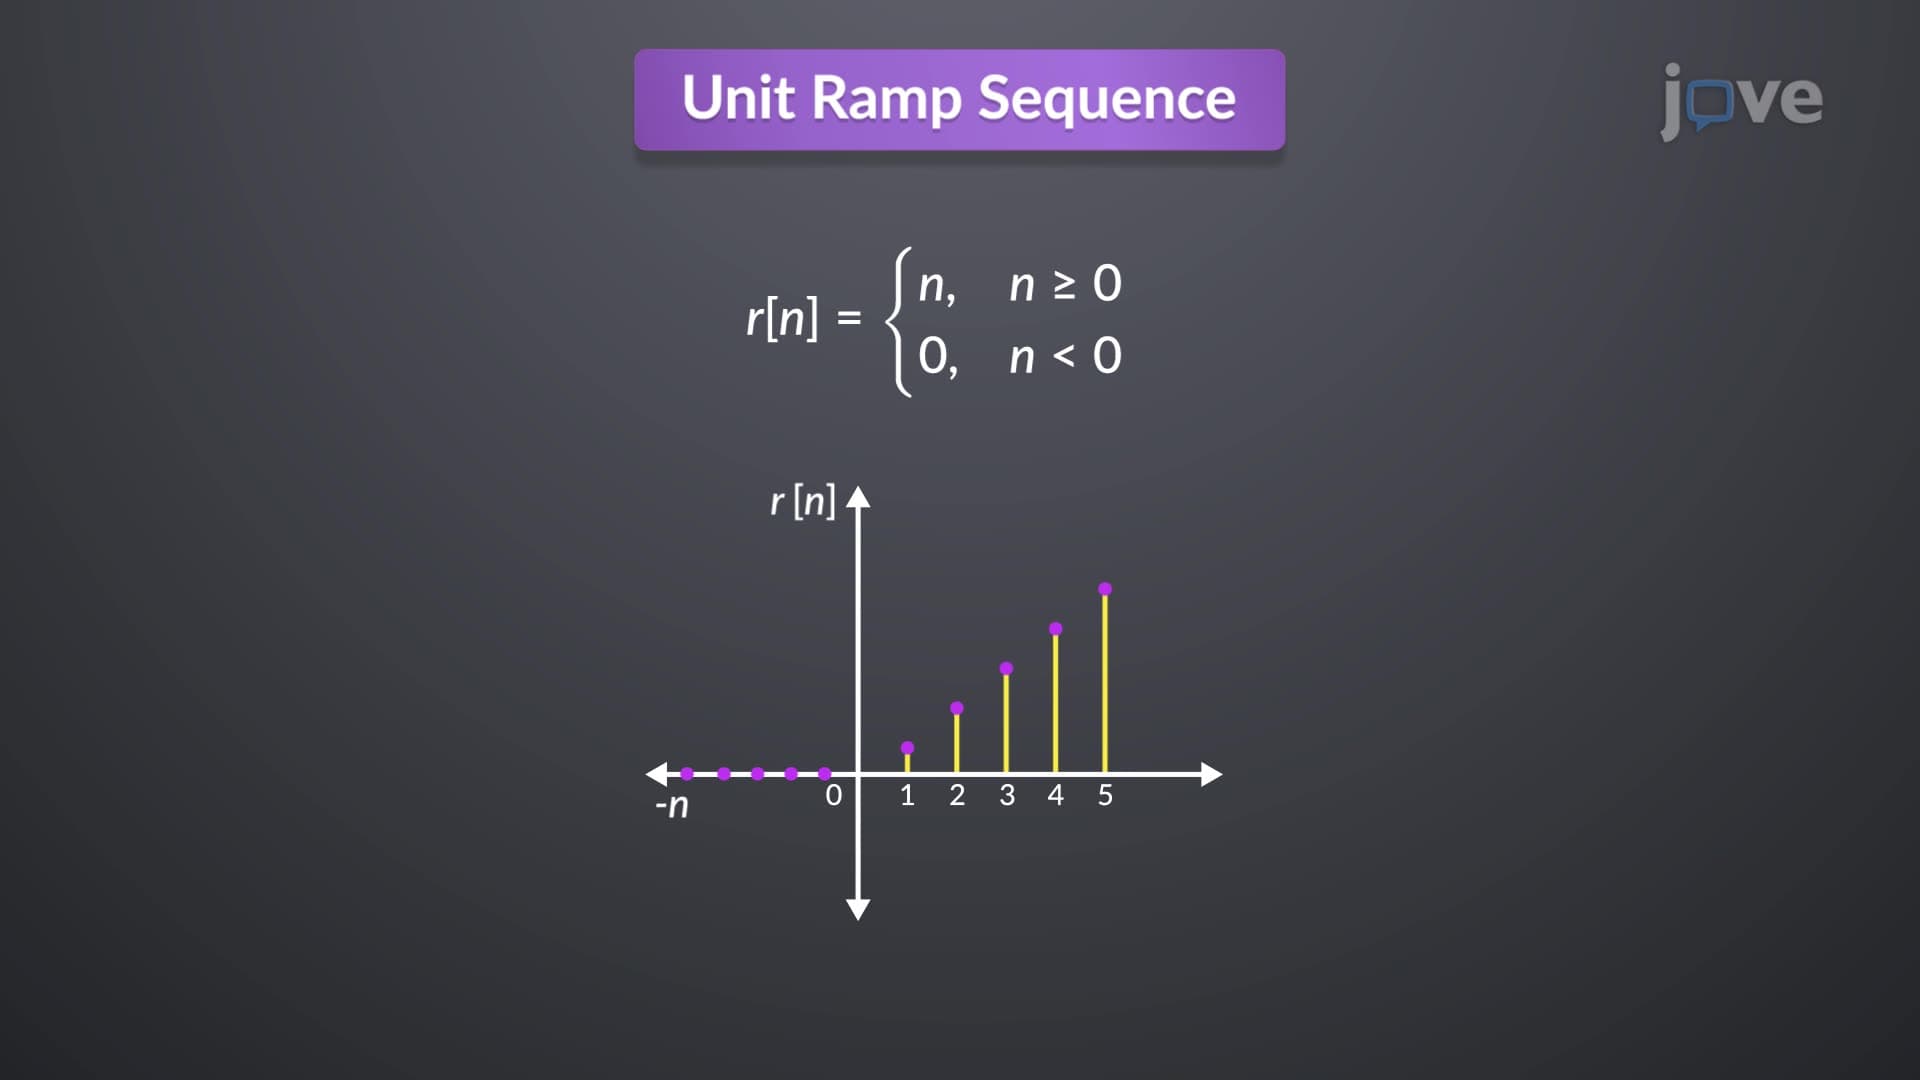
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...