Related Experiment Video
Updated: Sep 6, 2025


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Comparison of kinematic parameters of children gait obtained by inverse and direct models
Jurgita Ziziene1, Kristina Daunoraviciene1, Giedre Juskeniene2
1Department of Biomechanical Engineering, Vilnius Gediminas Technical University, Vilnius, Lithuania.

Abstract:
The purpose of this study is to compare differences between kinematic parameters of pediatric gait obtained by direct kinematics (DK) (Plug-in-Gait) and inverse kinematics (IK) (AnyBody) models. Seventeen healthy children participated in this study. Both lower extremities were examined using a Vicon 8-camera motion capture system and a force plate. Angles of the hip, knee, and ankle joints were obtained based on DK and IK models, and ranges of motion (ROMs) were identified from them. The standard error of measurement, root-mean-squared error, correlation r, and magnitude-phase (MP) metrics were calculated to compare differences between the models' outcomes. The determined standard error of measurement between ROMs from the DK and IK models ranged from 0.34° to 0.58°. A significant difference was found in the ROMs with the exception of the left hip's internal/external rotation. The mean RMSE of all joints' amplitudes exceeded the clinical significance limit and was 13.6 ± 4.0°. The best curve angles matching nature were found in the sagittal plane, where r was 0.79 to 0.83 and MP metrics were 0.05 to 0.30. The kinematic parameters of pediatric gait obtained by IK and DK differ significantly. Preferably, all of the results obtained by DK must be validated/verified by IK, in order to achieve a more accurate functional assessment of the individual. Furthermore, the use of IK expands the capabilities of gait analysis and allows for kinetic characterisation.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
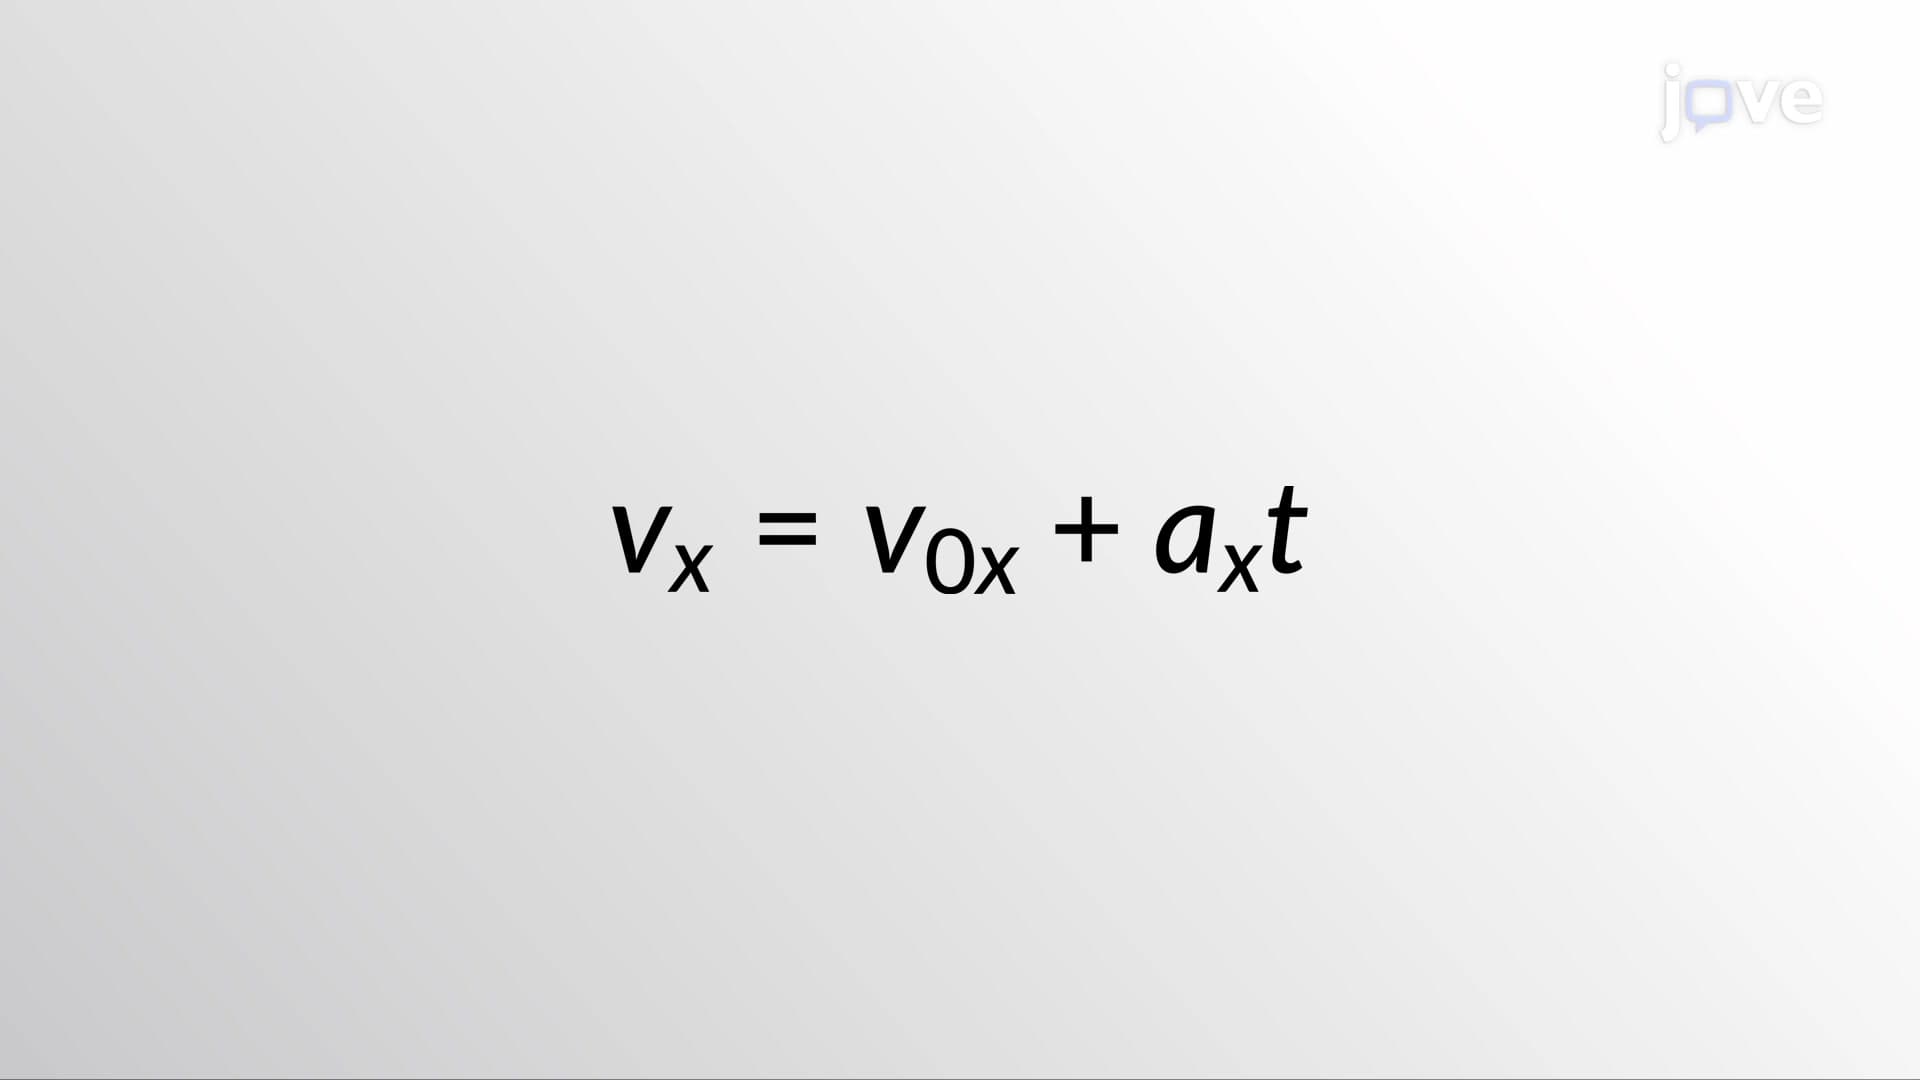 01:26
Kinematic Equations - I
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:10
Relative Motion Analysis - Acceleration