Related Experiment Video
Updated: Sep 6, 2025
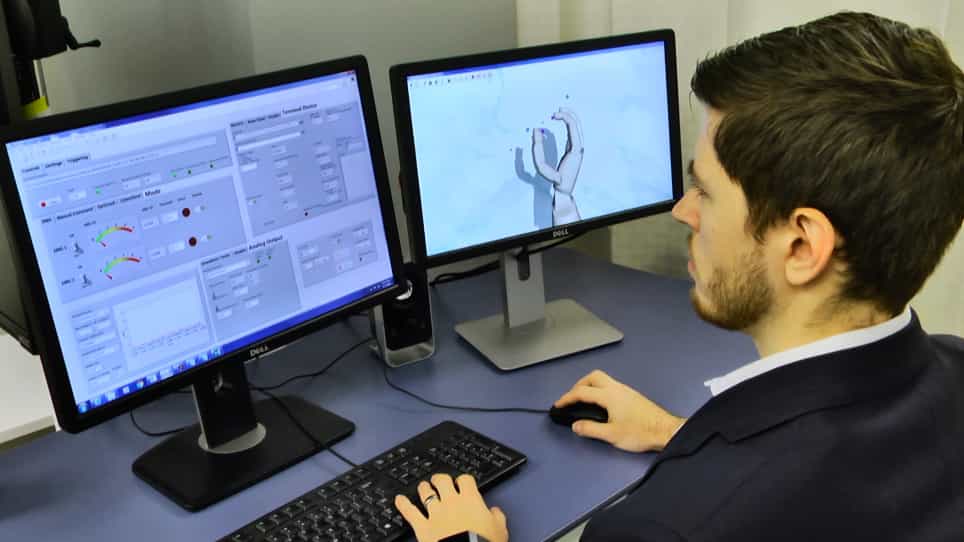

Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
Alignment of the attitude of teleoperators with that of a semi-autonomous android
Tomonori Kubota1,2,3, Kohei Ogawa4, Yuichiro Yoshikawa5
1Department of Systems Innovation, Osaka University, Toyonaka, Osaka, 560-8531, Japan. kubota.tomonori@irl.sys.es.osaka-u.ac.jp.

Abstract:
Studies on social robots that can communicate with humans are increasingly important. In particular, semi-aautonomous robots have shown potential for practical applications in which robot autonomy and human teleoperation are jointly used to accomplish difficult tasks. However, it is unknown how the attitude represented in the autonomous behavior of the robots affects teleoperators. Previous studies reported that when humans play a particular role, their attitudes align with that role. The teleoperators of semi-autonomous robots also play the role given to the robots and may assimilate their autonomous expression. We hypothesized that the attitude of teleoperators may align with that of robots through teleoperation. To verify this, we conducted an experiment with conditions under which a participant operated a part of the body of an android robot that autonomously expressed a preferential attitude toward a painting and a condition under which they did not. Experimental results demonstrated that the preferential attitude of participants who teleoperated the android aligned statistically significantly more with that of the robot in comparison to those who did not teleoperate it, thereby supporting our hypothesis. This finding is novel regarding attitude change in teleoperators of semi-autonomous robots and can support the implementation of effective human-robot collaboration systems.
More Related Videos
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024
 08:01
Virtual Hand with Ambiguous Movement between the Self and Other Origin: Sense of Ownership and 'Other-Produced' Agency
Published on: October 28, 2020
