Related Experiment Video
Updated: Sep 6, 2025


Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
Approximation in shift-invariant spaces with deep ReLU neural networks
Yunfei Yang1, Zhen Li2, Yang Wang3
1Department of Mathematics, The Hong Kong University of Science and Technology, Clear Water Bay, Kowloon, Hong Kong; Theory Lab, Huawei Technologies Co., Ltd., Shenzhen, China.

Abstract:
We study the expressive power of deep ReLU neural networks for approximating functions in dilated shift-invariant spaces, which are widely used in signal processing, image processing, communications and so on. Approximation error bounds are estimated with respect to the width and depth of neural networks. The network construction is based on the bit extraction and data-fitting capacity of deep neural networks. As applications of our main results, the approximation rates of classical function spaces such as Sobolev spaces and Besov spaces are obtained. We also give lower bounds of the Lp(1≤p≤∞) approximation error for Sobolev spaces, which show that our construction of neural network is asymptotically optimal up to a logarithmic factor.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:28
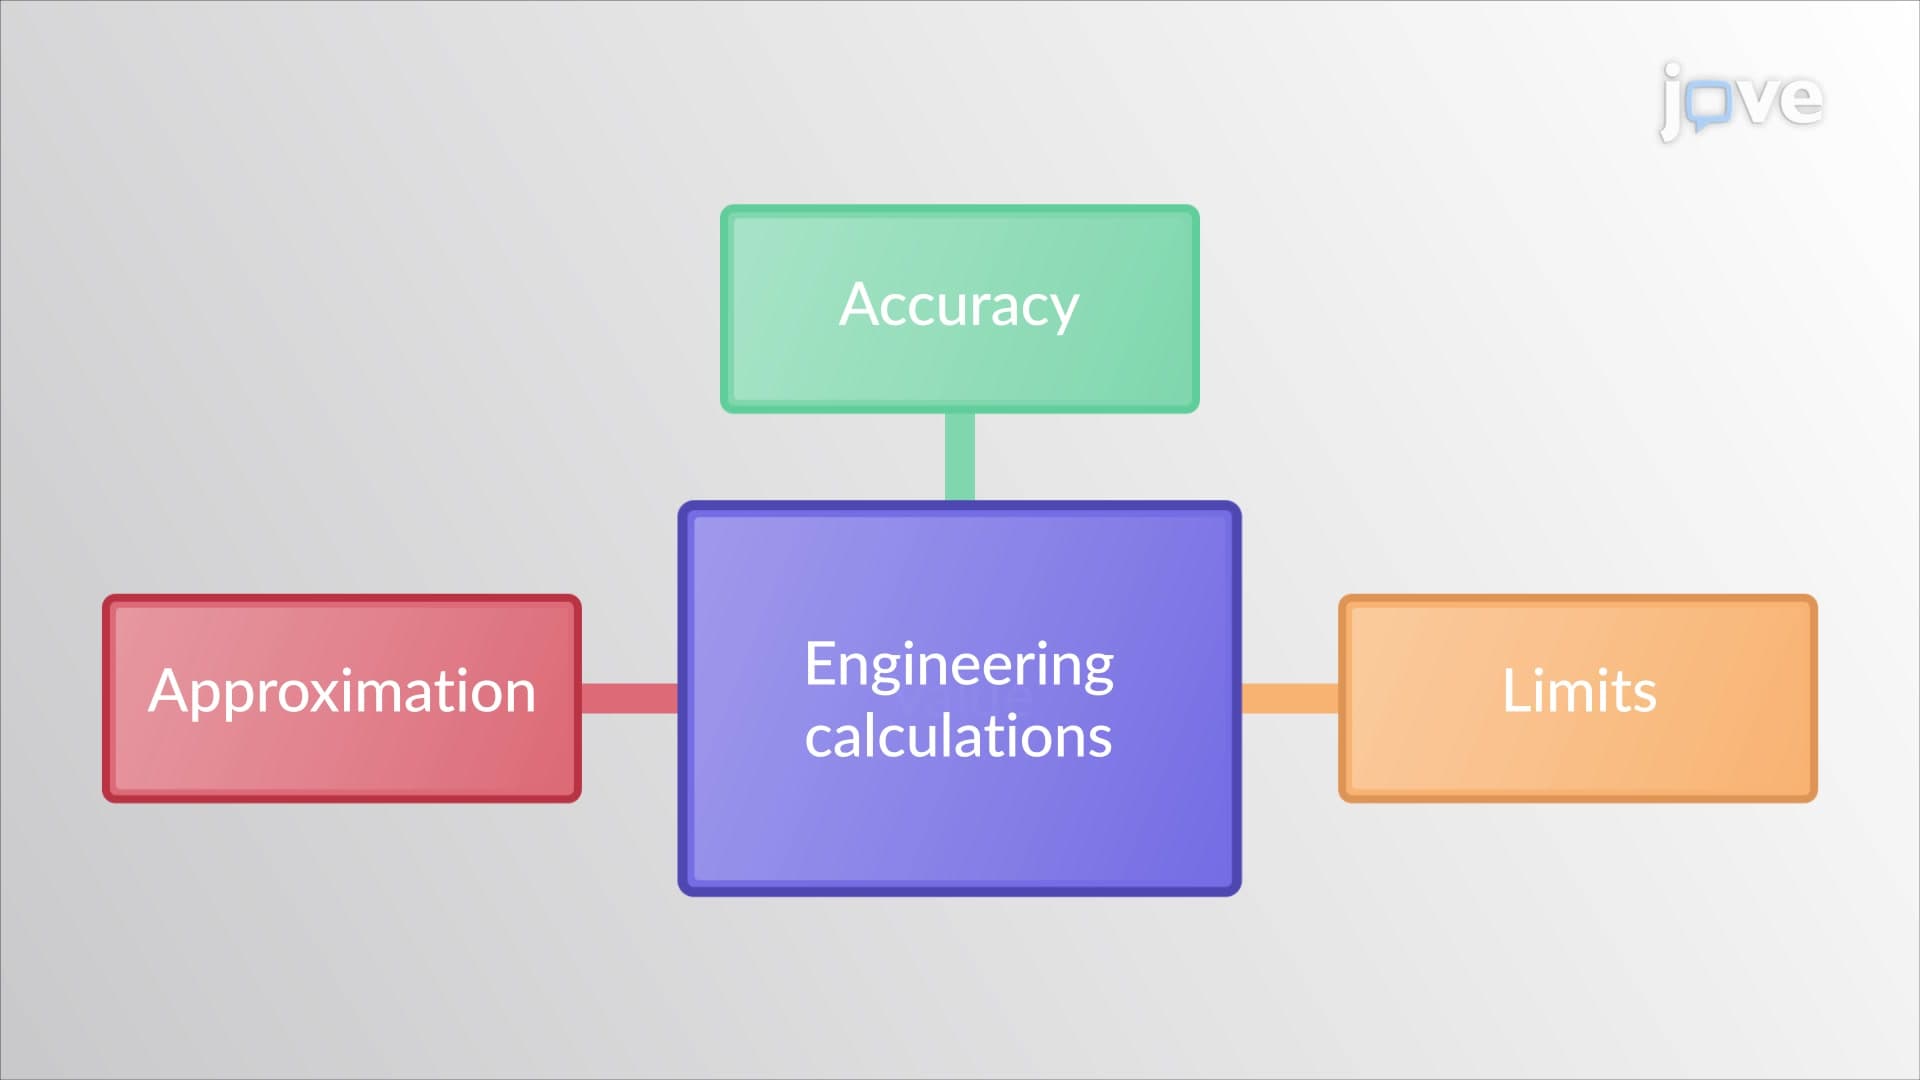
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
Comparison between RL and RC circuits
 01:27
State Space Representation
Consider an RLC circuit, a...