Related Experiment Video
Updated: Sep 6, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Control of escapes in two-degree-of-freedom open Hamiltonian systems
Alexandre R Nieto1, Thomas Lilienkamp2, Jesús M Seoane1
1Nonlinear Dynamics, Chaos and Complex Systems Group, Departamento de Física, Universidad Rey Juan Carlos, Tulipán s/n, 28933 Móstoles, Madrid, Spain.

Abstract:
We investigate the possibility of avoiding the escape of chaotic scattering trajectories in two-degree-of-freedom Hamiltonian systems. We develop a continuous control technique based on the introduction of coupling forces between the chaotic trajectories and some periodic orbits of the system. The main results are shown through numerical simulations, which confirm that all trajectories starting near the stable manifold of the chaotic saddle can be controlled. We also show that it is possible to jump between different unstable periodic orbits until reaching a stable periodic orbit belonging to a Kolmogorov-Arnold-Moser island.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:14
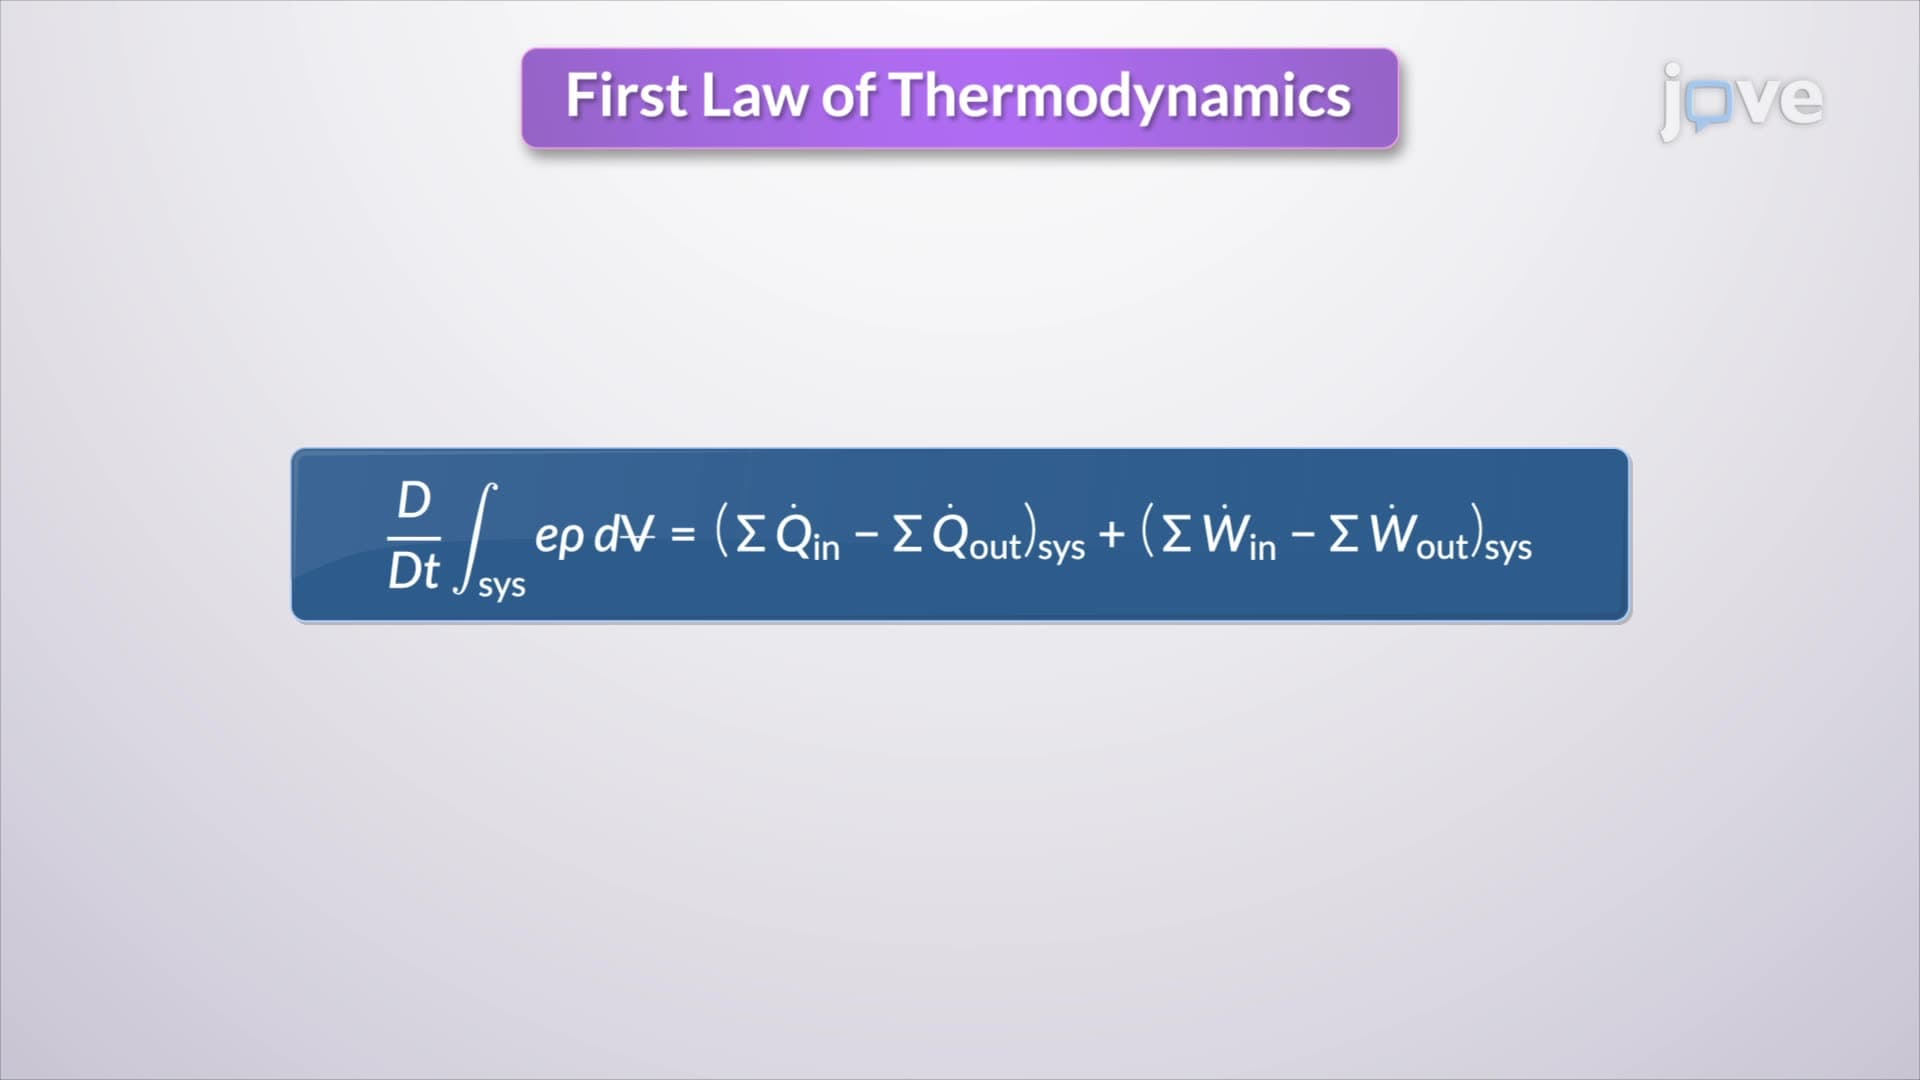
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:18
Second Order systems II