On the Solutions of a Quadratic Integral Equation of the Urysohn Type of Fractional Variable Order
Related Experiment Video
Updated: Sep 3, 2025
Facile Preparation of 4-Substituted Quinazoline Derivatives
Published on: February 15, 2016
Amar Benkerrouche1, Mohammed Said Souid2, Gani Stamov3
1Department of Mathématiques, Ziane Achour University of Djelfa, Djelfa 17000, Algeria.

Abstract:
In this manuscript we introduce a quadratic integral equation of the Urysohn type of fractional variable order. The existence and uniqueness of solutions of the proposed fractional model are studied by transforming it into an integral equation of fractional constant order. The obtained new results are based on the Schauder's fixed-point theorem and the Banach contraction principle with the help of piece-wise constant functions. Although the used methods are very powerful, they are not applied to the quadratic integral equation of the Urysohn type of fractional variable order. With this research we extend the applicability of these techniques to the introduced the Urysohn type model of fractional variable order. The applicability of the new results are demonstrated by providing Ulam-Hyers stability criteria and an example. Moreover, the presented results lead to future progress and expansion of the theory of fractional-order models, as well as of the concept of entropy in the framework of fractional calculus. Further, an example is constructed to demonstrate the reasonableness and effectiveness of the observed results.
Related Concept Videos
 01:19
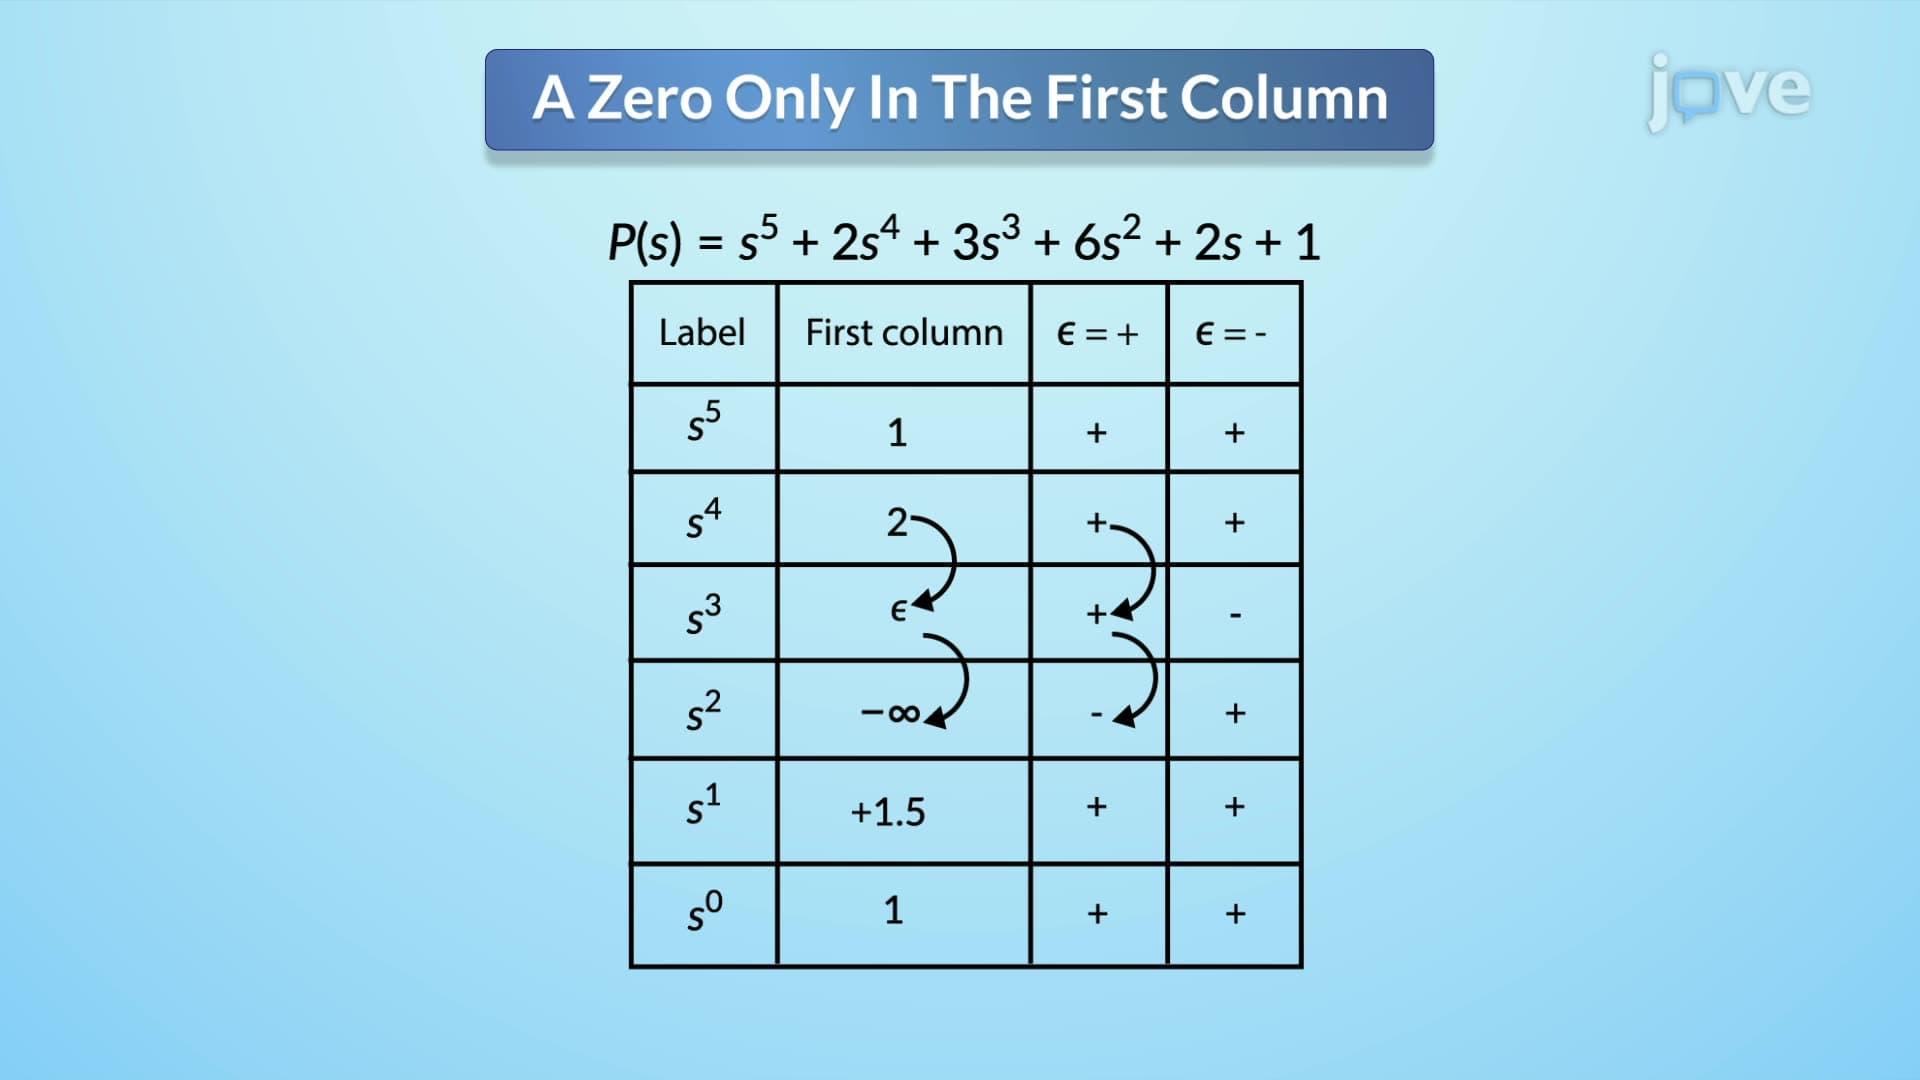
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:31
Alternative Sets of Equilibrium Equations
One example of such a situation can be observed in a...
 01:20
Inverse z-Transform by Partial Fraction Expansion
To begin the process, the poles of the function are identified and the function is...
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:19
Euler Equations of Motion