Related Experiment Video
Updated: Sep 3, 2025

A Swin Transformer-Based Model for Thyroid Nodule Detection in Ultrasound Images
Published on: April 21, 2023
STTG-net: a Spatio-temporal network for human motion prediction based on transformer and graph convolution network
Lujing Chen1, Rui Liu2, Xin Yang3
1National and Local Joint Engineering Laboratory of Computer Aided Design, School of Software Engineering, Dalian University, Dalian, 116622, China.

Abstract:
In recent years, human motion prediction has become an active research topic in computer vision. However, owing to the complexity and stochastic nature of human motion, it remains a challenging problem. In previous works, human motion prediction has always been treated as a typical inter-sequence problem, and most works have aimed to capture the temporal dependence between successive frames. However, although these approaches focused on the effects of the temporal dimension, they rarely considered the correlation between different joints in space. Thus, the spatio-temporal coupling of human joints is considered, to propose a novel spatio-temporal network based on a transformer and a gragh convolutional network (GCN) (STTG-Net). The temporal transformer is used to capture the global temporal dependencies, and the spatial GCN module is used to establish local spatial correlations between the joints for each frame. To overcome the problems of error accumulation and discontinuity in the motion prediction, a revision method based on fusion strategy is also proposed, in which the current prediction frame is fused with the previous frame. The experimental results show that the proposed prediction method has less prediction error and the prediction motion is smoother than previous prediction methods. The effectiveness of the proposed method is also demonstrated comparing it with the state-of-the-art method on the Human3.6 M dataset.

Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:07
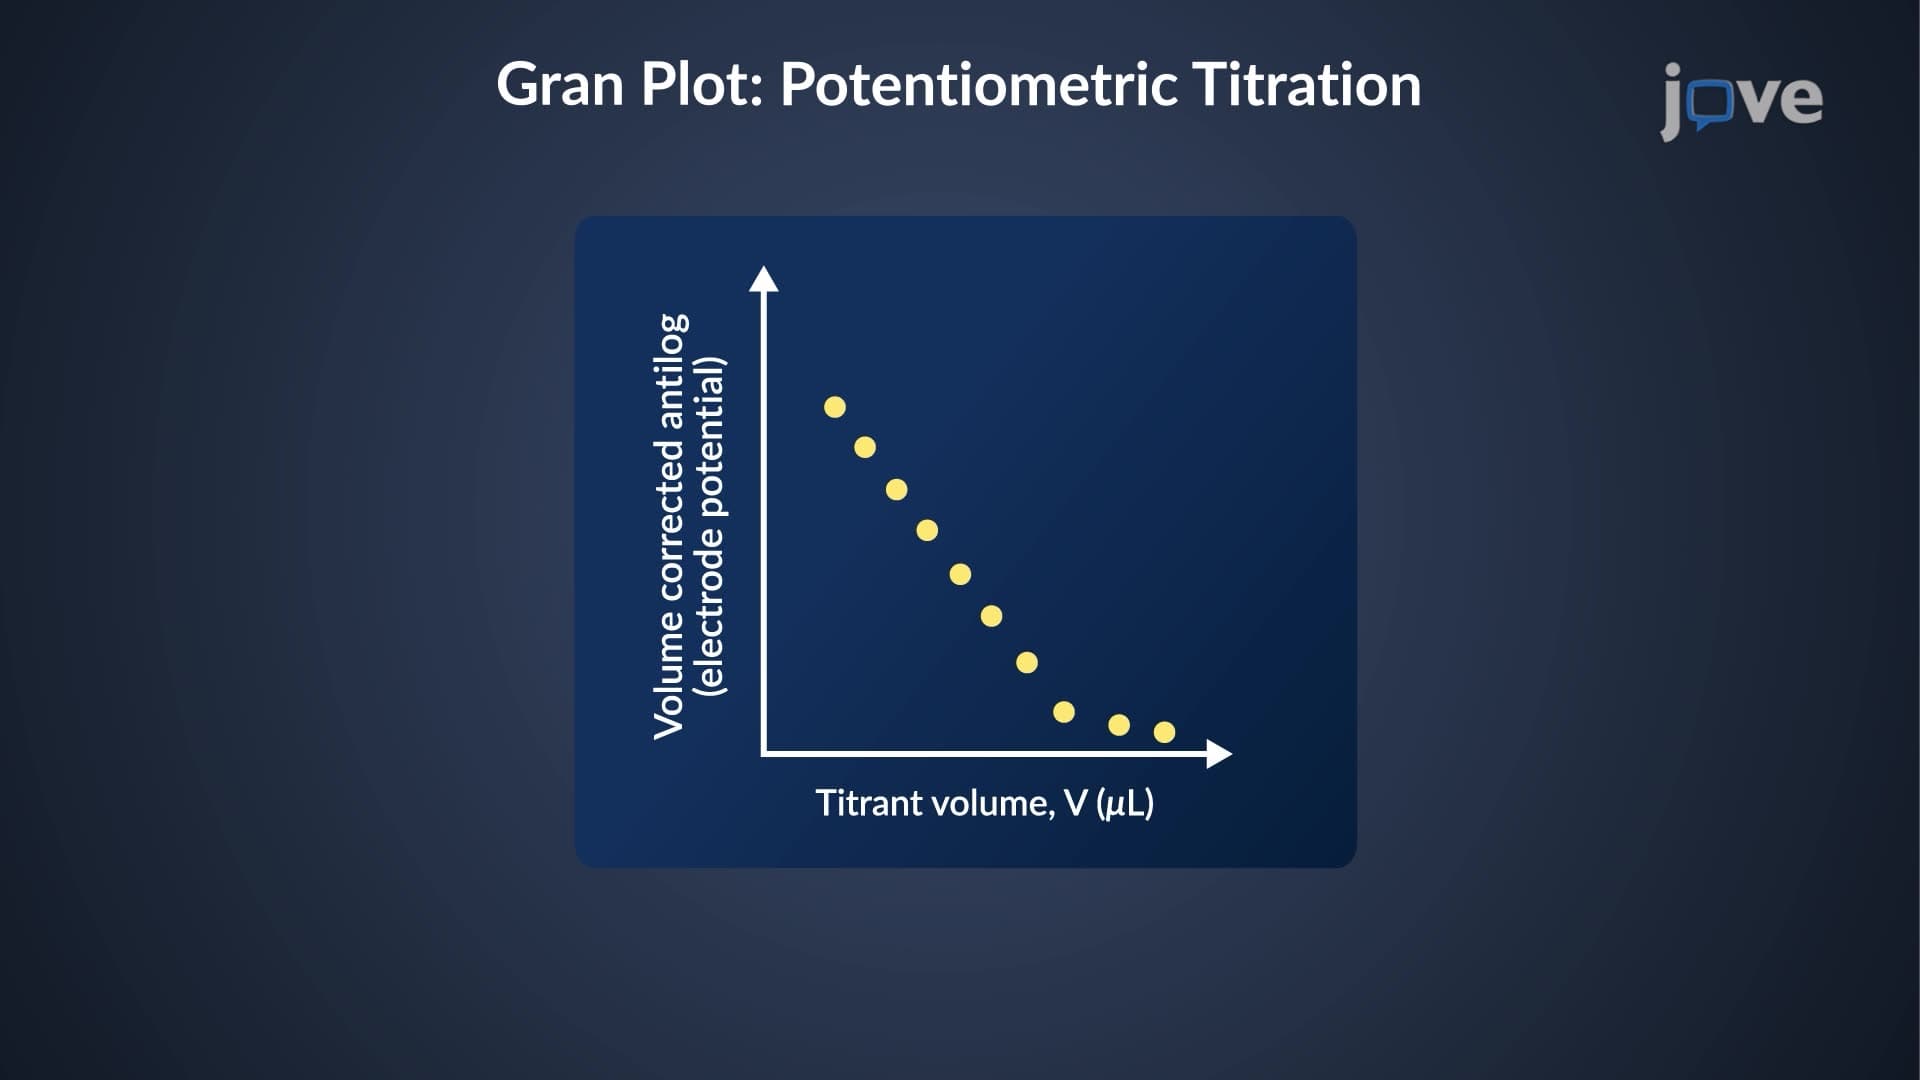
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:27
Transformers in Distribution System
Distribution substation transformers come in various ratings and typically use mineral oil for insulation and cooling. To prevent moisture and air from entering the oil, some transformers use an inert gas like nitrogen to fill the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...