On new sixth and seventh order iterative methods for solving non-linear equations using homotopy perturbation technique
Related Experiment Video
Updated: Sep 3, 2025
The Generation of Higher-order Laguerre-Gauss Optical Beams for High-precision Interferometry
Published on: August 12, 2013
Srinivasarao Thota1, P Shanmugasundaram2
1Department of Mathematics, School of Sciences, SR University, Warangal, Telangana, 506371, India. srinithota@ymail.com.

Objectives:
This paper proposes three iterative methods of order three, six and seven respectively for solving non-linear equations using the modified homotopy perturbation technique coupled with system of equations. This paper also discusses the analysis of convergence of the proposed iterative methods.
Results:
Several numerical examples are presented to illustrate and validation of the proposed methods. Implementation of the proposed methods in Maple is discussed with sample computations.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 13:07
Optical Coherence Tomography Based Biomechanical Fluid-Structure Interaction Analysis of Coronary Atherosclerosis Progression
Published on: January 15, 2022
Related Concept Videos
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:18
Second Order systems II
 01:19
Routh-Hurwitz Criterion II
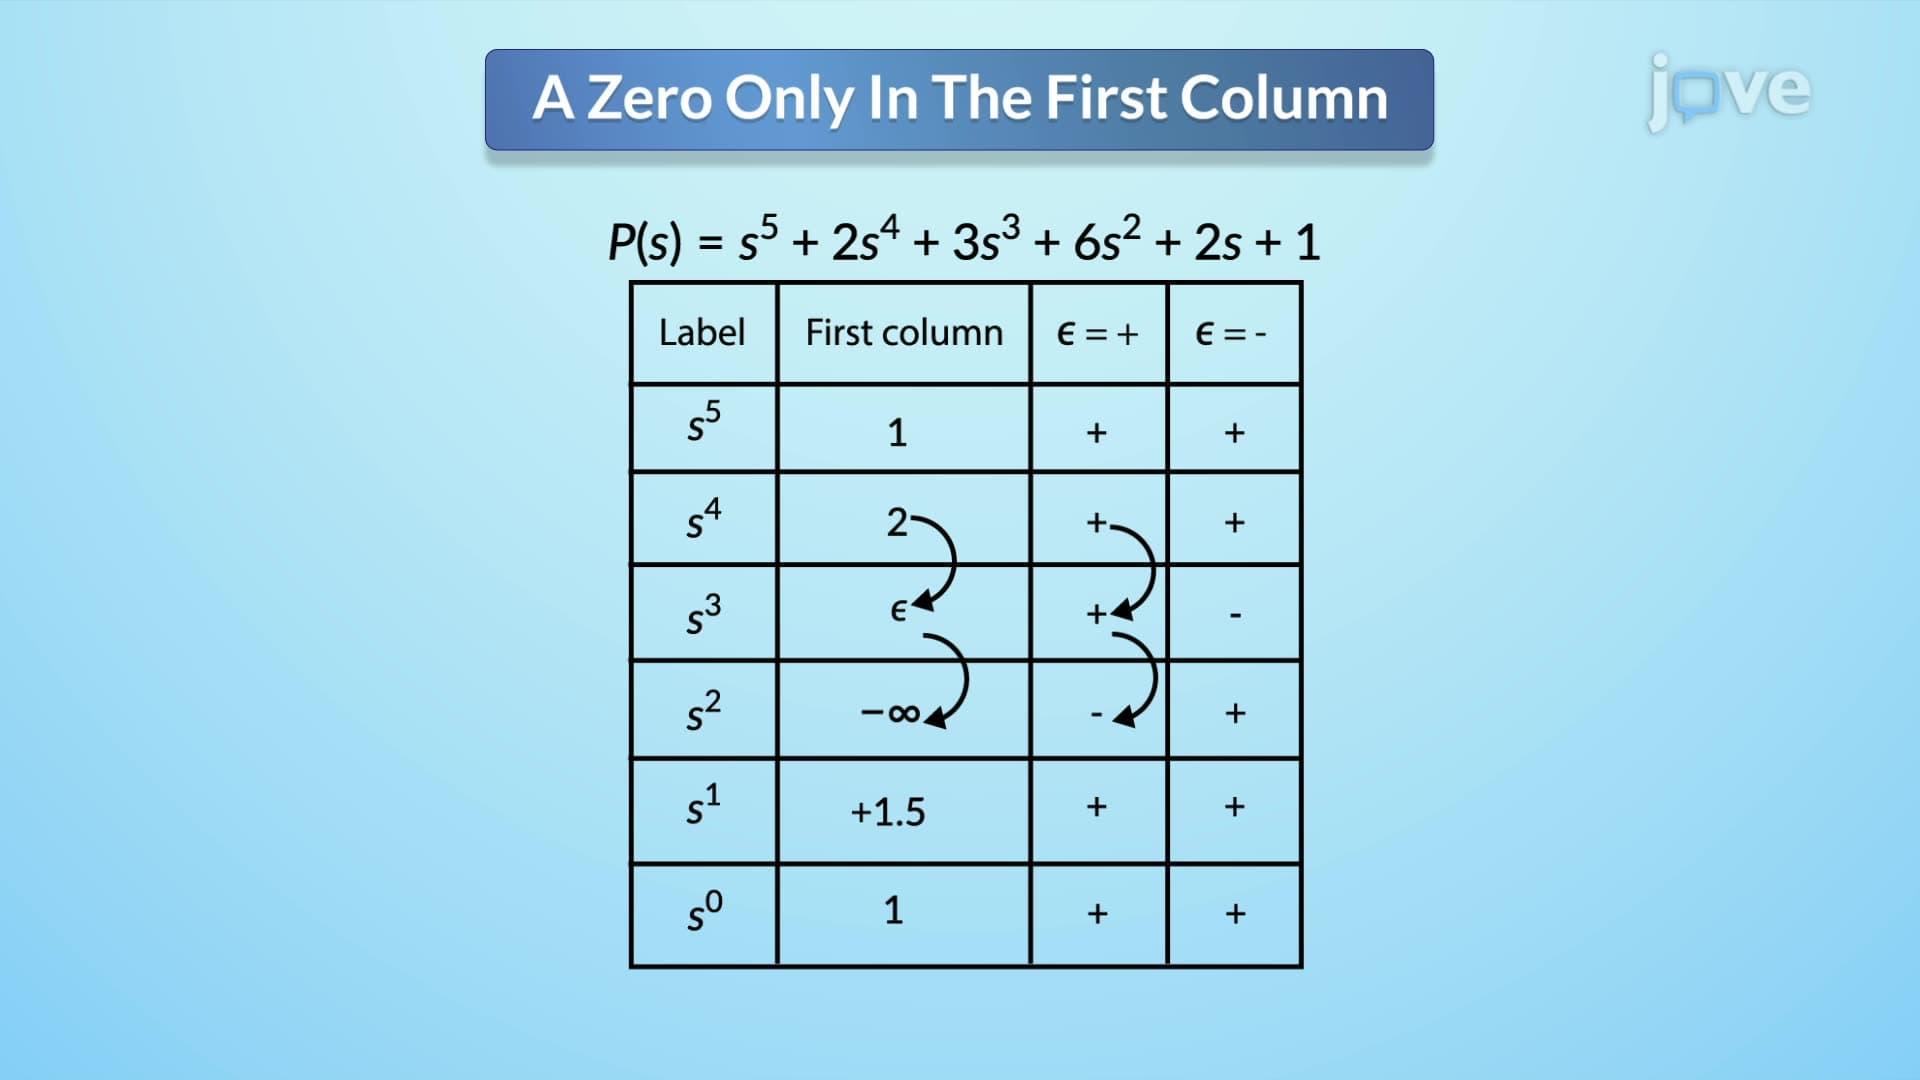
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:20
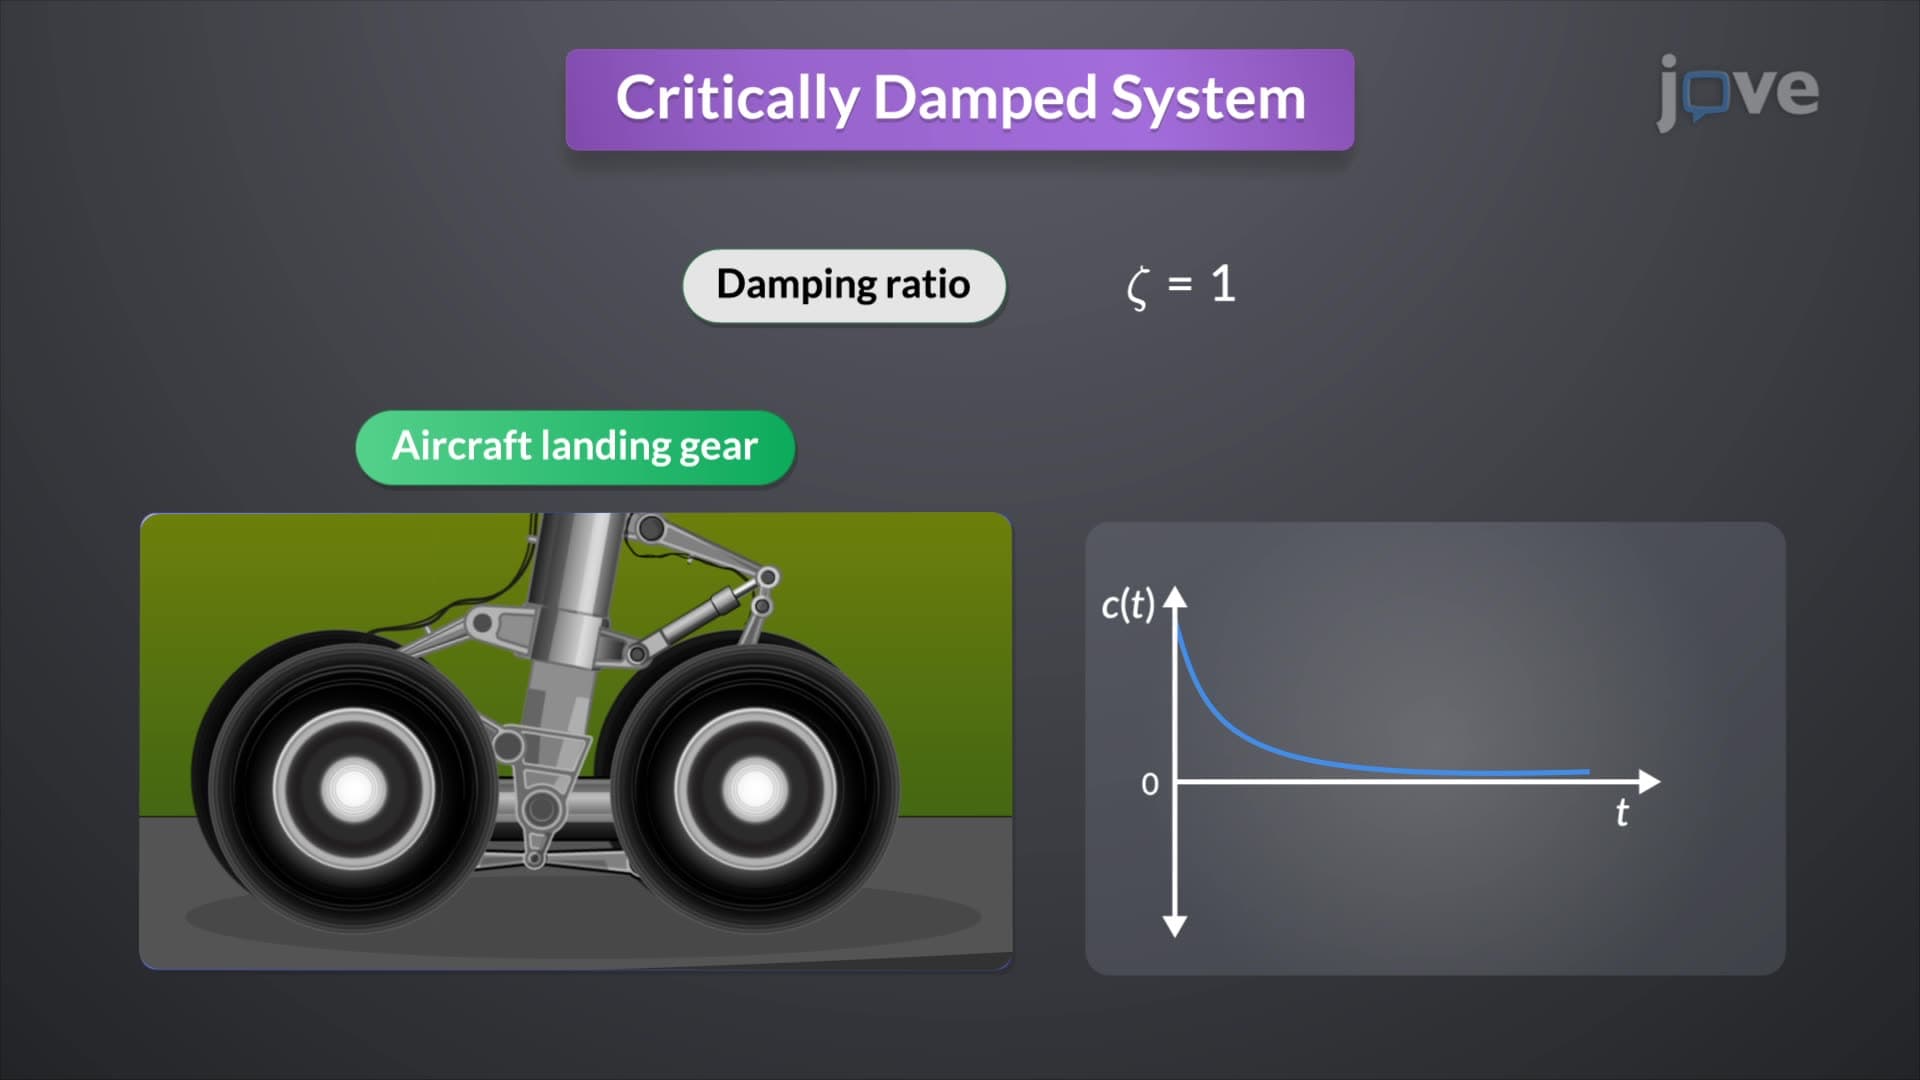
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:22
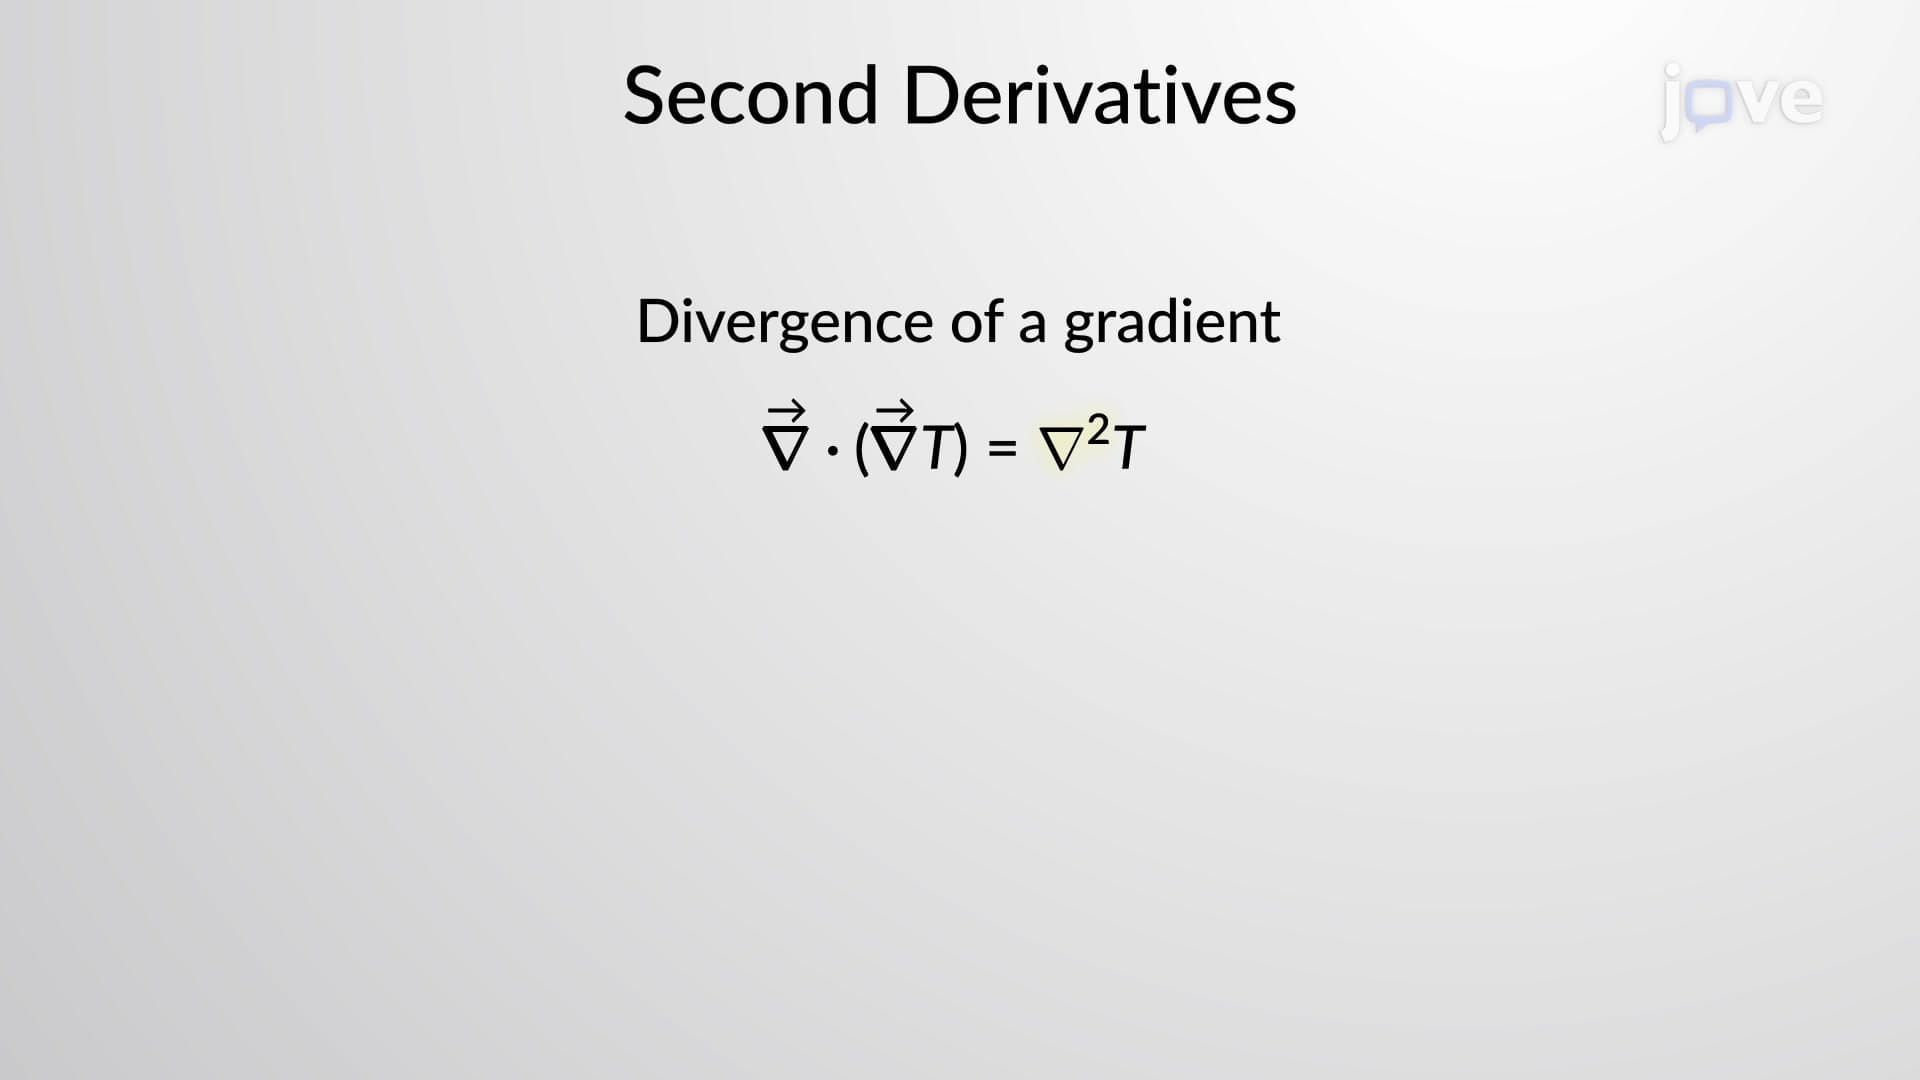
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...