Related Experiment Video
Updated: Aug 31, 2025


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Hierarchical and synergistic organization of control variables during the multi-digit grasp of a free and an
Junkyung Song1, Kitae Kim2, Satyajit Ambike3
1Department of Physical Education, Seoul National University, Seoul, South Korea.

Abstract:
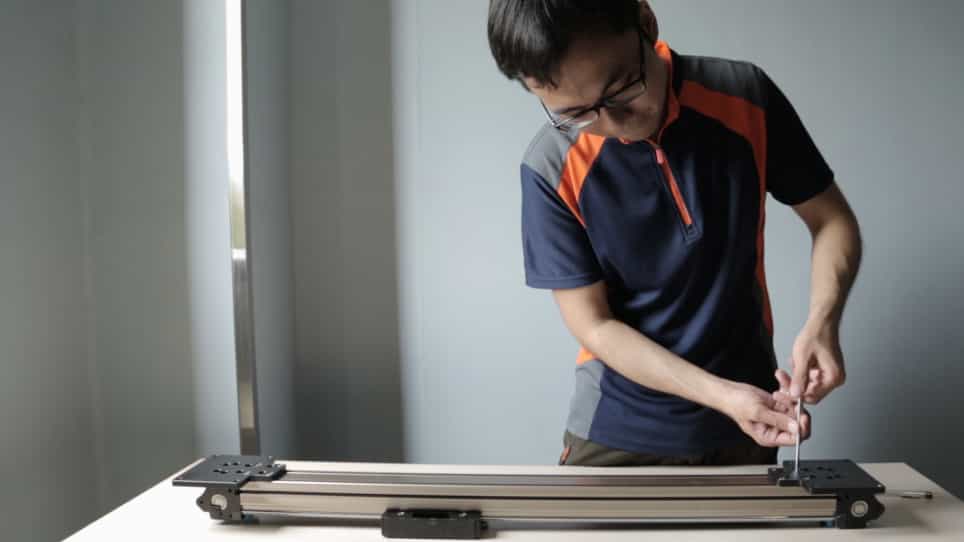
In the referent control theory, grip force emerges by designating the referent aperture (Ra) as a threshold position inside the object. This study quantified Ra and investigated whether the synergistic control of digit referent coordinate (RC) and apparent stiffness (k) depend on the external mechanical constraints on the hand-held object. Subjects held a motorized handle capable of adjusting the grip width and performed static multi-digit prehension tasks in which the handle was free and externally fixed in different conditions. The RC and k of individual digits were reconstructed from the changes in digit normal forces and the positions as the grip width was modulated. RCs of the thumb and virtual finger were used to calculate the width and midpoint of Ra, and synergy indices quantifying the task-specific covariation in the space of the digit normal forces and {RC, k} variables were computed. We found that the k and width of the Ra were larger when holding a free handle than the fixed handle. The higher stiffness in the free condition could be a strategy to ensure grip stability. The midpoint of Ra was skewed toward the virtual finger, reflecting different magnitudes of k for the two digits. Further, the normal forces and control variables {RC, k} displayed synergistic covariation for stabilization of the total grasping force. Finally, the synergies were weaker when the handle was externally fixed, demonstrating the dependence of synergies on external constraints. These results add to the current literature by demonstrating that grasp control involves modulation of digit apparent stiffness in addition to the referent coordinate and by identifying the synergistic organization of the control variables during static grasp.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:10
Control Systems
At the heart...