Differential biases in human-human versus human-robot interactions
Related Experiment Video
Updated: Aug 31, 2025
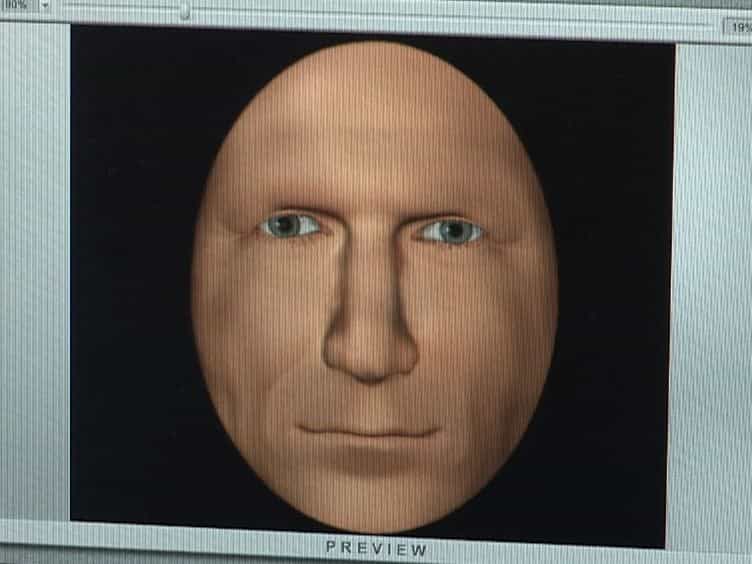
Perceptual and Category Processing of the Uncanny Valley Hypothesis' Dimension of Human Likeness: Some Methodological Issues
Published on: June 3, 2013
Gene M Alarcon1, August Capiola1, Izz Aldin Hamdan2
1Air Force Research Laboratory, United States.

Abstract:
The research on human-robot interactions indicates possible differences toward robot trust that do not exist in human-human interactions. Research on these differences has traditionally focused on performance degradations. The current study sought to explore differences in human-robot and human-human trust interactions with performance, consideration, and morality trustworthiness manipulations, which are based on ability/performance, benevolence/purpose, and integrity/process manipulations, respectively, from previous research. We used a mixed factorial hierarchical linear model design to explore the effects of trustworthiness manipulations on trustworthiness perceptions, trust intentions, and trust behaviors in a trust game. We found partner (human versus robot) differences across all three trustworthiness perceptions, indicating biases towards robots may be more expansive than previously thought. Additionally, there were marginal effects of partner differences on trust intentions. Interestingly, there were no differences between partners on trust behaviors. Results indicate human biases toward robots may be more complex than considered in the literature.
Related Concept Videos
 02:16
Stereotype Content Model
 01:14
Fundamental Attribution Error
 01:22
Bias
In statistics, a sampling bias is created when a sample is collected from a population, and some members of the population are not as likely to be chosen as others (remember, each member...
 01:31
Confirmation Biases
 02:30
Naturalistic Observations
 02:55
Stereotypes, Prejudice, and Discrimination