Related Experiment Video
Updated: Aug 30, 2025


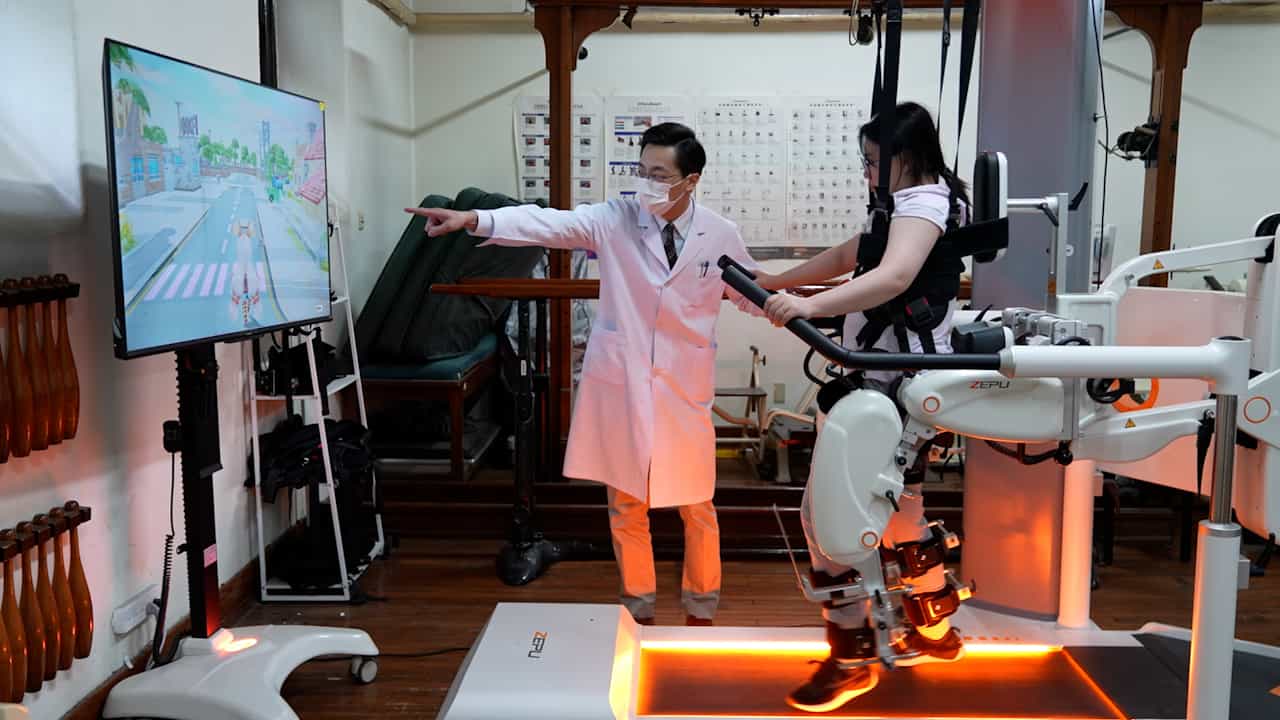
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
A review of the design of load-carrying exoskeletons
JieJunYi Liang1, QinHao Zhang1, Yang Liu1
1State Key Laboratory of Digital Manufacturing Equipment and Technology, Huazhong University of Science and Technology, Wuhan, 430074 China.

Abstract:
The increasing necessity of load-carrying activities has led to greater human musculoskeletal damage and an increased metabolic cost. With the rise of exoskeleton technology, researchers have begun exploring different approaches to developing wearable robots to augment human load-carrying ability. However, there is a lack of systematic discussion on biomechanics, mechanical designs, and augmentation performance. To achieve this, extensive studies have been reviewed and 108 references are selected mainly from 2013 to 2022 to address the most recent development. Other earlier 20 studies are selected to present the origin of different design principles. In terms of the way to achieve load-carrying augmentation, the exoskeletons reviewed in this paper are sorted by four categories based on the design principles, namely load-suspended backpacks, lower-limb exoskeletons providing joint torques, exoskeletons transferring load to the ground and exoskeletons transferring load between body segments. Specifically, the driving modes of active and passive, the structure of rigid and flexible, the conflict between assistive performance and the mass penalty of the exoskeleton, and the autonomy are discussed in detail in each section to illustrate the advances, challenges, and future trends of exoskeletons designed to carry loads.
More Related Videos
Related Concept Videos
 01:22
Design Consideration
The factor of safety is another key...
 01:30
Machines: Problem Solving II
 01:26
Frames: Problem Solving II
 01:16
Eccentric Loading
 01:04
Applications of Stress
The...
 01:19
Impact Loading
In cases of elastic deformation,...