Fast Quaternion Product Units for Learning Disentangled Representations in [Formula: see text]
Related Experiment Video
Updated: Aug 30, 2025
Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015

Abstract:
Real-world 3D structured data like point clouds and skeletons often can be represented as data in a 3D rotation group (denoted as [Formula: see text]). However, most existing neural networks are tailored for the data in the euclidean space, which makes the 3D rotation data not closed under their algebraic operations and leads to sub-optimal performance in 3D-related learning tasks. To resolve the issues caused by the above mismatching between data and model, we propose a novel non-real neuron model called quaternion product unit (QPU) to represent data on 3D rotation groups. The proposed QPU leverages quaternion algebra and the law of the 3D rotation group, representing 3D rotation data as quaternions and merging them via a weighted chain of Hamilton products. We demonstrate that the QPU mathematically maintains the [Formula: see text] structure of the 3D rotation data during the inference process and disentangles the 3D representations into "rotation-invariant" features and "rotation-equivariant" features, respectively. Moreover, we design a fast QPU to accelerate the computation of QPU. The fast QPU applies a tree-structured data indexing process, and accordingly, leverages the power of parallel computing, which reduces the computational complexity of QPU in a single thread from O(N) to O(logN). Taking the fast QPU as a basic module, we develop a series of quaternion neural networks (QNNs), including quaternion multi-layer perceptron (QMLP), quaternion message passing (QMP), and so on. In addition, we make the QNNs compatible with conventional real-valued neural networks and applicable for both skeletons and point clouds. Experiments on synthetic and real-world 3D tasks show that the QNNs based on our fast QPUs are superior to state-of-the-art real-valued models, especially in the scenarios requiring the robustness to random rotations. The code of this work is available at https://github.com/SuferQin/Fast-QPU.

Related Concept Videos
 01:17
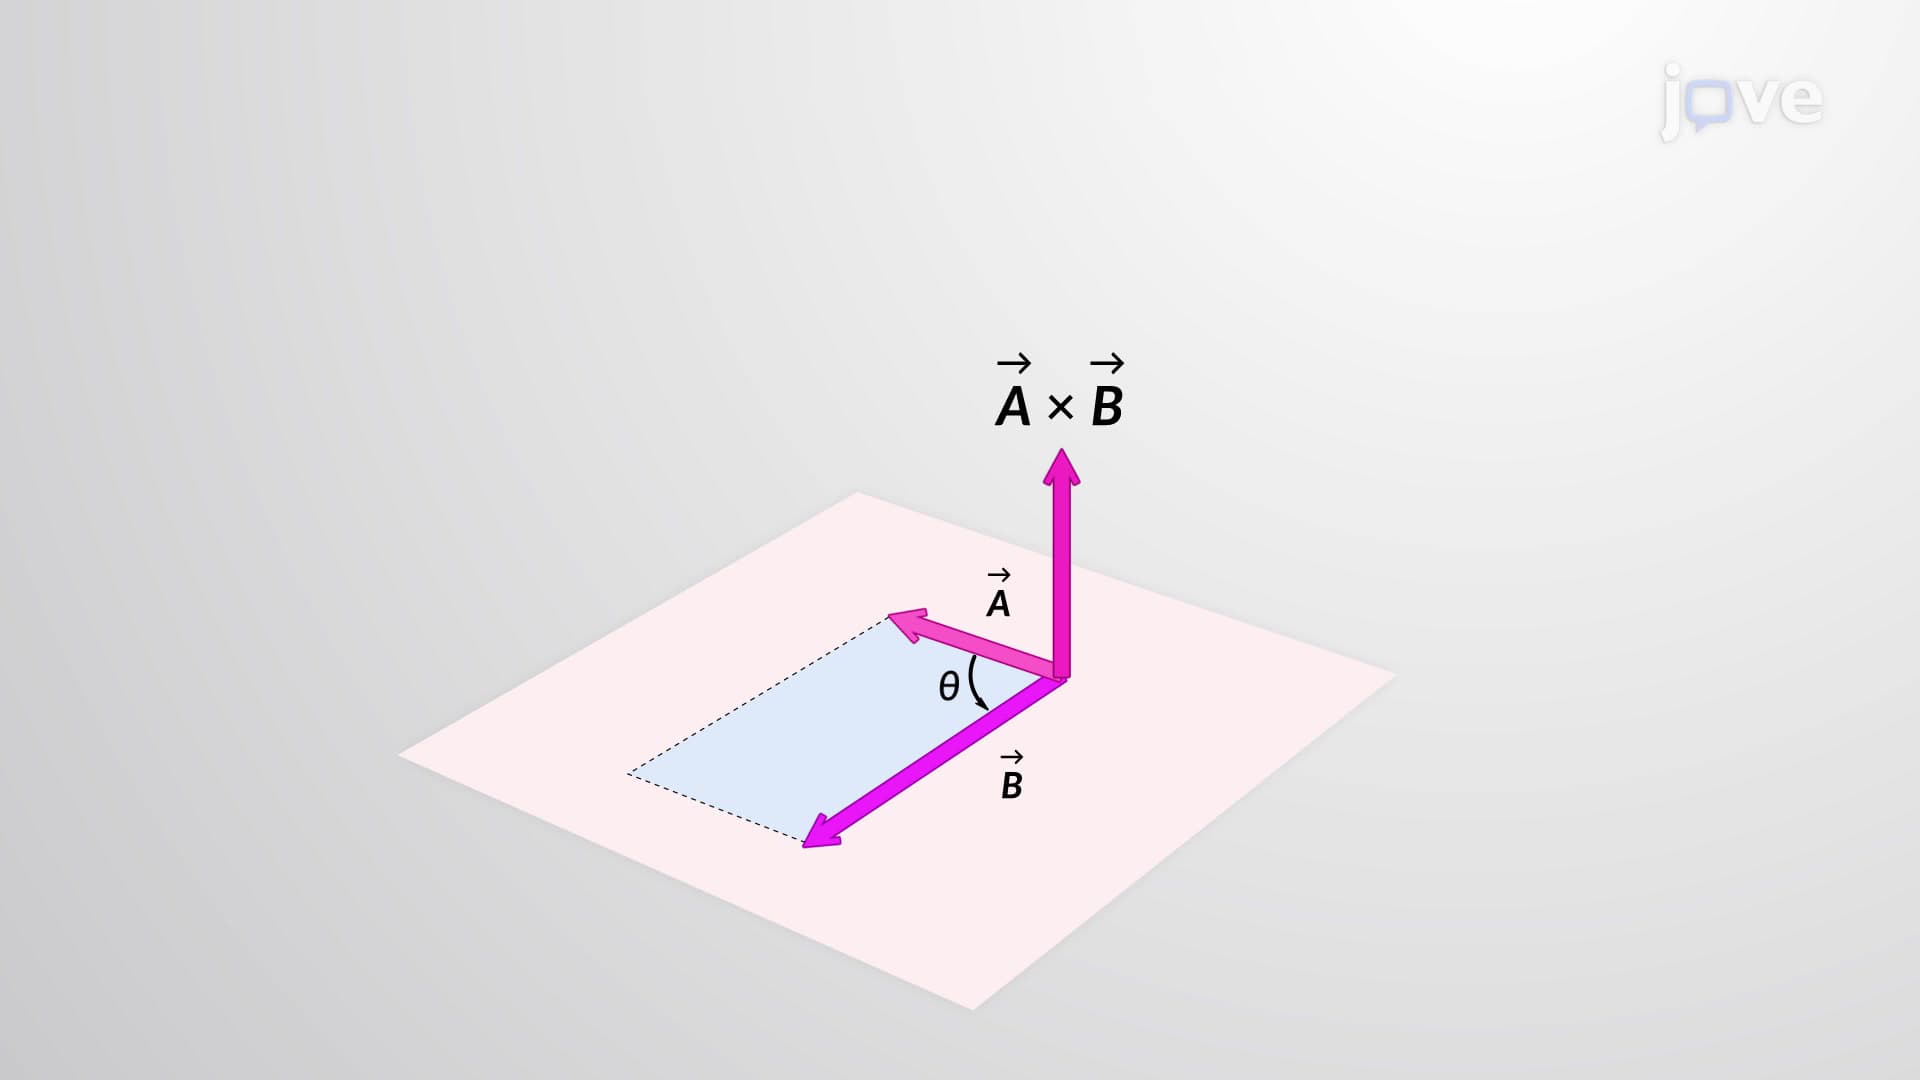
Vector Product (Cross Product)
Consider the cross product of two vectors. Imagine rotating the first vector about...
 01:28
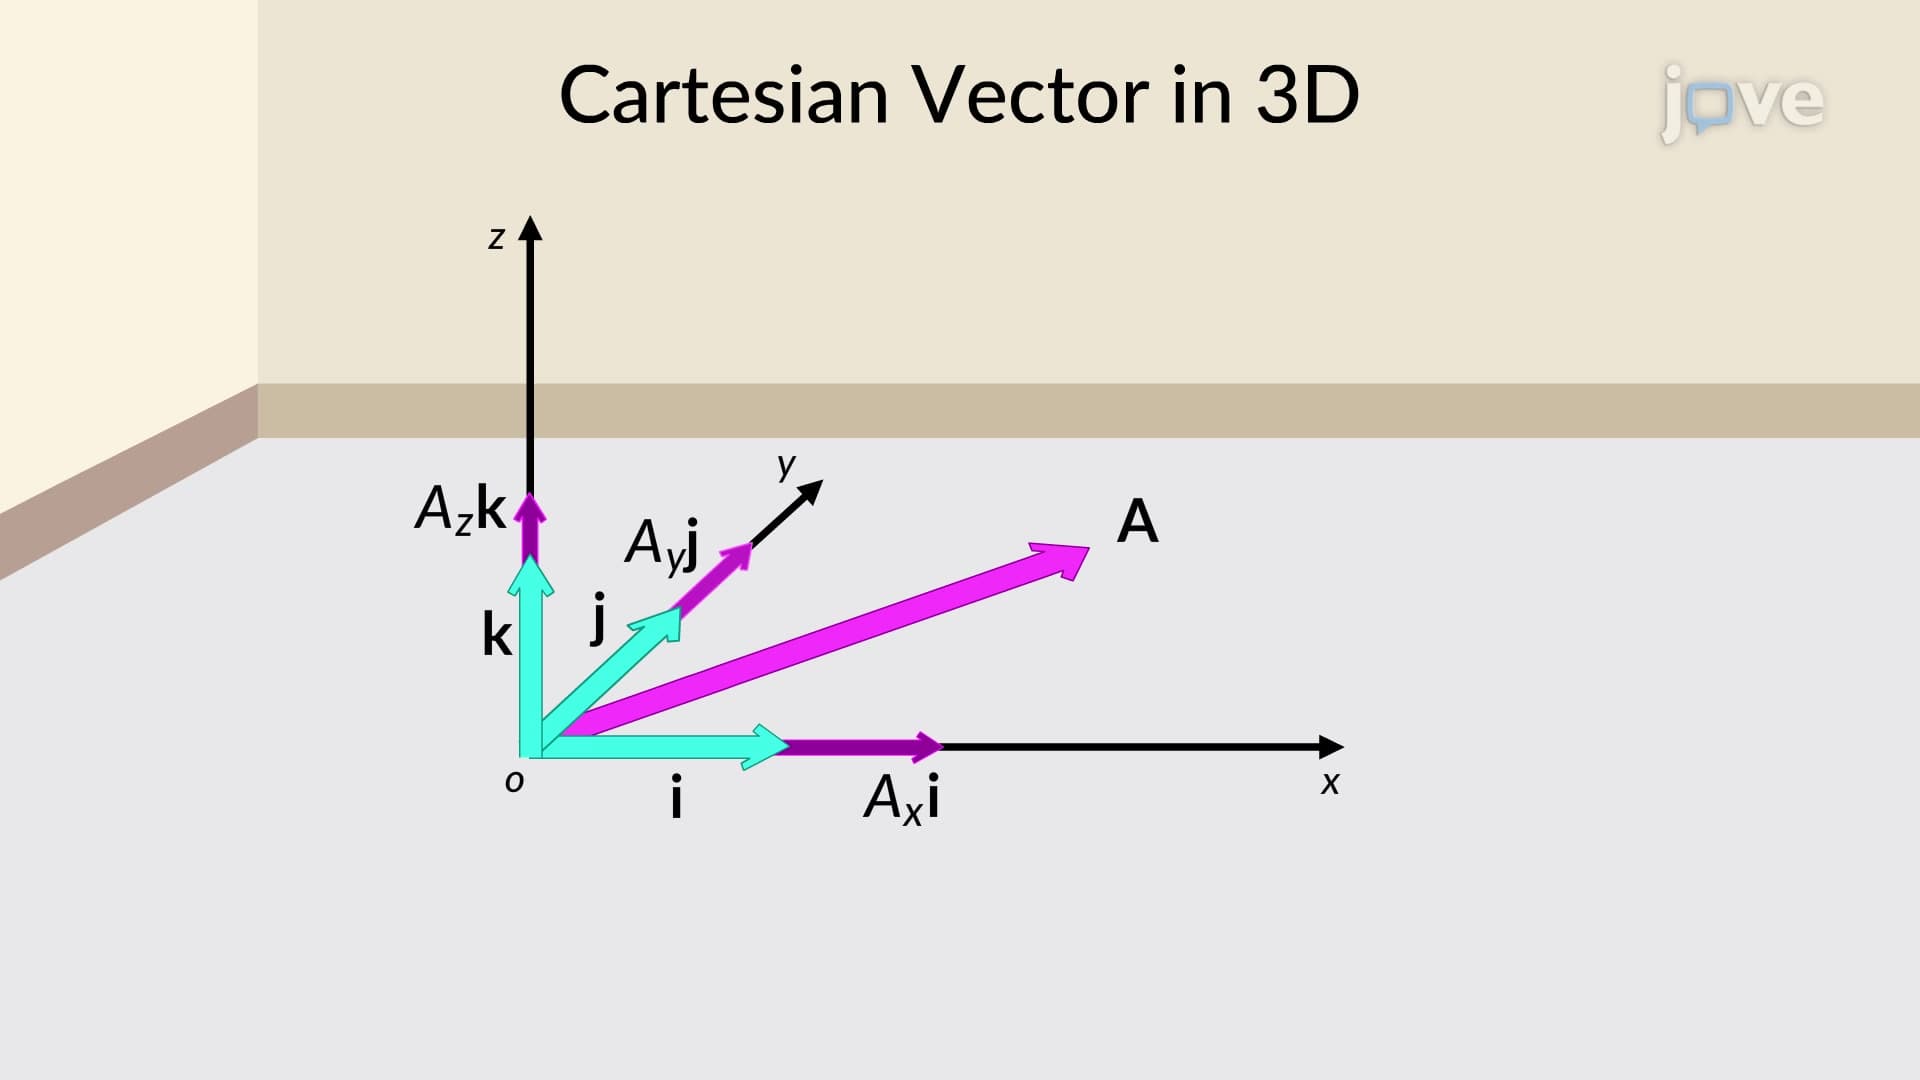
Cartesian Vector Notation
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Dot Product
In engineering, the dot product of any two vectors is the product of the magnitudes of the vectors and the cosine of the angle between them. It is denoted by a dot symbol between the two vectors.
Consider a vehicle pulling an object along the ground using a rope. If the rope makes an angle with the horizontal axis, the work done can be calculated using the dot product of the force applied and the object's displacement.
The dot...
 01:00
Position and Displacement Vectors
Further, several important kinds of...
 01:26
Cartesian Form for Vector Formulation