Related Experiment Video
Updated: Aug 29, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Supplementary Control for Quantized Discrete-Time Nonlinear Systems Under Goal Representation Heuristic Dynamic

Abstract:
This article is concerned with supplementary control of discrete-time nonlinear systems with multiple controllers in the framework of goal representation heuristic dynamic programming (GrHDP), where a logarithmic quantizer is used to govern the network communication. For the addressed problem, a neural network (NN)-based observer is first proposed to estimate the unknown system state in the simultaneous presence of quantized influence. In light of the estimated states and the ideal control inputs via a zero-sum game, a GrHDP algorithm with a reinforced term is developed to implement the supplementary control task, where some novel weight updating rules are constructed by virtue of an additional tunable parameter to improve the system performance. Furthermore, a set of conditions about the stability of estimated error dynamics of both observer states and updated NNs' weights are derived by resorting to the Lyapunov stability theory. Finally, the effectiveness of the developed method is verified by a power system and a numerical experiment.
More Related Videos
 11:54
Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:16
Statically Indeterminate Problem Solving
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:13
Stability of Equilibrium Configuration: Problem Solving
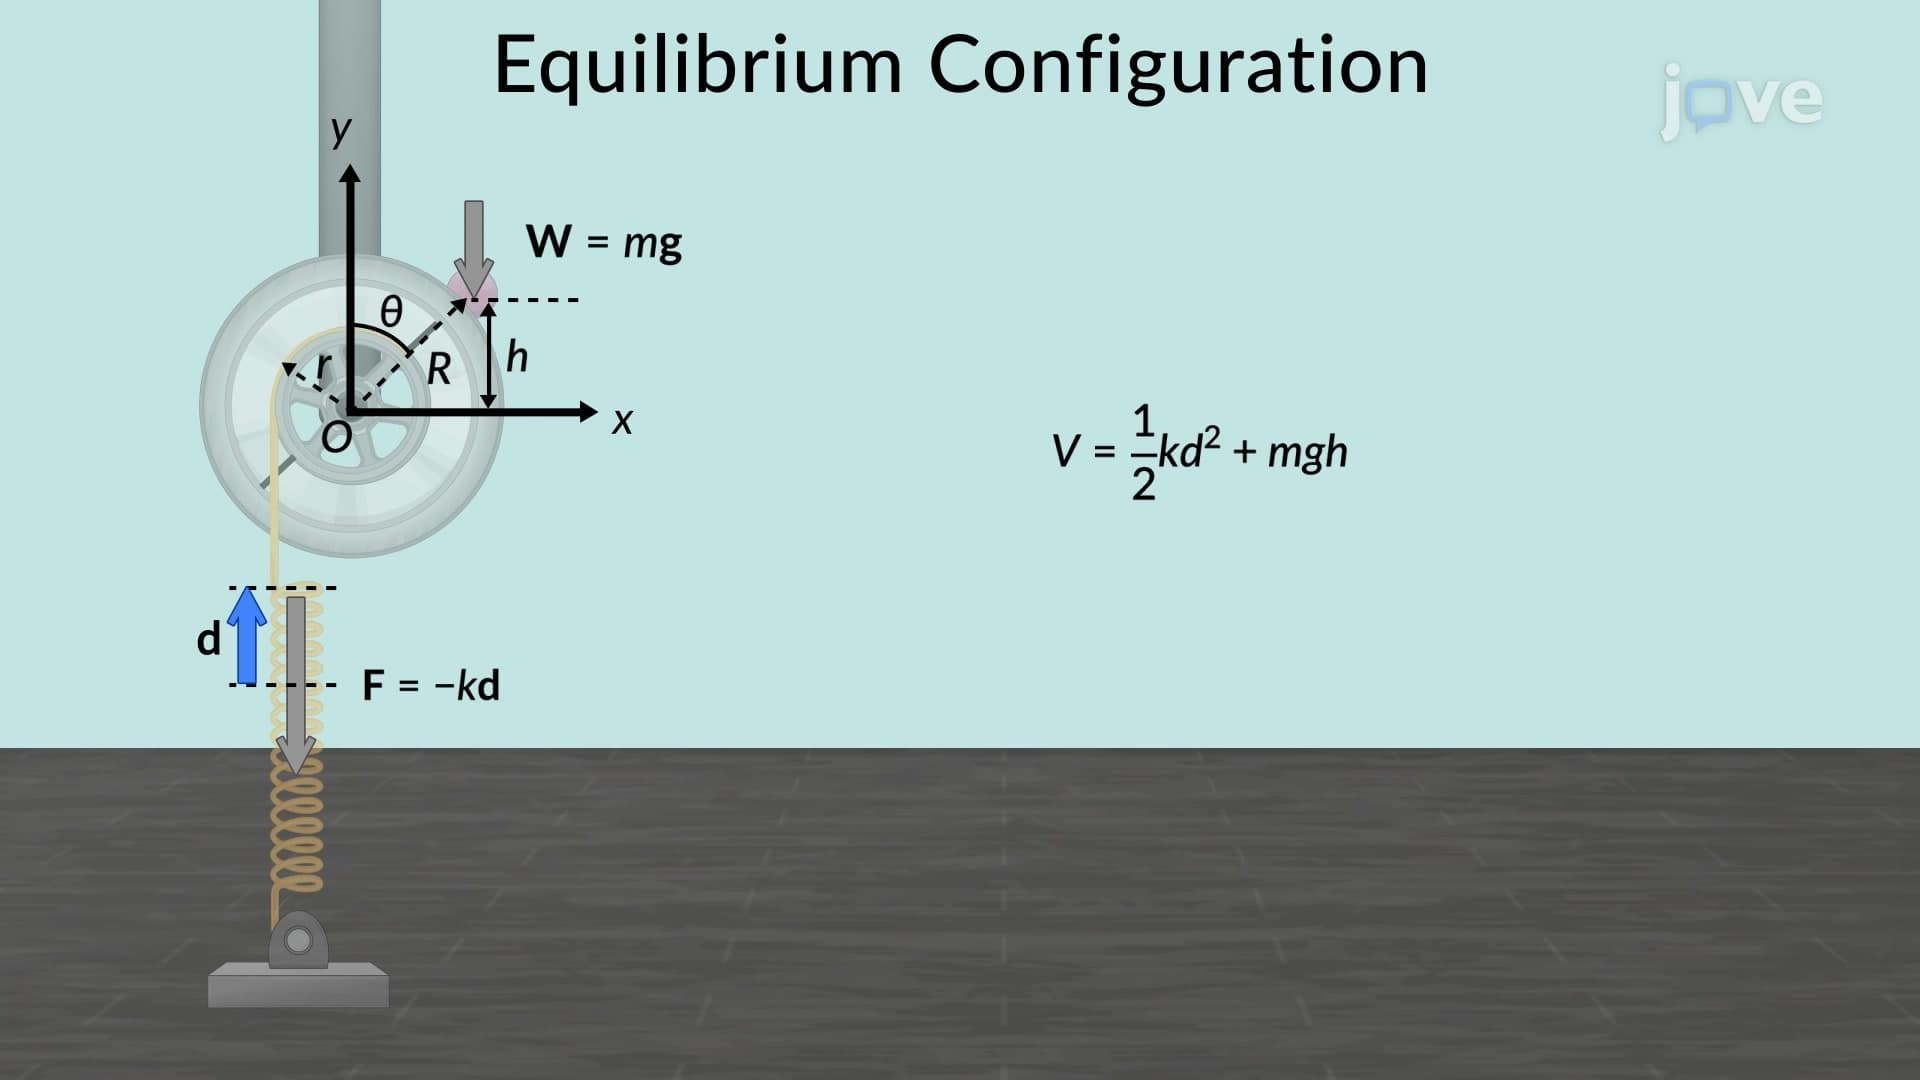
Problem-solving in the context of the stability of equilibrium configuration...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...